Research Papers

最新机器人研究的通俗英语摘要,涵盖人形机器人、四足机器人、工业自动化和人工智能。
499 论文
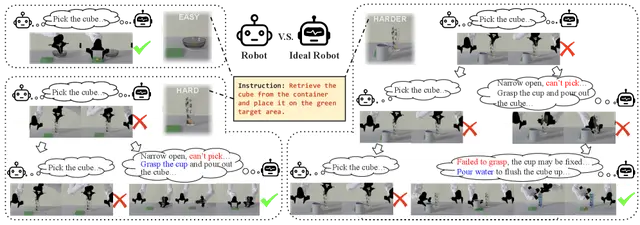
RoboWits基准测试:机器人在意外挑战下能否解决创造性问题?
AI6月1日

RoboWits基准测试:机器人在意外挑战下能否解决创造性问题?

RoboWits基准测试显示,当前VLA模型在创造性问题解决上表现不佳,揭示了推理是机器人技术中最薄弱的环节。

Chunru Lin, Hongxin Zhang, Fenghao Yu, Zhehuan Chen +4

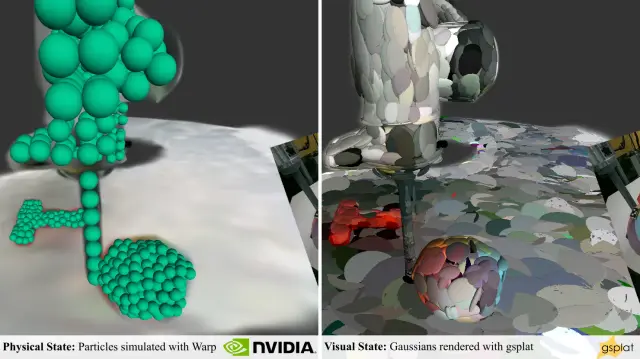
不确定性驱动的3D高斯泼溅实现实时主动建图
Robotics5月31日

不确定性驱动的3D高斯泼溅实现实时主动建图

GAVIS框架以200FPS的速度实现3D高斯泼溅的实时不确定性量化,通过各向异性可见性场引导机器人主动建图。

Shangjie Xue, Jesse Dill, Dhruv Ahuja +3

面向机器人操作的三模态动力学引导表示学习
AI5月30日

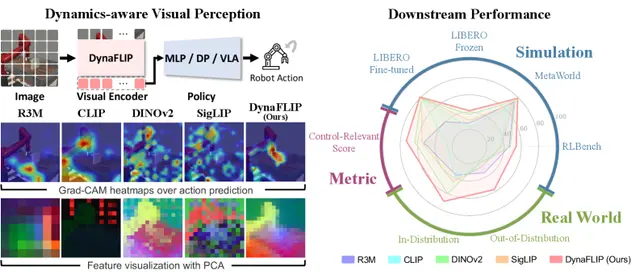
面向机器人操作的三模态动力学引导表示学习

我们提出DynaFLIP,一个动力学感知的3D流-语言-图像预训练框架,将运动理解前移至感知阶段。通过联合对…

Jusuk Lee, Seungjae Lee, Jonghun Shin +6

SE3Kit:为机器人学家打造的轻量级3D数学库
Robotics5月29日

SE3Kit:为机器人学家打造的轻量级3D数学库
Daniyal Maroufi, Omid Rezayof, Farshid Alambeigi

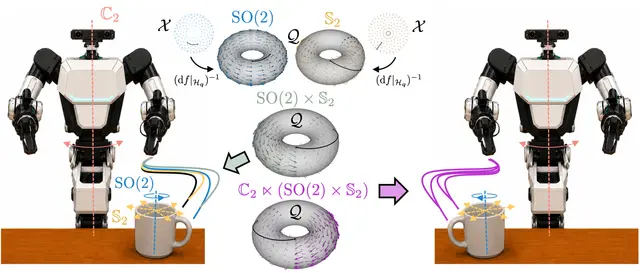
跨空间对称性:新组合让机器人学习更快
Robotics5月28日

跨空间对称性:新组合让机器人学习更快

Loizos Hadjiloizou, Rodrigo Pérez-Dattari, Noémie Jaquier

Scout-Assisted Planning Cuts Robot Team Travel Costs by Over 30%
AI5月27日

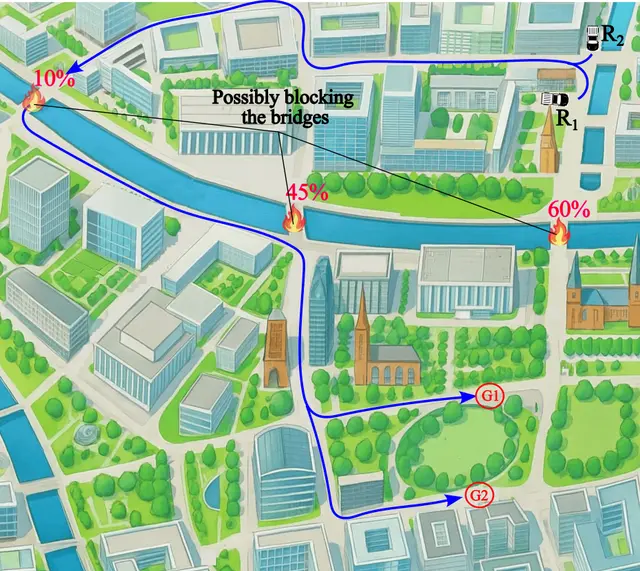
Scout-Assisted Planning Cuts Robot Team Travel Costs by Over 30%

A planning framework that uses drones to scout ahead for ground robots, cutting travel costs by over 30% in partially known environments.

Hoang-Dung Bui, Abhish Khanal, Raihan Islam Arnob +1

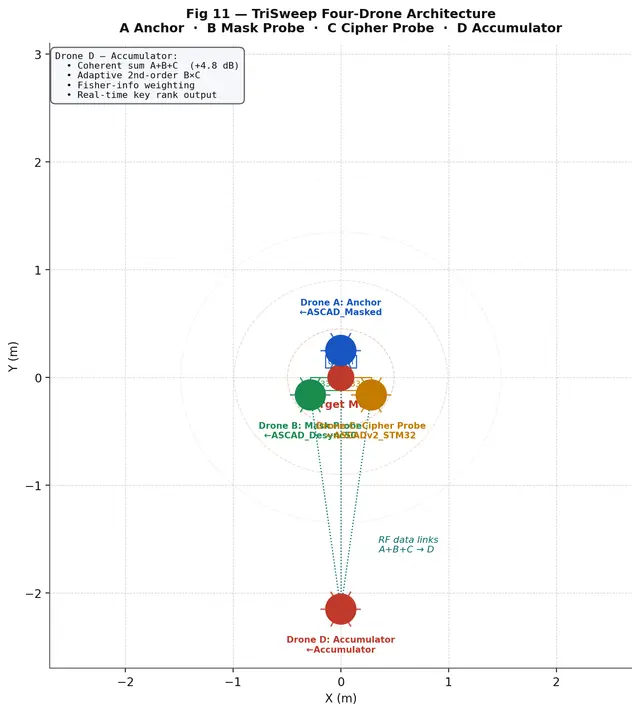
Four-Drone Swarm Framework for Electromagnetic Side-Channel Analysis
drones5月26日

Four-Drone Swarm Framework for Electromagnetic Side-Channel Analysis

This paper presents TriSweep, a simulation framework for four-drone swarm electromagnetic side-channel analysis of masked embedded cryptographic devices at s…

Eric Yocam, Varghese Vaidyan

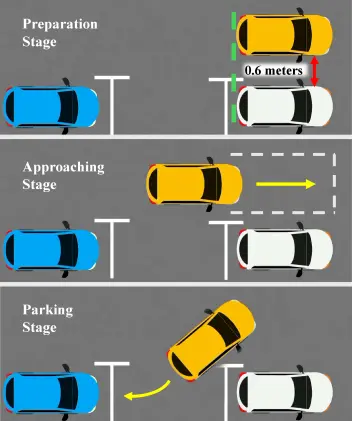
Accelerated Automated Parking: N3P Cuts Planning Time by 86%
Robotics5月25日

Accelerated Automated Parking: N3P Cuts Planning Time by 86%

Yifan Xue, Toktam Mohammadnejad, Faizan M Tariq +5

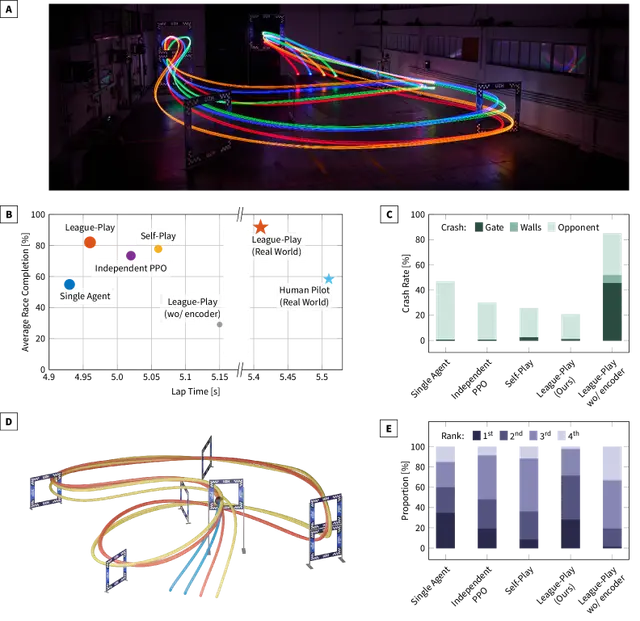
Multi-Agent RL Drone Racing Achieves Superhuman Safety and Agility
AI5月24日

Multi-Agent RL Drone Racing Achieves Superhuman Safety and Agility

Ismail Geles, Leonard Bauersfeld, Markus Wulfmeier +1

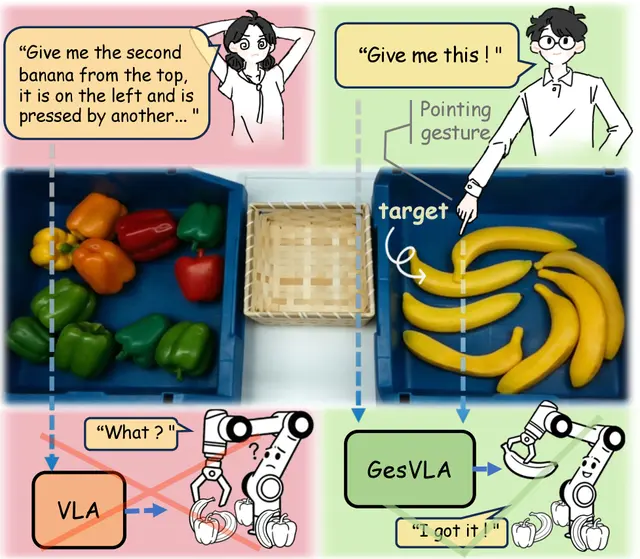
Gesture-Aware VLA Boosts Robot Intent Understanding to 94.3% Accuracy
Robotics5月23日

Gesture-Aware VLA Boosts Robot Intent Understanding to 94.3% Accuracy

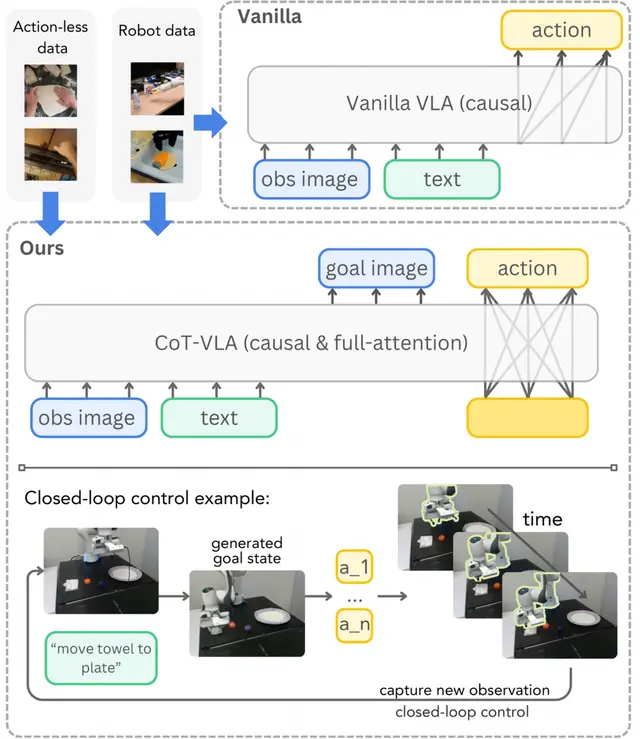
GesVLA encodes pointing gestures as latent tokens, achieving 94.3% intent reasoning accuracy and significantly improving robot manipulation in cluttered scenes.

Wenxuan Guo, Ziyuan Li, Meng Zhang +7

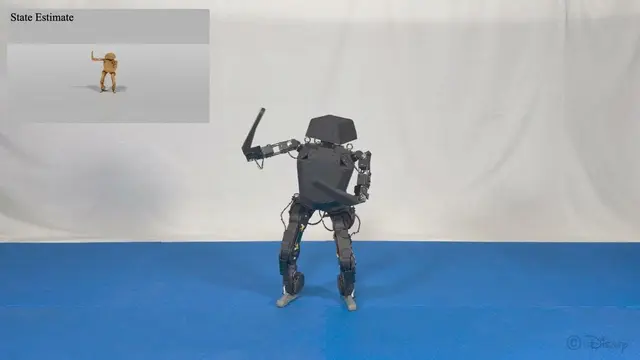
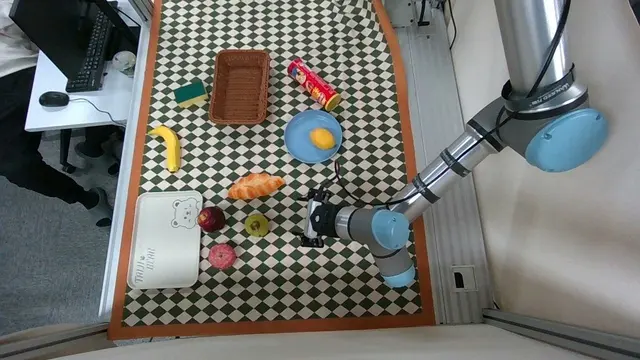
CoCo-InEKF: Better Robot State Estimation for Dynamic Motion
AI5月22日

CoCo-InEKF: Better Robot State Estimation for Dynamic Motion

Michael Baumgartner, David Müller, Agon Serifi +4

Pelican-Unified 1.0: One AI Model That Sees, Thinks, Imagines, and Acts
AI5月22日

Pelican-Unified 1.0: One AI Model That Sees, Thinks, Imagines, and Acts

Yi Zhang, Yinda Chen, Che Liu +24

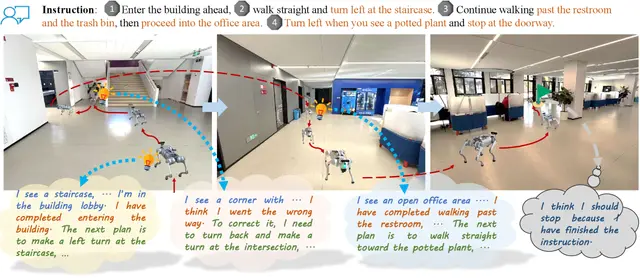
Self-Aware Robots Navigate Better Using Vision-Language Reasoning
Robotics5月22日

Self-Aware Robots Navigate Better Using Vision-Language Reasoning

Wenxuan Guo, Xiuwei Xu, Yichen Liu +7

HandITL Lets Humans Seamlessly Correct Dexterous Robot Hands Mid-Task
AI5月16日

HandITL Lets Humans Seamlessly Correct Dexterous Robot Hands Mid-Task

HandITL enables human correction of dexterous VLA policies during deployment, reducing command discontinuity and improving long-horizon task success.

Zhuohang Li, Liqun Huang, Wei Xu +5

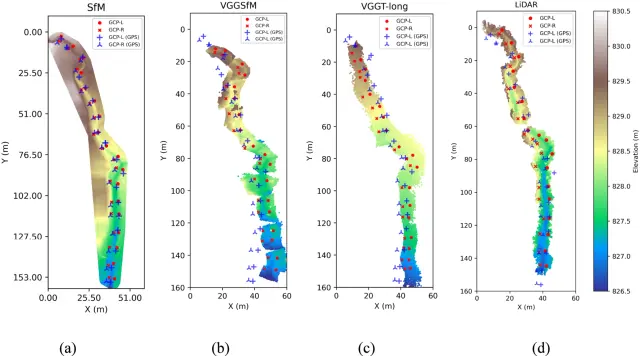
通过残差场预测的前馈式3D场景编辑
AI5月16日

通过残差场预测的前馈式3D场景编辑

我们提出VGGT-Edit,一个用于指令驱动的原生3D场景编辑的前馈框架。它将编辑视为3D残差场预测任务,避免了2D提升管线中常见的多视角不一致问题,同时保持了结构完整性。

Kaixin Zhu, Yiwen Tang, Yifan Yang +9

AI通过代码生成大规模生成可活动3D模型
Robotics5月16日

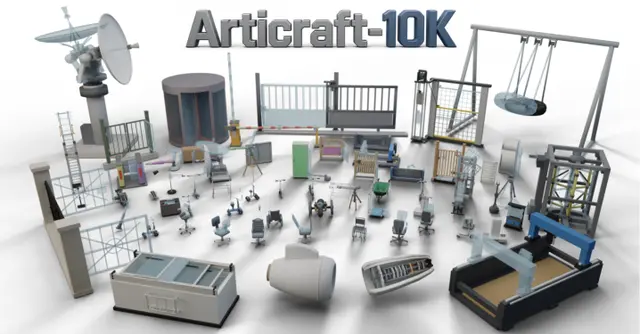
AI通过代码生成大规模生成可活动3D模型

Matt Zhou, Ruining Li, Xiaoyang Lyu +6

PriorVLA:在视觉-语言-动作模型中保留预训练先验知识
AI5月13日

PriorVLA:在视觉-语言-动作模型中保留预训练先验知识

Xinyu Guo, Bin Xie, Wei Chai +4

AI5月13日

神经倾斜使莱维驱动SDE推断可扩展且实用

我们引入了一个变分推断框架,用于莱维驱动随机微分方程(SDE),其中近似后验表示为倾斜莱维过程,先验跳跃测度通过学习到的指数因子重新加权。

Yaman Kindap, Manfred Opper, Benjamin Dupuis +2

AI5月12日

自适应门控平衡机器人泛化与精细操作

HarmoWAM使用共享世界模型和自适应门控,在可泛化运动与精细操作之间切换,实现零样本域外泛化。

Qiuxuan Feng, Jiale Yu, Jiaming Liu +8