Papers di ricerca
Sintesi in linguaggio semplice delle più recenti ricerche sulla robotica — robot umanoidi, quadrupedi, automazione industriale e IA.
Robotics23 set
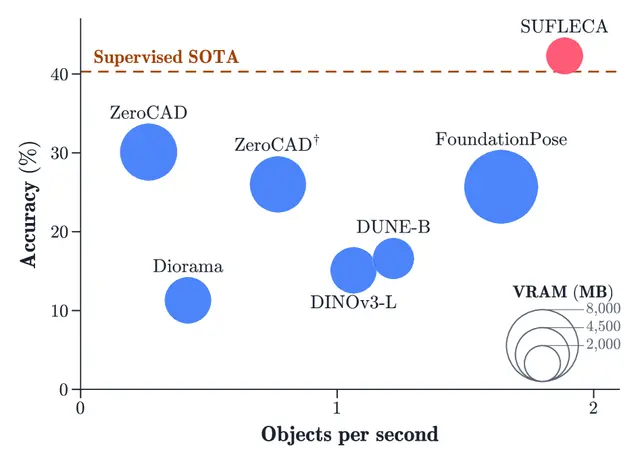
Scaling Up Feature Learning for CAD-to-Image Alignment

Robotics23 set
Single-Sensor Flow History Guides Underwater Robot Navigation
Robotics23 set
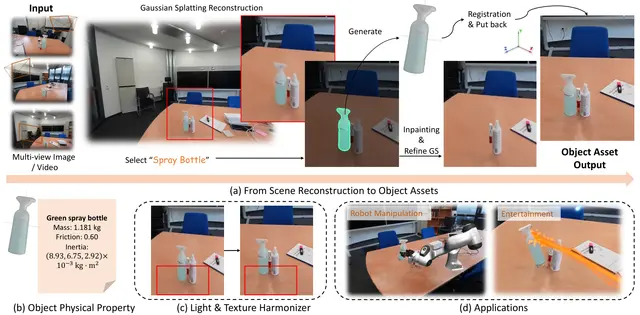
Gaussian Scene Reconstruction for Interactive Robotic Environments
AI22 set
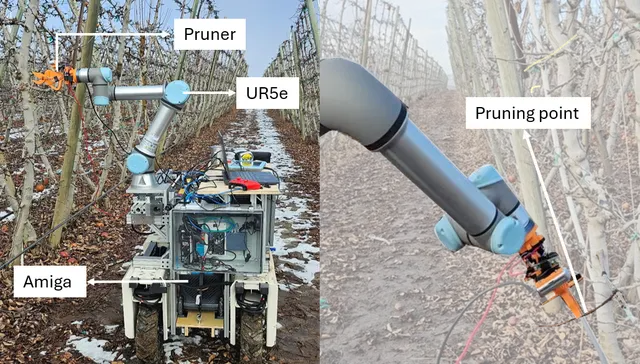
Hybrid Reinforcement Learning for Visuomotor Robotic Pruning in Planar Orchards
Robotics22 set
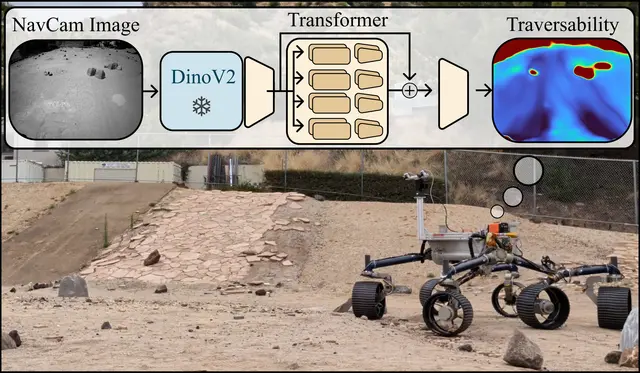
Learning to Drive on Mars with Multimodal Visual Traversability Models
Robotics22 set
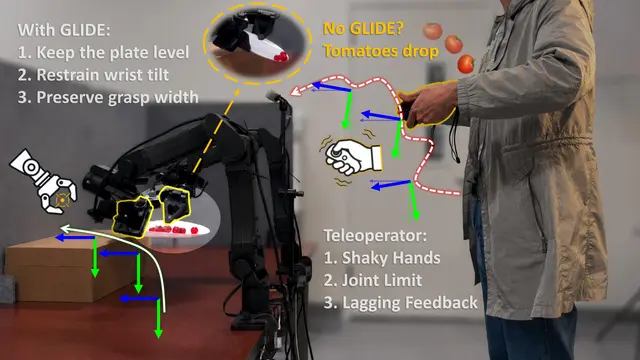
GLIDE Guardrails Help Robots Learn Safer Wine Serving Skills
Robotics21 set
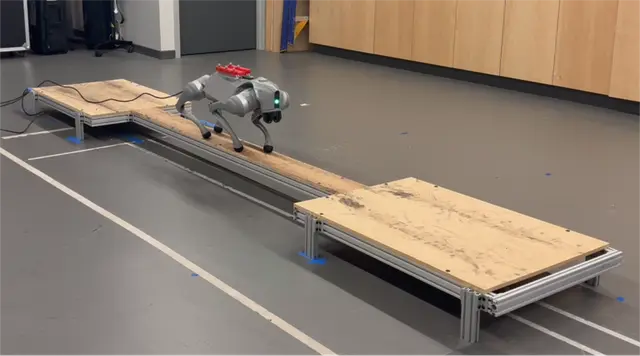
How Duty Factor Predicts Robust Quadrupedal Locomotion Across Gaits
Robotics21 set
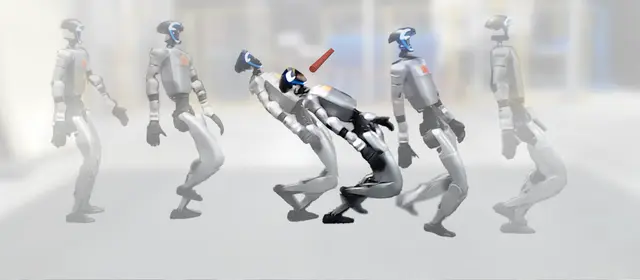
LIMBO Helps Humanoid Robots Learn Agile, Safe Whole-Body Control
Robotics21 set
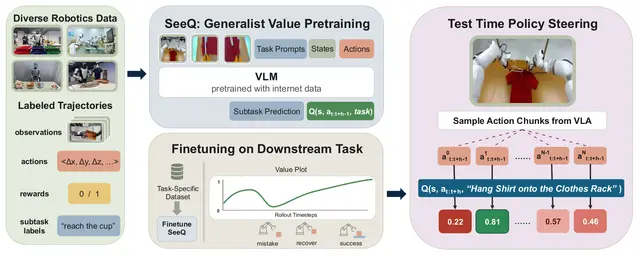
Training Generalist Value Functions for Long-Horizon Robot Manipulation
Robotics20 set
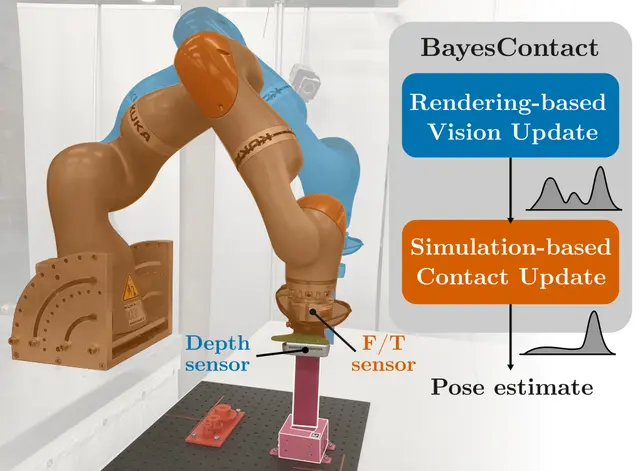
BayesContact: Estimating Hidden Object Poses by Fusing Vision and Touch
Robotics20 set
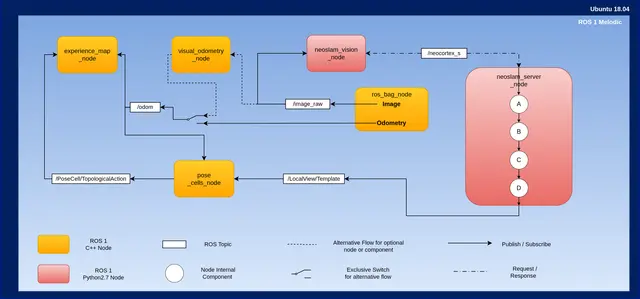
NeoSLAM: A New Implementation and Comparative Evaluation Against RatSLAM
Humanoid20 set
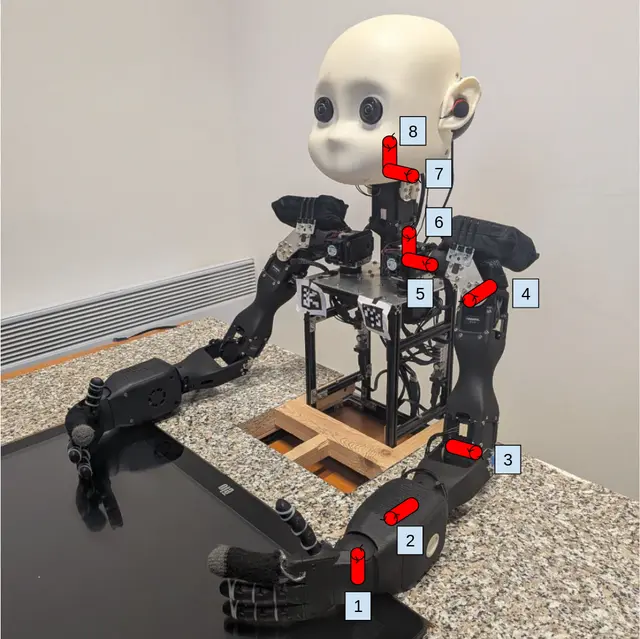
NICO Robot Mimics Human Arm Gestures Using Only a Single RGB Camera
Robotics19 set
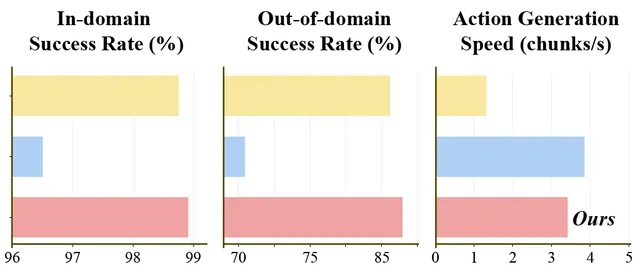
MoWAM Predicts Robot Motion for Efficient World Models and Action Planning
Robotics19 set
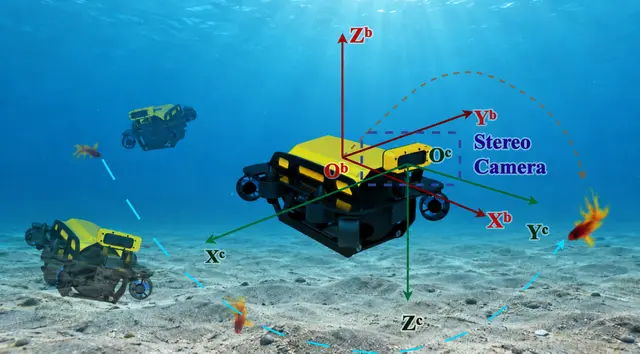
Underwater AUVs Track Targets with Better Depth and Motion Prediction
Robotics19 set
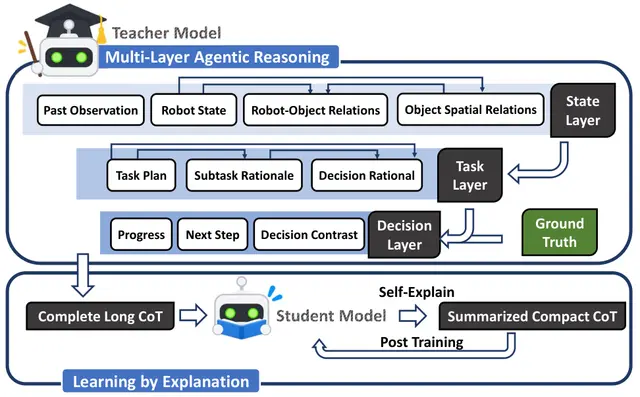
A Lightweight Robot Monitor Learns When Tasks Change Stage
AI18 set
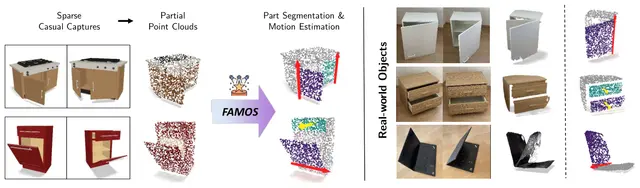
Feed-Forward 3D Articulation Modeling from Sparse Robot Observations
AI18 set
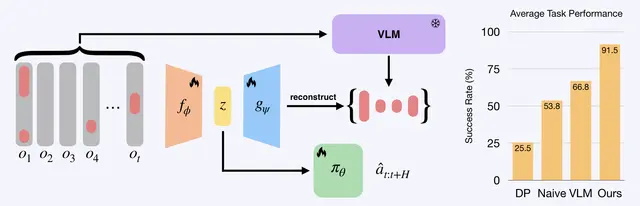
Lightweight Robotic Memory Models for Long-Horizon Manipulation
AI18 set
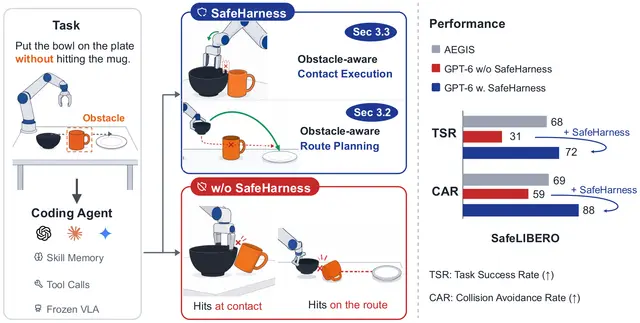
Safe Robot Manipulation Gets a Coding Agent to Check Every Move
Robotics17 set