Papers di ricerca

Sintesi in linguaggio semplice delle più recenti ricerche sulla robotica — robot umanoidi, quadrupedi, automazione industriale e IA.
499 articoli
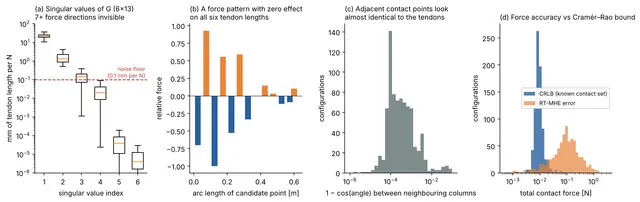
Locating Contact on Tendon-Driven Continuum Robots Using Tendon Measurements Alone
Roboticsoggi

Locating Contact on Tendon-Driven Continuum Robots Using Tendon Measurements Alone

We presented an analysis and an estimator for locating contact on tendon-driven continuum robots using only tendon lengths and tensions.

Haitham El-Hussieny

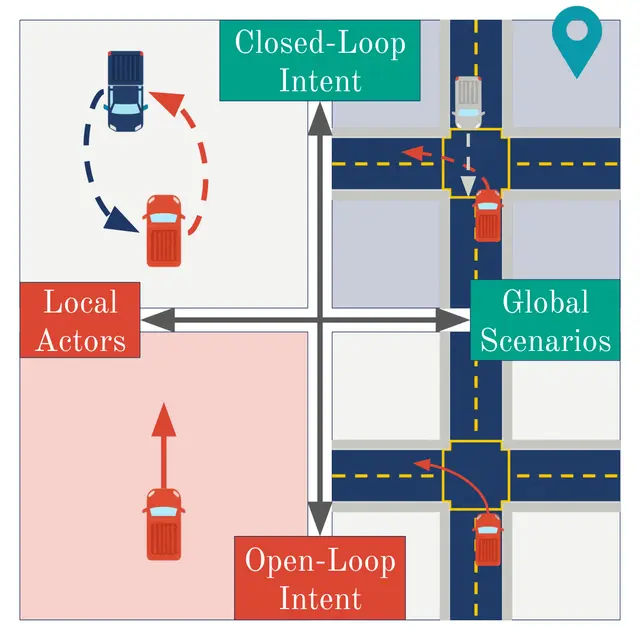
Keeping Autonomous Driving Test Scenarios on Track with Closed-Loop Policy Orchestration
Roboticsoggi

Keeping Autonomous Driving Test Scenarios on Track with Closed-Loop Policy Orchestration
Closed-loop policy evaluation is subject to closed-loop drift.

Frieda Rong, Zhaoyue Wang, Veer Kapadia +6

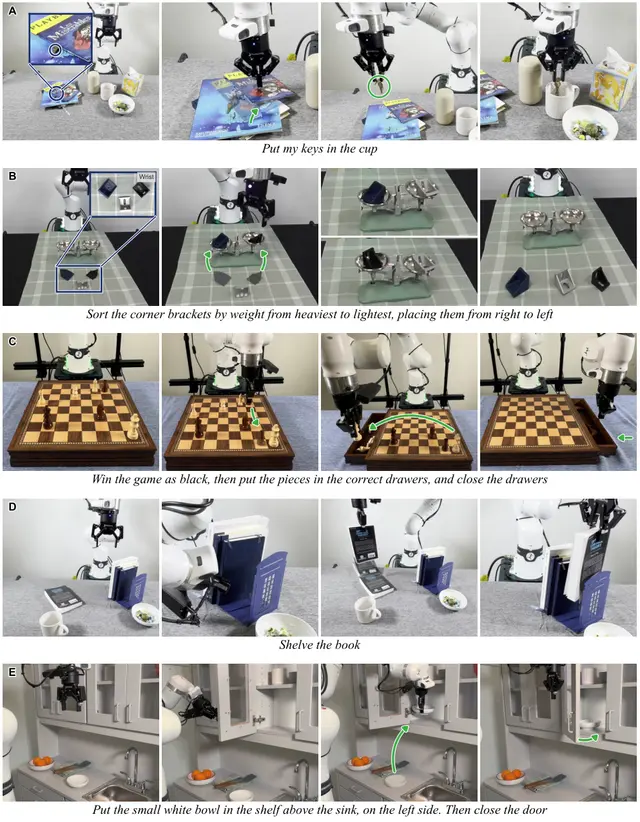
A Robot That Writes Code to See, Search, and Manipulate Objects
AIoggi

A Robot That Writes Code to See, Search, and Manipulate Objects

AMP1 uses a general-purpose AI model to write robot-control code, interpret feedback, and adapt manipulation plans as tasks unfold.

Chen Chen, Omid Bagherieh, Naveen Nikamanth Appiah Balaji +10

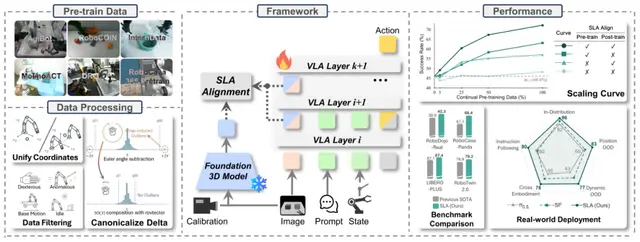
How Continual Training Scales Robot Skills Across Tasks and Robot Bodies
Roboticsieri

How Continual Training Scales Robot Skills Across Tasks and Robot Bodies

Fuhao Li, Wenxuan Song, Qizhou Huang +7

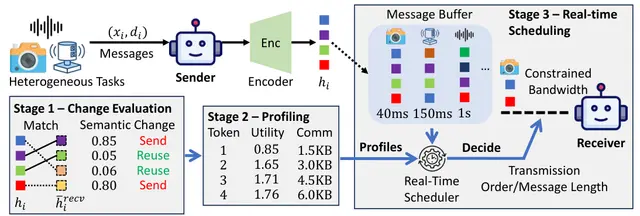
Real-Time Latent Communication for Cyber-Physical Agents
Roboticsieri

Real-Time Latent Communication for Cyber-Physical Agents

Shanghao Shi, Jian Xiao, Ching-Hsiang Chan +5

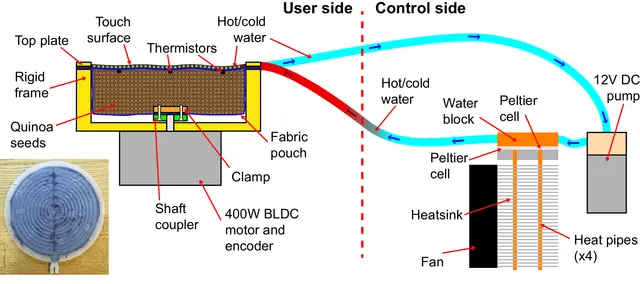
A Haptic Interface Combines Softness and Temperature Control in Real Time
Roboticsieri

A Haptic Interface Combines Softness and Temperature Control in Real Time

There is strong motivation for tactile display technology capable of producing softness and thermal sensations simultaneously.

Joshua Brown, Fernando Bello, Lynette Jones

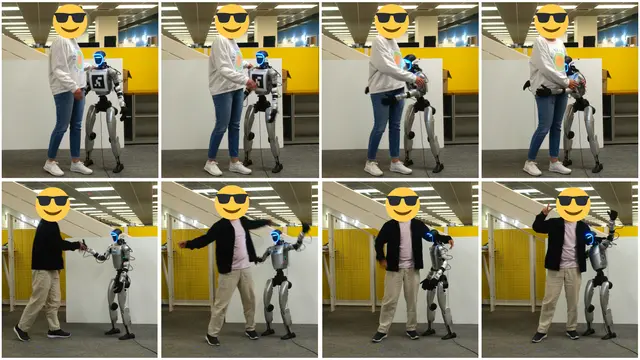
How Humanoids Learn Natural, Contact-Aware Human Interaction Through Motion
Humanoidl’altro ieri

How Humanoids Learn Natural, Contact-Aware Human Interaction Through Motion

Social Humanoid uses interaction-preserving retargeting and generative motion to help a Unitree G1 respond to people.

Vongani H. Maluleke, James Ni, Kie Horiuchi +7

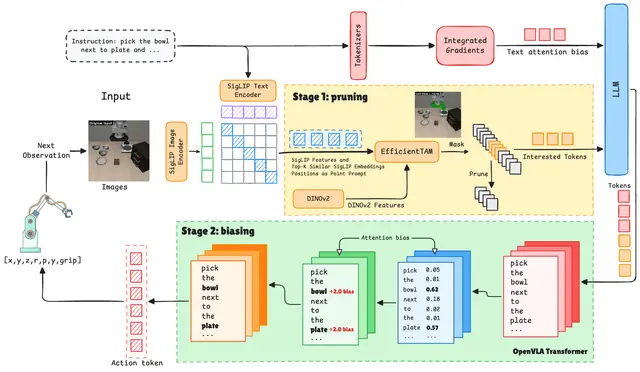
T3R Cuts Visual Tokens for Faster, More Robust Vision-Language-Action Models
Roboticsl’altro ieri

T3R Cuts Visual Tokens for Faster, More Robust Vision-Language-Action Models
Mohammed Hassan, Zhenyang Chen, Zheng Wang +5

Calibrated Latent Probing Predicts and Classifies VLA Failures Before They Happen
AIl’altro ieri

Calibrated Latent Probing Predicts and Classifies VLA Failures Before They Happen

Michal P. Podolinsky, Yunhao Yang, Daniel Little +6

VFlash Lets Robots Decode Visual Plans Into Useful Actions More Quickly
Robotics3 gg fa

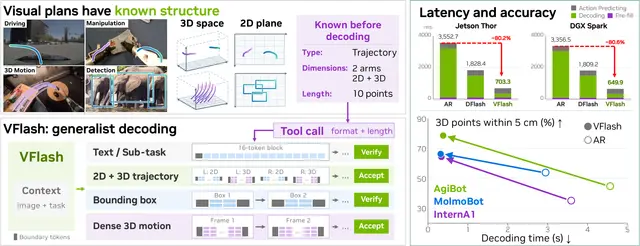
VFlash Lets Robots Decode Visual Plans Into Useful Actions More Quickly

VFlash predicts visual plans such as trajectories and object locations in parallel, with dense-motion generation up to 26.4 times faster in reported tests.

Yu-Cheng Chou, Shihao Wang, Jin Huang +16

Dexterous Robot Hands Reuse RL Skills to Learn from Fewer Demos
Robotics3 gg fa

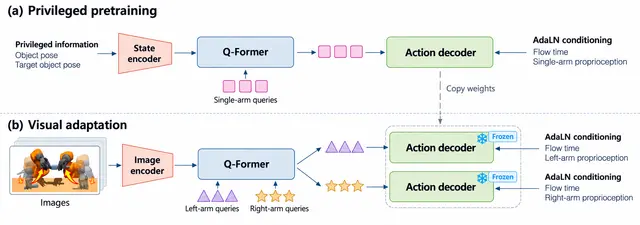
Dexterous Robot Hands Reuse RL Skills to Learn from Fewer Demos

A frozen RL controller helps dexterous robot hands learn visual manipulation tasks from fewer demonstrations in simulation.

Yixiao Wang, Peiyi Chen, Mustafa Mukadam +3

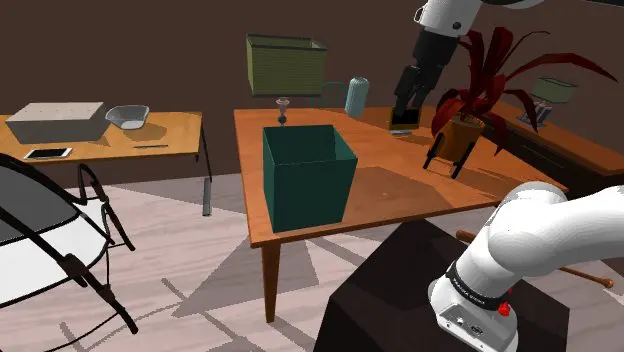
How Robots Learn Transferable VLA Corrections from Semantic Human Interventions
Robotics3 gg fa

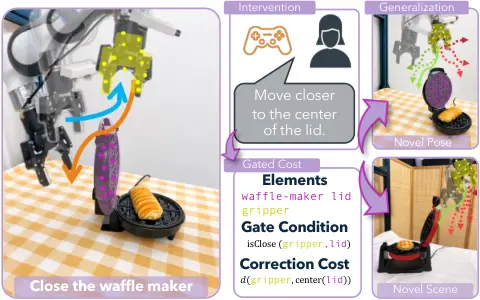
How Robots Learn Transferable VLA Corrections from Semantic Human Interventions

Arpit Bahety, Skand Peri, Sriniket Ambatipudi +4

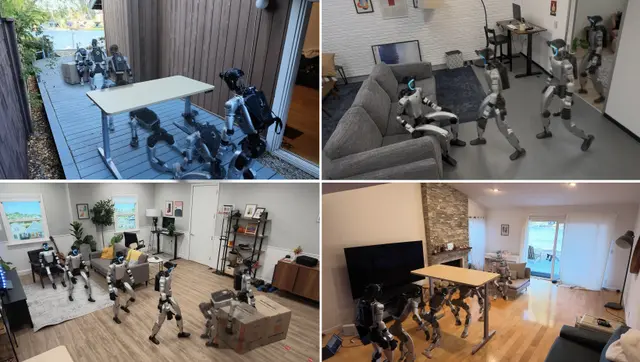
How Reinforcement Learning Improves Generalist Robot Policies at Scale
AI4 gg fa

How Reinforcement Learning Improves Generalist Robot Policies at Scale

Michal Korniak, Marco Bagatella, Ralf Römer +21

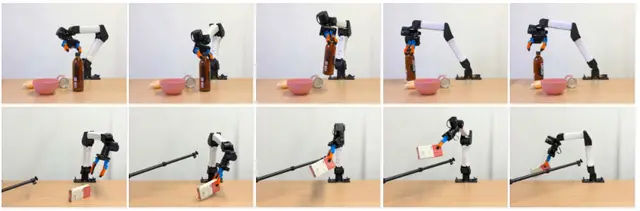
Simulation Trains Humanoids to See, Plan, and Move in Real Worlds
Humanoid4 gg fa

Simulation Trains Humanoids to See, Plan, and Move in Real Worlds

A simulation-trained humanoid stack links camera-based task planning to motion control and transfers to real settings without maps.

Siyuan Hu, Abulikemu Abuduweili, Yue Meng +5

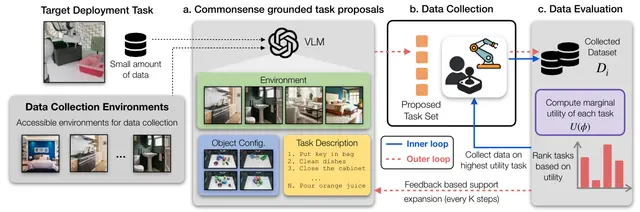
Fast GPU Planning for Torque-Limited, Collision-Free Robot Motion
Robotics4 gg fa

Fast GPU Planning for Torque-Limited, Collision-Free Robot Motion

Fast manipulation requires motions that are both quick to plan and quick to execute.

Balakumar Sundaralingam, Adithyavairavan Murali, Stan Birchfield

GUILD Guides Robot Imitation Learning Data Collection Across Auxiliary Tasks
AI5 gg fa

GUILD Guides Robot Imitation Learning Data Collection Across Auxiliary Tasks

Shivin Dass, Kevin Nguyen, Rohan Yelandur +2

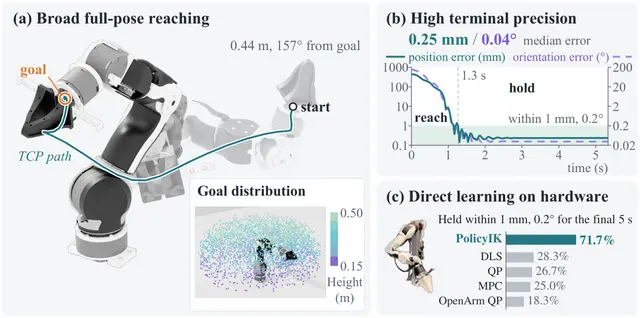
PolicyIK Uses Reinforcement Learning for Precise Robot Arm Inverse Kinematics
AI5 gg fa

PolicyIK Uses Reinforcement Learning for Precise Robot Arm Inverse Kinematics

Yuhan Liu, Xinqi Liu, Zixuan Dong +2

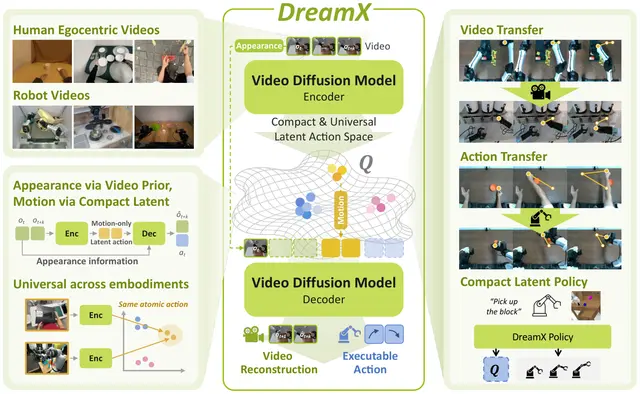
DreamX Learns Transferable Robot Actions from Video Diffusion Models
AI5 gg fa

DreamX Learns Transferable Robot Actions from Video Diffusion Models

Trained on heterogeneous human and robot videos, DreamX achieves state-of-the-art performance among latent action models on LARYBench.

Jisoo Kim, Chaehyun Kim, Junsu Kim +6

Backpropagation-Free Black-Box Domain Adaptation for Robust 3D Point Cloud Recognition
Robotics6 gg fa

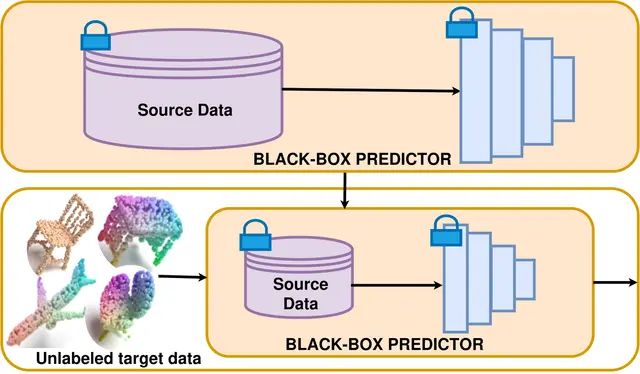
Backpropagation-Free Black-Box Domain Adaptation for Robust 3D Point Cloud Recognition
3D-BBDA is a backpropagation-free black-box domain adaptation framework for 3D point cloud classification that requires neither source data nor source model internals.

Shivangi Rai, Kunal Jangid, Vaibhav Kumar +1

D&A: Zero-Shot Robotic Rewards Through Separate Description and Assessment
AI6 gg fa

D&A: Zero-Shot Robotic Rewards Through Separate Description and Assessment

Marius Memmel, Shawn Yin, Urvi Rutia +9