Papers di ricerca
Sintesi in linguaggio semplice delle più recenti ricerche sulla robotica — robot umanoidi, quadrupedi, automazione industriale e IA.
Robotics3 set
Three Surgical Cameras Reveal When Robots See Much Better in 3D
Robotics3 set
Evaluating World Models for Robot Control Under Real-Time Feedback
Robotics3 set
Robust LiDAR Semantic Segmentation for Safe Autonomous Driving Deployment
AI2 set
Imitation Learning Loses Dexterous Robot Robustness at Higher Speeds

Humanoid2 set
Humanoid Robots Open Doors, Recover, and Sort Objects Autonomously
Robotics2 set
Pepper Robots Learn Where to Look Before Moving Through Dense Foliage
Robotics1 set
Autonomous Robot Manipulation Skills Through Language-Driven Quality-Diversity
Robotics1 set
Two Arms Build 3D Maps from Calibrated RGB-D Data for Robots
AI1 set
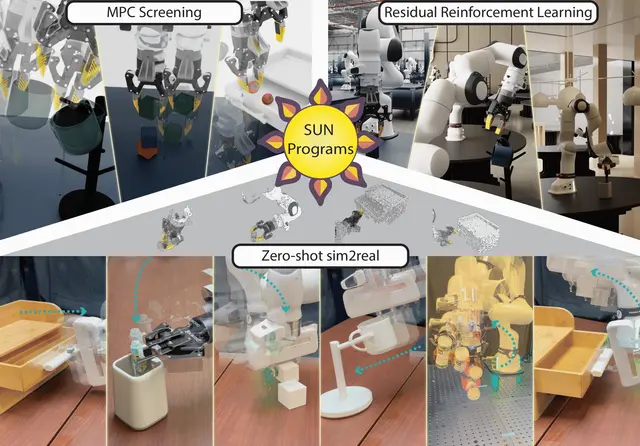
Persistent Programs for Language-Grounded Robot Control, Learning, and Transfer
AI31 ago
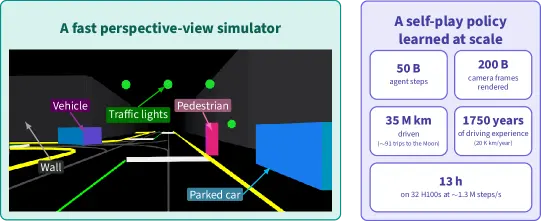
Pictura Trains Self-Driving Policies with Perspective Self-Play at Scale
AI31 ago
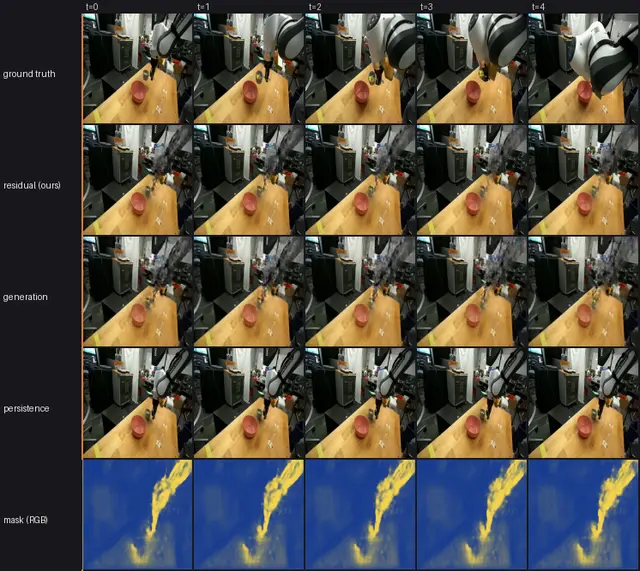
Particle World Modeling for Text-Assisted Robot Video Prediction
Robotics31 ago
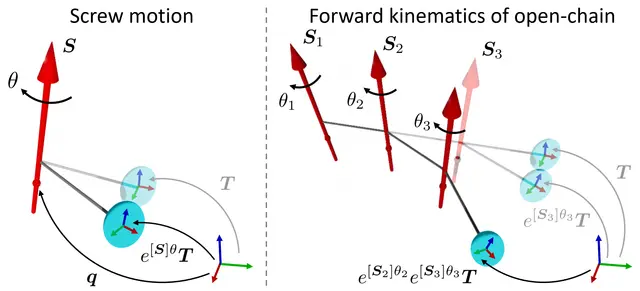
ChainSplat Helps Robots Learn Flexible Object Motion From RGB Video

Robotics30 ago
Transitional AV Lane-Change Dataset Reveals How Gaps Converge and Collision Risk Peaks
AI30 ago
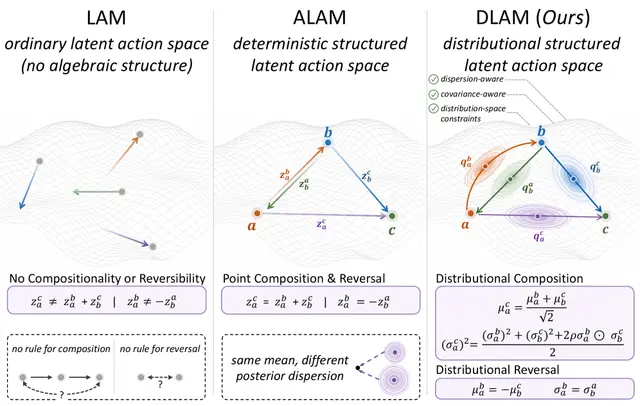
New Model Teaches Robots to Predict Visual Changes with Uncertain Latent Actions
Robotics30 ago
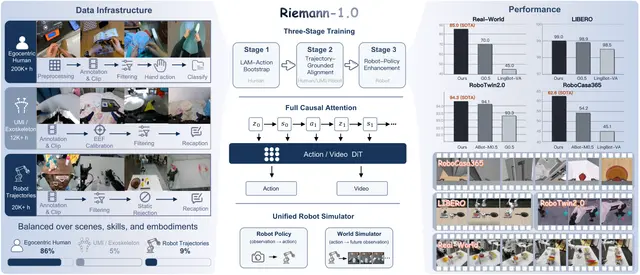
Riemann-1.0 Builds Embodied World Action Models for Physical AI
AI29 ago
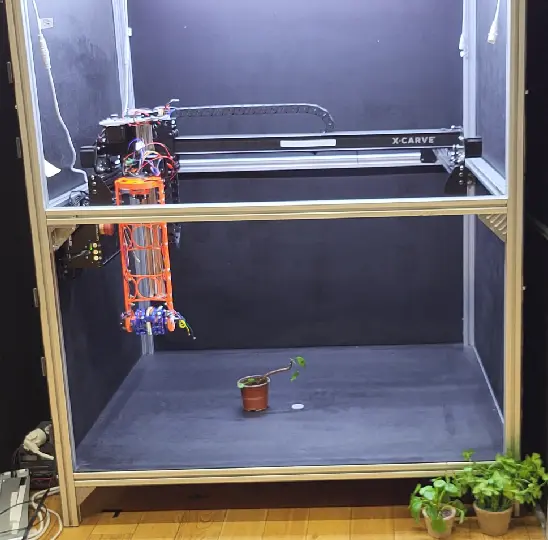
Robotic Active Sensing Maps Plant Stress Across Individual Plant Leaves
AI29 ago
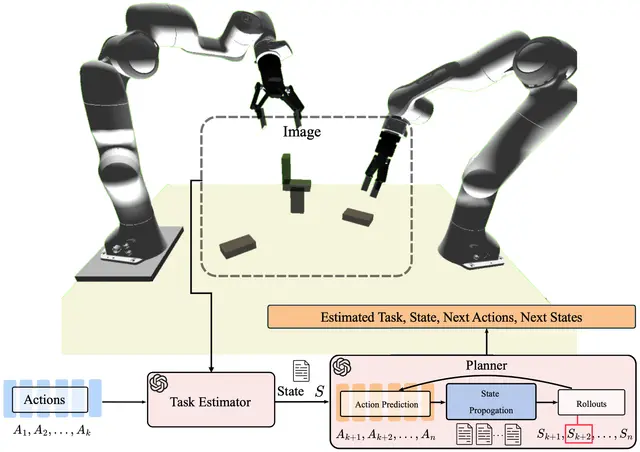
State-Aware Task Planning with Multimodal LLMs for Human-Robot Collaboration
Robotics29 ago
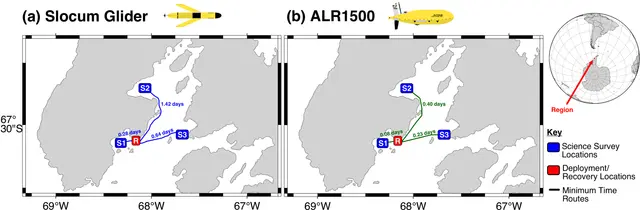
Scheduling Marine Autonomous Vehicle Fleets for Greater Scientific Impact
AI28 ago