Papers di ricerca
Sintesi in linguaggio semplice delle più recenti ricerche sulla robotica — robot umanoidi, quadrupedi, automazione industriale e IA.
Robotics10 set
Frequency-Aware Flow Matching Helps Robots Plan Smoother Actions
drones10 set
Multi-Agent Reinforcement Learning for Autonomous Wildfire UAV Exploration
Robotics9 set
Rethinking Learned Occupancy for Safer Autonomous Active Mapping with Observation-Gated Filtering
Robotics9 set
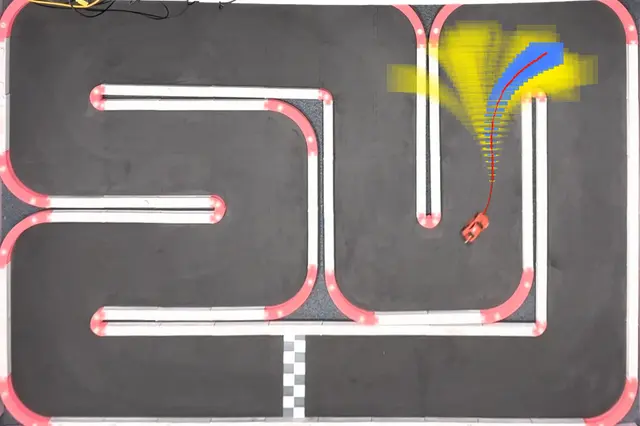
Online Reachability Makes Sampling-Based Motion Planning Safer
AI9 set
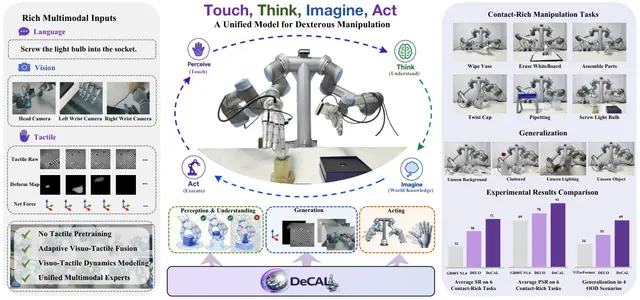
Contact-Aware Dexterous Robot Learning with Vision, Language, and Tactile Imagination
AI8 set
RoboSPA Tests VLA Models on Spatial and Long-Horizon Tasks

Robotics8 set
Why Behavior Trees Need Help to Adapt in Real-World Robots
Humanoid8 set
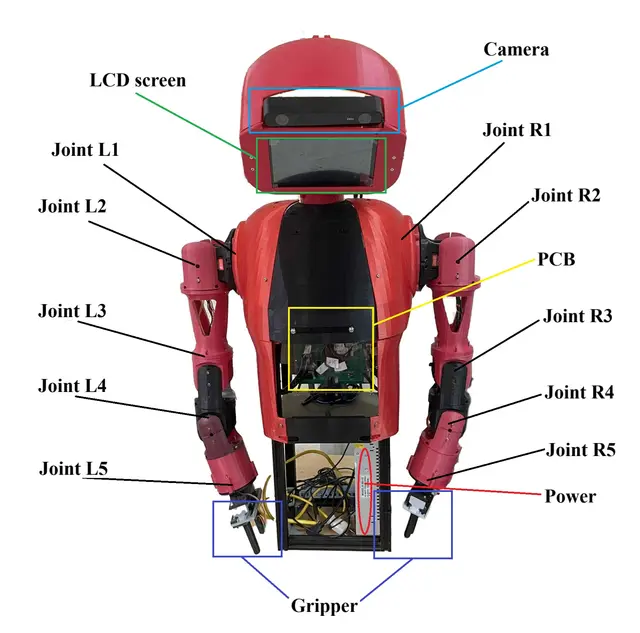
Humanoid Robot Prototype Unifies Vision, Gestures, Voice, And Expressive Control
Robotics7 set
Task Graphs Help Robots Execute Long-Horizon Manipulation Tasks
Robotics7 set
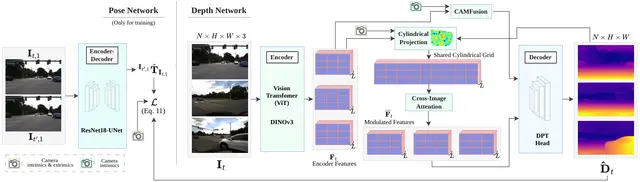
Cross-View Geometry Helps Robots Build More Reliable Surround-View Depth Maps
Robotics7 set
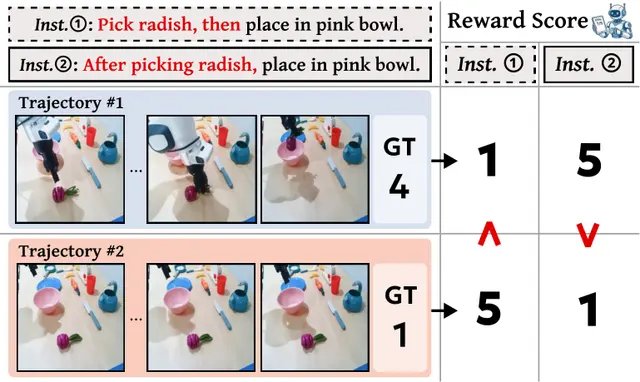
Testing Paraphrase Robustness in Vision-Language Robot Reward Models
AI6 set
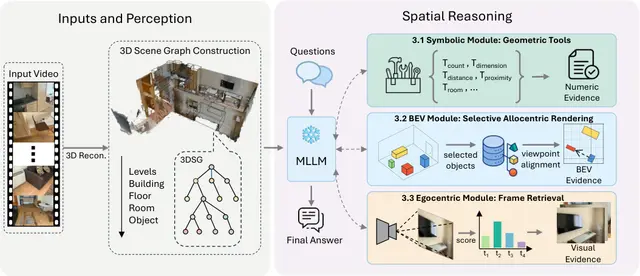
Training-Free 3D Scene Graph Reasoning for Multimodal Language Models
Robotics6 set
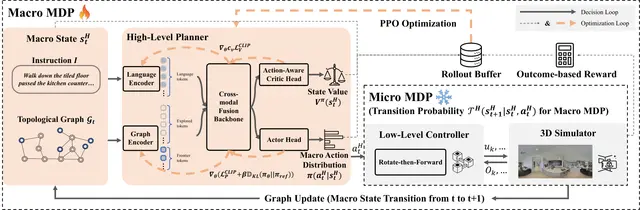
Topological Graphs Help Robots Learn Closed-Loop Vision-Language Navigation
Robotics6 set
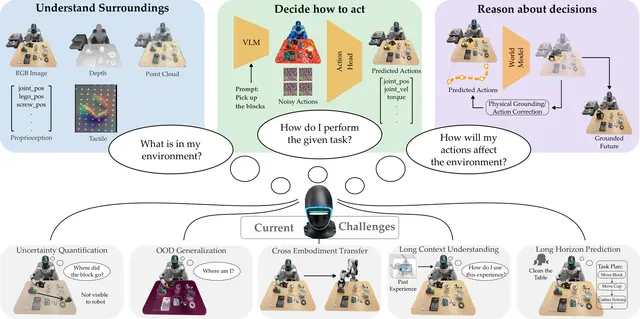
Unified Robot Learning Through Representations, Vision-Language-Action, and World Models
AI5 set
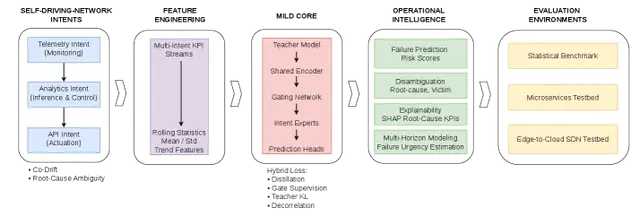
How AI Predicts and Untangles Cascading Network Failures Before They Spread
Robotics5 set
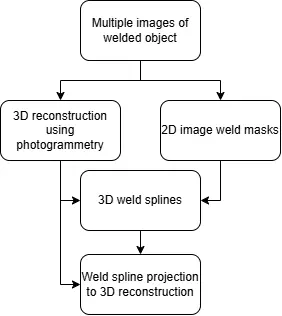
Smartphone Images Map Weld Seams in 3D for Robotic Finishing Work

AI5 set
Efficient Active Reward Learning from Preferences with Subspace Inference
AI4 set
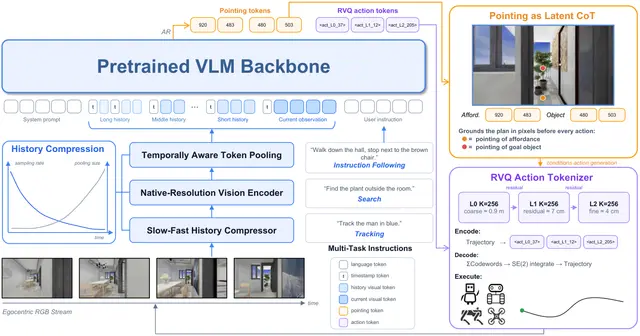
LightNav-0 Uses Spatial Intelligence for Generalist Robot Navigation
Robotics4 set