Papers di ricerca
Sintesi in linguaggio semplice delle più recenti ricerche sulla robotica — robot umanoidi, quadrupedi, automazione industriale e IA.
AI7 ott
Online Filtered Q-Gradients Speed Up Robot Flow Policy Training by 10x
AI6 ott
Transferable Adversarial Patches Disrupt World Action Models in Simulated Robot Tasks
AI6 ott
Recursive Video In-Context Learning Helps Robots Handle Long-Horizon Tasks
Humanoid6 ott
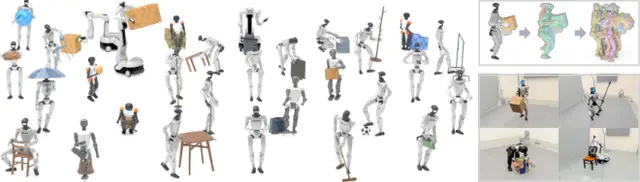
How Humanoid Robots Grow Whole-Body Skills From Their Own Motion Data
Robotics5 ott
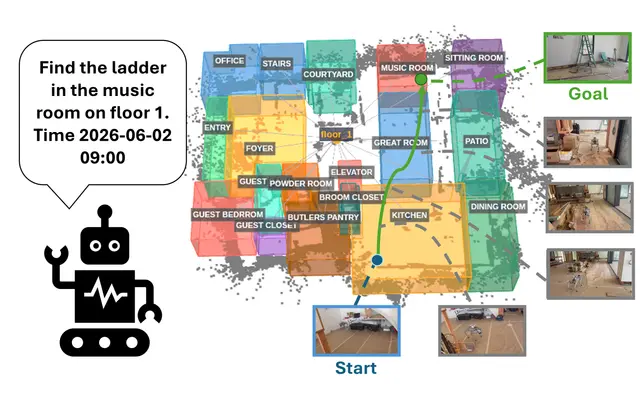
How Robots Navigate Active Sites as Work Zones and Hazards Change
AI5 ott
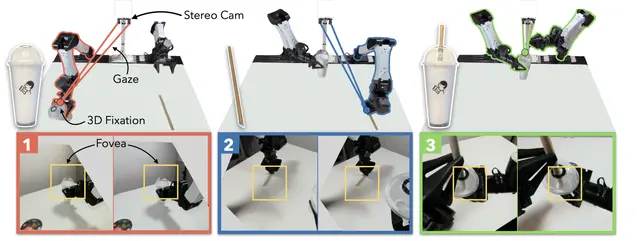
How Active Gaze Helps Robots Manipulate Precisely Without Wrist-Mounted Cameras
AI5 ott
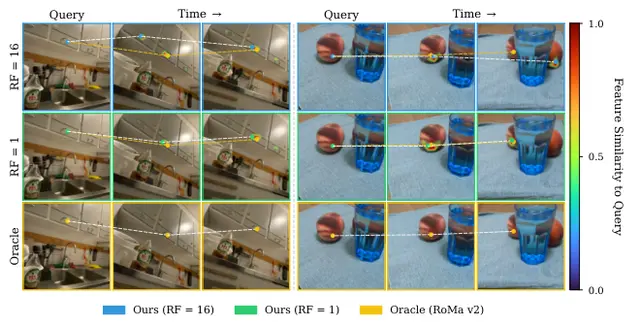
Geometric Learning from Novel Views with Lean Decoders and Strong Encoders
Humanoid4 ott
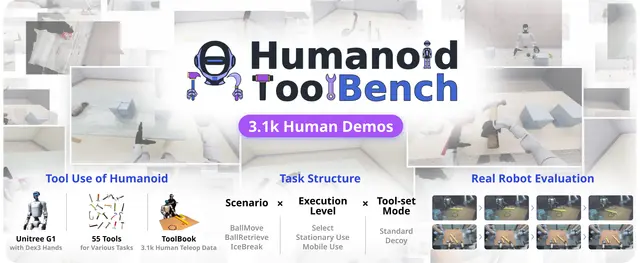
Can Humanoid Robots Choose Tools and Complete Tasks While Moving Reliably?
Robotics4 ott
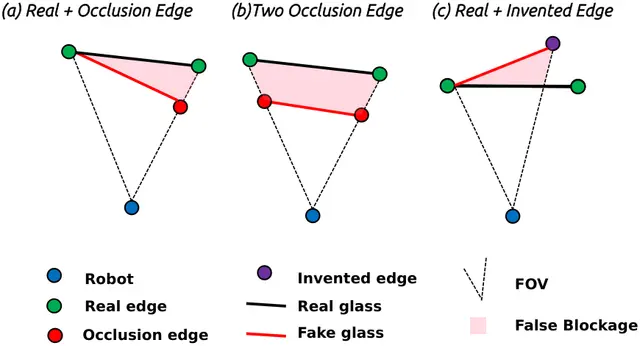
How GlassGuard Helps Mobile Robots Map Glass Without Blocking Safe Paths
AI4 ott
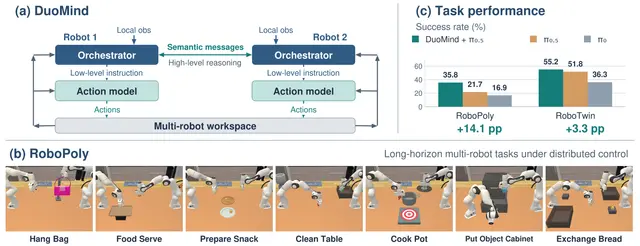
How DuoMind Helps Two Robots Coordinate With Shared Language
AI3 ott
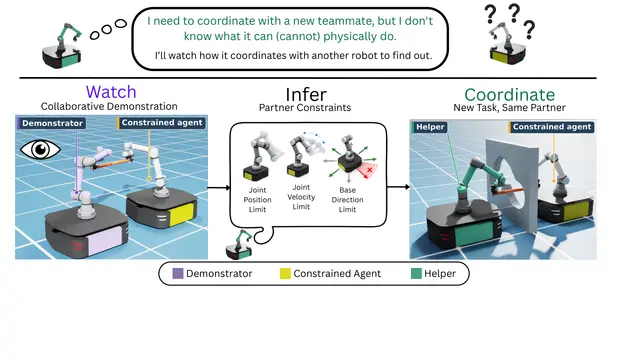
How Robots Learn Partner Limits for Safer Teamwork on New Tasks

AI3 ott
FERPO Trains Robot Policies With Better Action Coverage, Faster Updates
AI3 ott
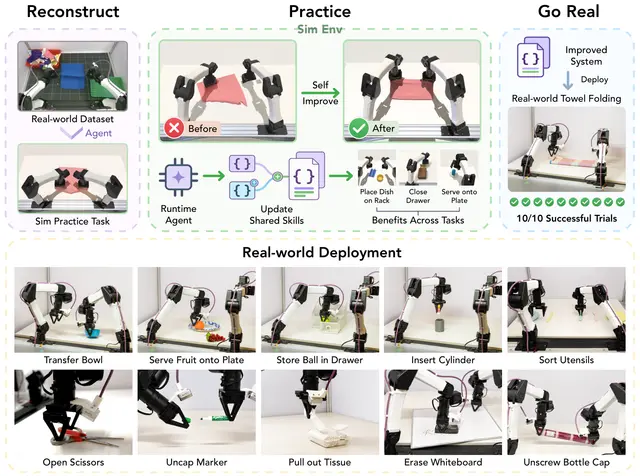
How RPG Helps Embodied Agents Improve Robot Skills Through Practice
Robotics2 ott
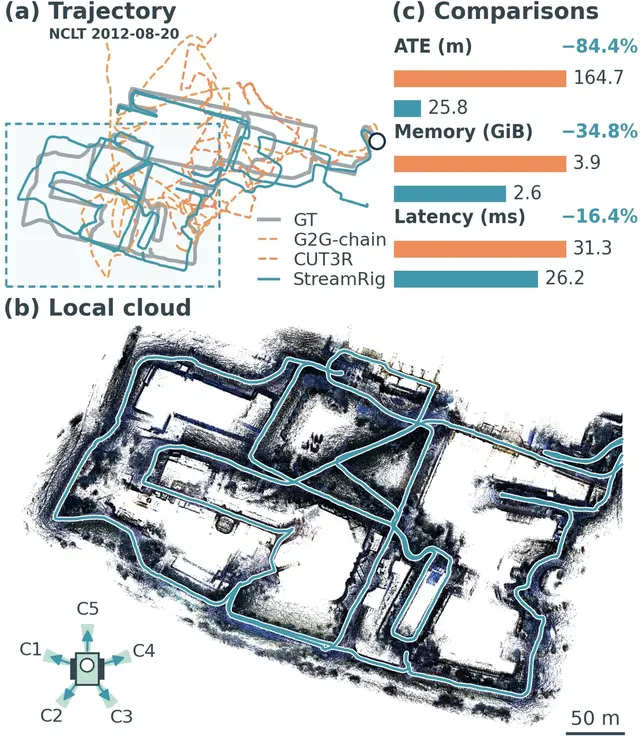
StreamRig Uses Intra-Rig Geometry for Streaming Multi-Camera Odometry
AI2 ott
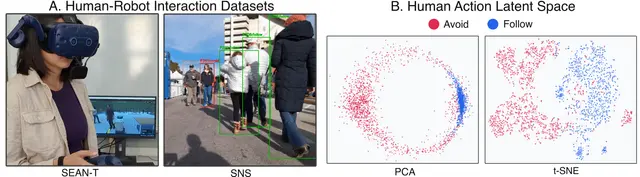
How STARS Helps Robots Read Social Intent from Human Motion Cues
AI2 ott
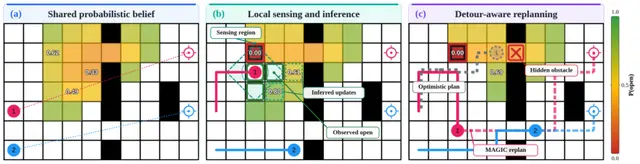
How Robot Teams Plan Safer Routes When Maps Hide Blocked Paths
Robotics1 ott
GPU Planning Helps Robots Pick Better Paths in Unknown Environments
AI1 ott
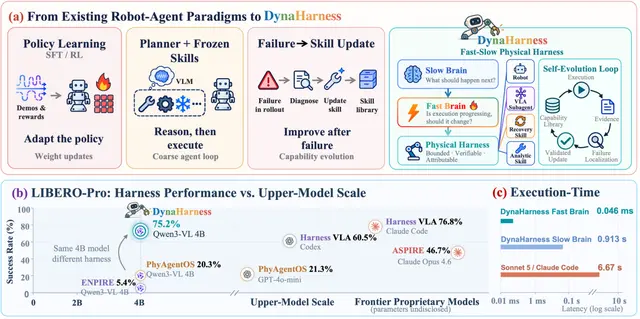
How a Physical Robot Harness Helps Agents Recover, Switch, and Learn
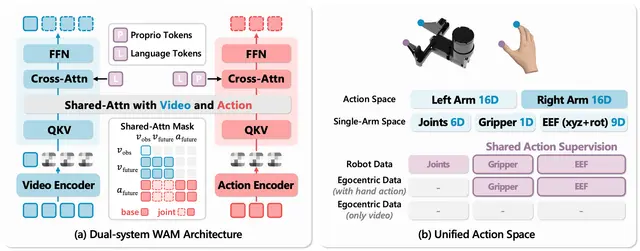
Robotics1 ott