Papers di ricerca

Sintesi in linguaggio semplice delle più recenti ricerche sulla robotica — robot umanoidi, quadrupedi, automazione industriale e IA.
499 articoli
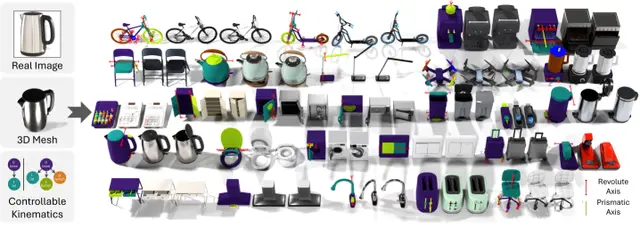
How Instruct-Particulate Enables Fast 3D Object Articulation from Vision-Language Models
Robotics15 giu

How Instruct-Particulate Enables Fast 3D Object Articulation from Vision-Language Models

We scale feed-forward 3D object articulation by using vision-language models to pseudo-label synthetic 3D assets, enabling a transformer-based architecture t…

Ruining Li, Yuxin Yao, Matt Zhou, Chuanxia Zheng +4

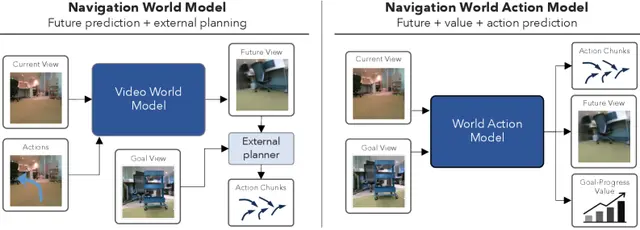
Navigation World Action Model for Goal-Conditioned Visual Navigation
Robotics14 giu

Navigation World Action Model for Goal-Conditioned Visual Navigation

NavWAM learns a joint world-action prediction model that turns visual foresight into a closed-loop policy for goal-conditioned visual navigation.

Daichi Azuma, Taiki Miyanishi, Koya Sakamoto +6

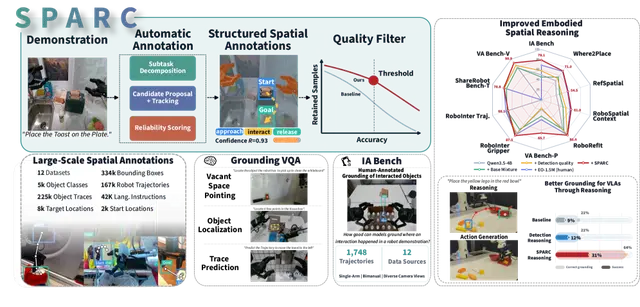
SPARC: Reliable Spatial Annotations from Robot Demonstrations at Scale
Robotics14 giu

SPARC: Reliable Spatial Annotations from Robot Demonstrations at Scale

Given a robot demonstration video, a language instruction, and gripper proprioceptive signal, SPARC produces object-centric spatial annotations for each inte…

Nils Blank, Paul Mattes, Maximilian Xiling Li +5

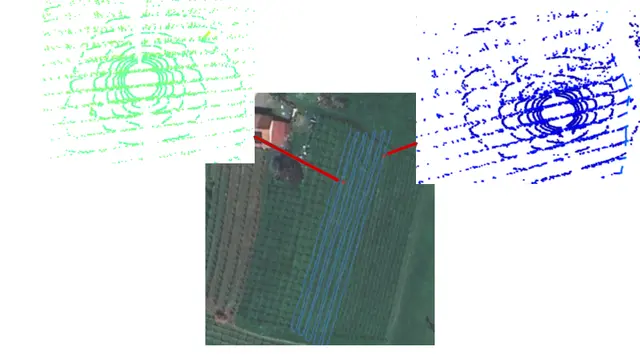
Heterogeneous LiDAR Early Fusion and Learned Re-Ranking for Robust Long-Term Place Recognition
AI14 giu

Heterogeneous LiDAR Early Fusion and Learned Re-Ranking for Robust Long-Term Place Recognition
Judith Vilella-Cantos, Juan José Cabrera, Mónica Ballesta +2

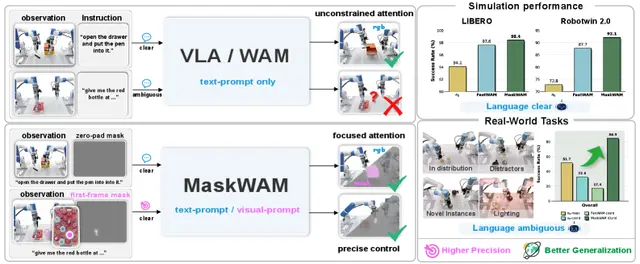
MaskWAM Teaches Robots to Predict What Matters for Better Manipulation
AI13 giu

MaskWAM Teaches Robots to Predict What Matters for Better Manipulation

Hanyang Yu, Haitao Lin, Jingbo Zhang +4

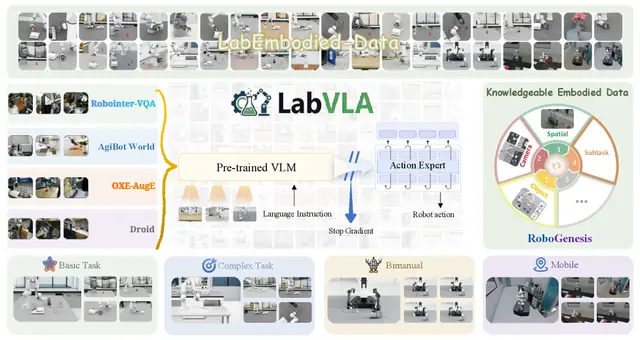
LabVLA Brings Vision-Language-Action Models to Lab Automation
AI13 giu

LabVLA Brings Vision-Language-Action Models to Lab Automation

LabVLA achieves high success rates in lab tasks using synthetic data from RoboGenesis and transfers to real robots, advancing lab automation.

Baochang Ren, Xinjie Liu, Xi Chen +15

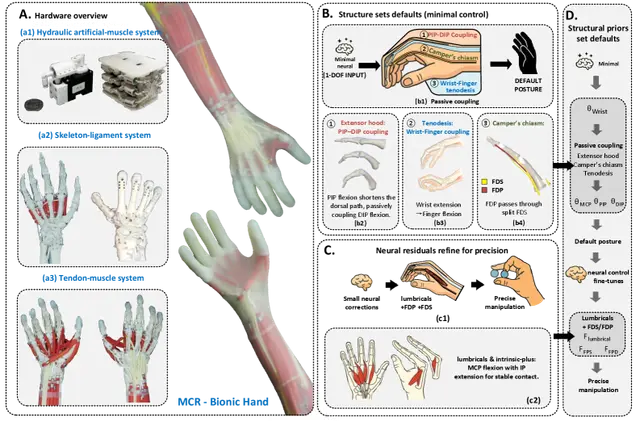
MCR-Bionic Hand: How Anatomical Structure Unlocks Dexterous Robot Manipulation
Robotics13 giu

MCR-Bionic Hand: How Anatomical Structure Unlocks Dexterous Robot Manipulation

Researchers have built MCR-Bionic, a musculoskeletal robotic hand that mimics key anatomical structures from the human hand—bones, ligaments, tendons, and in…

Haosen Yang, Guowu Wei

Weaver: A Fast and Scalable World Model for Robotic Manipulation
Robotics12 giu

Weaver: A Fast and Scalable World Model for Robotic Manipulation

Arnav Kumar Jain, Yilin Wu, Jesse Farebrother +2

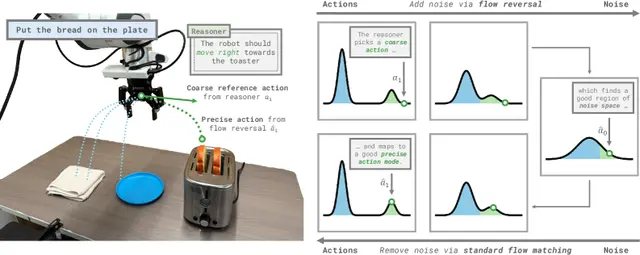
Flow Reversal Steering Makes Robot Generalists Better at Following High-Level Guidance
Robotics12 giu

Flow Reversal Steering Makes Robot Generalists Better at Following High-Level Guidance
Andy Tang, William Chen, Andrew Wagenmaker +2

Mana: A New System for Dexterous Robot Manipulation of Articulated Tools
AI12 giu

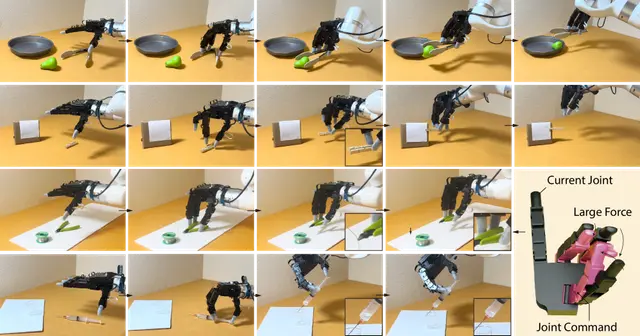
Mana: A New System for Dexterous Robot Manipulation of Articulated Tools

Mana trains robot hands to manipulate articulated tools like syringes and scissors using only simulation data, achieving 86.7% real-world success with zero sim-to-real retraining.

Zhao-Heng Yin, Guanya Shi, Pieter Abbeel +1

When and Where Should You Allocate Test-Time Compute in Embodied Planners?
AI11 giu

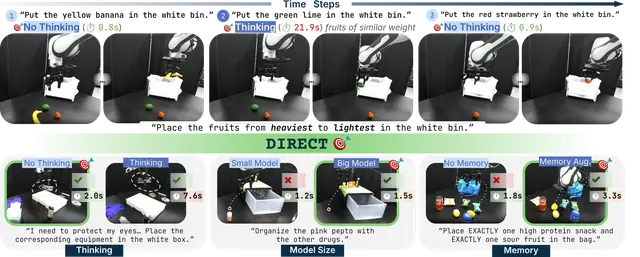
When and Where Should You Allocate Test-Time Compute in Embodied Planners?

Scaling test-time compute is not free in robotics: in a hierarchical stack the planner is invoked repeatedly, so per-call costs from chain-of-thought reasoni…

Jadelynn Dao, Milan Ganai, Yasmina Abukhadra +7

World Pilot Gives Vision-Language-Action Robots a World-Action Model Boost
Robotics11 giu

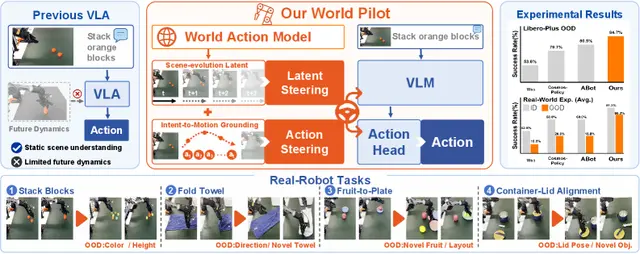
World Pilot Gives Vision-Language-Action Robots a World-Action Model Boost

Zefu Lin, Rongxu Cui, Junjia Xu +4

New Method Gives Cheap Robot Arms Force Feedback Without Extra Sensors
AI11 giu

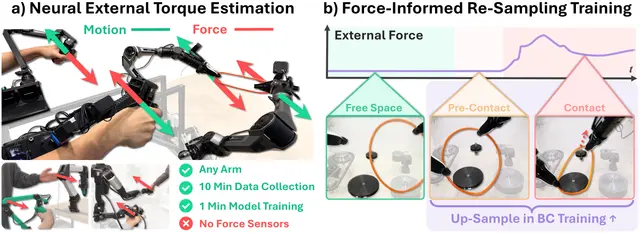
New Method Gives Cheap Robot Arms Force Feedback Without Extra Sensors

Steven Oh, Jason Jingzhou Liu, Tony Tao +5

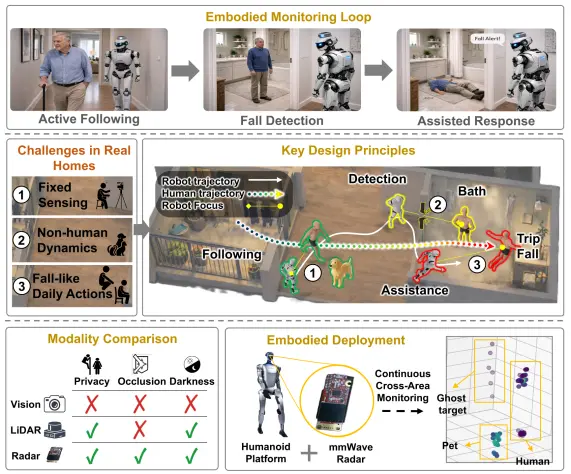
Embodied mmWave Radar on Humanoid Robots Enables 24/7 Fall Detection
Humanoid10 giu

Embodied mmWave Radar on Humanoid Robots Enables 24/7 Fall Detection

Researchers have developed EM-Fall, a system that mounts mmWave radar on a humanoid robot to detect falls day and night, even in complete darkness. The robot…

Yanshuo Lu, Yuxuan Hu, Shenghai Yuan +5

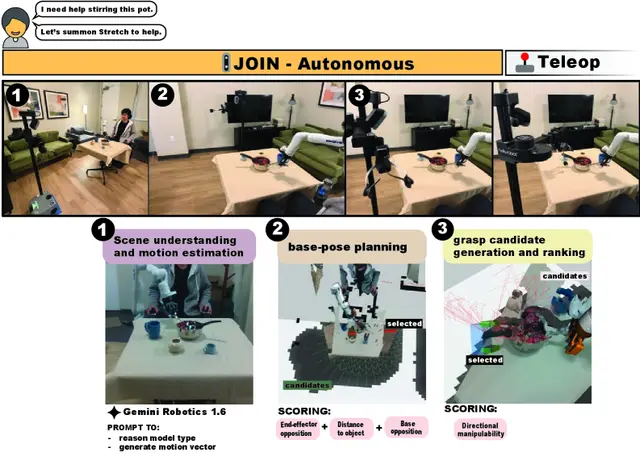
Bimanual Joining System Lets Wheelchair Robots Call for Backup
Robotics10 giu

Bimanual Joining System Lets Wheelchair Robots Call for Backup

Researchers at Northeastern University developed JOIN, a three-phase system that enables a mobile robot to autonomously join a wheelchair-mounted arm already…

Drake Moore, Matt Cheng, Xiang Zhi Tan +1

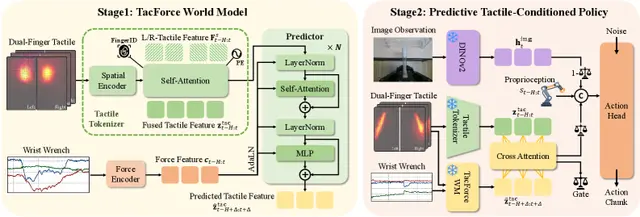
TacForeSight Predicts Tactile Feedback From Force Data for Better Robot Handling
Robotics10 giu

TacForeSight Predicts Tactile Feedback From Force Data for Better Robot Handling

Yujie Zang, Yuhang Zheng, Xian Nie +7

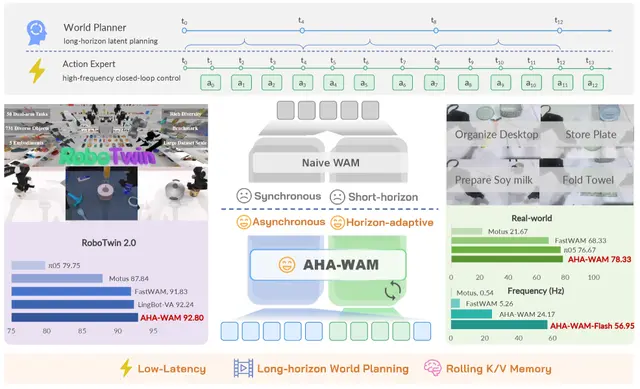
AHA-WAM: Asynchronous World-Action Model for Faster, Smarter Robot Manipulation
AI9 giu

AHA-WAM: Asynchronous World-Action Model for Faster, Smarter Robot Manipulation

Jisong Cai, Long Ling, Shiwei Chu +10

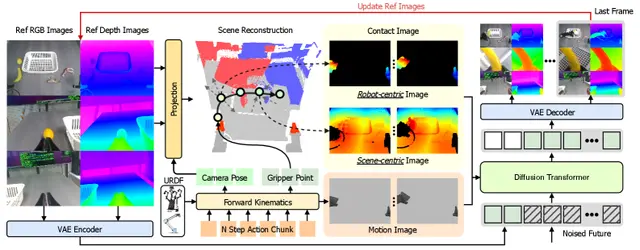
How Robots Turn Actions Into Motion and Contact Images for Better World Models
Robotics9 giu

How Robots Turn Actions Into Motion and Contact Images for Better World Models

An embodied world model that translates future actions into motion and contact images for video prediction on cloth manipulation tasks.

Zhenyu Wu, Xiuwei Xu, Yukun Zhou +8

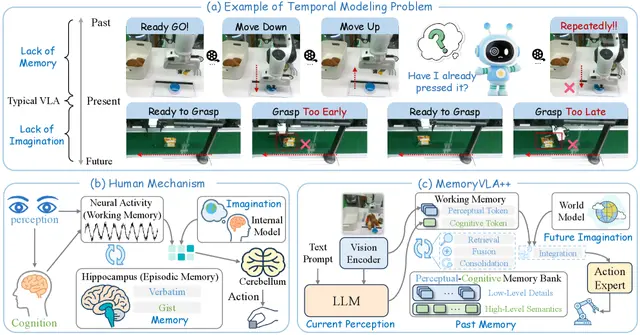
MemoryVLA++ Equips Robots with Memory and Imagination for Complex Tasks
Robotics9 giu

MemoryVLA++ Equips Robots with Memory and Imagination for Complex Tasks

MemoryVLA++ adds memory and imagination to vision-language-action models, boosting robot success on long-horizon and memory-dependent tasks.

Hao Shi, Weiye Li, Bin Xie +6

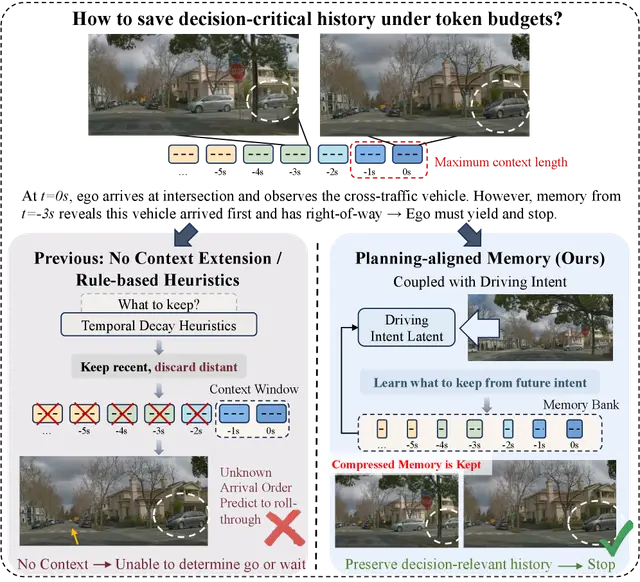
Planning-Aligned Token Compression for Extended-Memory Autonomous Driving
AI8 giu

Planning-Aligned Token Compression for Extended-Memory Autonomous Driving

Zhixuan Liang, Yuxiao Chen, Yurong You +12