Nghiên cứu Papers
Bản tóm tắt dễ hiểu về các nghiên cứu robot mới nhất — robot hình người, robot bốn chân, tự động hóa công nghiệp và AI.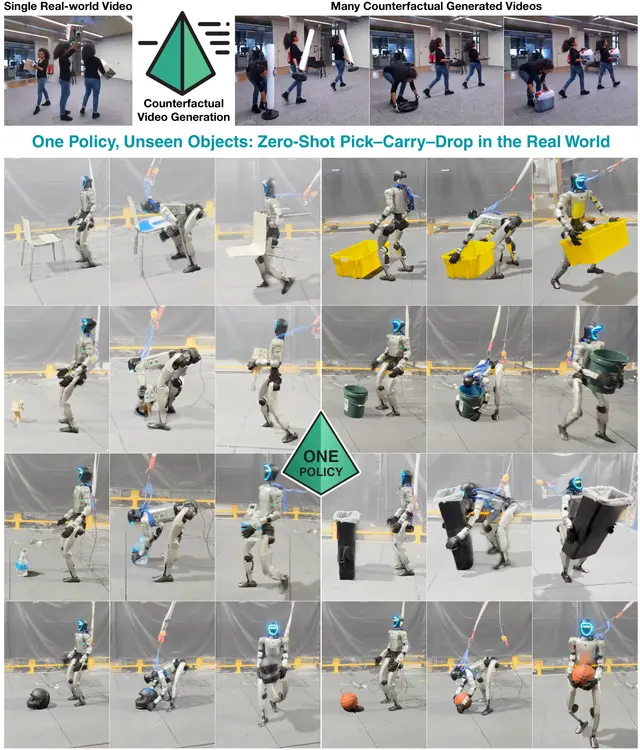
Robotics30 thg 9
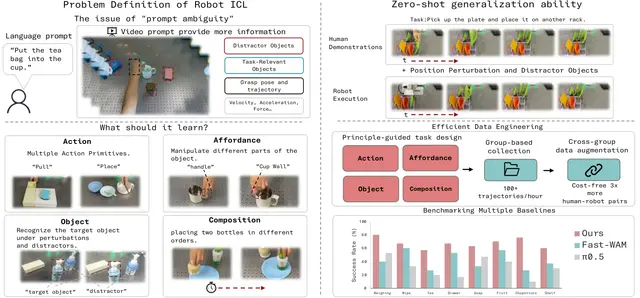
Robots Learn New Manipulation Skills From Videos, Not Teleoperation
AI30 thg 9
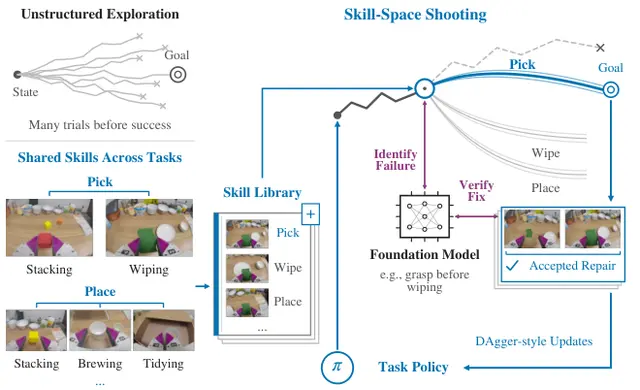
How Robots Improve Policies by Reusing Skills to Repair Their Failures
AI29 thg 9
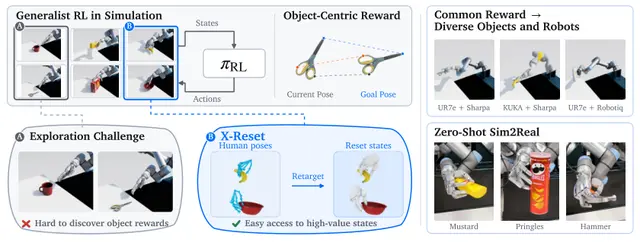
Human Demonstrations Help Robot Hands Learn Object Manipulation
Robotics29 thg 9
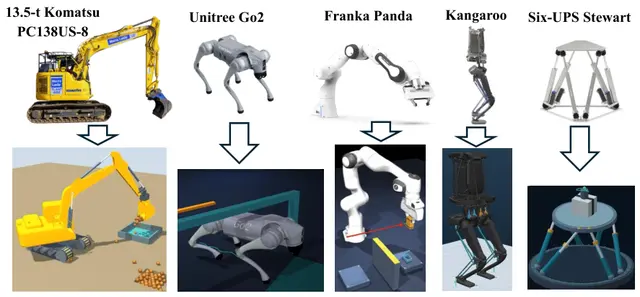
RoboCompiler: Compiling Closed-Chain Robots for Consistent Control and Simulation
AI29 thg 9
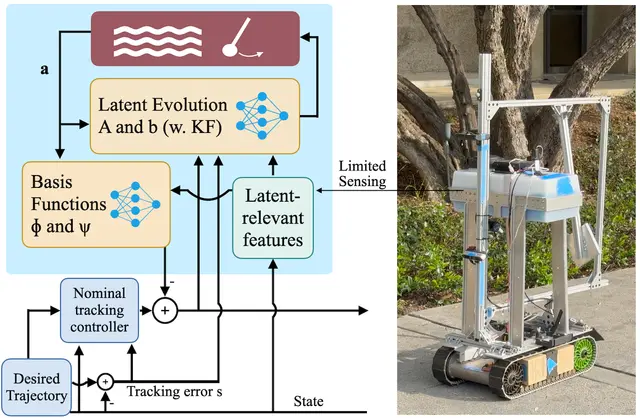
How Robots Learn to Model Hidden Disturbances for Better Robot Control
drones28 thg 9
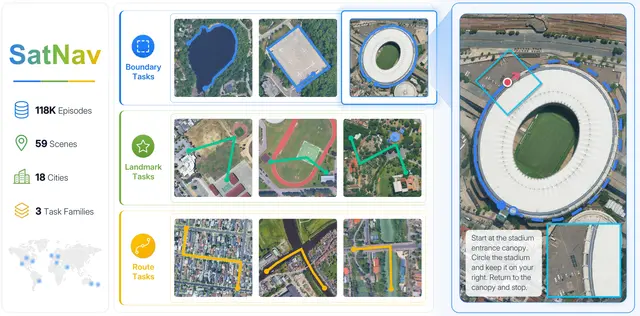
SatNav Benchmarks Long-Horizon UAV Navigation from Satellite Images
Humanoid28 thg 9
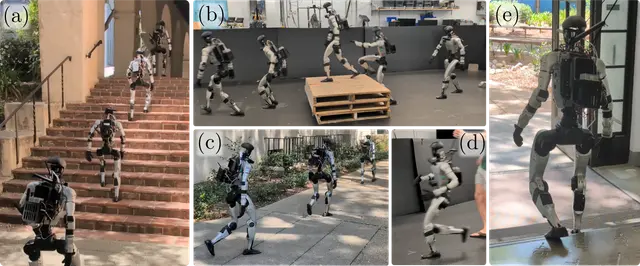
Humanoid Robots Learn to Walk, Run, Jump, and Read Rough Terrain
Robotics28 thg 9
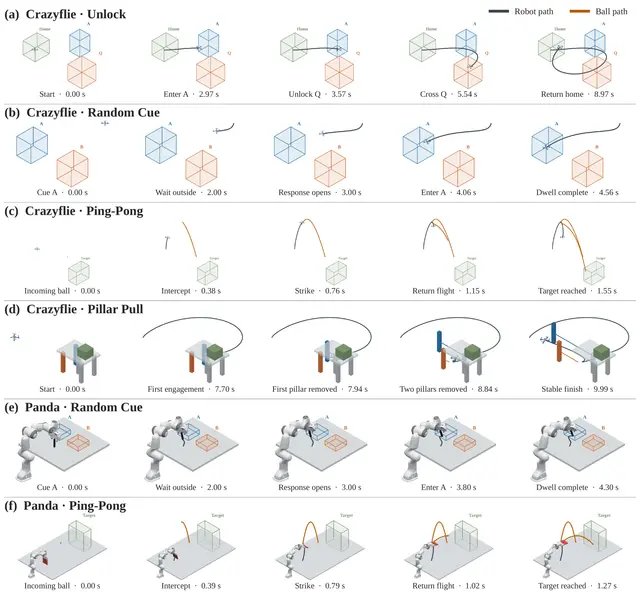
STL-Guided Robot Policy Learning from Sparse Success Signals for Control
Robotics27 thg 9
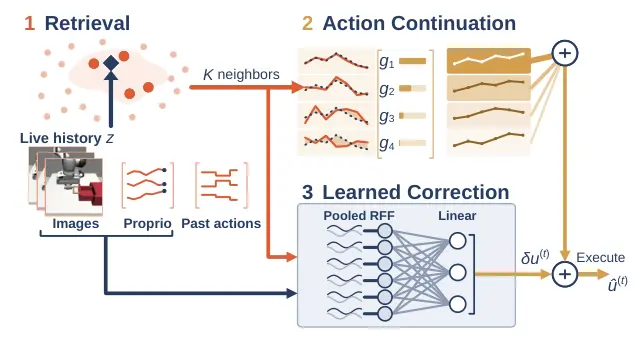
Training-Free Robot Behavior Cloning Through Retrieval and Action Continuation
Robotics27 thg 9
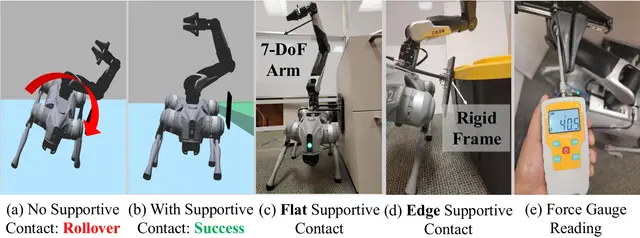
Choosing Environmental Contacts for Legged Loco-Manipulation
Robotics27 thg 9
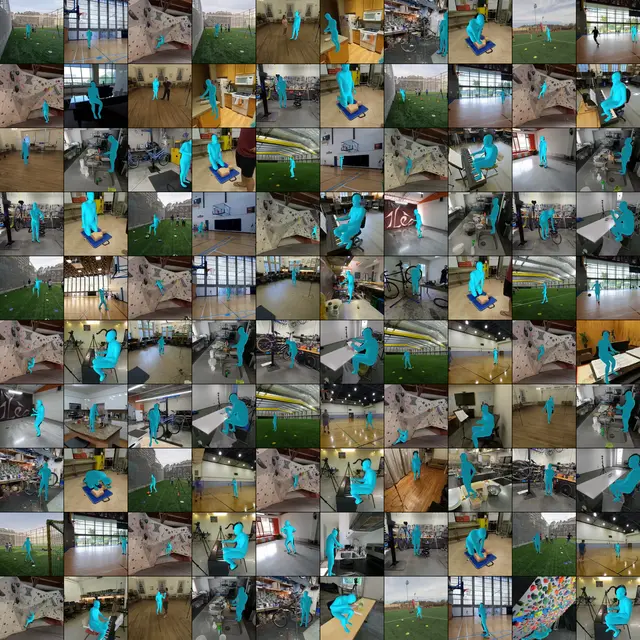
Ego-Exo4D Human Meshes Dataset for 4D Motion Reconstruction from Multi-View Video
AI26 thg 9
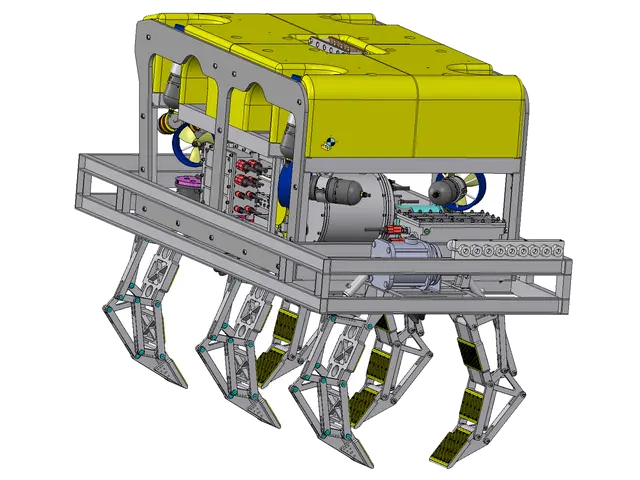
Object-Centric World Models Help Underwater ROVs Plan Safer Salvage
AI26 thg 9
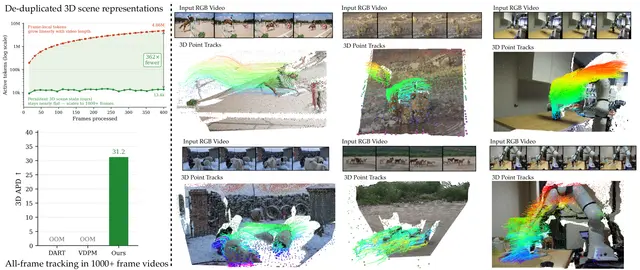
Dense 3D Point Tracking with Sliding-Window De-Duplication
AI26 thg 9
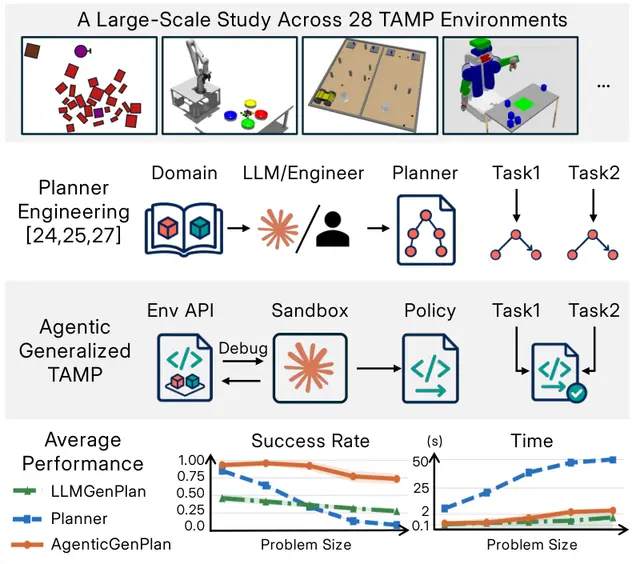
How Coding Agents Solve Generalized Robot Task and Motion Planning
AI25 thg 9
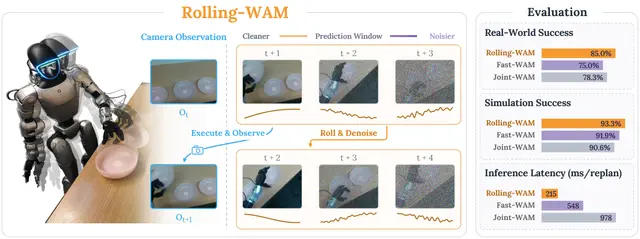
Rolling World Action Models for Faster Closed-Loop Robot Manipulation
AI25 thg 9
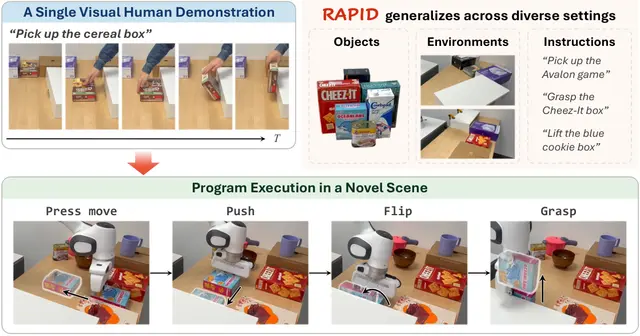
RAPID Enables Robot Manipulation Programs to Generalize Across Diverse New Scenes
AI25 thg 9
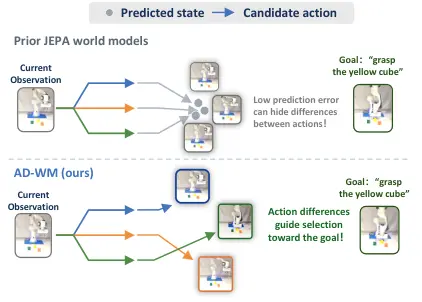
Action-Discriminative World Models Improve Counterfactual Robot Control
AI24 thg 9
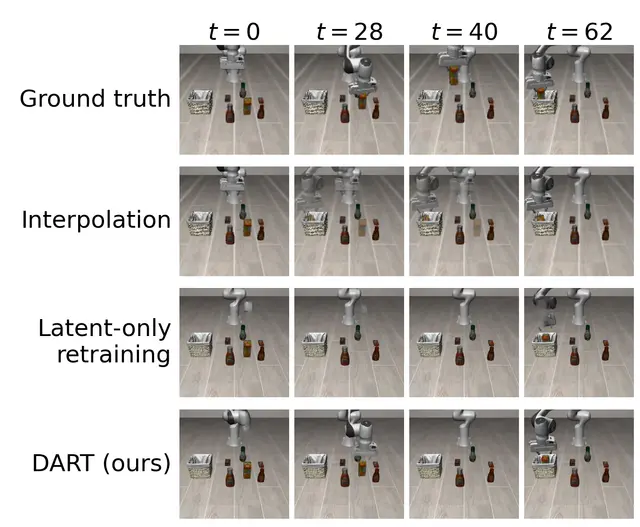
How DART Restores Lost Motion in Frozen World Models for Robots
Robotics24 thg 9