Nghiên cứu Papers
Bản tóm tắt dễ hiểu về các nghiên cứu robot mới nhất — robot hình người, robot bốn chân, tự động hóa công nghiệp và AI.
Humanoid25 thg 7
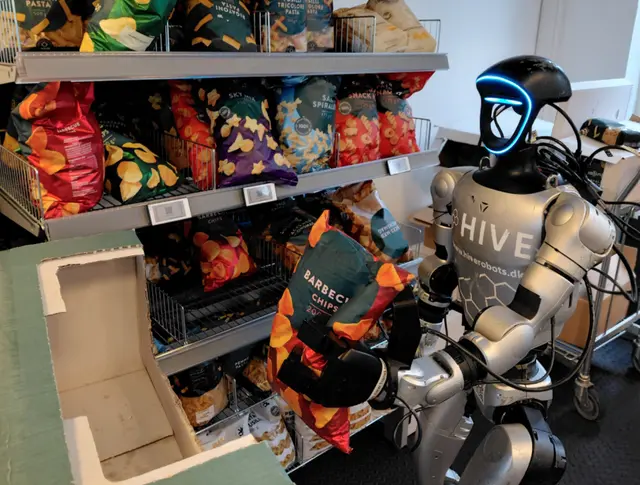
A Data-Efficient Framework for Deploying Retail Humanoid Robots in the Real World
AI25 thg 7
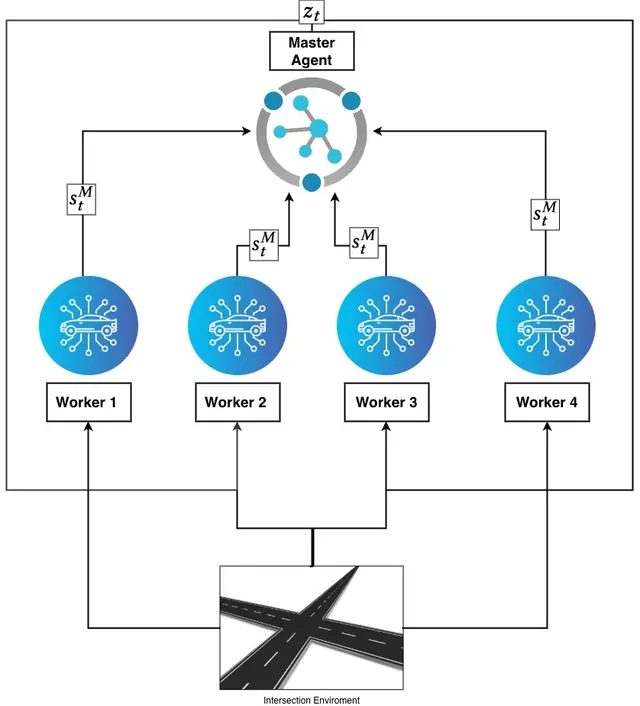
Zero-Collision Intersection Navigation via Compact Latent Coordination
AI25 thg 7
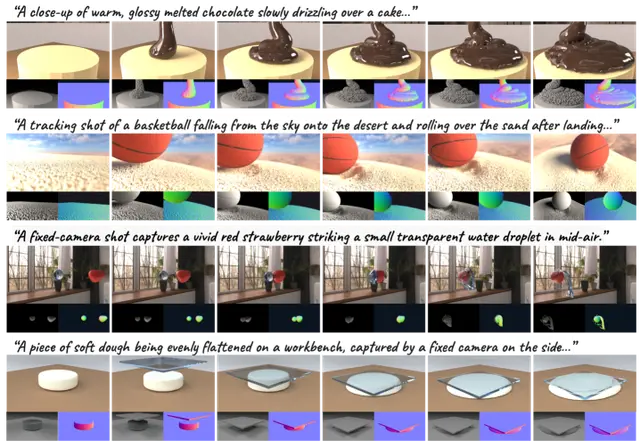
Multi-Agent Framework Generates 4D Physical Worlds From Natural Language
Robotics24 thg 7
Why Robots Forget Answers: Memory Bottlenecks in Sequential Embodied QA
Robotics24 thg 7
How to Train Robots That Actually Handle Novel Tasks: A Bias-Aware Data Strategy
Robotics24 thg 7
A Growable Community-Driven Data Engine for Scalable Robot Manipulation
Robotics23 thg 7
Distributed Motion Planning with Safety Guarantees for Self-Reconfiguring Robotic Boats
Robotics23 thg 7
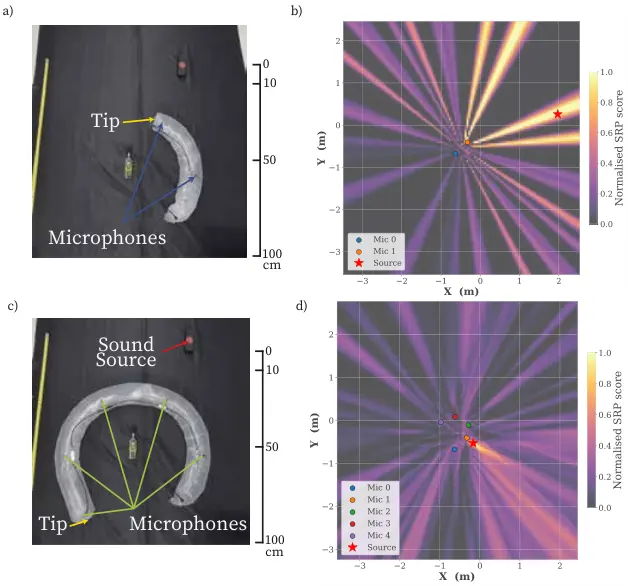
Soft Vine Robot Grows Microphone Array to Locate Sound Sources
Humanoid23 thg 7
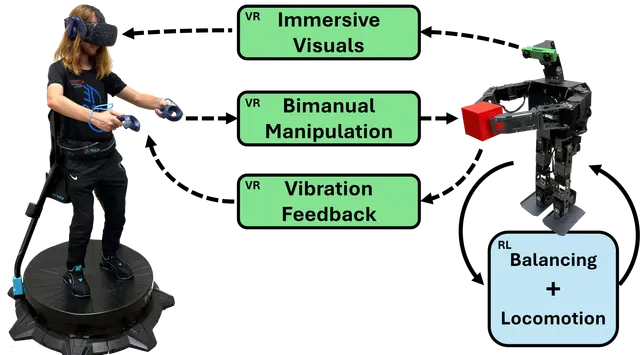
Miniature Humanoid Tele-Loco-Manipulation: VR Control + Reinforcement Learning
drones22 thg 7
No Training, Better Flights: Test-Time Scaling Makes Smarter UAV Navigation
drones22 thg 7
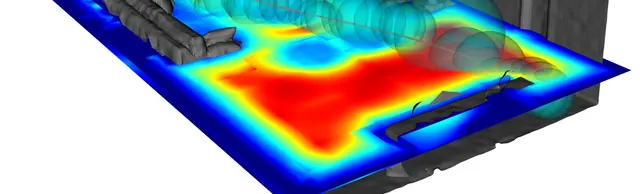
Real-Time Signed Distance Field Mapping and Fast Motion Planning for Drones
Robotics22 thg 7
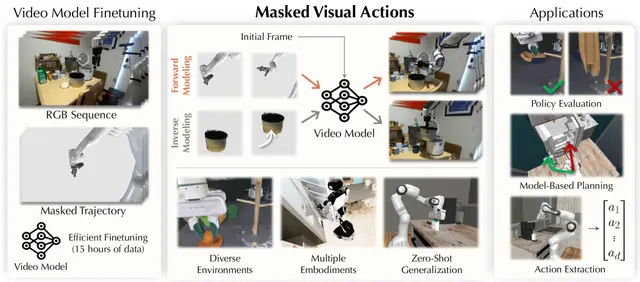
Masked Visual Actions Enable Robots to Learn World Models from Video
Humanoid21 thg 7
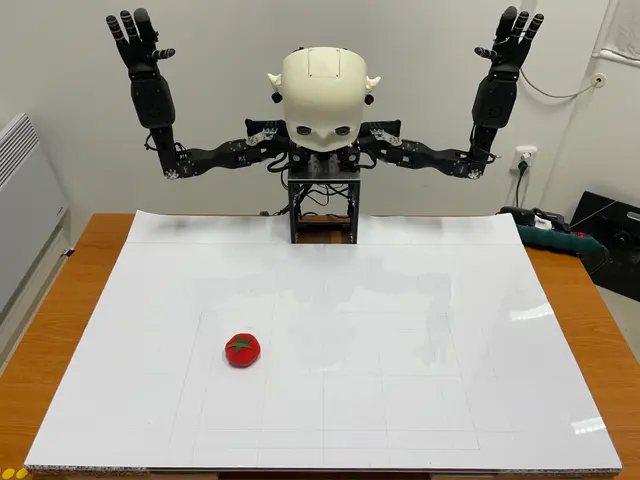
How Haptic Calibration and Visual Feedback Improve Humanoid Robot Grasping
Robotics21 thg 7
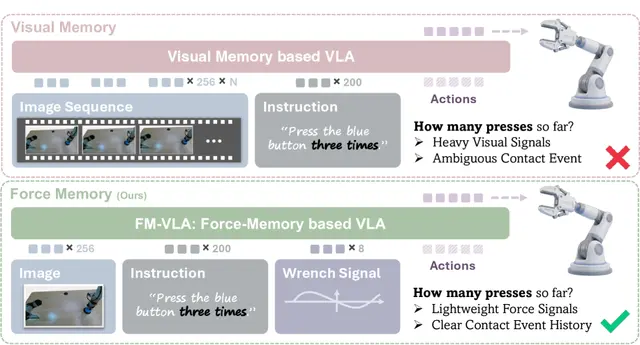
FM-VLA: Giving Robots a Sense of Touch Memory for Smarter Contact-Rich Tasks
AI21 thg 7
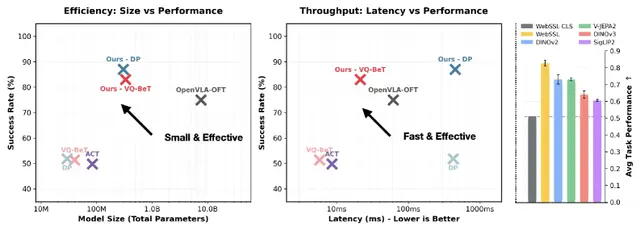
Patch Policy: Efficient Robot Control Through Dense Visual Patch Features
Robotics20 thg 7
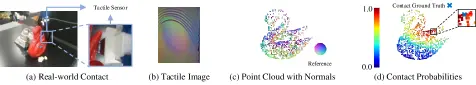
VTLoc: How Robots Pinpoint Touch in 3D Space Using Vision and Feel
Robotics20 thg 7
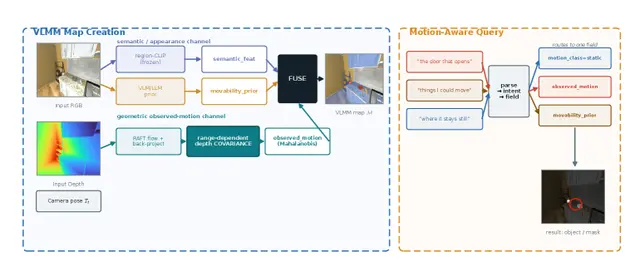
VLMM Gives Robots a New Way to Ask "Can I Move That?" in 3D Maps
Humanoid20 thg 7
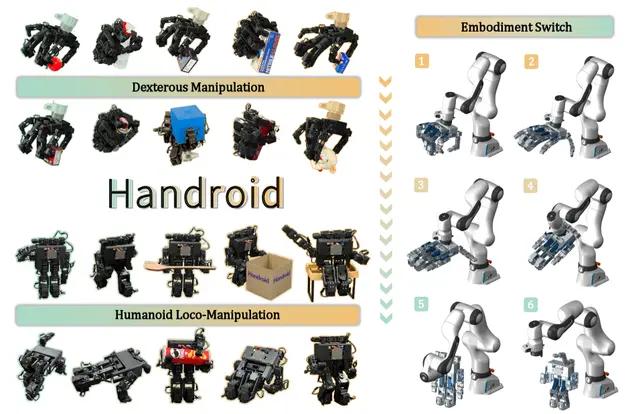
Handroid: A Desktop Robot That Switches Between Hand and Humanoid
AI19 thg 7