Nghiên cứu Papers
Bản tóm tắt dễ hiểu về các nghiên cứu robot mới nhất — robot hình người, robot bốn chân, tự động hóa công nghiệp và AI.
Robotics10 thg 9
Frequency-Aware Flow Matching Helps Robots Plan Smoother Actions
drones10 thg 9
Multi-Agent Reinforcement Learning for Autonomous Wildfire UAV Exploration
Robotics9 thg 9
Rethinking Learned Occupancy for Safer Autonomous Active Mapping with Observation-Gated Filtering
Robotics9 thg 9
Online Reachability Makes Sampling-Based Motion Planning Safer
AI9 thg 9
Contact-Aware Dexterous Robot Learning with Vision, Language, and Tactile Imagination
AI8 thg 9
RoboSPA Tests VLA Models on Spatial and Long-Horizon Tasks

Robotics8 thg 9
Why Behavior Trees Need Help to Adapt in Real-World Robots
Humanoid8 thg 9
Humanoid Robot Prototype Unifies Vision, Gestures, Voice, And Expressive Control
Robotics7 thg 9
Task Graphs Help Robots Execute Long-Horizon Manipulation Tasks
Robotics7 thg 9
Cross-View Geometry Helps Robots Build More Reliable Surround-View Depth Maps
Robotics7 thg 9
Testing Paraphrase Robustness in Vision-Language Robot Reward Models
AI6 thg 9
Training-Free 3D Scene Graph Reasoning for Multimodal Language Models
Robotics6 thg 9
Topological Graphs Help Robots Learn Closed-Loop Vision-Language Navigation
Robotics6 thg 9
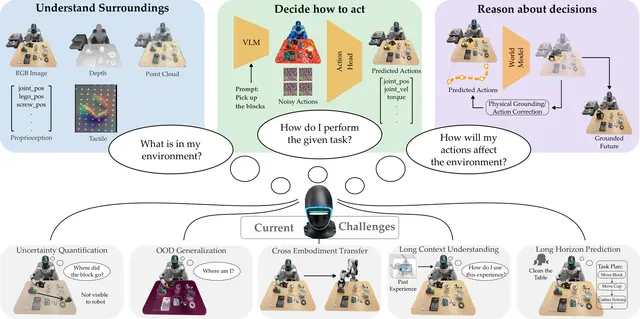
Unified Robot Learning Through Representations, Vision-Language-Action, and World Models
AI5 thg 9
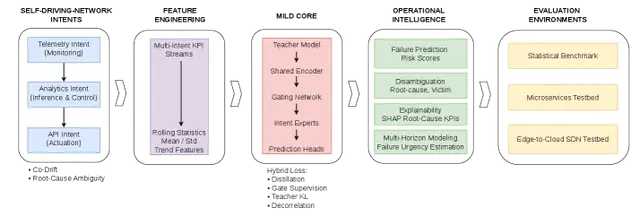
How AI Predicts and Untangles Cascading Network Failures Before They Spread
Robotics5 thg 9
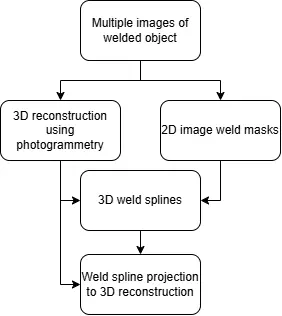
Smartphone Images Map Weld Seams in 3D for Robotic Finishing Work

AI5 thg 9
Efficient Active Reward Learning from Preferences with Subspace Inference
AI4 thg 9
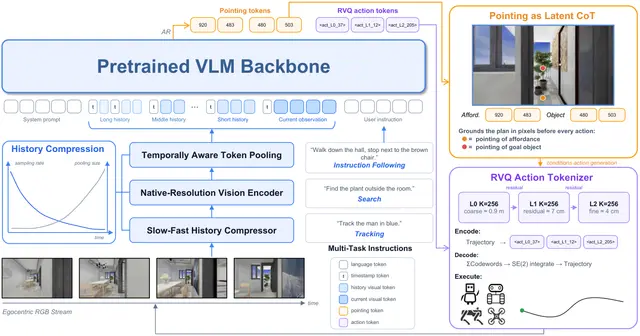
LightNav-0 Uses Spatial Intelligence for Generalist Robot Navigation
Robotics4 thg 9