Nghiên cứu Papers
Bản tóm tắt dễ hiểu về các nghiên cứu robot mới nhất — robot hình người, robot bốn chân, tự động hóa công nghiệp và AI.
Robotics22 thg 6
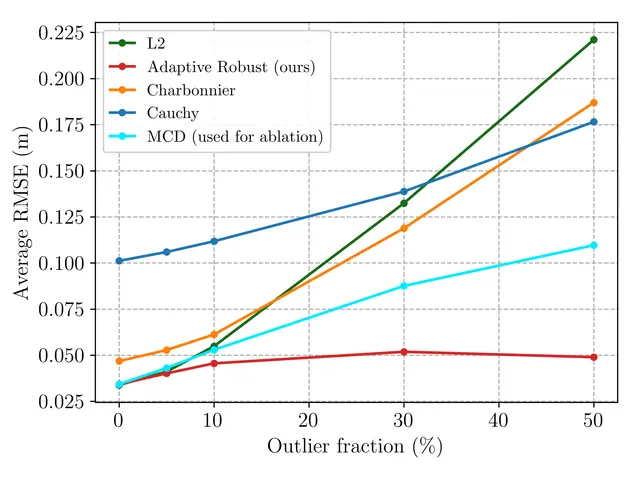
ARC: Adaptive Robust Estimation Handles Outliers and Unknown Noise in Real-Time Localization
Robotics22 thg 6
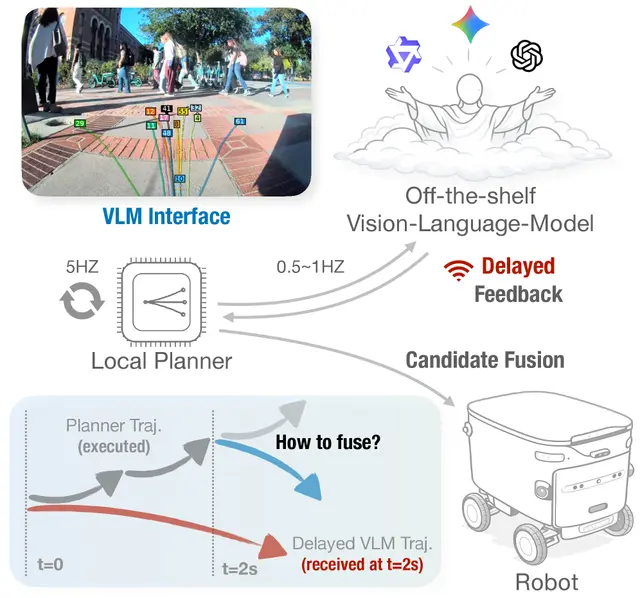
Slow Brain, Fast Planner: Keeping Robots Safe When AI Vision Takes Its Time
Robotics21 thg 6
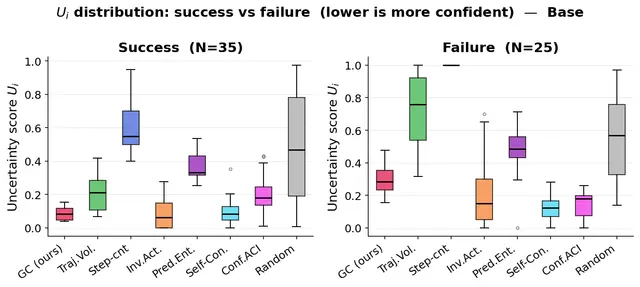
GroundControl: Anticipating Navigation Failures in Vision-Language Agents Using Trajectory-Consistent Uncertainty
Robotics21 thg 6
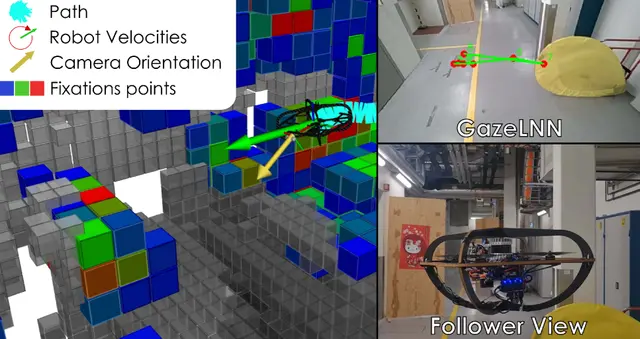
Fast Human Attention Prediction Enables Real-Time Fixation-Guided Drone Navigation

Robotics21 thg 6
New Motion Planning Algorithms Make Continuum Robots More Resilient
AI19 thg 6
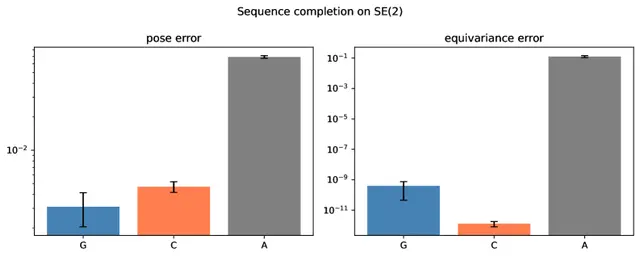
New Attention Mechanism Treats Robot Poses as Group Elements, Boosts Performance
Robotics19 thg 6
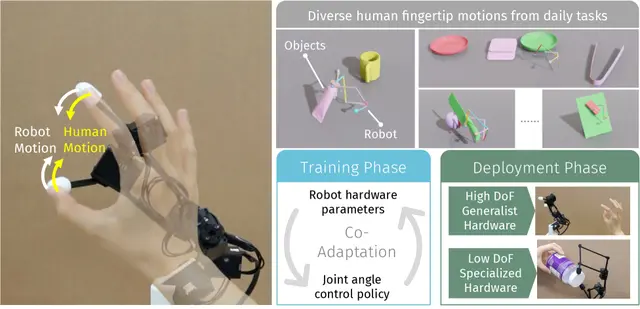
Generating Task-Specific Robot Hands from Human Fingertip Demonstrations
Robotics19 thg 6
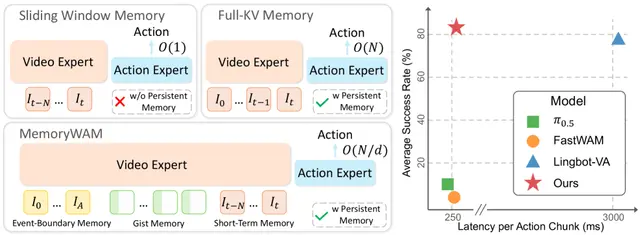
MemoryWAM: Persistent Memory Makes Robot Action Models Faster and Smarter
AI18 thg 6
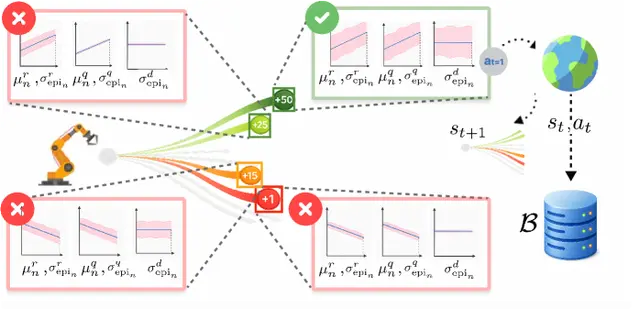
New Algorithm UBP2 Uses Uncertainty to Learn Robot Rewards from Preferences
Robotics18 thg 6
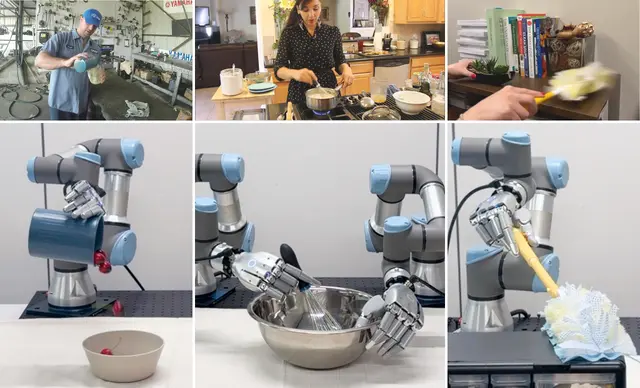
Do as I Do: Turning Everyday Human Videos Into Dexterous Robot Data
Robotics18 thg 6
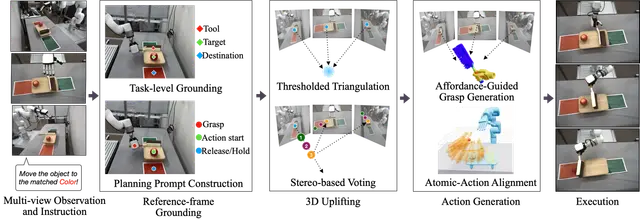
Zero-Shot Long-Horizon Dexterous Manipulation with Multi-View 3D Grounded VLM Reasoning
Robotics17 thg 6
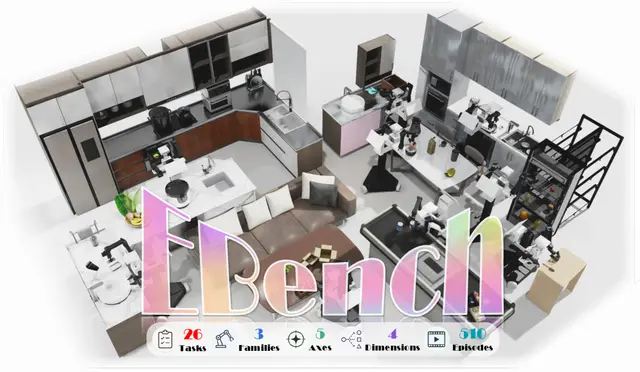
EBench: A New Benchmark Diagnoses Mobile Manipulation Robots' Core Capabilities
Robotics17 thg 6
MOCHI Cleans Up Noisy Multi-Human Object Interaction Data
AI17 thg 6
Visual Verifier Helps Robots Improve Their Own Policy Without Retraining
AI16 thg 6
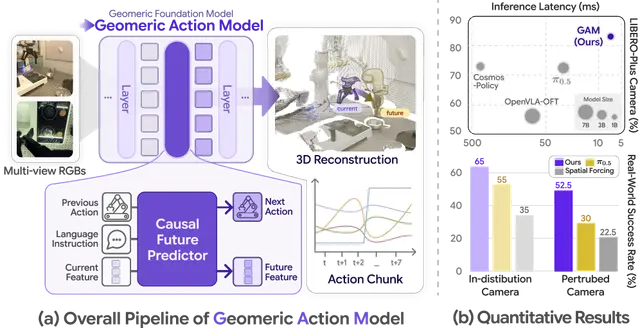
Geometric Action Model Unifies Geometry and Action Prediction for Robot Learning
Robotics16 thg 6
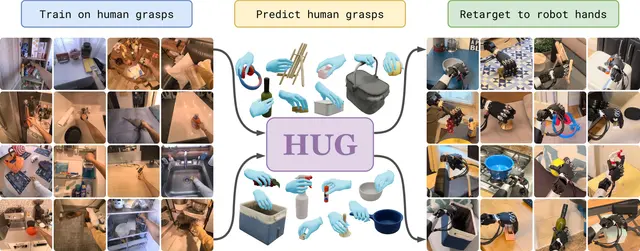
Human Universal Grasping: A Model That Learns Diverse Natural Grasps
Robotics16 thg 6
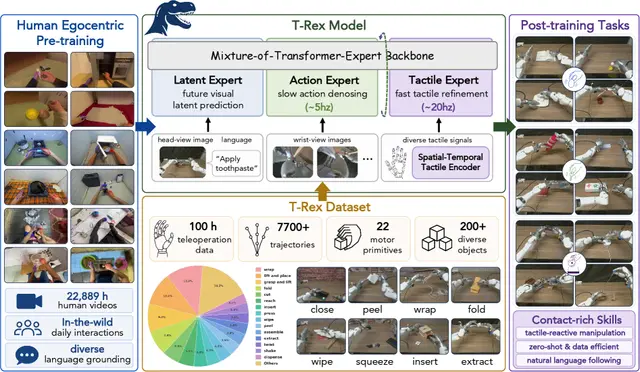
T-Rex: Tactile-Reactive Dexterous Manipulation Using Robot Hands
Robotics15 thg 6
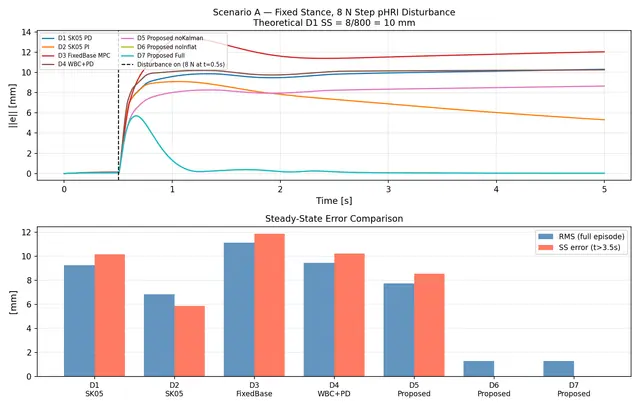
Whole-Body Impedance MPC Lets Legged Robots Safely Handle Human Pushes
Robotics15 thg 6