Nghiên cứu Papers
Bản tóm tắt dễ hiểu về các nghiên cứu robot mới nhất — robot hình người, robot bốn chân, tự động hóa công nghiệp và AI.
AI29 thg 6
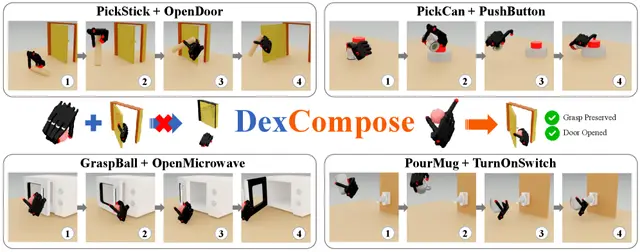
DexCompose Lets One Robot Hand Chain Dexterous Skills Without Retraining
Robotics28 thg 6
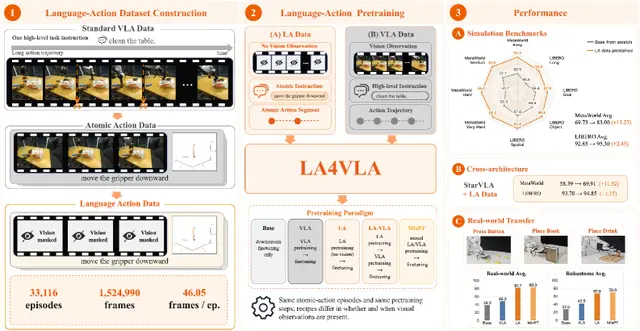
LA4VLA: Teaching Robots to Follow Instructions Without Seeing

Robotics28 thg 6
OctoSense: Self-Supervised Learning Unifies 8 Sensors for Robust Robot Perception
AI28 thg 6
Hallucination in World Models is Predictable and Preventable
Robotics27 thg 6
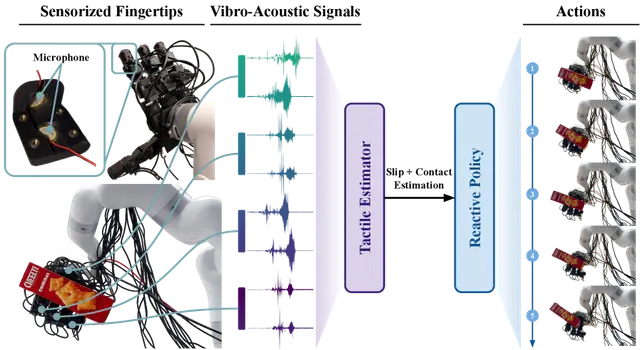
VibeAct: Using Vibration to Enable Reactive Robot Hand Dexterity
Robotics27 thg 6
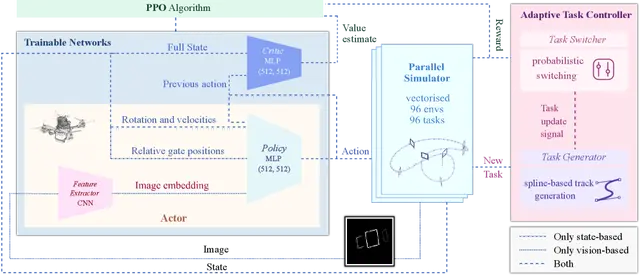
New Reinforcement Learning Method Lets Drones Race Fast in Unseen Tracks Without Retraining
Robotics27 thg 6
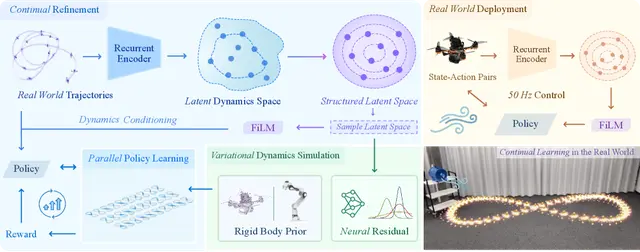
Continual Robot Learning: Adapting to Changing Dynamics in Real Time
Robotics26 thg 6
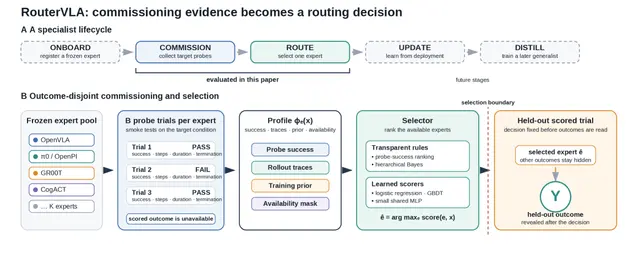
RouterVLA: Using Routine Smoke Tests to Pick the Best Robot VLA Model
Robotics26 thg 6
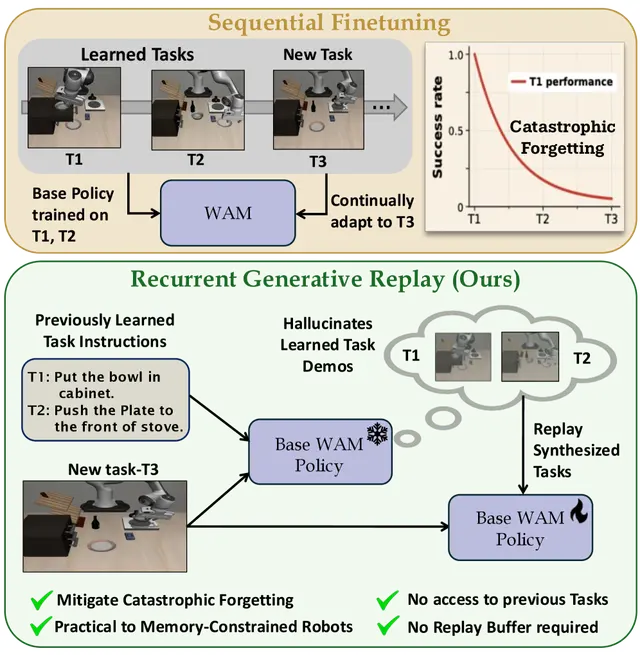
World Action Models Use Generative Replays to Prevent Robot Forgetting

Robotics26 thg 6
Massive Open Dataset and Toolkit for Robot Behavior Cloning
Robotics25 thg 6
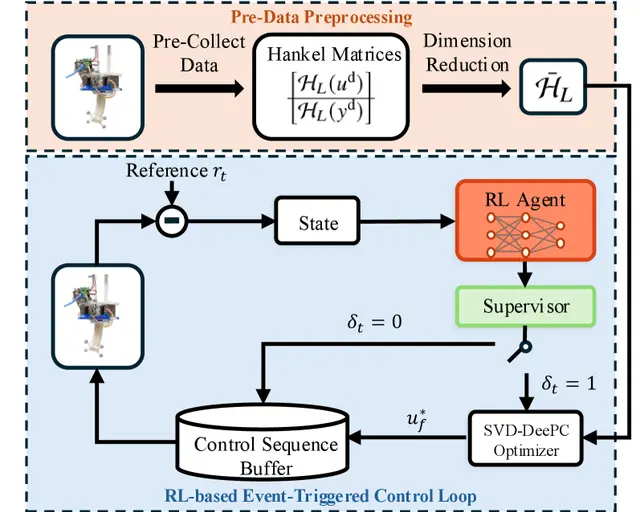
Deep Reinforcement Learning Makes Cable-Driven Soft Robot Arms More Computationally Efficient
Robotics25 thg 6
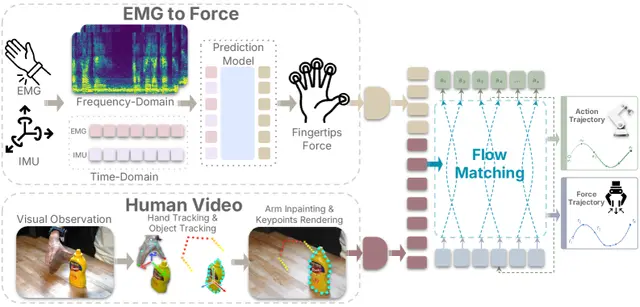
ForceBand: Learning Forceful Robot Manipulation Through Muscle Sensing
AI25 thg 6
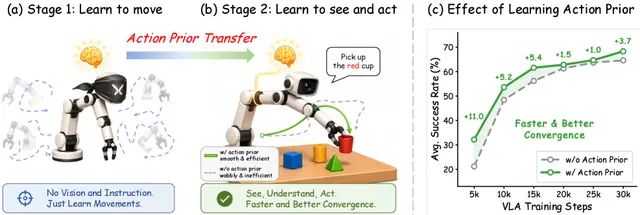
Robots Learn the Feel of Movement Before Learning to See and Act
Robotics24 thg 6
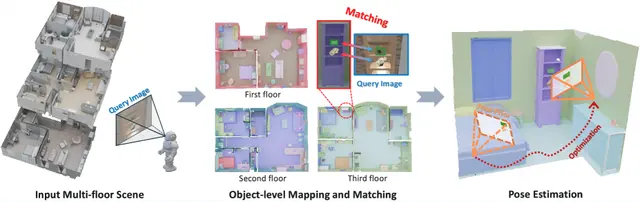
OpenReLoc: Object-Level Camera Relocalization with Open-Vocabulary Understanding
Warehouse24 thg 6
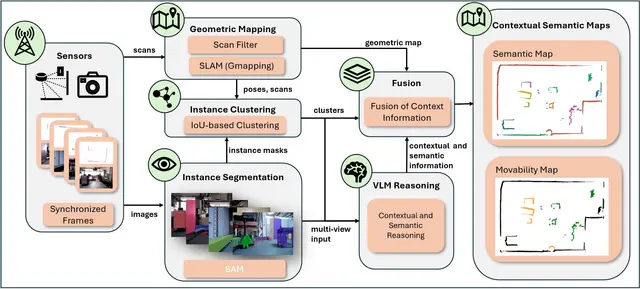
Vision-Language Model Gives Warehouse Robots Context-Aware Semantic Maps
AI24 thg 6
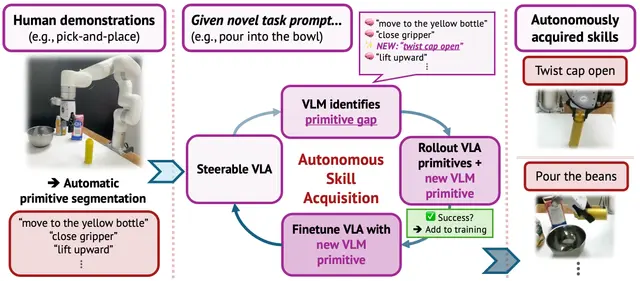
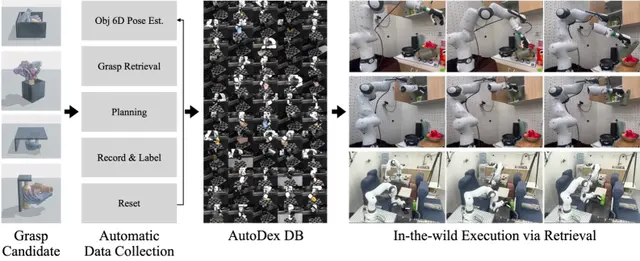
InSight: How Robots Learn New Skills Without Human Help
Robotics23 thg 6
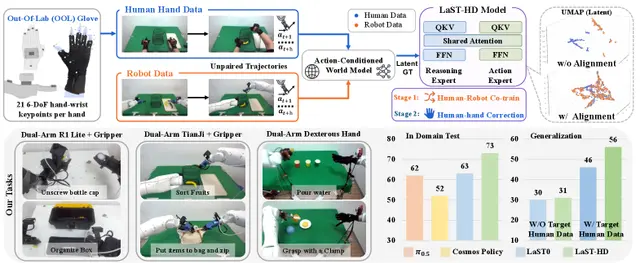
Robots Learn Physical Reasoning from Scalable Human Hand Data
Robotics23 thg 6
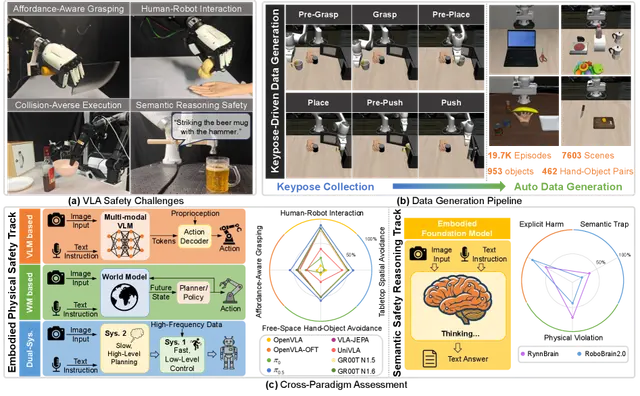
LIBERO-Safety Benchmark Puts Vision-Language-Action Robots Through Physical and Semantic Safety Tests
AI23 thg 6