Papers de cercetare
Rezumate în limbaj simplu ale celor mai recente cercetări în robotică — roboți umanoizi, roboți cvadrupedi, automatizare industrială și inteligență artificială.
Robotics12 iul.
FabriVLA: Lightweight VLA for Precise Multi-Task Manipulation

Robotics12 iul.
New Metric Measures How Human-Like and Comfortable Robot Movements Are
Robotics11 iul.
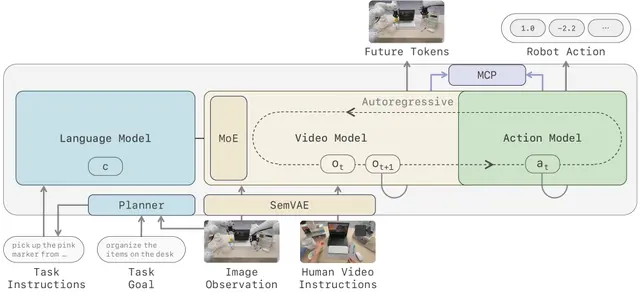
Native Video-Action Pretraining for Generalizable Robot Control
AI11 iul.
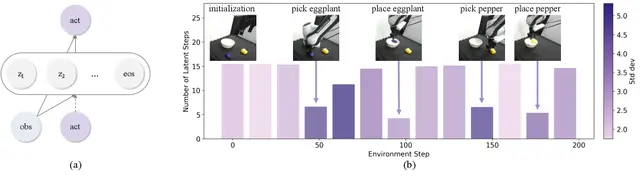
Latent Memory Palace: Teaching Robots to Reason Like Humans With Adaptive Compute
Robotics11 iul.
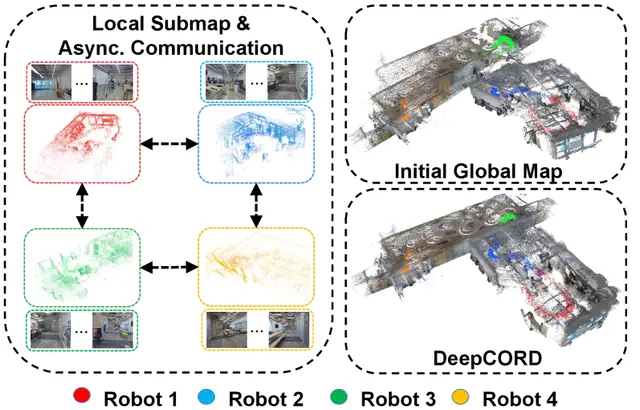
DeepCORD: Learning Adaptive Distributed Optimizers for Multi-Robot SLAM
AI10 iul.
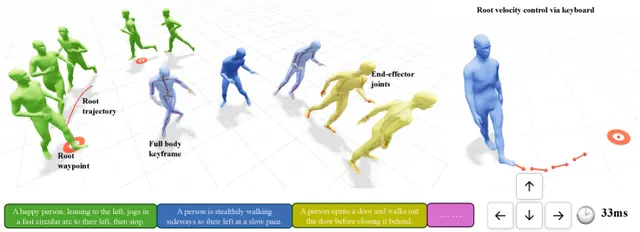
ARDY: Autoregressive Diffusion Model for Interactive Human Motion Generation
Humanoid10 iul.
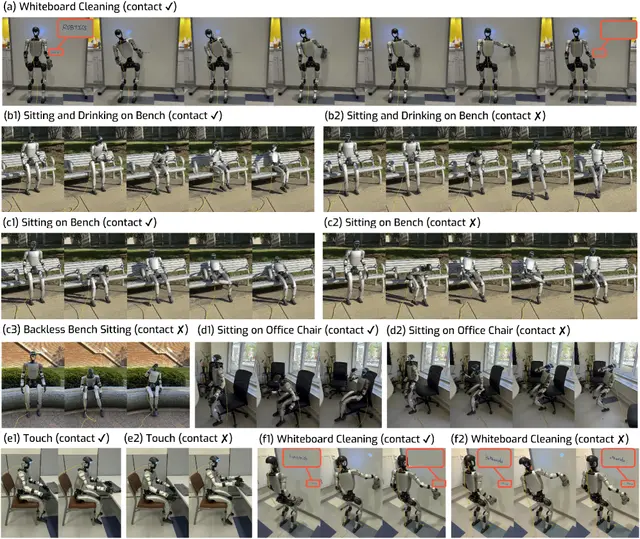
Humanoid Robots Learn to Control Object Contact Through Motion Mimicry
Robotics10 iul.
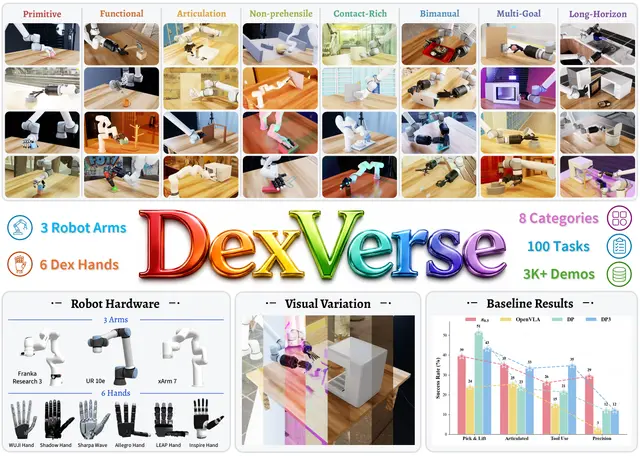
DexVerse: A Modular Benchmark for Multi-Task, Multi-Embodiment Dexterous Manipulation
AI9 iul.
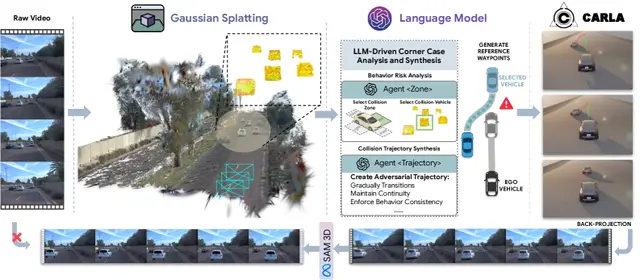
CARLA-GS: Decoupled AI Pipeline Synthesizes Rare Driving Scenarios from Real Data
Robotics9 iul.
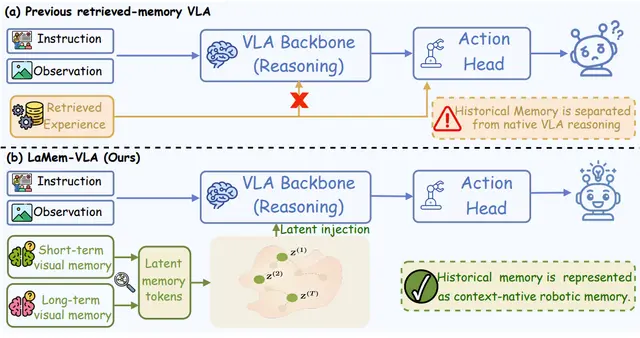
Dual Latent Memory Gives Robot Arms Sharper Long-Horizon Skills

Robotics9 iul.
Elephant Trunk Inspires ELEANOR: A Soft Architected Arm for Grasping
Robotics8 iul.
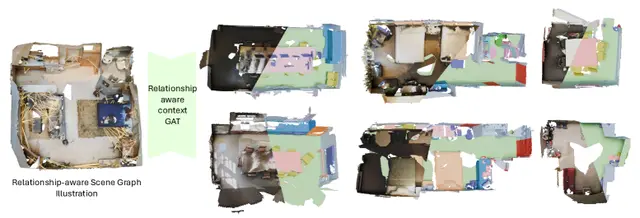
Beyond Isolated Objects: How 3D Scene Graphs Unlock Smarter Open-Vocabulary Robot Perception
AI8 iul.
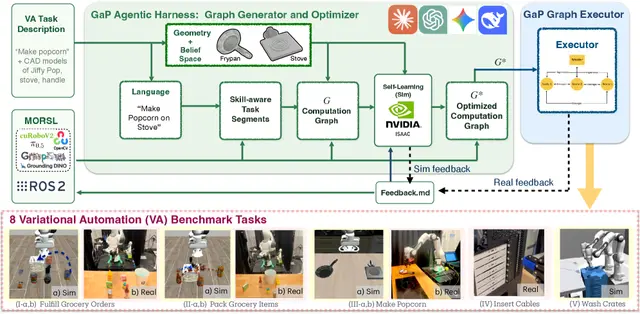
GaP: A Graph-Based Multi-Agent System for Variational Automation Tasks
AI8 iul.
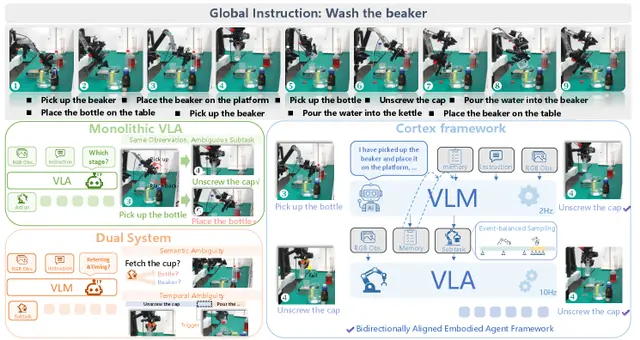
Cortex Framework: How a Bidirectional AI Solves Long-Horizon Robot Manipulation
Robotics7 iul.
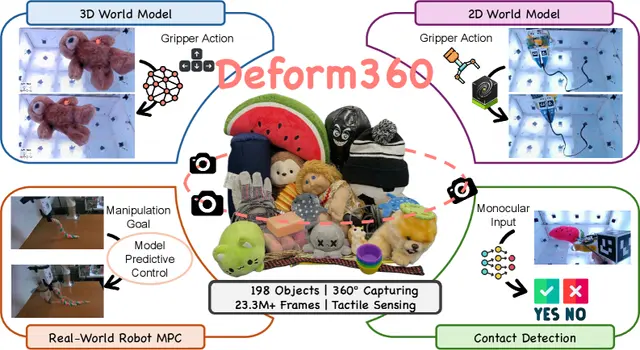
Deform360 Dataset Brings 41 Cameras and Touch Sensing to Deformable Object Robotics
AI7 iul.
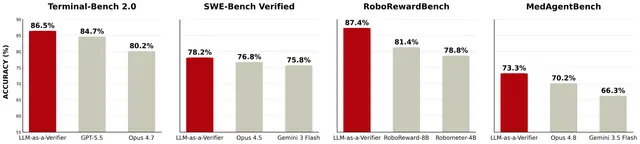
LLM-as-a-Verifier: A General Purpose Framework for Checking Robot and AI Outputs
AI7 iul.
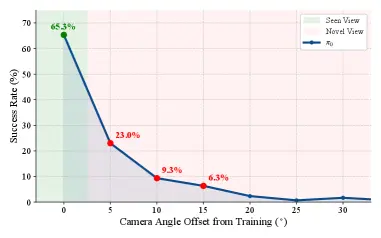
Robots That Adapt to Any Camera Viewpoint Without Calibration

drones6 iul.
Affordable Drones Get Smarter: Real-Time Vision on a $100 UAV
Robotics6 iul.