Papers de cercetare
Rezumate în limbaj simplu ale celor mai recente cercetări în robotică — roboți umanoizi, roboți cvadrupedi, automatizare industrială și inteligență artificială.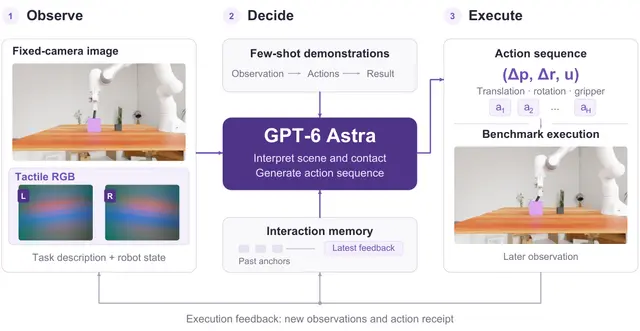
AIacum 20 de zile
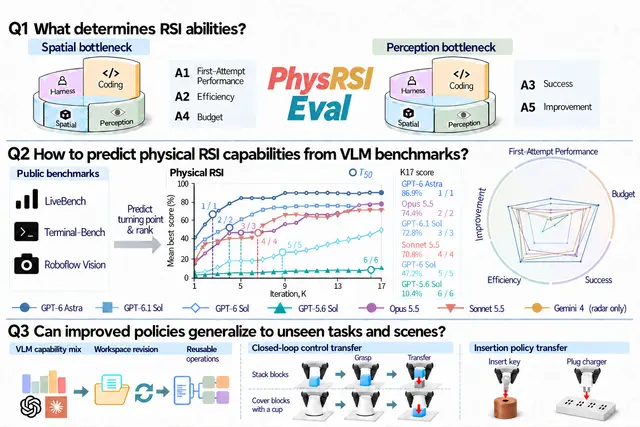
How LLMs Improve Robot Manipulation Through Physical Feedback and Repeated Practice
Roboticsacum 20 de zile
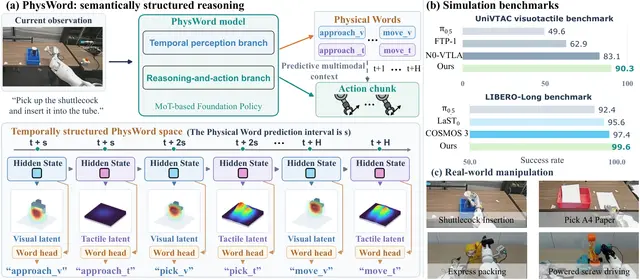
Robot Words Help Manipulators Predict Motion, Touch, and Reuse Actions Better
Roboticsacum 21 de zile
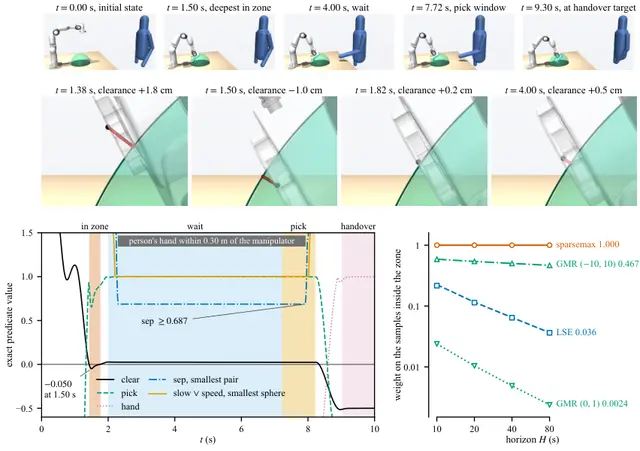
SparseMax-dSTL Enables Sound Temporal Logic Trajectory Optimization
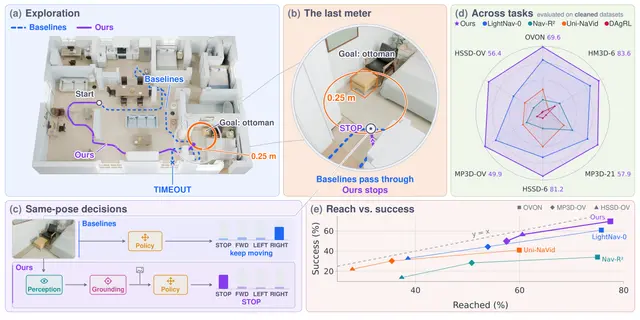
Roboticsacum 21 de zile
Why Robots Reach Navigation Goals but Still Fail to Stop Correctly
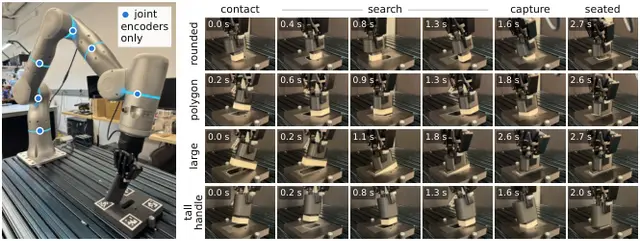
Roboticsacum 21 de zile
Precise Proprioceptive Sim-to-Real Robot Assembly for Diverse Pegs, Gears, and Nuts
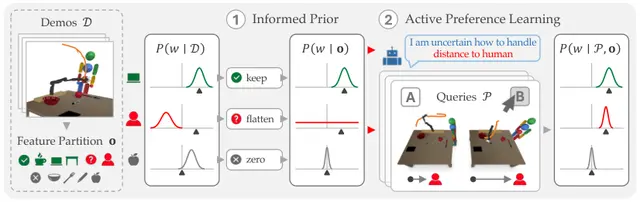
AIacum 22 de zile
Robots Learn to Ask Better Questions About What People Really Want
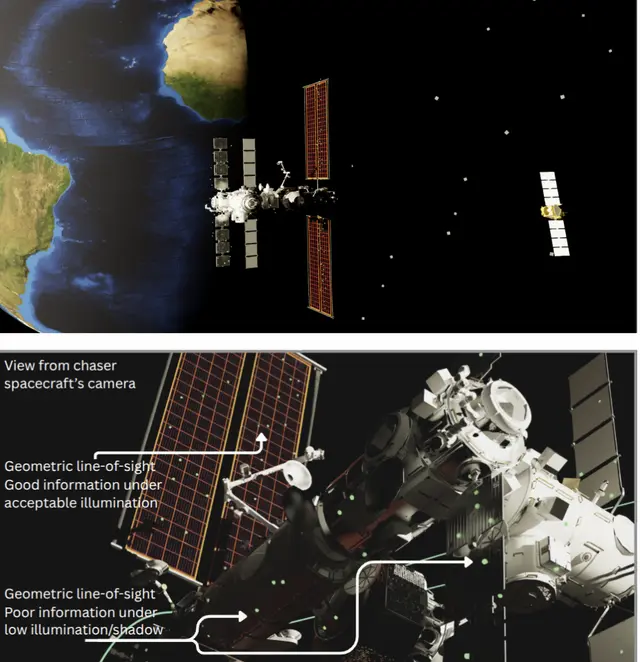
Roboticsacum 22 de zile
Active Perception for Better-Lit Autonomous Spacecraft Inspection in Orbit
Roboticsacum 22 de zile
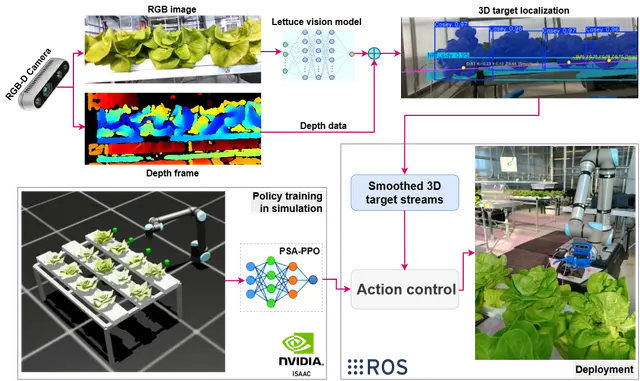
Path-Safe Sim-to-Real Learning for Hydroponic Lettuce Harvesting
AIacum 23 de zile
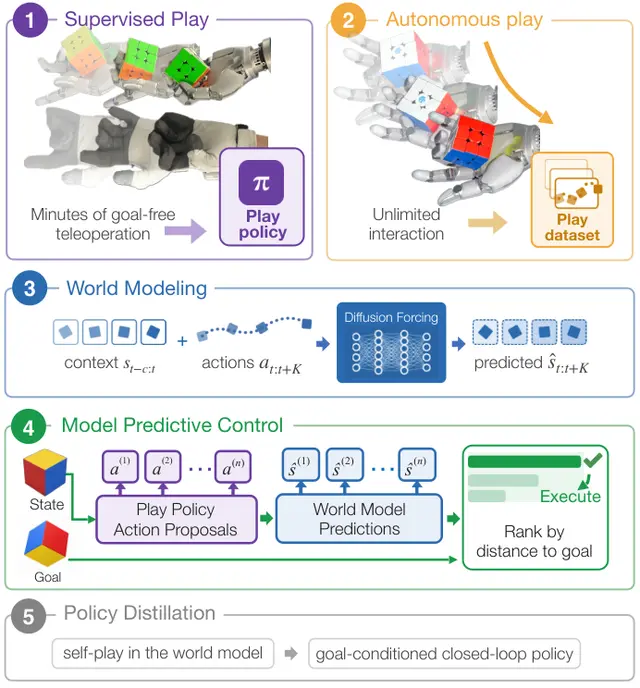
Dexterous Robot Manipulation Through Supervised Play and Planning
AIacum 23 de zile
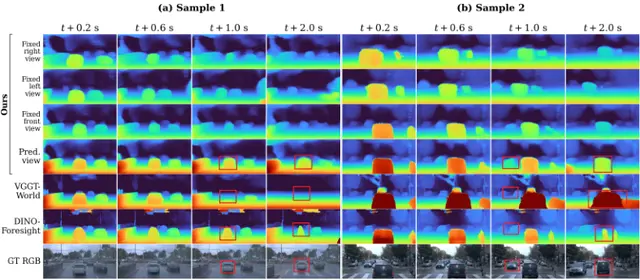
GeoState Helps Robots Predict 3D Scenes Beyond Their Current Camera View
AIacum 23 de zile
How Co-Evolving Robot Training Worlds Helps Policies Learn and Adapt Better
Roboticsacum 24 de zile
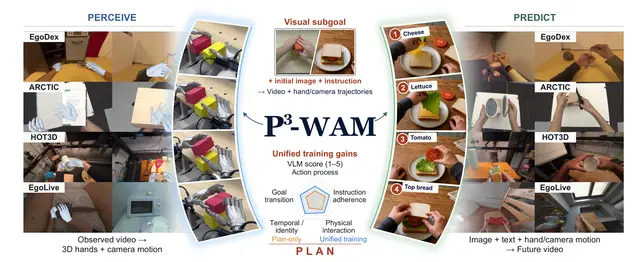
Dexterous Robots See, Predict, and Plan with One World Action Model
AIacum 24 de zile
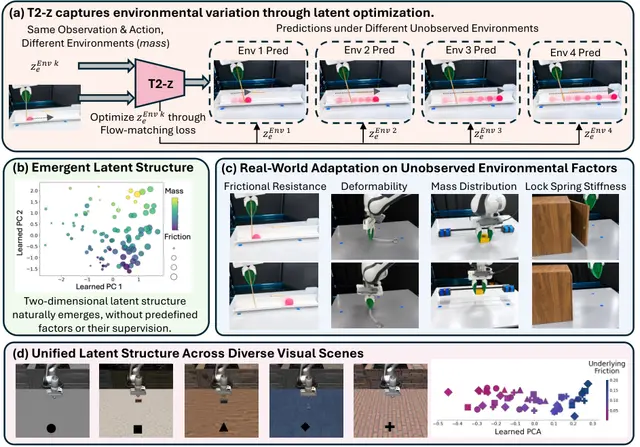
T2-z Optimizes Environment Latents for Robotic World Models at Test Time
Roboticsacum 24 de zile
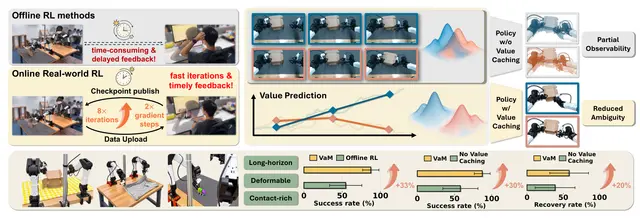
Robot Policies Turn Value Predictions Into Memory to Learn Online
AIacum 25 de zile
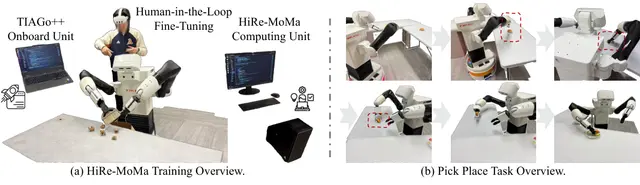
Sparse Human Guidance Trains Mobile Robots for Real-World Object Manipulation Tasks
Humanoidacum 25 de zile
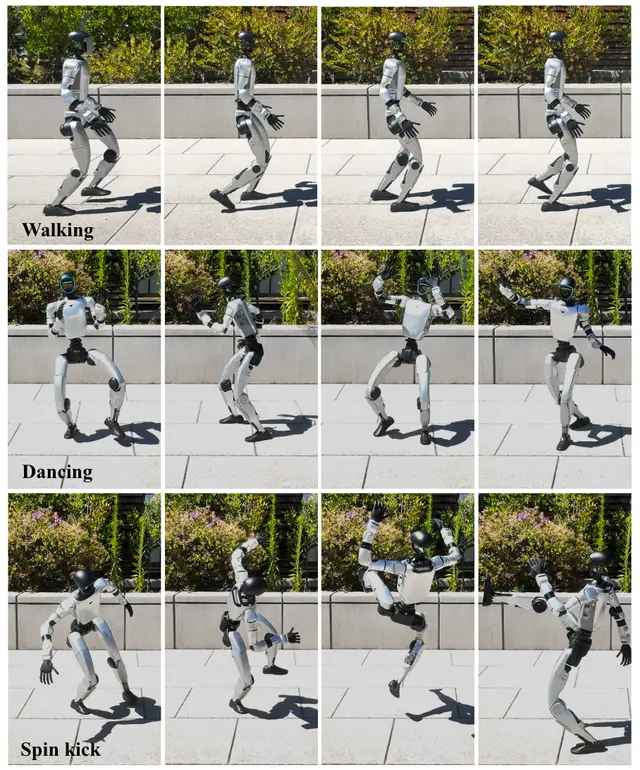
Diffusion Builds Humanoid Controllers From Weights for Real Robot Motion
Roboticsacum 25 de zile
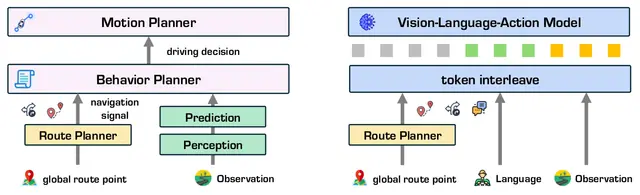
A Driving AI That Checks If Navigation Commands Are Safe First
Roboticsacum 26 de zile
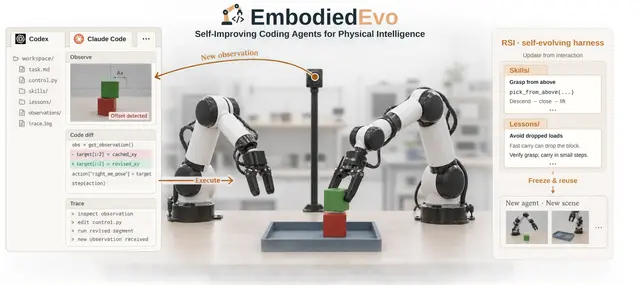
EmbodiedEvo: Coding Agents Build Reusable Skills for Physical Robot Tasks
AIacum 26 de zile