Papers de cercetare
Rezumate în limbaj simplu ale celor mai recente cercetări în robotică — roboți umanoizi, roboți cvadrupedi, automatizare industrială și inteligență artificială.
Roboticsacum 27 de zile
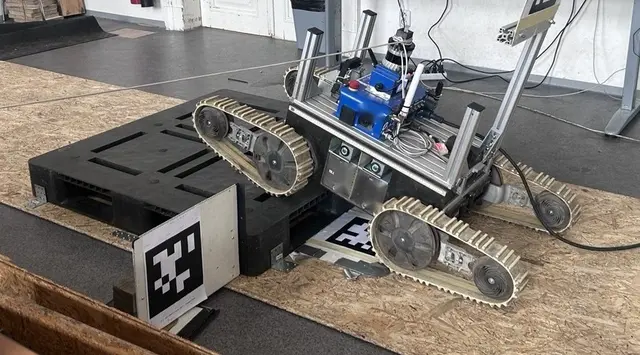
A Mapless Flipper Controller Helps Tracked Robots Stay Level and Escape
Roboticsacum 27 de zile
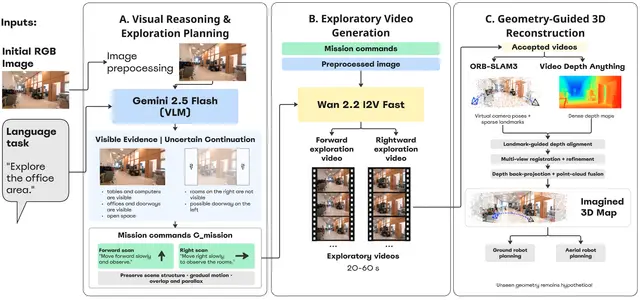
Robots Use Imagined Video to Build 3D Maps Before They Move
Roboticsacum 27 de zile
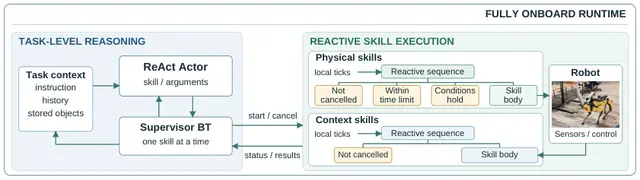
How Behavior-Tree Agents Make Onboard Robots More Reliable in Real Tasks
Roboticsacum 28 de zile
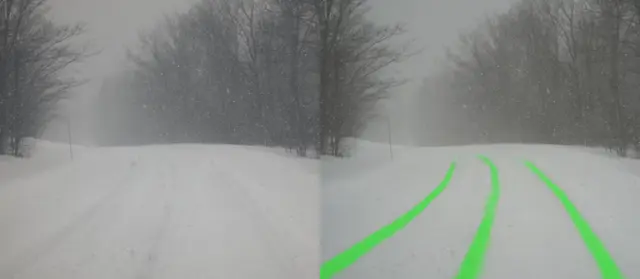
Thermal Vision Helps Robots Find Hidden Wheel Tracks in Snow Safely
Roboticsacum 28 de zile
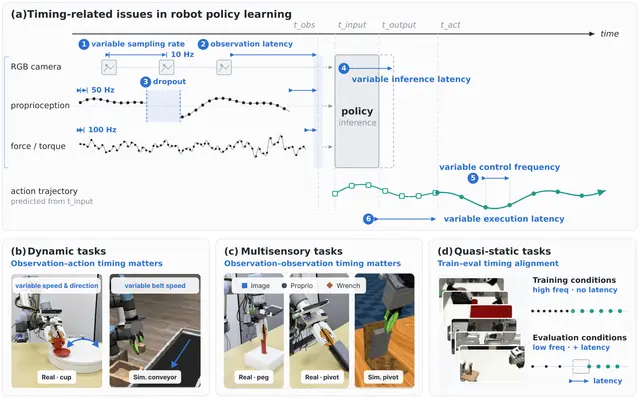
Chronos Policy Uses Physical Time to Improve Robot Learning and Control
Roboticsacum 28 de zile
Robots Learn New Tasks by Changing the Noise Behind Their Actions
AIacum 29 de zile
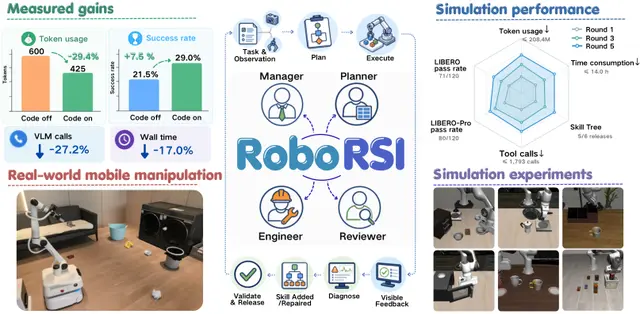
How RoboRSI Helps Robots Improve and Reuse Skills in Real Environments
Roboticsacum 29 de zile
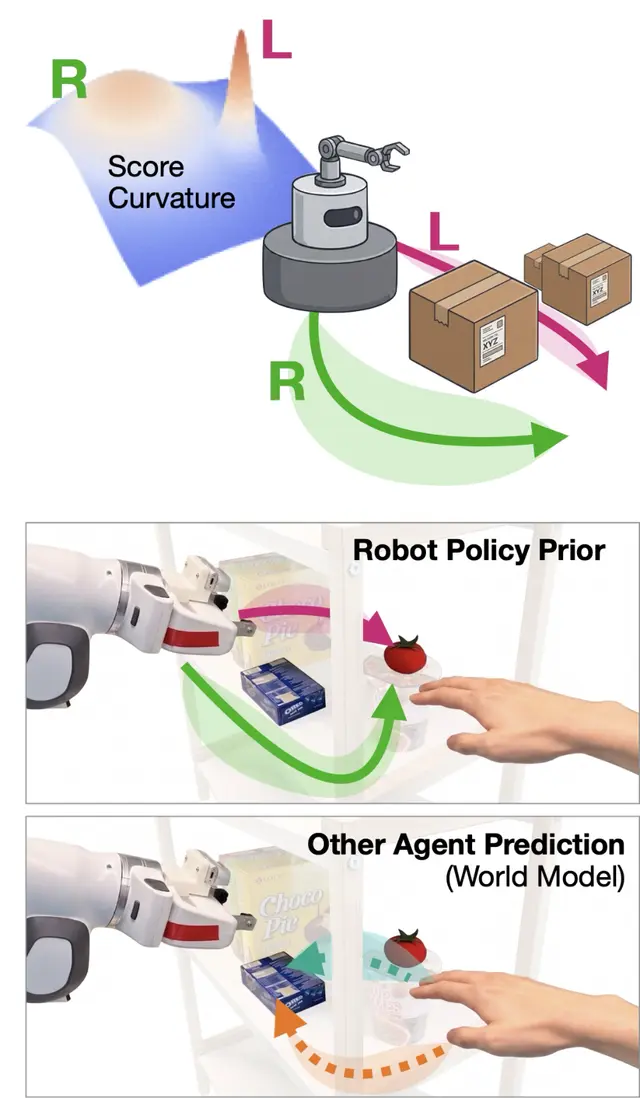
Fast Robot Trajectory Uncertainty Enables Safer Paths Through Crowds and Obstacles
AIacum 29 de zile
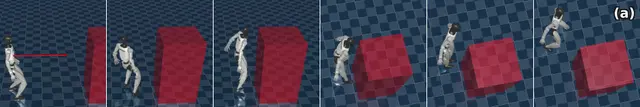
A Safety Filter Helps Humanoids Stay Safe Without Sacrificing Their Tasks
Robotics10 oct.
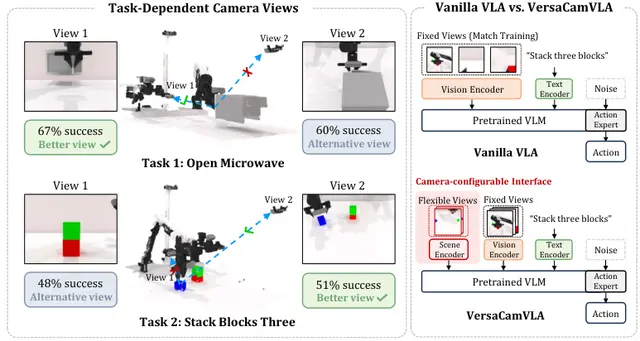
Flexible Camera Policies Help Robots Handle Changing Views During Manipulation Tasks
Robotics10 oct.
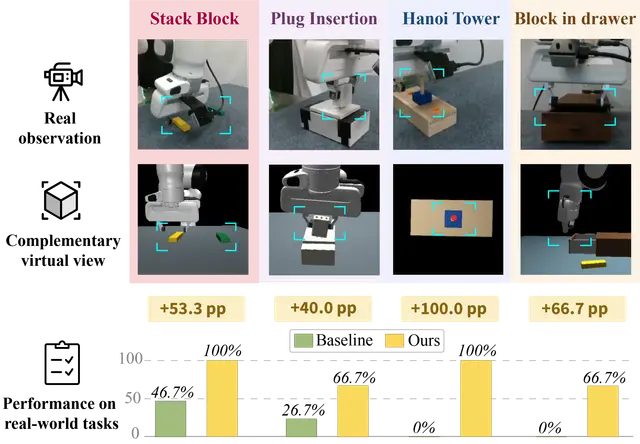
Virtual Views Help Robots Improve Fine Manipulation Success at Test Time
AI10 oct.
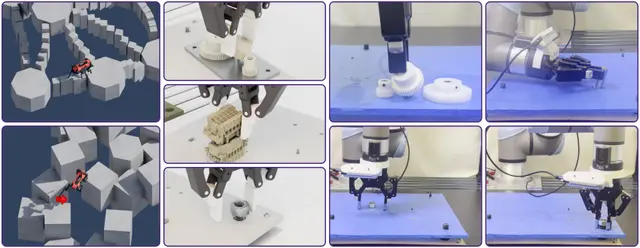
A Balanced Data Diet Improves Large-Scale Reinforcement Learning for Robot Control
AI9 oct.
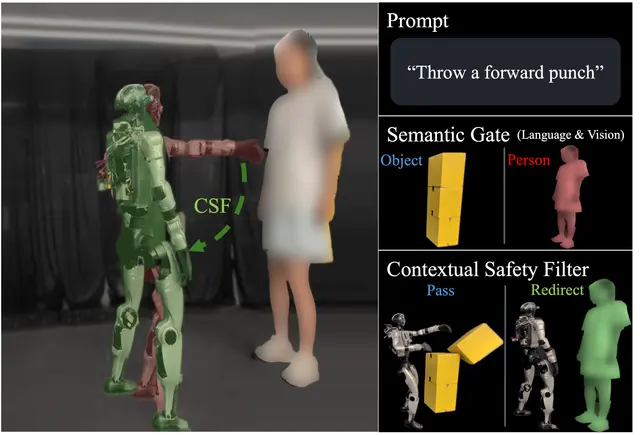
How Context-Aware Safety Filters Keep Generated Humanoid Motions Safe Near People
Robotics9 oct.
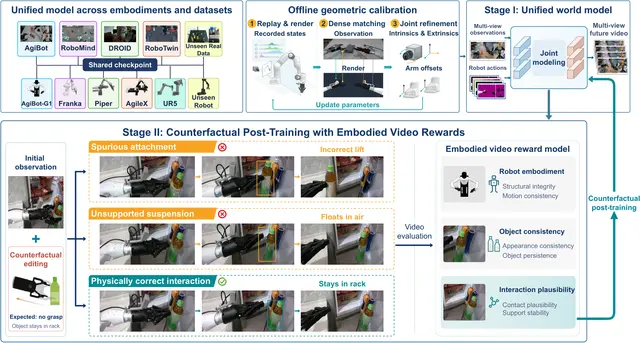
A Robot World Model That Tests Actions Before Robots Try Them
Robotics9 oct.
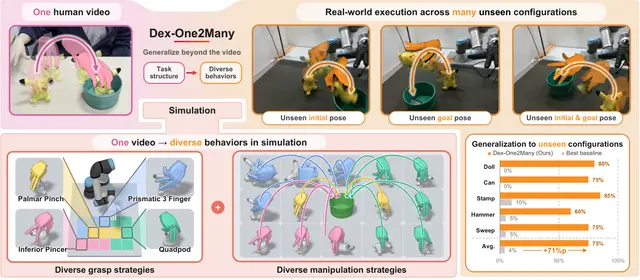
Learning Generalizable Dexterous Robot Manipulation from a Single Human Demonstration
AI8 oct.
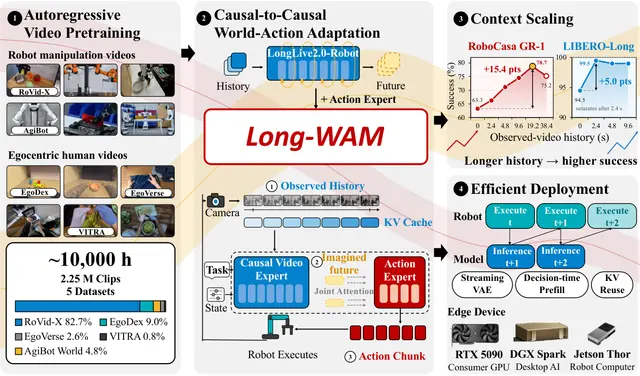
Long-WAM Scales Visual Context for Predictive Robot Action and Control
Robotics8 oct.
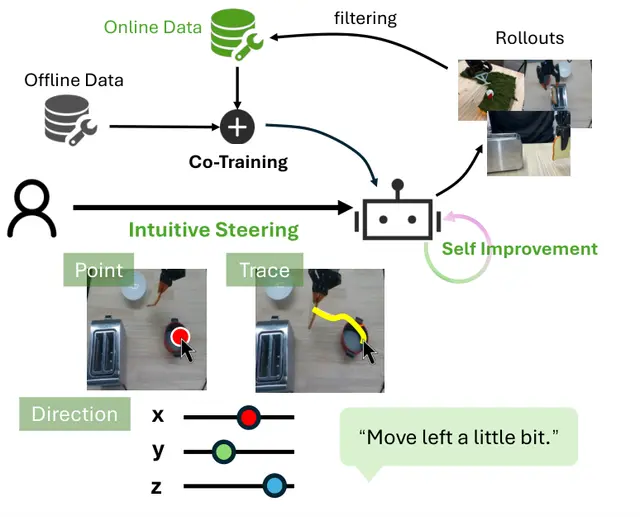
Steer Robot Policies with Sparse Human Input Using RoboPrompt
AI8 oct.
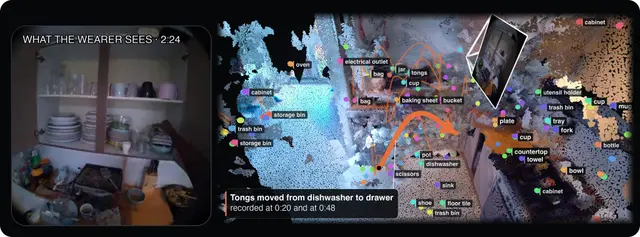
Persistent 3D Object Memory for Spatial Questions in Egocentric Video
Robotics7 oct.