Papers sa Pananaliksik

Mga buod sa payak na Ingles ng pinakabagong pananaliksik sa robotika — mga robot na humanoid, mga robot na may apat na paa, awtomasyong industriyal, at artipisyal na intelihensiya.
499 papers
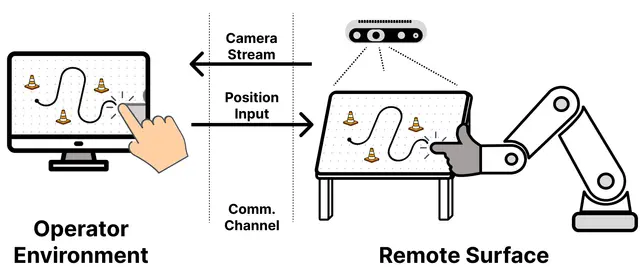
Touchscreen Teleoperation Interface for Robotic Manipulator Control
RoboticsAgo 8

Touchscreen Teleoperation Interface for Robotic Manipulator Control

A total of 20 participants took part in the study, of whom 17 chose to disclose demographic information.

Juan José García Cárdenas, Alperen Kenan, Hamidreza Raei, Paul Bremner +3

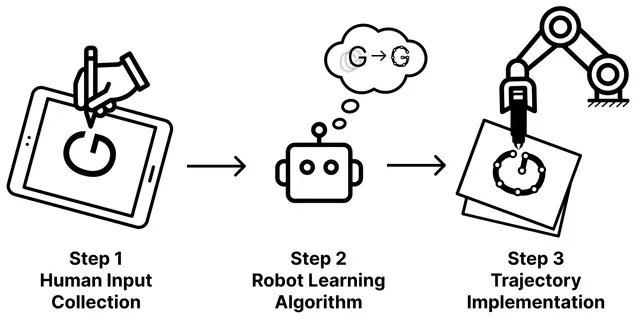
Learning Human-Like Robot Handwriting from Demonstrations and Force Data
AIAgo 8

Learning Human-Like Robot Handwriting from Demonstrations and Force Data

Several datasets have been proposed to study human handwriting and drawing behaviour.

Alperen Kenan, Paul Bremner, Manuel Giuliani

Interactive Visual-Action World Models for Generalizable Robot Manipulation
RoboticsAgo 7

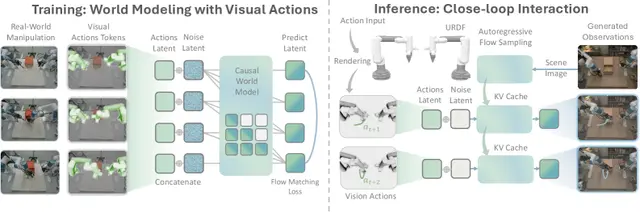
Interactive Visual-Action World Models for Generalizable Robot Manipulation

In this work, we introduce GeniWorld, a generalizable interactive world model conditioned on visual actions.

Chenghao Gu, Hanyang Yu, Jingbo Zhang +7

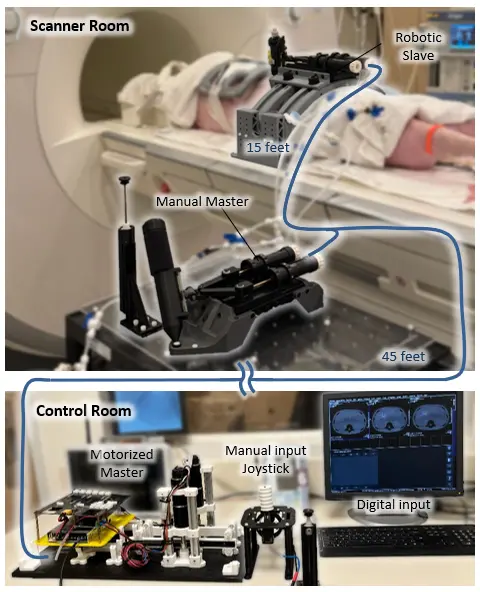
MRI-Safe Master-Slave Robot Enables Remote Needle Guidance in Closed MRI Bores
RoboticsAgo 7

MRI-Safe Master-Slave Robot Enables Remote Needle Guidance in Closed MRI Bores

Omar Curiel, Jing-Yuan Huang, Po-Chih Chen +6

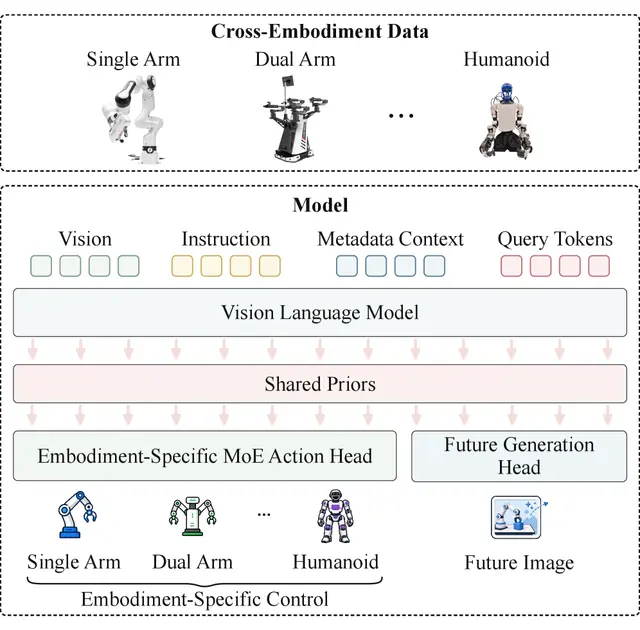
One Policy Controls Three Robots Using Shared Skills Across Different Bodies
RoboticsAgo 7

One Policy Controls Three Robots Using Shared Skills Across Different Bodies

Junfeng Li, Junjie He, Zhide Zhong +12

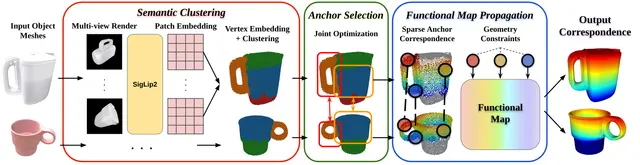
Semantic Anchored Correspondence for Zero-Shot Robot Skill Transfer
RoboticsAgo 6

Semantic Anchored Correspondence for Zero-Shot Robot Skill Transfer

SemAnCorr is a training-free framework establishing dense correspondence across objects by anchoring semantically meaningful regions and propagating constraints via functional maps for zero-shot manipulation skill transfer.

Xiaoxiang Dong, William Baron, Hongyi Chen +3

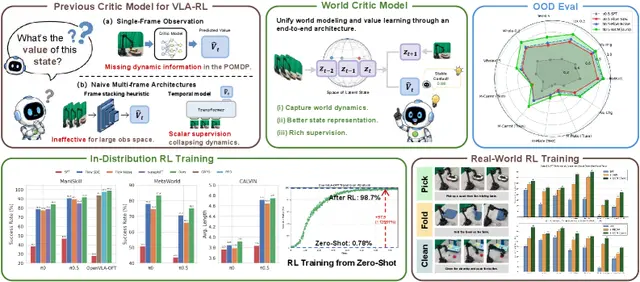
World Critic Model Boosts Vision-Language-Action Reinforcement Learning
RoboticsAgo 6

World Critic Model Boosts Vision-Language-Action Reinforcement Learning

A World Critic Model that jointly learns latent state prediction and value estimation consistently improves vision-language-action RL performance across 149 simulation tasks and 7 real-world manipulation tasks.

Senyu Fei, Xiaopeng Yu, Siyin Wang +3

Dynamic Diffusion Policies That Learn When to Stop Computing
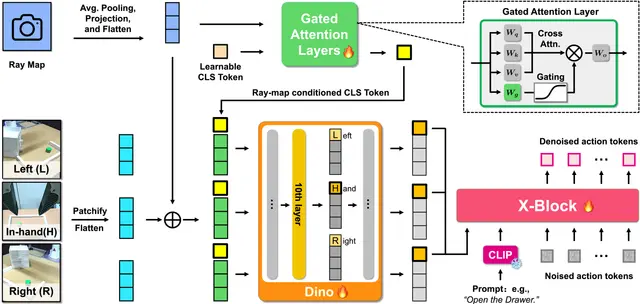
AIAgo 6

Dynamic Diffusion Policies That Learn When to Stop Computing

Rohit Kumar Salla, Manoj Saravanan, Simon Stepputtis

RayViT Keeps Robot Skills Working When Cameras Change Viewpoint
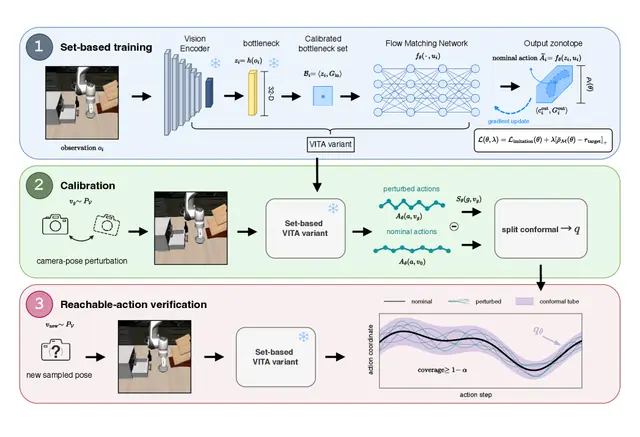
RoboticsAgo 5

RayViT Keeps Robot Skills Working When Cameras Change Viewpoint

Qian Wang, Longrui Chen, Peiran Sun +8

Verifying Visuomotor Policies With Set-Based Training Under Camera Uncertainty
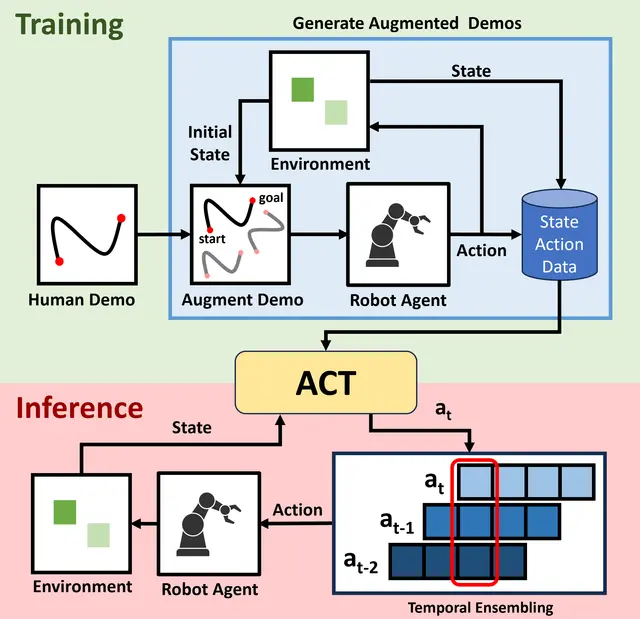
RoboticsAgo 5

Verifying Visuomotor Policies With Set-Based Training Under Camera Uncertainty

This work makes probabilistic reachable-action verification tractable for visuomotor policies by keeping the visual encoder frozen and inserting a calibrated low-dimensional interface.

Yanliang Huang, Zhuocheng Zhang, Peng Xie +5

Why Action Chunking Improves Robot Policies — and How to Beat It
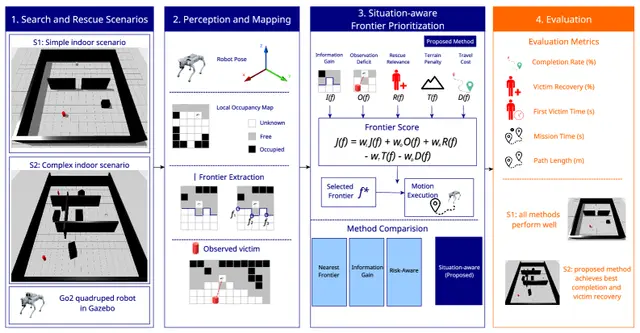
RoboticsAgo 5

Why Action Chunking Improves Robot Policies — and How to Beat It

Action chunking improves robot control through implicit ensembling — and randomized-delay ensembles can match or beat its performance without chunking.

Filippo Lazzati, Kyle Stachowicz, William Chen +3

Situation-Aware Frontier Prioritization for Quadruped Search and Rescue
RoboticsAgo 4

Situation-Aware Frontier Prioritization for Quadruped Search and Rescue

Kevin Farias, Santiago Martin, Barbara Flores +5

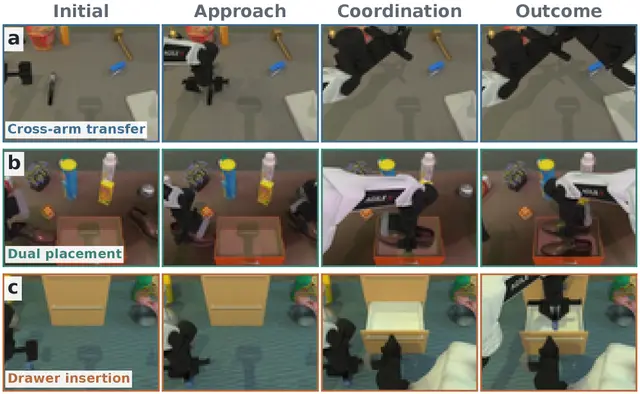
Coordination Contracts for Bimanual Robot Policy Intervention
AIAgo 4

Coordination Contracts for Bimanual Robot Policy Intervention

Shuaijun Liu, Qifu Wen, Shuyang Hao +5

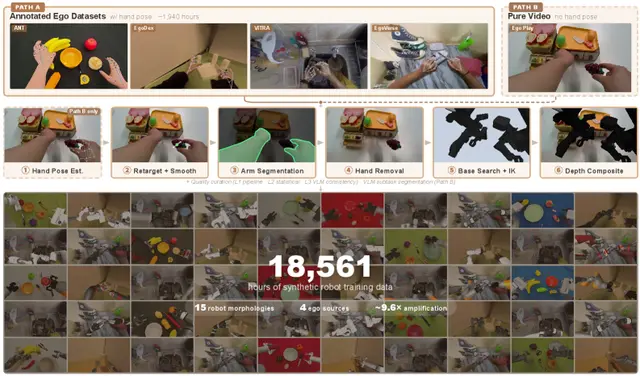
Everyday Human Videos Become 18,500 Hours of Robot Training Data
RoboticsAgo 4

Everyday Human Videos Become 18,500 Hours of Robot Training Data

Ego2Robot converts egocentric human videos into 18,561 hours of robot training data across 15 morphologies, boosting physical robot success by up to 14 points.

Ye Wang, Pei Lin, Xiong-Hui Chen +12

Humanoid Robot Balance: How Object Mass Changes Lifting Stability
HumanoidAgo 3

Humanoid Robot Balance: How Object Mass Changes Lifting Stability

New research quantifies how object mass affects humanoid balance, identifying a critical mass that maximizes stability during lifting tasks.

Hyunjong Song, William Z. Peng, Joo H. Kim

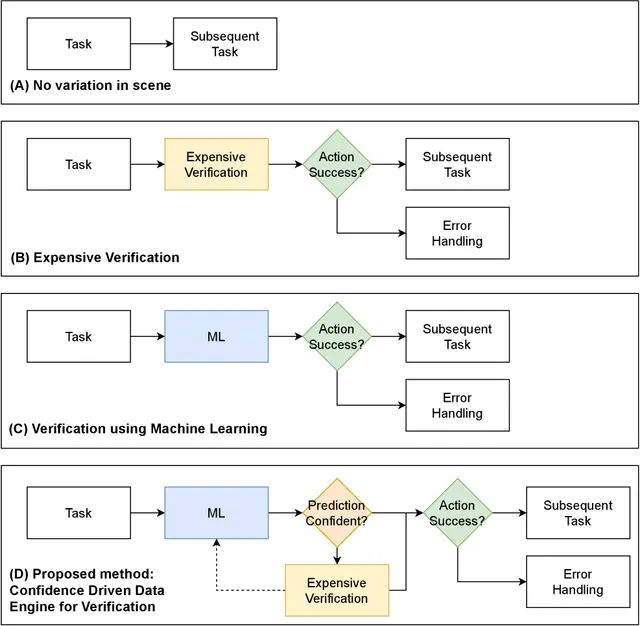
Robot Insertion Quality Control With Self-Supervised Confidence Learning
RoboticsAgo 3

Robot Insertion Quality Control With Self-Supervised Confidence Learning

Zebin Duan, Norbert Krüger, Juan Heredia +2

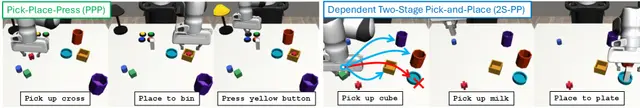
Compositional Generalization in Robot Tasks: When Sparse Data Fails
RoboticsAgo 3

Compositional Generalization in Robot Tasks: When Sparse Data Fails

Yixiao Wang, Cheng-En Wu, Lingfeng Sun +5

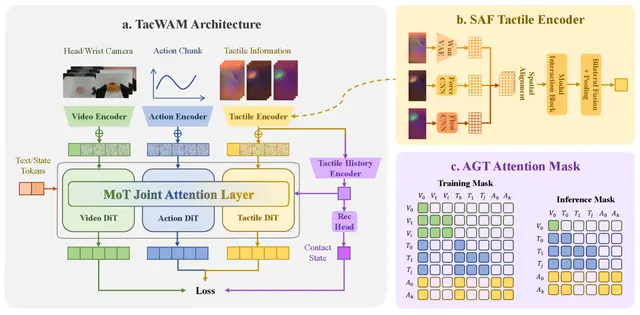
TacWAM: Anchor-Guided World Action Model with Mechanics-Aware Tactile Prediction
RoboticsAgo 2

TacWAM: Anchor-Guided World Action Model with Mechanics-Aware Tactile Prediction

TacWAM extends visual World Action Model training with recent tactile history and future tactile prediction, enabling contact-rich manipulation to benefit from force and deformation supervision.

Lei Jin, Yiding Ma, Xin Zhang +3

AIAgo 2

Quantile Matching Tightens Latent World Models for Robot Planning
Quantile-quantile matching keeps latent world model regularization alive in the tails, improving planning success across four control environments.

Zhoushun Yu, Xiaoyu Hu, Xiangyu Xu

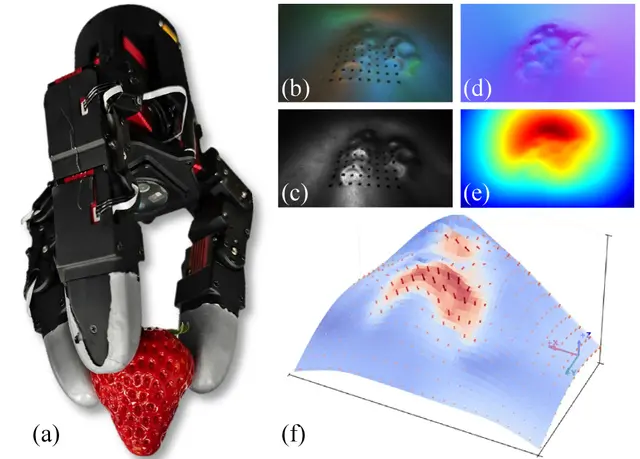
Multispectral Fingertip Sensor Reconstructs 3D Shape and Force within 0.04 mm
RoboticsAgo 2

Multispectral Fingertip Sensor Reconstructs 3D Shape and Force within 0.04 mm

Xiaofan Lu, Kaiji Huang, Jiahui Chen +3