Papers sa Pananaliksik

Mga buod sa payak na Ingles ng pinakabagong pananaliksik sa robotika — mga robot na humanoid, mga robot na may apat na paa, awtomasyong industriyal, at artipisyal na intelihensiya.
499 papers
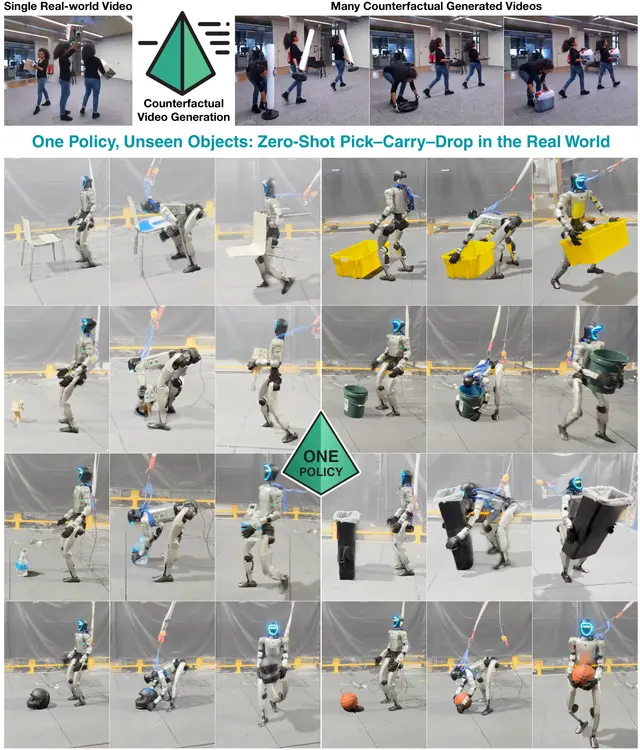
Counterfactual Videos Scale Humanoid Object Handling from Simulation to Reality
HumanoidSet 30

Counterfactual Videos Scale Humanoid Object Handling from Simulation to Reality

How can humanoids learn to interact with the diverse objects encountered in everyday life?

Zihan Wang, Zhen Wu, Pieter Abbeel, Rocky Duan +5

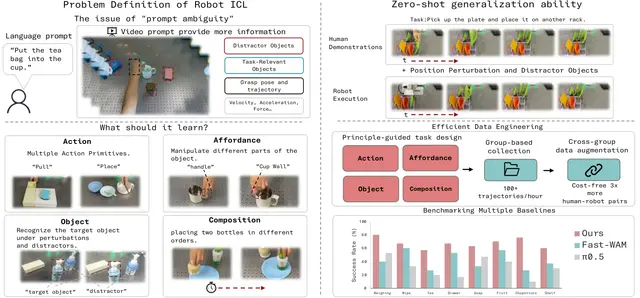
Robots Learn New Manipulation Skills From Videos, Not Teleoperation
RoboticsSet 30

Robots Learn New Manipulation Skills From Videos, Not Teleoperation

A visual-prompt learning recipe trains robots to interpret human manipulation videos while ignoring irrelevant changes in objects, people, and scene conditions.

Minxing Li, Minghao Han, Weizhi Zhao +10

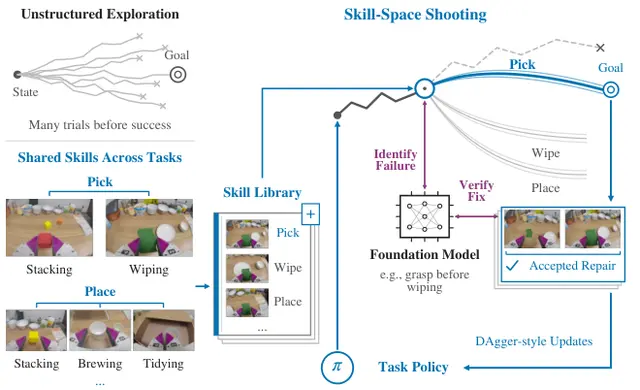
How Robots Improve Policies by Reusing Skills to Repair Their Failures
AISet 30

How Robots Improve Policies by Reusing Skills to Repair Their Failures

Scaling robots to a wider range of real-world tasks requires a way for their policies to keep improving after deployment, without relying on continual human guidance.

Zihang Rui, Renhao Wang, Haoxu Huang +1

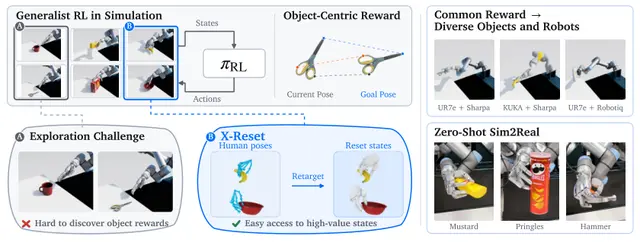
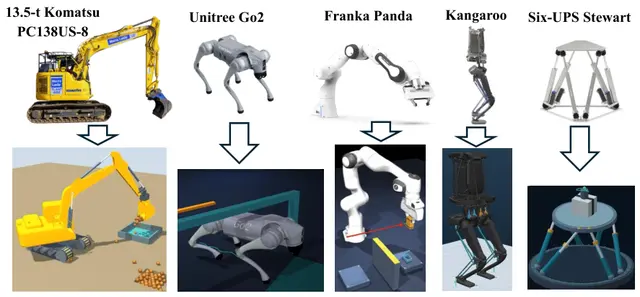
Human Demonstrations Help Robot Hands Learn Object Manipulation
AISet 29

Human Demonstrations Help Robot Hands Learn Object Manipulation

Prithwish Dan, Chenyang Ma, Wei Zhan

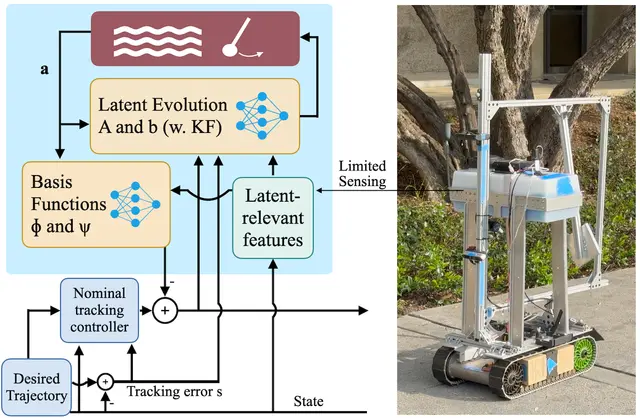
RoboCompiler: Compiling Closed-Chain Robots for Consistent Control and Simulation
RoboticsSet 29

RoboCompiler: Compiling Closed-Chain Robots for Consistent Control and Simulation
Mehdi Heydari Shahna, Joongheon Kim, Jouni Mattila

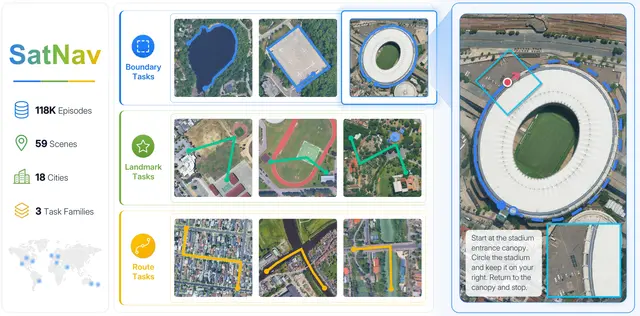
How Robots Learn to Model Hidden Disturbances for Better Robot Control
AISet 29

How Robots Learn to Model Hidden Disturbances for Better Robot Control

A learned, contractive disturbance model gives adaptive controllers a way to predict hidden forces that change over time.

Min Kim, José Leonardo Brenes, Fred Hadaegh +1

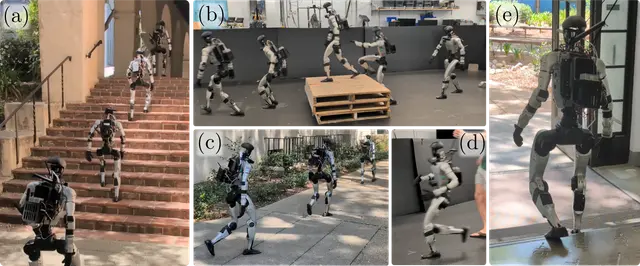
SatNav Benchmarks Long-Horizon UAV Navigation from Satellite Images
dronesSet 28

SatNav Benchmarks Long-Horizon UAV Navigation from Satellite Images

SatNav defines three task families—Boundary, Landmark, and Route—to evaluate complementary aspects of memory-intensive, long-horizon navigation.

Jiajun Jiang, Chunliang Hua, Zichun Chen +4

Humanoid Robots Learn to Walk, Run, Jump, and Read Rough Terrain
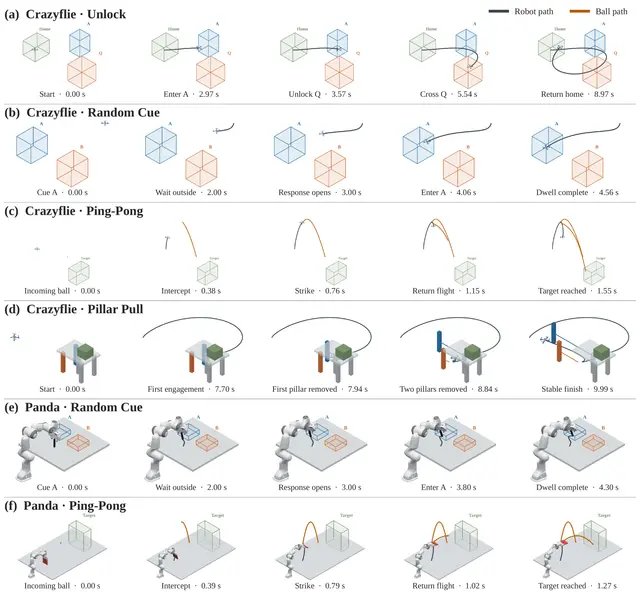
HumanoidSet 28

Humanoid Robots Learn to Walk, Run, Jump, and Read Rough Terrain

Zachary Olkin, William D. Compton, Aaron D. Ames

STL-Guided Robot Policy Learning from Sparse Success Signals for Control
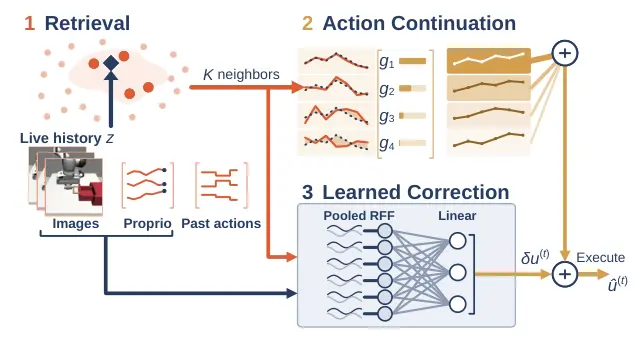
RoboticsSet 28

STL-Guided Robot Policy Learning from Sparse Success Signals for Control

Hongrui Zheng, Cristian Ioan Vasile, Antonio Loquercio +1

Training-Free Robot Behavior Cloning Through Retrieval and Action Continuation
RoboticsSet 27

Training-Free Robot Behavior Cloning Through Retrieval and Action Continuation

Large datasets and pretrained representations have driven advances in robot imitation learning.

Maximilian Adang, Timothy Chen, Lars Osterberg +2

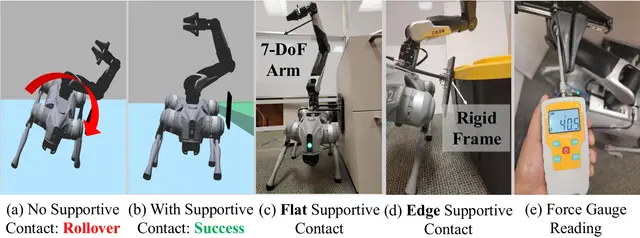
Choosing Environmental Contacts for Legged Loco-Manipulation
RoboticsSet 27

Choosing Environmental Contacts for Legged Loco-Manipulation

To address these challenges, we develop Capability-Tradeoff Contact Selection (CTCS) for task-dependent environmental contact selection.

Al Jaber Mahmud, Shuai Li, Xuan Wang

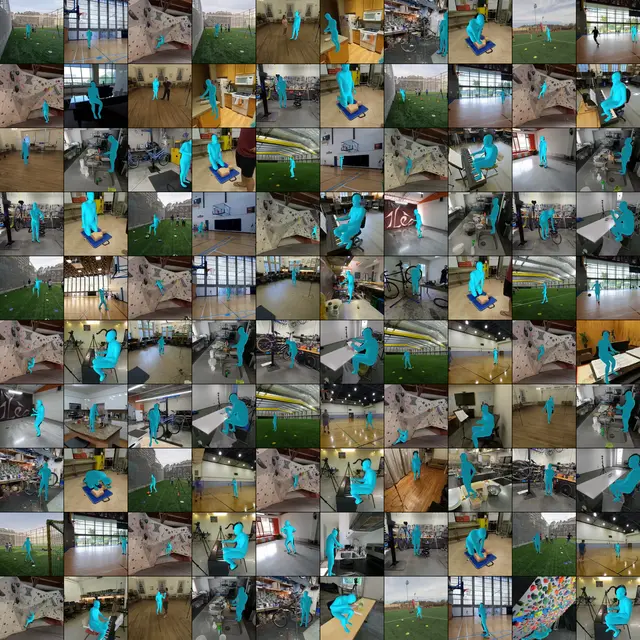
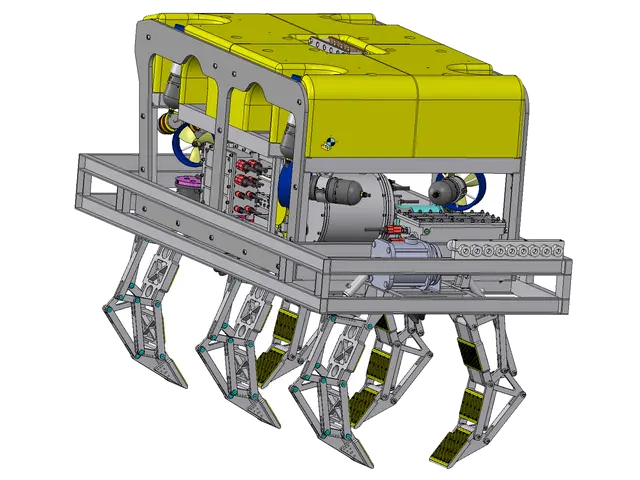
Ego-Exo4D Human Meshes Dataset for 4D Motion Reconstruction from Multi-View Video
RoboticsSet 27

Ego-Exo4D Human Meshes Dataset for 4D Motion Reconstruction from Multi-View Video

Abhiram Maddukuri, Georgios Pavlakos

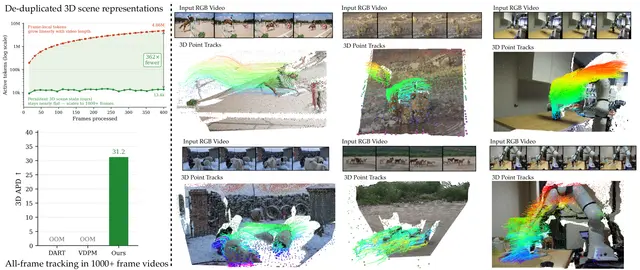
Object-Centric World Models Help Underwater ROVs Plan Safer Salvage
AISet 26

Object-Centric World Models Help Underwater ROVs Plan Safer Salvage

Yuncong Yang, Jinlong Li, Yulong Xue +4

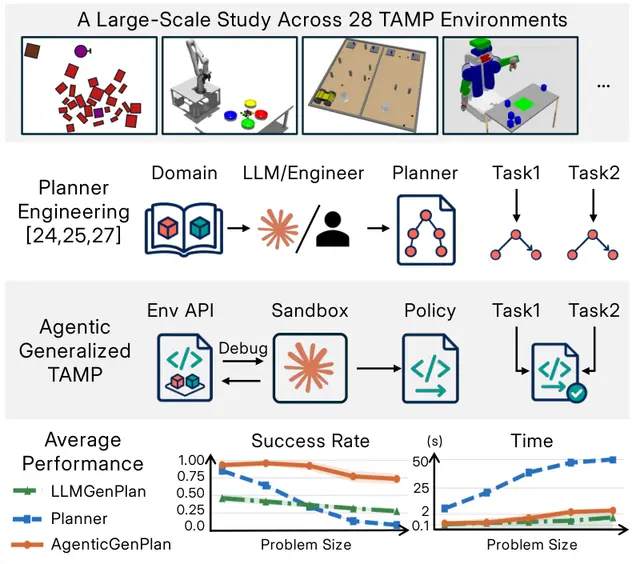
Dense 3D Point Tracking with Sliding-Window De-Duplication
AISet 26

Dense 3D Point Tracking with Sliding-Window De-Duplication

At the end of each window, we voxelize the feature cloud based on predicted target positions.

Ayush Jain, Sreeharsha Paruchuri, Ishita Gupta +5

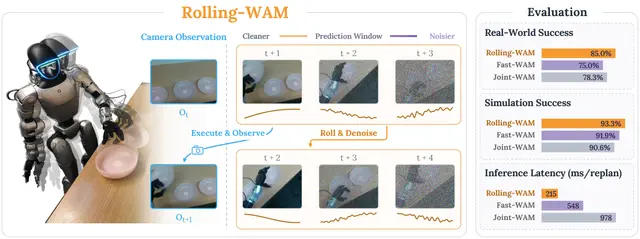
How Coding Agents Solve Generalized Robot Task and Motion Planning
AISet 26

How Coding Agents Solve Generalized Robot Task and Motion Planning

Each environment is represented by an MDP and a task description.

Matteo Merler, Bowen Li, Josh Roy +4

Rolling World Action Models for Faster Closed-Loop Robot Manipulation
AISet 25

Rolling World Action Models for Faster Closed-Loop Robot Manipulation

Yinghua Zhou, Junjie Ye, Yiqi Zhao +8

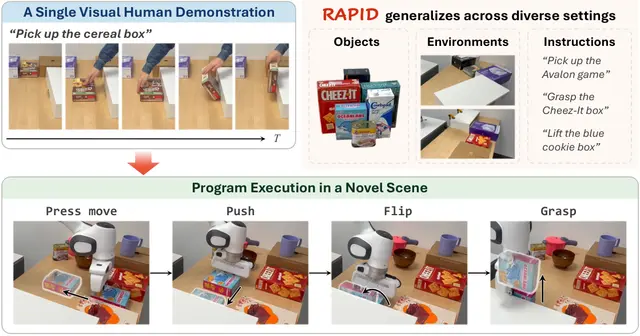
RAPID Enables Robot Manipulation Programs to Generalize Across Diverse New Scenes
AISet 25

RAPID Enables Robot Manipulation Programs to Generalize Across Diverse New Scenes

Yuyao Liu, Jiayuan Mao, David Hsu +2

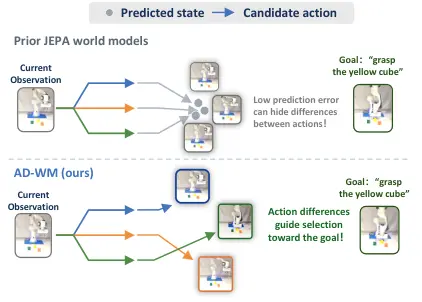
Action-Discriminative World Models Improve Counterfactual Robot Control
AISet 25

Action-Discriminative World Models Improve Counterfactual Robot Control

The training and planning pipeline of AD-WM uses residual latent prediction and action-recovery objectives to shape action-discriminative transitions.

Jiabin Qiu, Zixuan Chen, Hongye Cao +3

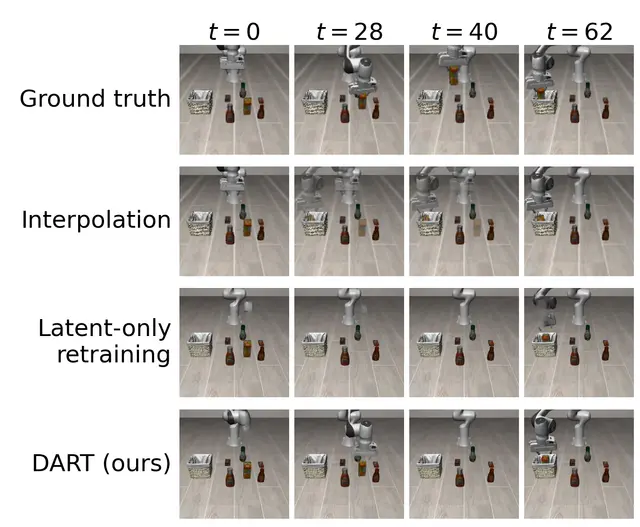
How DART Restores Lost Motion in Frozen World Models for Robots
AISet 24

How DART Restores Lost Motion in Frozen World Models for Robots

DART diagnoses why frozen latent-flow world models lose motion and restores dynamic predictions without unfreezing their visual representation.

Xiwen Chen, Rigaudiere Z. Li, Zhiruo Zhou +2

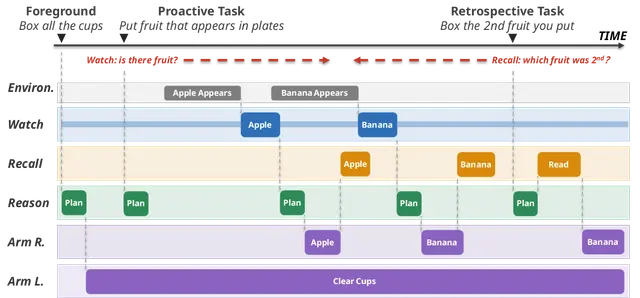
Always-On Robots Watch, Recall, and Act Across Concurrent Dual-Arm Streams
RoboticsSet 24

Always-On Robots Watch, Recall, and Act Across Concurrent Dual-Arm Streams

Ding Yi, Peiwen Sun, Chenchu Rong +4