Papers sa Pananaliksik

Mga buod sa payak na Ingles ng pinakabagong pananaliksik sa robotika — mga robot na humanoid, mga robot na may apat na paa, awtomasyong industriyal, at artipisyal na intelihensiya.
499 papers
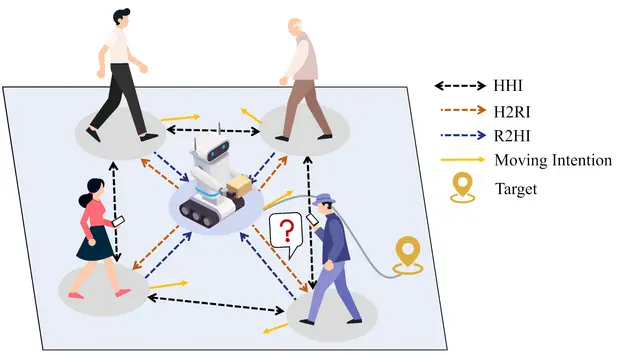
A Gated Transformer Helps Robots Navigate Dense, Uncertain Crowds
RoboticsSet 10

A Gated Transformer Helps Robots Navigate Dense, Uncertain Crowds

H2INT helps robots navigate uncertain crowds using relative pedestrian positions, gated Transformers, and recurrent memory.

Ao Shen, Kaixi Chen, Shiwei Liu, Fang Deng +1

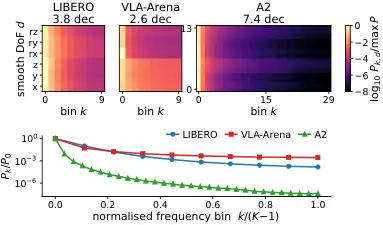
Frequency-Aware Flow Matching Helps Robots Plan Smoother Actions
RoboticsSet 10

Frequency-Aware Flow Matching Helps Robots Plan Smoother Actions

FreqFM uses action frequencies to help vision-language robots generate smoother, better-controlled trajectories.

Haochen Niu, Shengye Dong, Hao Liu +2

Multi-Agent Reinforcement Learning for Autonomous Wildfire UAV Exploration
dronesSet 10

Multi-Agent Reinforcement Learning for Autonomous Wildfire UAV Exploration

Drones have increasingly been deployed in wildfire response efforts, but reliance on human operators limits operational uptime and scalability.

Caden Chandra, Jerry Ng

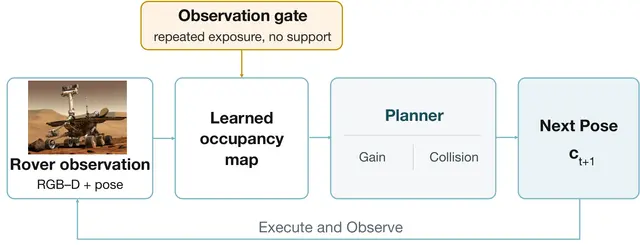
Rethinking Learned Occupancy for Safer Autonomous Active Mapping with Observation-Gated Filtering
RoboticsSet 9

Rethinking Learned Occupancy for Safer Autonomous Active Mapping with Observation-Gated Filtering
Jiahui Zhang, Bonian Han, Gongbo Liang +1

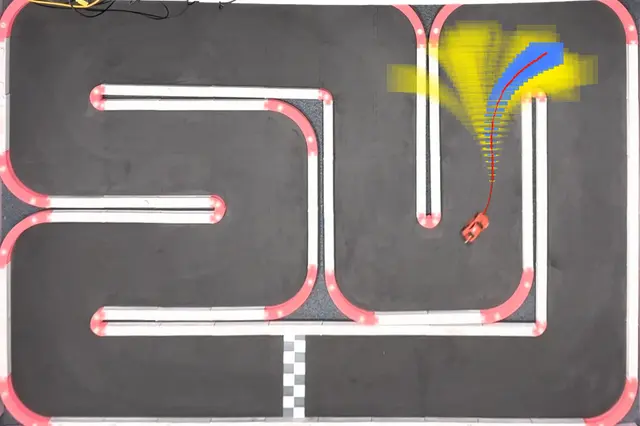
Online Reachability Makes Sampling-Based Motion Planning Safer
RoboticsSet 9

Online Reachability Makes Sampling-Based Motion Planning Safer

Brendan Gould, Zhiyuan Zhang, Panagiotis Tsiotras +1

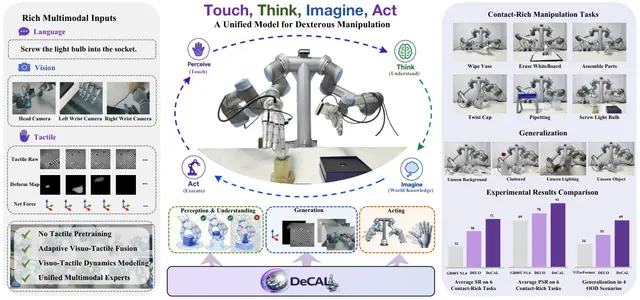
Contact-Aware Dexterous Robot Learning with Vision, Language, and Tactile Imagination
AISet 9

Contact-Aware Dexterous Robot Learning with Vision, Language, and Tactile Imagination

DeCAL is a physically grounded dexterous vision-language-action model that enables effective utilization of tactile signals for contact-rich manipulation.

Yankai Fu, Ning Chen, Junkai Zhao +5

AISet 8

RoboSPA Tests VLA Models on Spatial and Long-Horizon Tasks

RoboSPA benchmarks whether vision-language-action models can handle spatial ambiguity, long procedures, and reliable robot manipulation.

Zhenxuan Fan, Bo Zhang, Yutong Lin +9

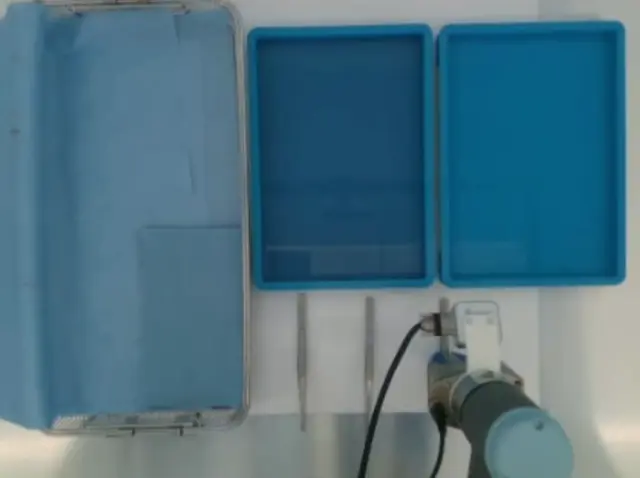
Why Behavior Trees Need Help to Adapt in Real-World Robots
RoboticsSet 8

Why Behavior Trees Need Help to Adapt in Real-World Robots

Mehran Rostamnia, Gianluca Filippone, Ricardo Caldas +1

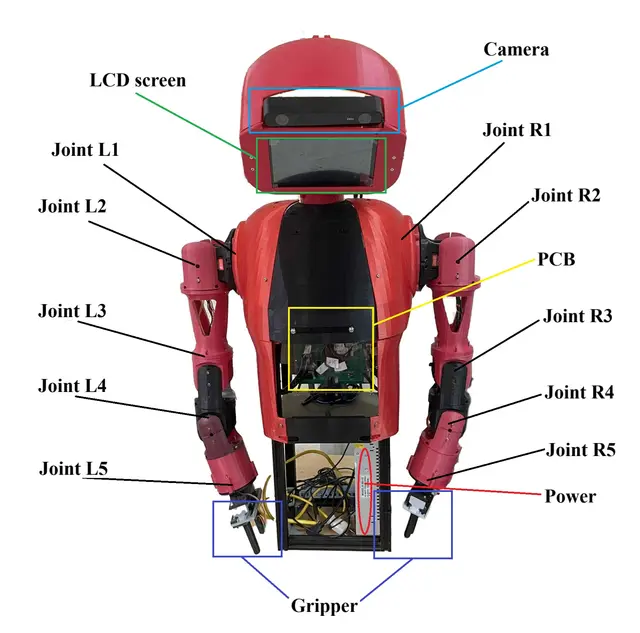
Humanoid Robot Prototype Unifies Vision, Gestures, Voice, And Expressive Control
HumanoidSet 8

Humanoid Robot Prototype Unifies Vision, Gestures, Voice, And Expressive Control

Thang Tran Viet, Thanh Nguyen Canh, Huy Uong Gia +4

Task Graphs Help Robots Execute Long-Horizon Manipulation Tasks
RoboticsSet 7

Task Graphs Help Robots Execute Long-Horizon Manipulation Tasks

A neuro-symbolic robot system combines task graphs, event memory, camera verification, and VLA control for long manipulation tasks.

Vivek Chavan, Yahuan Shi, Oliver Heimann +2

Cross-View Geometry Helps Robots Build More Reliable Surround-View Depth Maps
RoboticsSet 7

Cross-View Geometry Helps Robots Build More Reliable Surround-View Depth Maps

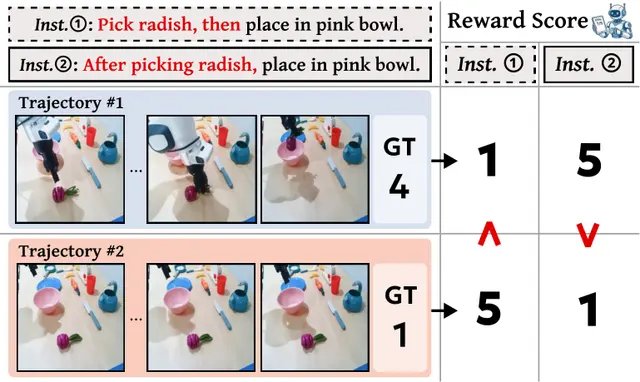
CrossDepth uses geometry-constrained attention and camera-ray embeddings to estimate consistent surround-view depth without ground-truth labels.

Samer Abualhanud, Max Mehltretter

Testing Paraphrase Robustness in Vision-Language Robot Reward Models
RoboticsSet 7

Testing Paraphrase Robustness in Vision-Language Robot Reward Models

Wonje Jeung, Sangyeon Yoon, Hyesoo Hong +6

Training-Free 3D Scene Graph Reasoning for Multimodal Language Models
AISet 6

Training-Free 3D Scene Graph Reasoning for Multimodal Language Models

Junqing Du, Fernando Ropero, Erkin Turkoz +2

Topological Graphs Help Robots Learn Closed-Loop Vision-Language Navigation
RoboticsSet 6

Topological Graphs Help Robots Learn Closed-Loop Vision-Language Navigation

Topological graphs reduce robot navigation to a few meaningful choices, making closed-loop reinforcement learning more efficient.

Shuhao Ye, Sitong Mao, Yuxiang Cui +7

Unified Robot Learning Through Representations, Vision-Language-Action, and World Models
RoboticsSet 6

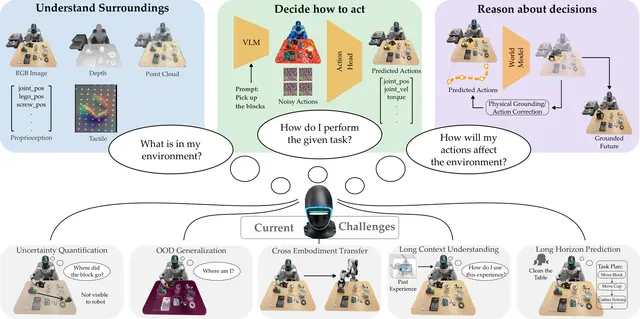
Unified Robot Learning Through Representations, Vision-Language-Action, and World Models
While state-based representations offer interpretability and sample efficiency, their reliance on accurate sensing limits real-world deployment.

Shaunak A. Mehta, Ananya Hazarika, Haochen Zhang +5

How AI Predicts and Untangles Cascading Network Failures Before They Spread
AISet 5

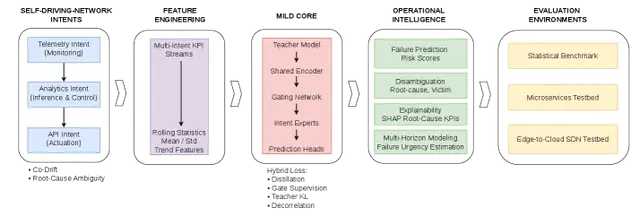
How AI Predicts and Untangles Cascading Network Failures Before They Spread

Md. Kamrul Hossain, Walid Aljoby

Smartphone Images Map Weld Seams in 3D for Robotic Finishing Work
RoboticsSet 5

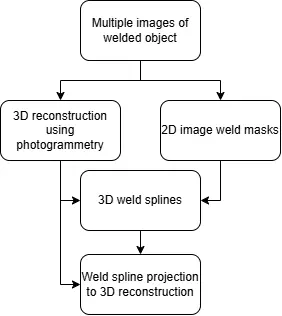
Smartphone Images Map Weld Seams in 3D for Robotic Finishing Work

Augustin Raju, Abilash Madavath, Chandra Yuvesh Aubeeluck +3

Efficient Active Reward Learning from Preferences with Subspace Inference
AISet 5

Efficient Active Reward Learning from Preferences with Subspace Inference

In recent years, reinforcement learning from human feedback (RLHF) has become the dominant technique for aligning decision-making agents with human intention…

Yutai Zhou, Erdem Bıyık

LightNav-0 Uses Spatial Intelligence for Generalist Robot Navigation
AISet 4

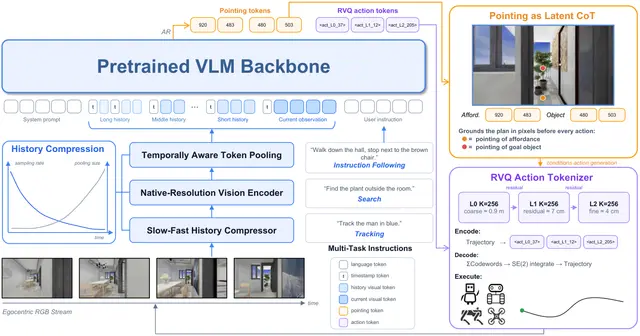
LightNav-0 Uses Spatial Intelligence for Generalist Robot Navigation

Building on this interface, we construct an end-to-end system using only the compact VLM backbone and token-based outputs.

Shaoan Wang, Aocheng Luo, Fei Huang +17

Autonomous Farm Robots Solve Sharp Corners With Reversing Turns
RoboticsSet 4

Autonomous Farm Robots Solve Sharp Corners With Reversing Turns

Riikka Soitinaho, Timo Oksanen