Papers sa Pananaliksik

Mga buod sa payak na Ingles ng pinakabagong pananaliksik sa robotika — mga robot na humanoid, mga robot na may apat na paa, awtomasyong industriyal, at artipisyal na intelihensiya.
499 papers
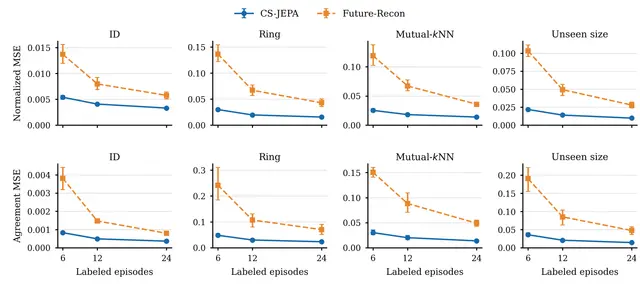
One Shared Future Lets Robot Swarms Learn with Far Fewer Labels
RoboticsAgo 1

One Shared Future Lets Robot Swarms Learn with Far Fewer Labels

Decentralized JEPA lets robot swarms learn collective state from one shared future target, cutting label needs and winning under distribution shift.

Alan-Barsag Gazzaev, Alexey Garvilov, Sergey Muravyov

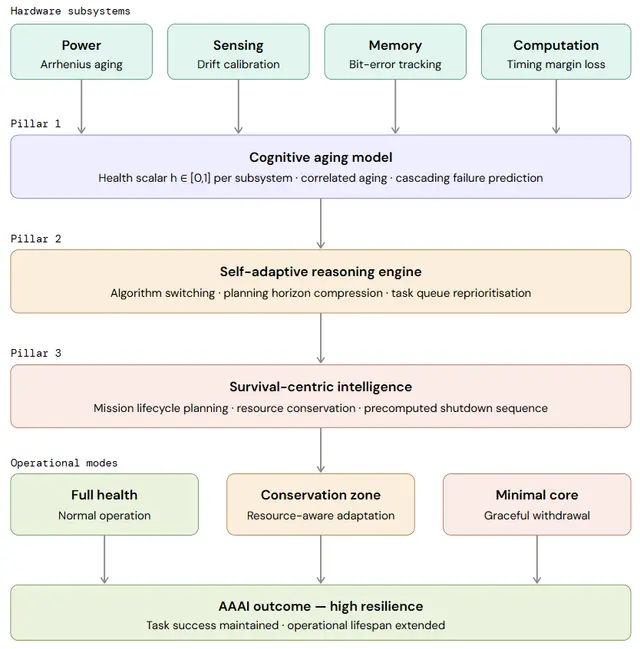
When Machines Know They Are Aging: Hardware-Aware AI Framework
AIAgo 1

When Machines Know They Are Aging: Hardware-Aware AI Framework

Consider an autonomous underwater vehicle that has spent two years inspecting subsea pipelines. Its battery retains only a fraction of its original capacity,…

Cheng Siong Chin, Jianhua Zhang, Mohan Venkateshkumar

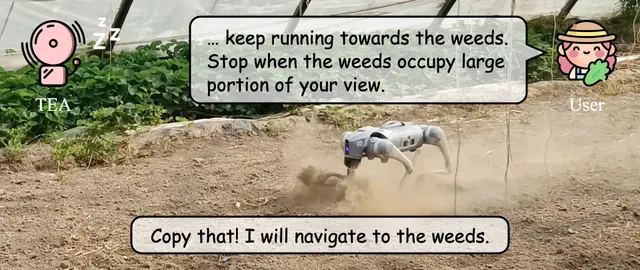
Traversability Alarms Help Agricultural Robots Navigate by Language
RoboticsAgo 1

Traversability Alarms Help Agricultural Robots Navigate by Language

A traversability alarm module raised agricultural VLN robot success rate from 47% to 54% across 1,560 farm and forest navigation episodes.

Xiaobei Zhao, Xingqi Lyu, Xin Chen +1

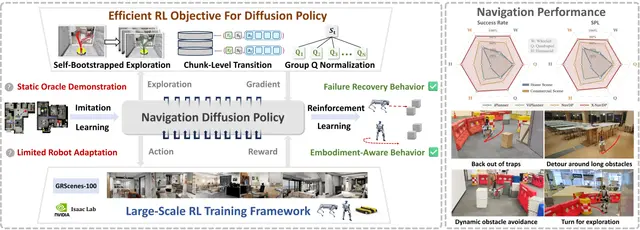
Navigation AI That Adapts to New Robot Bodies and Recovery Behaviors
RoboticsHul 31

Navigation AI That Adapts to New Robot Bodies and Recovery Behaviors

Tianyu Yang, Yiming Zeng, Wenzhe Cai +5

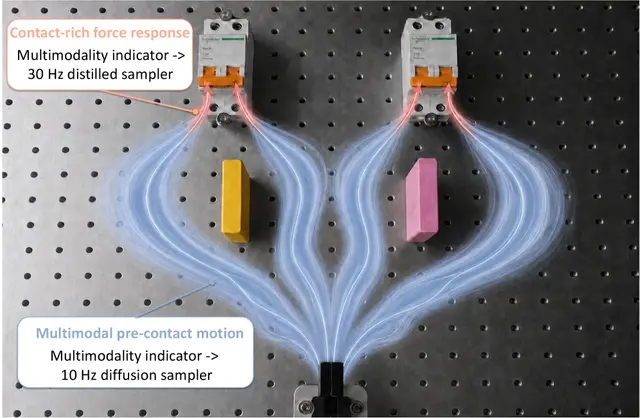
Frequency-Adaptive Diffusion Policy Lifts Contact-Rich Manipulation Success
RoboticsHul 31

Frequency-Adaptive Diffusion Policy Lifts Contact-Rich Manipulation Success

Lifeng Zhuo, Wendi Chen, Han Xue +4

Perception-Aware Safety Control Teaches Humanoid Robots to Dodge
HumanoidHul 31

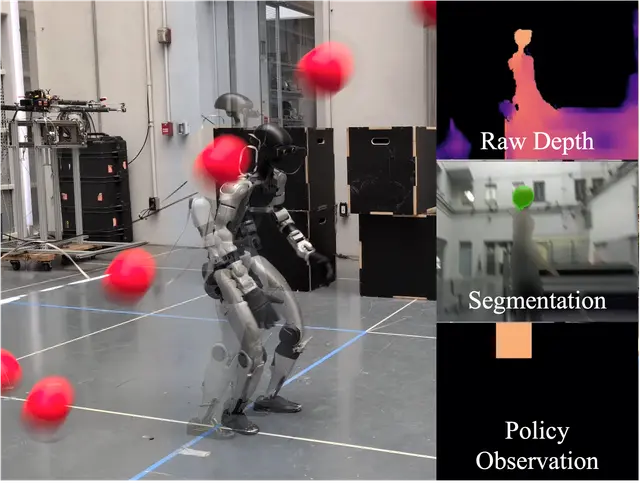
Perception-Aware Safety Control Teaches Humanoid Robots to Dodge

Caltech's PAC-MAN framework trains humanoids to dodge balls with perception-aware CBF-RL, deploying zero-shot on a Unitree G1 using onboard depth only.

Lizhi Yang, Junheng Li, Aaron D. Ames

Can Vision-Language Models Act Through a Full Human Body?
RoboticsHul 30

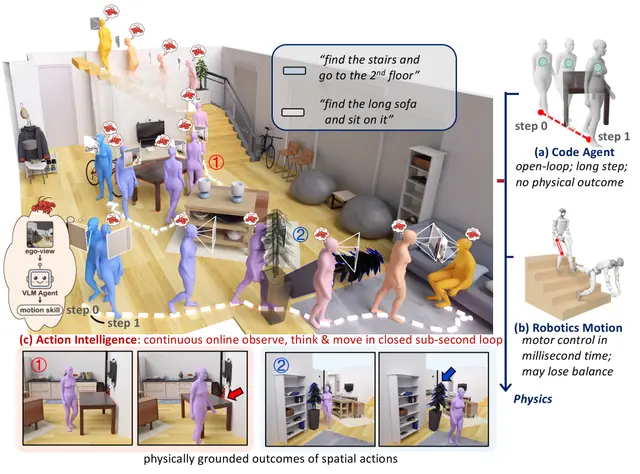
Can Vision-Language Models Act Through a Full Human Body?

Vision-language models can describe scenes and answer questions, but can they actually control a physical body to perform real-world tasks? HumanCLAW evaluat…

Siyao Li, Jiawei Gu, Shuai Liu +15

VidMap Bridges SLAM and SfM for Accurate 3D from Video
RoboticsHul 30

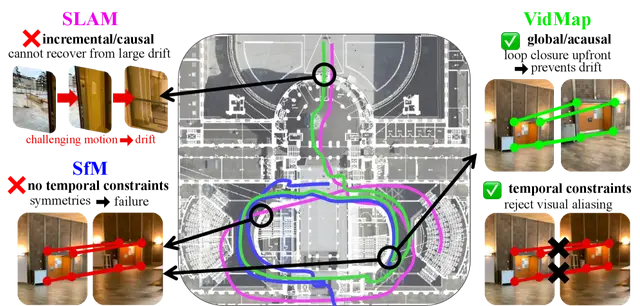
VidMap Bridges SLAM and SfM for Accurate 3D from Video

Zador Pataki, Paul-Edouard Sarlin, Marc Pollefeys

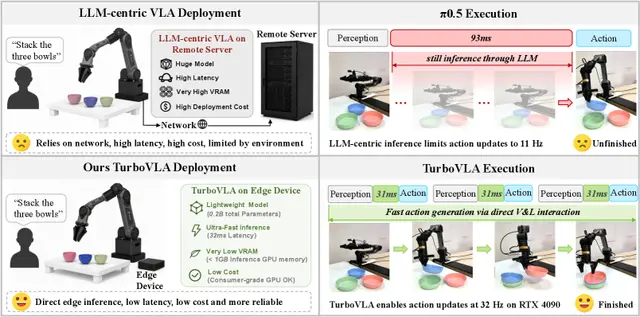
TurboVLA Runs Vision-Language-Action Robot Control at 32 Hz on a Single RTX 4090
RoboticsHul 30

TurboVLA Runs Vision-Language-Action Robot Control at 32 Hz on a Single RTX 4090

Hengyi Xie, Chenfei Yao, Xianjin Wu +7

Audio-Visual Imitation Learning for Safer Robot Manipulation with Spatial Sound
RoboticsHul 29

Audio-Visual Imitation Learning for Safer Robot Manipulation with Spatial Sound

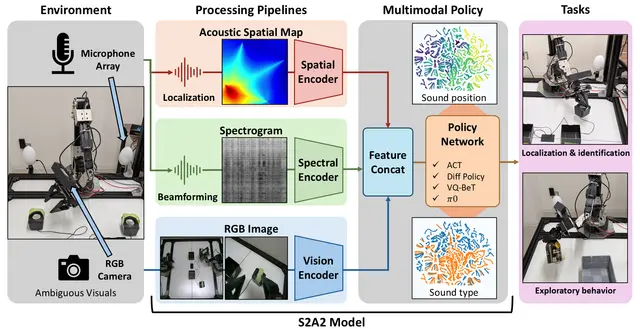
The S2A2 framework consists of an environment setup, the S2A2 model, and the acoustic-aware manipulation tasks. The S2A2 model consists of processing pipelin…

Kaneyoshi Hiratsuka, Benjamin Yen, Ryosuke Kojima

Reactive Real-Time Flow Policies Achieve Fast Robot Reflexes
AIHul 29

Reactive Real-Time Flow Policies Achieve Fast Robot Reflexes

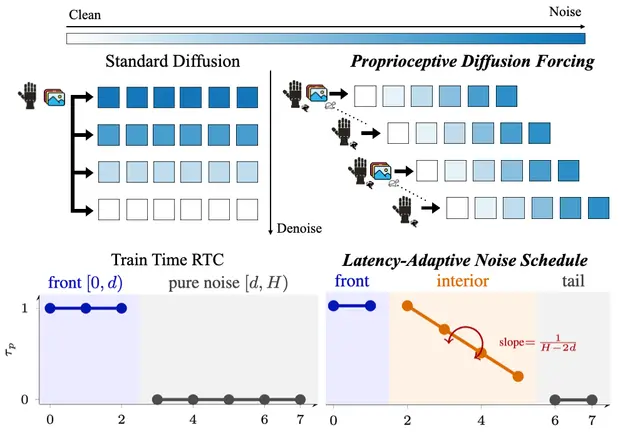
Deploying reactive visuomotor policies on physical robots requires real-time inference, but modern architectures incur significant latency overheads from pro…

Sungjae Park, Shubham Tulsiani

New AI Method Lets Robots Learn World Models Without Exhaustive Search
RoboticsHul 29

New AI Method Lets Robots Learn World Models Without Exhaustive Search

Junhan Sun, Hao Zhao, Guofeng Zhang

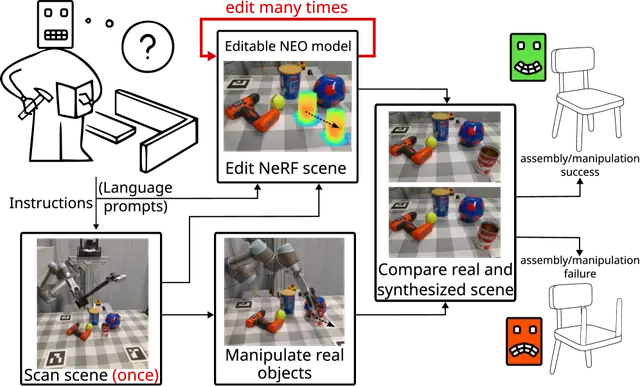
NeRF Scenes That Never Need Retraining — Edit Objects Without Starting Over
RoboticsHul 28

NeRF Scenes That Never Need Retraining — Edit Objects Without Starting Over

Mikołaj Zieliński, David Hall, Dominik Belter +1

Handheld Device Gives Surgeons Joystick Control Over Steerable Guidewires
RoboticsHul 28

Handheld Device Gives Surgeons Joystick Control Over Steerable Guidewires

A handheld joystick-controlled device lets surgeons steer tendon-driven guidewires with robotic precision while keeping manual control.

Saima Chavenet, Timothy A. Brumfiel, Revanth Konda +1

Data Pyramid for Embodied Manipulation
RoboticsHul 28

Data Pyramid for Embodied Manipulation

A unified framework categorizing manipulation data from real-robot, human demonstration, and simulation sources, examining pipelines and trade-offs.

Yifan Ye, Yankai Fu, Yaoxu Lv +26

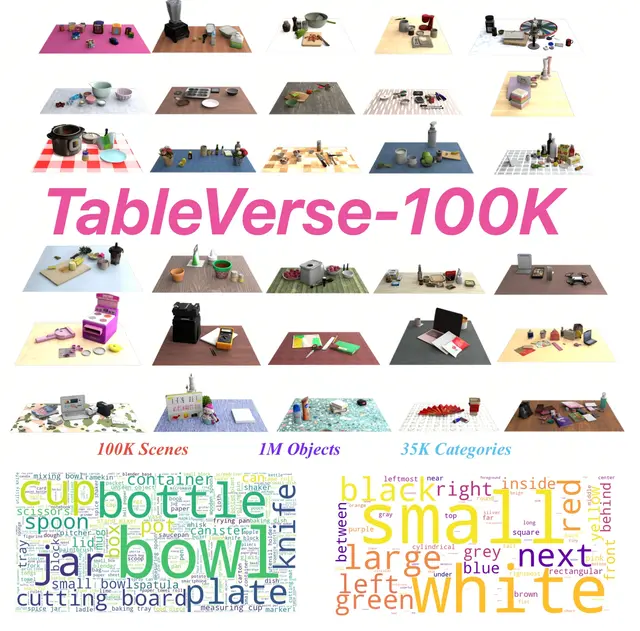
TableVerse Turns Real-World Images Into Realistic Robot Training Simulations
RoboticsHul 27

TableVerse Turns Real-World Images Into Realistic Robot Training Simulations

Boyuan Wang, Yue Zhang, Xutao Xue +2

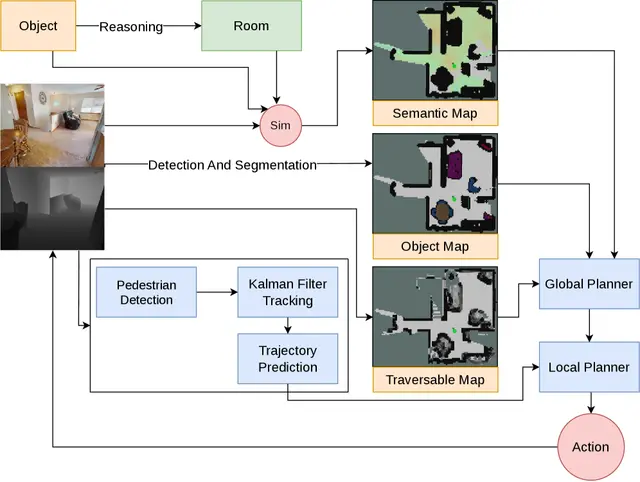
ZONDA: Zero-Shot Navigation with Dynamic Avoidance on Multiple Floors
RoboticsHul 27

ZONDA: Zero-Shot Navigation with Dynamic Avoidance on Multiple Floors

Shaomin Liang, Xuanhong Liao, Shiyao Zhang

Real-Time Nash Equilibrium Solver for Mixed-Traffic Autonomous Vehicles
RoboticsHul 27

Real-Time Nash Equilibrium Solver for Mixed-Traffic Autonomous Vehicles

A new decision-making framework treats autonomous driving as a Generalized Nash Equilibrium Problem, explicitly modeling the back-and-forth between an AV and…

Nouhed Naidja, Mohamed-Cherif Rahal, Steve Pechberti +3

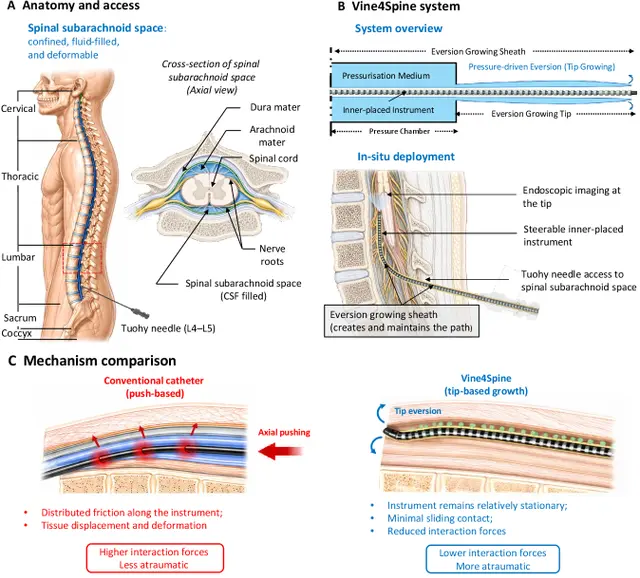
Eversion-Based Robots Enable Safe Navigation Inside the Spinal Canal
RoboticsHul 26

Eversion-Based Robots Enable Safe Navigation Inside the Spinal Canal

Unlike conventional push-based catheters, Vine4Spine advances through distal eversion of a thin-walled, compliant sheath. Growth occurs exclusively at the ti…

Zicong Wu, Panagiotis Kalozoumis, S. M. Hadi Sadati +8

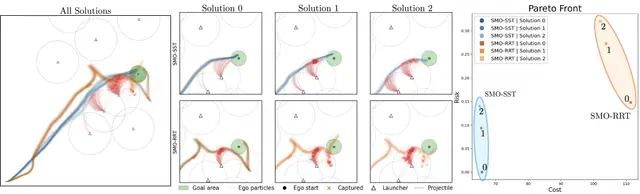
Stochastic Multi-Objective Kinodynamic Planning Defeats Adversarial Robots
RoboticsHul 26

Stochastic Multi-Objective Kinodynamic Planning Defeats Adversarial Robots

Thomas Marshall Vielmetti, Daniel Cherenson, Dimitra Panagou