Papers sa Pananaliksik

Mga buod sa payak na Ingles ng pinakabagong pananaliksik sa robotika — mga robot na humanoid, mga robot na may apat na paa, awtomasyong industriyal, at artipisyal na intelihensiya.
499 papers
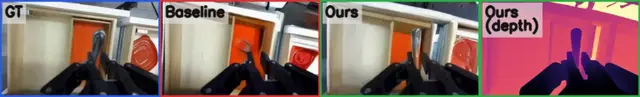
DepthWorld Builds Geometrically Consistent 3D World Models for Robot Manipulation
AIOkt 7

DepthWorld Builds Geometrically Consistent 3D World Models for Robot Manipulation

Current video world models miss geometric structure entirely.

Jai Bardhan, Josef Sivic, Vladimir Petrik

Online Filtered Q-Gradients Speed Up Robot Flow Policy Training by 10x
AIOkt 7

Online Filtered Q-Gradients Speed Up Robot Flow Policy Training by 10x

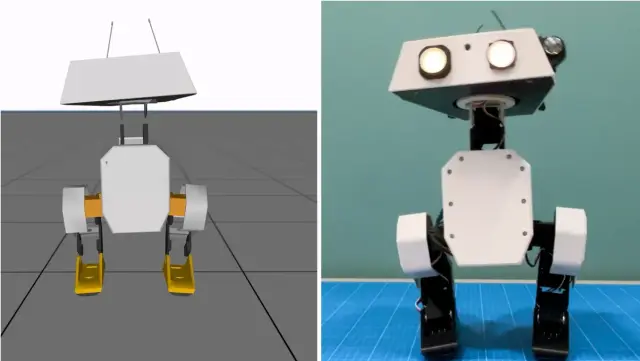
QF3 uses filtered critic gradients to train flow-based robot policies, reporting zero-shot humanoid hardware transfer and 10× faster wall-clock training than FPO++.

Chung Min Kim, Brent Yi, David McAllister +7

Transferable Adversarial Patches Disrupt World Action Models in Simulated Robot Tasks
AIOkt 6

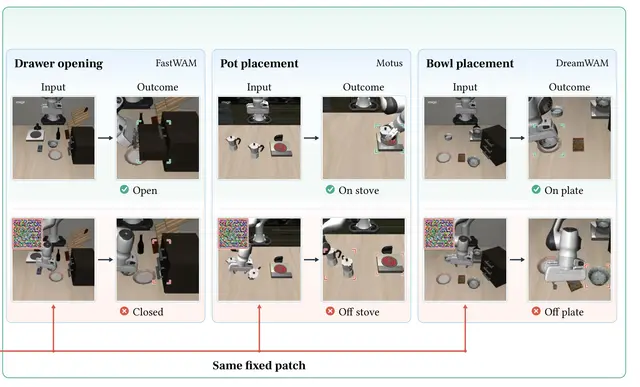
Transferable Adversarial Patches Disrupt World Action Models in Simulated Robot Tasks

We consider an attacker who aims to reduce the task success rate of a WAM-controlled robot by modifying a small region of its visual input.

Xuanyu Lu, Fengqing Jiang, Kaiyuan Zheng +8

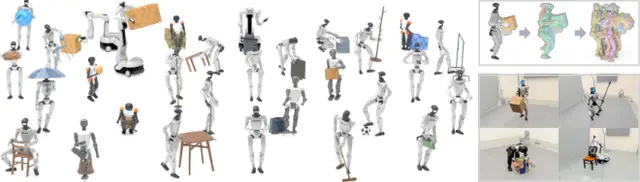
Recursive Video In-Context Learning Helps Robots Handle Long-Horizon Tasks
AIOkt 6

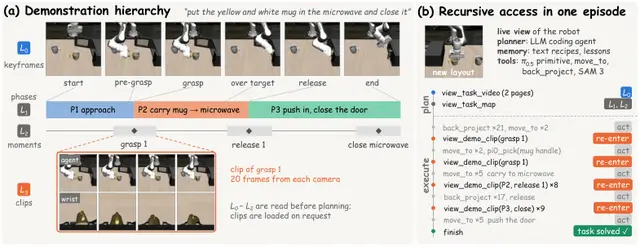
Recursive Video In-Context Learning Helps Robots Handle Long-Horizon Tasks

Wenrui Bao, Xinxin Liu, Bingxin Xu +1

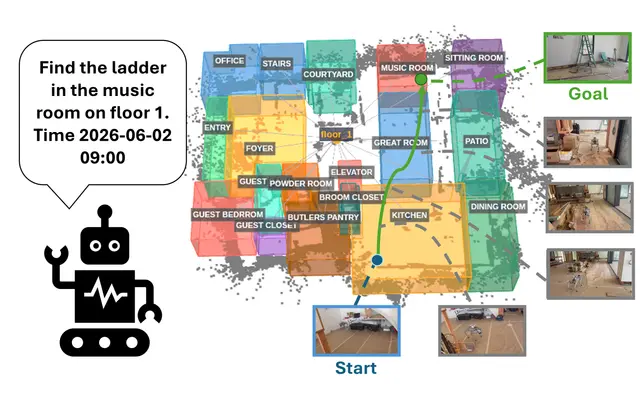
How Humanoid Robots Grow Whole-Body Skills From Their Own Motion Data
HumanoidOkt 6

How Humanoid Robots Grow Whole-Body Skills From Their Own Motion Data

Yucheng Zhang, Sirui Xu, Jinhong Li +8

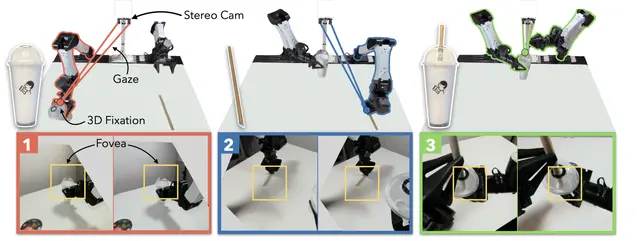
How Robots Navigate Active Sites as Work Zones and Hazards Change
RoboticsOkt 5

How Robots Navigate Active Sites as Work Zones and Hazards Change

CORNAV combines construction plans, work schedules, site perception, and safety rules to route robots around changing hazards.

Parastoo Ali Pour, Deepak Prakash Kumar, Tommy Zhou +2

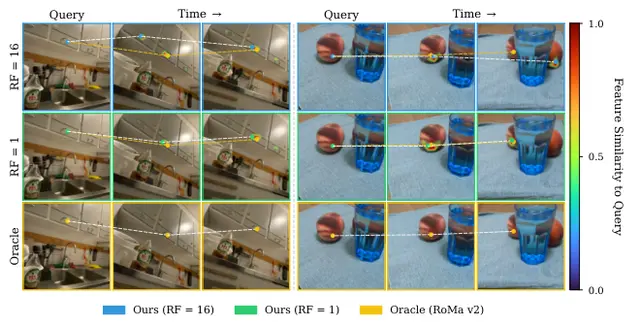
How Active Gaze Helps Robots Manipulate Precisely Without Wrist-Mounted Cameras
AIOkt 5

How Active Gaze Helps Robots Manipulate Precisely Without Wrist-Mounted Cameras

EyeRobot 2.0 is a robot learning framework that introduces Active Visual Fixation (AVF).

Kush Hari, Justin Kerr, Nidhya Shivakumar +7

Geometric Learning from Novel Views with Lean Decoders and Strong Encoders
AIOkt 5

Geometric Learning from Novel Views with Lean Decoders and Strong Encoders

Keerthi Kaashyap, Dennis Anthony, Akshay Krishnan +5

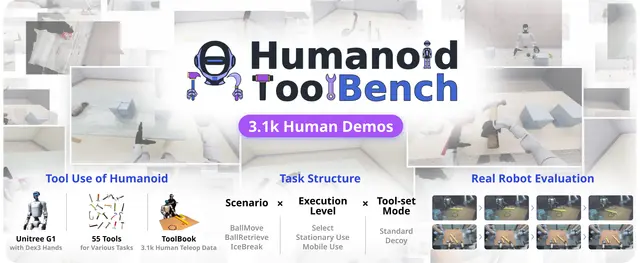
Can Humanoid Robots Choose Tools and Complete Tasks While Moving Reliably?
HumanoidOkt 4

Can Humanoid Robots Choose Tools and Complete Tasks While Moving Reliably?

Kyochul Jang, Seohyeon Park, Ohchul Kwon +9

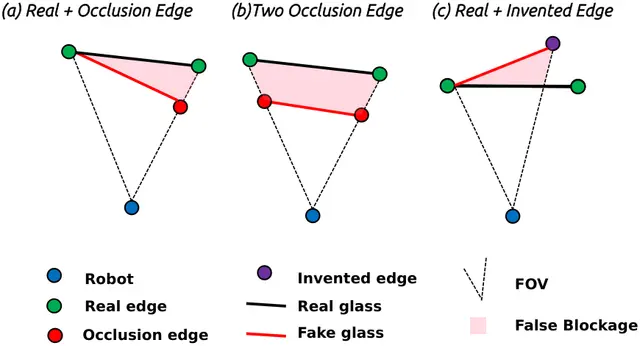
How GlassGuard Helps Mobile Robots Map Glass Without Blocking Safe Paths
RoboticsOkt 4

How GlassGuard Helps Mobile Robots Map Glass Without Blocking Safe Paths

GlassGuard combines camera detection, LiDAR geometry, and multi-view checks to help mobile robots map glass without blocking open paths.

Hanwen Guo, Zhengzhi Lin, Yusen Xie +1

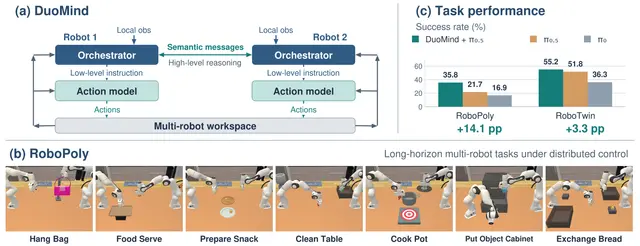
How DuoMind Helps Two Robots Coordinate With Shared Language
AIOkt 4

How DuoMind Helps Two Robots Coordinate With Shared Language

DuoMind helps two robots coordinate long manipulation tasks by sharing language-based plans, task information, and confidence between local controllers.

Hanchu Zhou, Dechen Gao, Hang Wang +5

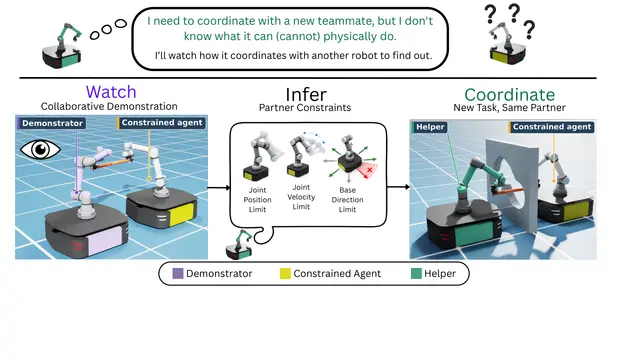
How Robots Learn Partner Limits for Safer Teamwork on New Tasks
AIOkt 3

How Robots Learn Partner Limits for Safer Teamwork on New Tasks

Suyu Ye, Zheyuan Zhang, Vaishnav Tadiparthi +5

FERPO Trains Robot Policies With Better Action Coverage, Faster Updates
AIOkt 3

FERPO Trains Robot Policies With Better Action Coverage, Faster Updates

Sebastian Sanokowski, Alireza Sarmadi, Majid Khadiv

How RPG Helps Embodied Agents Improve Robot Skills Through Practice
AIOkt 3

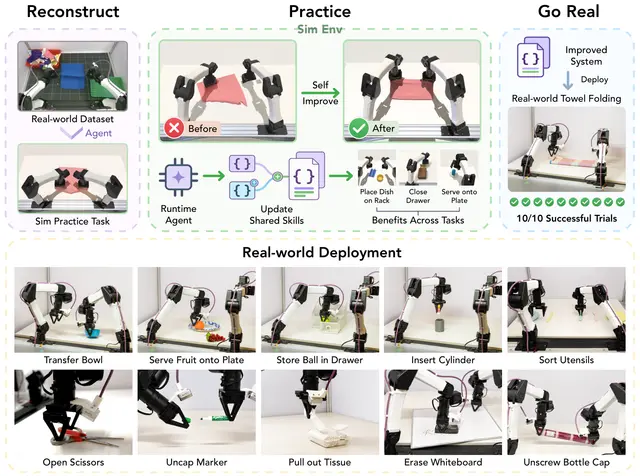
How RPG Helps Embodied Agents Improve Robot Skills Through Practice

RPG coordinates six specialized agents across its three stages: Constructor, Runtime Agent, Privileged Agent, Video Analyzer, Implementor, and Merger.

Yen-Jen Wang, Haozhe Jiang, Shuying Deng +7

StreamRig Uses Intra-Rig Geometry for Streaming Multi-Camera Odometry
RoboticsOkt 2

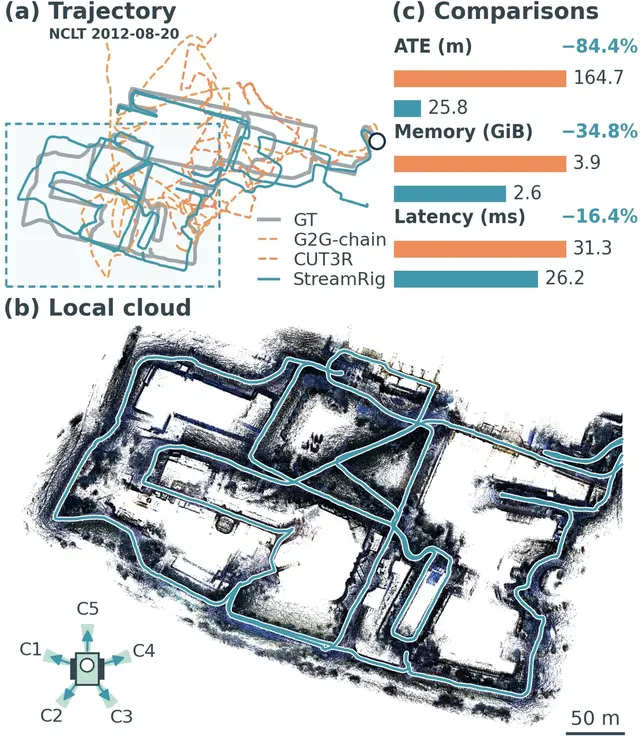
StreamRig Uses Intra-Rig Geometry for Streaming Multi-Camera Odometry

Multiple cameras widen the field of view and add redundancy when one view degrades.

Yufei Wei, Shuhao Ye, Qi Wang +4

How STARS Helps Robots Read Social Intent from Human Motion Cues
AIOkt 2

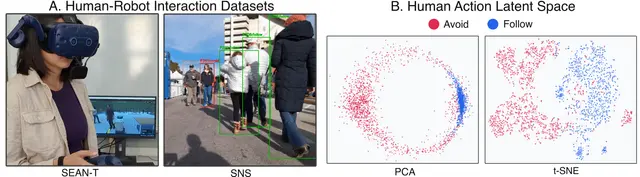
How STARS Helps Robots Read Social Intent from Human Motion Cues

Nathan Tsoi, Michael J. Munje, Tejas Oberoi +5

How Robot Teams Plan Safer Routes When Maps Hide Blocked Paths
AIOkt 2

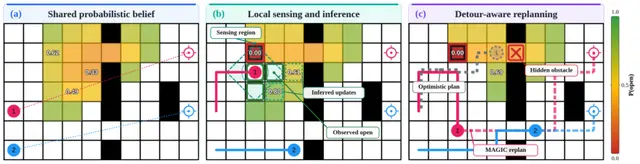
How Robot Teams Plan Safer Routes When Maps Hide Blocked Paths

Viraj Parimi, Shao-Hung Chan, Han Zhang +2

GPU Planning Helps Robots Pick Better Paths in Unknown Environments
RoboticsOkt 1

GPU Planning Helps Robots Pick Better Paths in Unknown Environments

A GPU-accelerated exploration planner scores what each viewpoint adds beyond earlier views, helping robots avoid redundant mapping.

João Félix Mendes, Rodrigo Ventura, Meysam Basiri

How a Physical Robot Harness Helps Agents Recover, Switch, and Learn
AIOkt 1

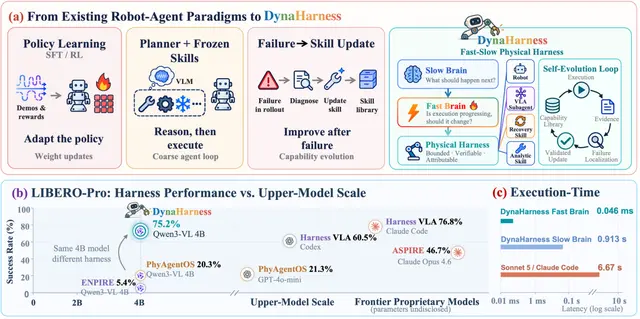
How a Physical Robot Harness Helps Agents Recover, Switch, and Learn

DynaHarness puts a fast control layer between robot-agent advice and execution, monitoring progress and routing failures for diagnosis.

Haoyuan Deng, Jiebin Liu, Tengxiao Zhang +3

How Egocentric Videos Help Robots Learn Better Real-World Skills at Scale
RoboticsOkt 1

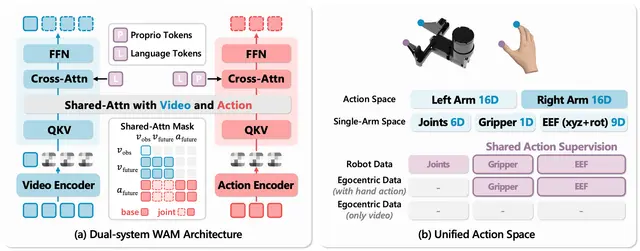
How Egocentric Videos Help Robots Learn Better Real-World Skills at Scale

Zhihao Sun, Liu Liu, Xinjiang Wang +6