Научни Papers

Обобщения на разбираем език на най-новите научни изследвания в роботиката — хуманоидни роботи, четириноги роботи, индустриална автоматизация и изкуствен интелект.
499 научни статии
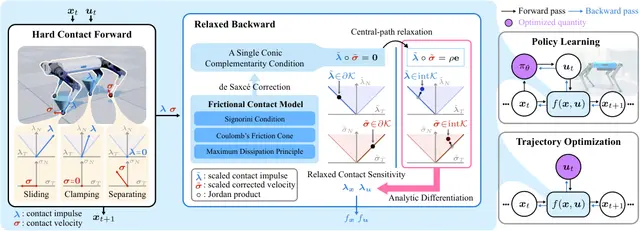
Teaching Legged Robots to Learn Through Foot Contact, Not Around It
Roboticsпреди 13 дни

Teaching Legged Robots to Learn Through Foot Contact, Not Around It

A contact-gradient method targets legged-robot policy learning and trajectory planning through foot-contact transitions.

Gijeong Kim, Seungbin Oh, Dongyun Kang, Hae-Won Park

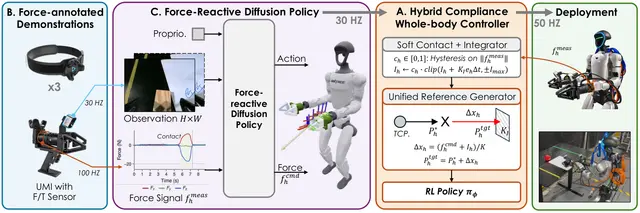
Force-Reactive Learning for Humanoid Loco-Manipulation in Contact-Rich Tasks
Humanoidпреди 13 дни

Force-Reactive Learning for Humanoid Loco-Manipulation in Contact-Rich Tasks
Humanoid robots offer a general-purpose embodiment for working in environments built for people.

Sihang Li, Xiaofeng Guo, Jinkun Cao +5

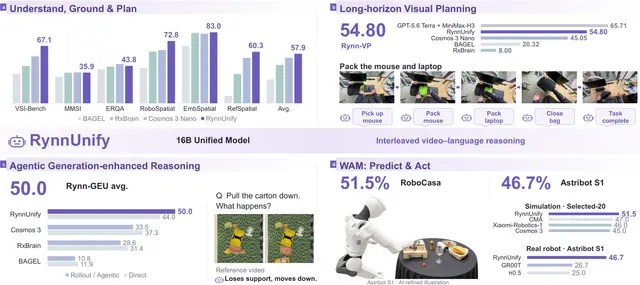
RynnUnify Unifies Robot Reasoning and Video Generation for Embodied Tasks
Roboticsпреди 14 дни

RynnUnify Unifies Robot Reasoning and Video Generation for Embodied Tasks
We retain the autoregressive reasoner of Cosmos3 without architectural modifications.

Minghao Zhu, Bohan Hou, Kun Xiang +20

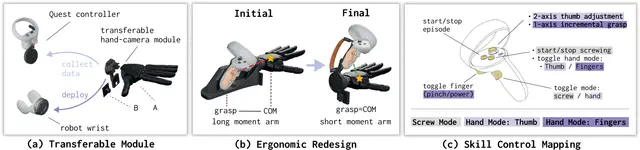
DexPort Makes Dexterous Hand Demonstrations Easier to Collect and Deploy
AIпреди 14 дни

DexPort Makes Dexterous Hand Demonstrations Easier to Collect and Deploy

Amber Xie, Jiawei Fu, Xiaofeng Guo +3

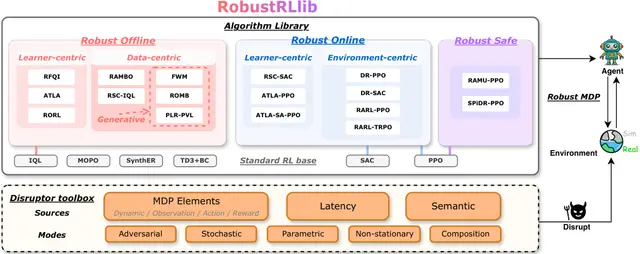
A Shared Testbed Reveals Where Robust Robot Learning Holds Up Best
AIпреди 14 дни

A Shared Testbed Reveals Where Robust Robot Learning Holds Up Best

Xi Chen, Fengqi Hu, Zeyu Shen +5

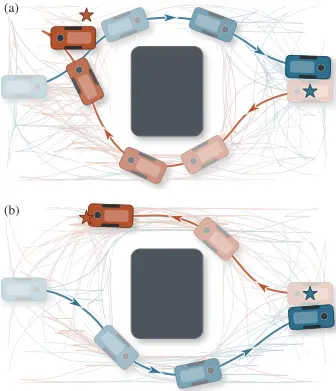
How Robot Teams Coordinate Motion with Dispersive Tree Search
Roboticsпреди 15 дни

How Robot Teams Coordinate Motion with Dispersive Tree Search

WarpWeaver coordinates robot teams through decentralized search over candidate motion trees, with a near-optimality certificate tied to search resolution.

Shashank A. Deshpande, Blake T. Edwards, Jonathan P. How

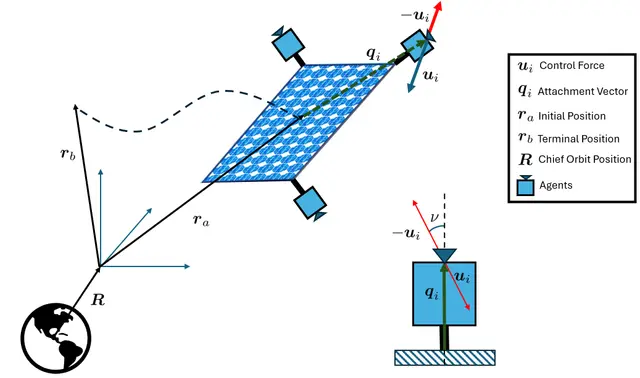
How Robot Swarms Can Move a Rigid Payload Through Orbit Together
Roboticsпреди 15 дни

How Robot Swarms Can Move a Rigid Payload Through Orbit Together

A decentralized planner splits cooperative orbital payload transport into convex thrust allocation and a search over payload torque trajectories.

Sidhdharth D. Sikka, Revathy Ravuri, Hei Yin Jowett Chan +2

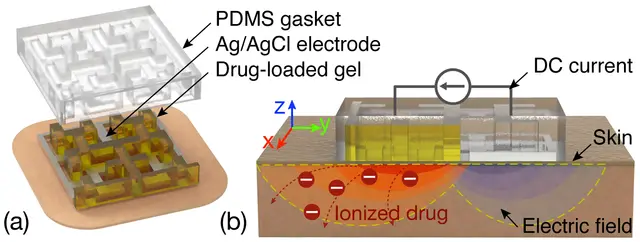
How Hydrogel Shape Can Tune Drug Delivery in Soft Robotic Devices
Roboticsпреди 15 дни

How Hydrogel Shape Can Tune Drug Delivery in Soft Robotic Devices

Heather Jin Hee Kim, Mohsen Alishahi, Kyuin Park +3

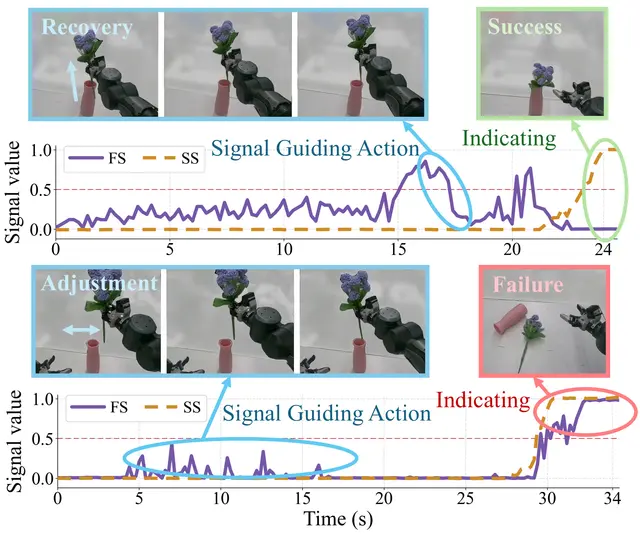
Echo Couples Robot Actions and Task Status Signals in Vision-Language Models
Roboticsпреди 16 дни

Echo Couples Robot Actions and Task Status Signals in Vision-Language Models
Yufeng Liu, Bohao Fan, Juntu Zhao +11

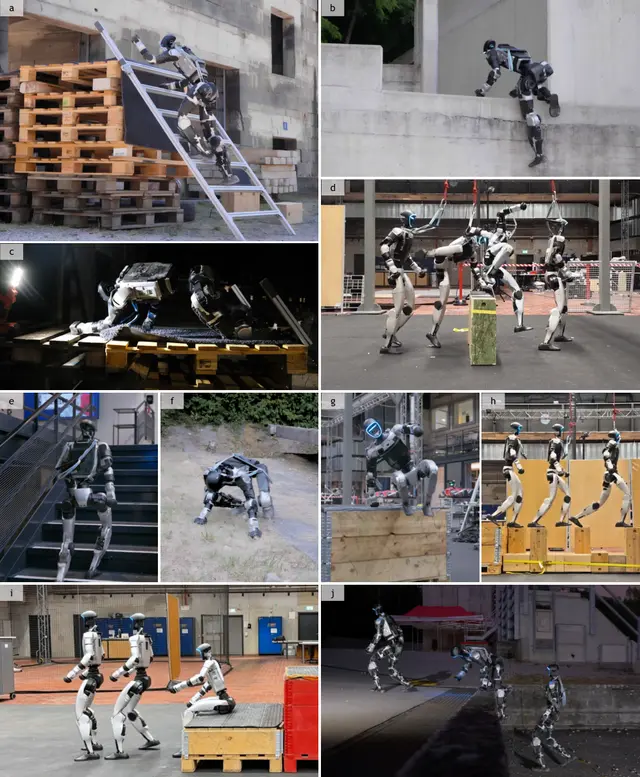
Humanoid Robots Use Attention and Contact Plans to Cross Difficult Terrain
Humanoidпреди 16 дни

Humanoid Robots Use Attention and Contact Plans to Cross Difficult Terrain

A humanoid controller uses contact plans instead of full-body scripts, achieving at least 98.5% success across tested reference-anchored terrain categories.

Junzhe He, Kehan Wen, Chong Zhang +7

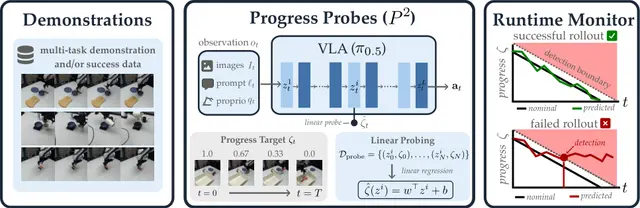
Progress Probes Monitor Vision-Language-Action Models at Runtime
Roboticsпреди 16 дни

Progress Probes Monitor Vision-Language-Action Models at Runtime

Next, we study how our lightweight progress probe compares to general-purpose VLMs as runtime monitors.

Atiksh Bhardwaj, Edward W. Duan, Junwon Seo +4

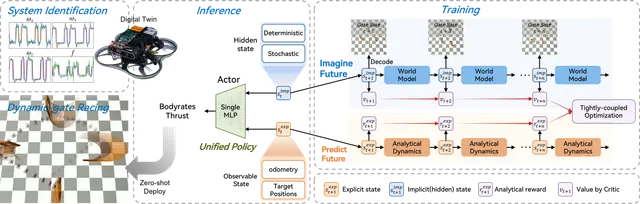
Quadrotor Control Pairs World Models with Differentiable Physics for Agile Flight
Roboticsпреди 17 дни

Quadrotor Control Pairs World Models with Differentiable Physics for Agile Flight
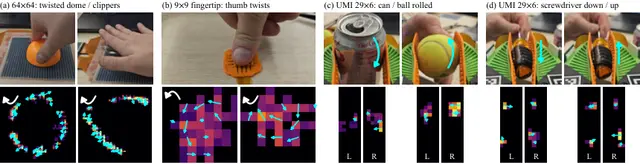
Fanxing Li, Yuxiang Huang, Shengyang Wang +7

OpenTac Makes Custom Robot Touch Sensors Easier to Build and Simulate
Roboticsпреди 17 дни

OpenTac Makes Custom Robot Touch Sensors Easier to Build and Simulate

Ariel Slepyan, Geeta Chandra Raju Bethala, Jiafeng Gu +12

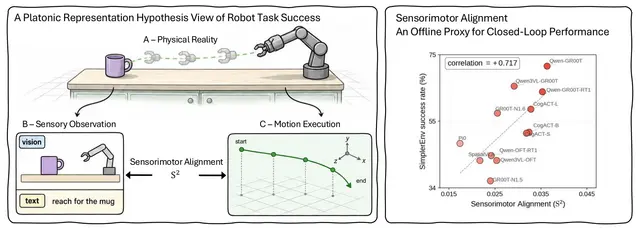
Sensorimotor Alignment Offers a Useful Clue to Embodied Robot Policy Success
AIпреди 17 дни

Sensorimotor Alignment Offers a Useful Clue to Embodied Robot Policy Success

Sensorimotor alignment between model features and robot motion correlates with task success, offering a potential signal for evaluating embodied policies.

Yunfei Xie, Howard H. Qian, Shiyi Lan +2

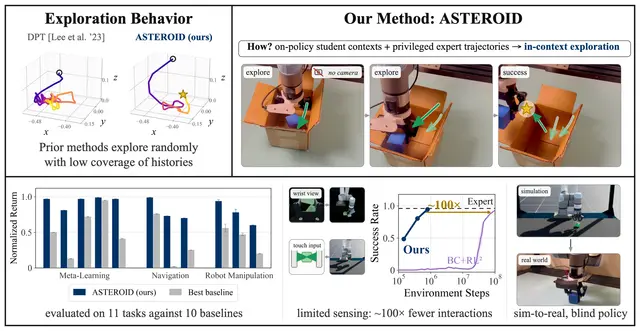
How Robots Learn In-Context Exploration Through On-Policy Distillation
AIпреди 18 дни

How Robots Learn In-Context Exploration Through On-Policy Distillation

We evaluate our approach on a diverse suite of partially observable decision-making problems across robotic manipulation, discrete exploration, and continuous navigation.

Sriyash Poddar, Yanda Bao, Jacob Krantz +5

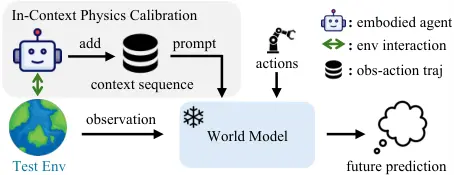
Calibrating Robot World Models with In-Context Physics from Test-Scene Interaction
AIпреди 18 дни

Calibrating Robot World Models with In-Context Physics from Test-Scene Interaction
Yunhao Luo, Wentao He, Yinpei Dai +5

Agentic World Action Models: Code-Guided Skills for Robot Control
Roboticsпреди 18 дни

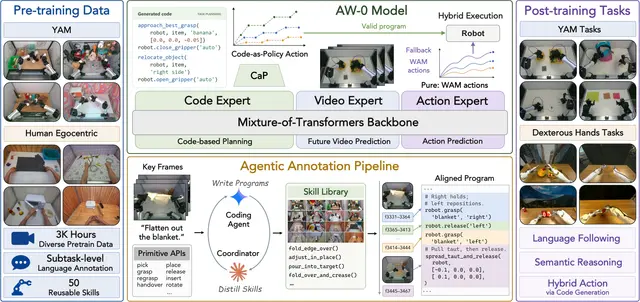
Agentic World Action Models: Code-Guided Skills for Robot Control

Zhuoyang Liu, Dantong Niu, Botong Zhang +15

One Model Connects Robot Video, Language, Memory, and Actions for Control
AIпреди 19 дни

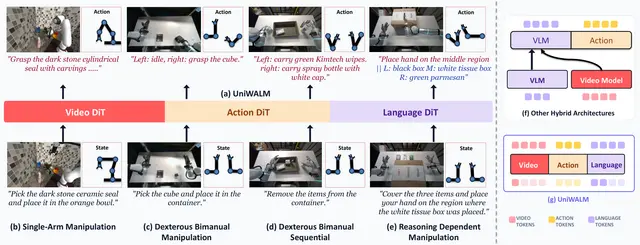
One Model Connects Robot Video, Language, Memory, and Actions for Control

UniWALM combines future video, robot actions, language, and carried textual memory to target tasks that require remembering counts, hidden objects, and failed attempts.

Rahul Sajnani, Diego Romeres, Mingyuan Zhang +9

Teaching Robot Hands to Copy and Adapt Everyday Human Object Skills
AIпреди 19 дни

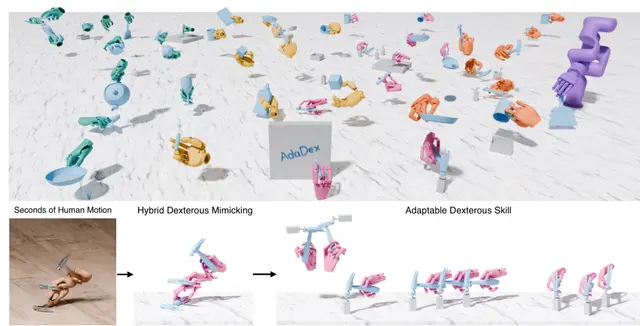
Teaching Robot Hands to Copy and Adapt Everyday Human Object Skills

Hybrid Dexterous Mimicking turns human hand-object videos into robot skills designed to tolerate noisy motion estimates and transfer across simulators.

Yuxuan Kuang, Jiashun Wang, Yixuan Sun +5

One Model Generates 3D Motion and Video for Any Animated Rig
AIпреди 19 дни

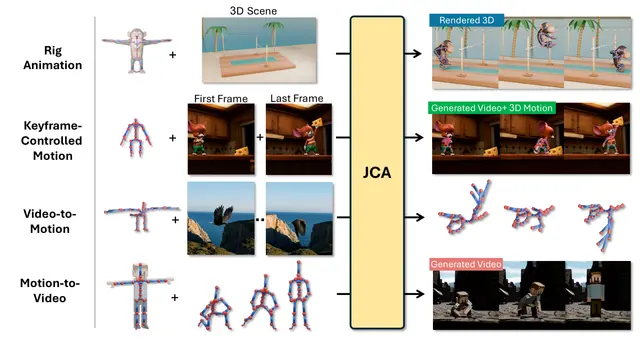
One Model Generates 3D Motion and Video for Any Animated Rig

Noam Rotstein, Yoad Tewel, Chen Tessler +5