Papers de pesquisa
Resumos em linguagem simples das pesquisas mais recentes em robótica — robôs humanoides, quadrúpedes, automação industrial e IA.
Robotics14 de jun.
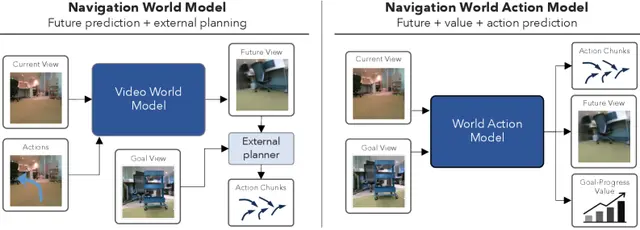
Navigation World Action Model for Goal-Conditioned Visual Navigation
Robotics14 de jun.
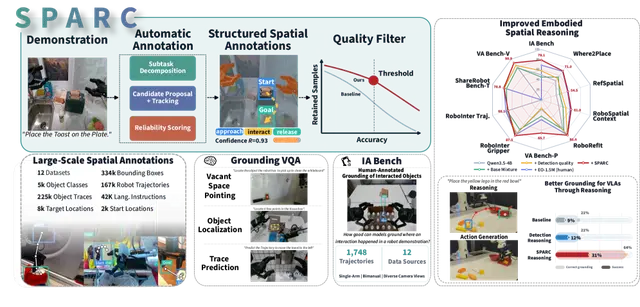
SPARC: Reliable Spatial Annotations from Robot Demonstrations at Scale
AI14 de jun.
Heterogeneous LiDAR Early Fusion and Learned Re-Ranking for Robust Long-Term Place Recognition
AI13 de jun.
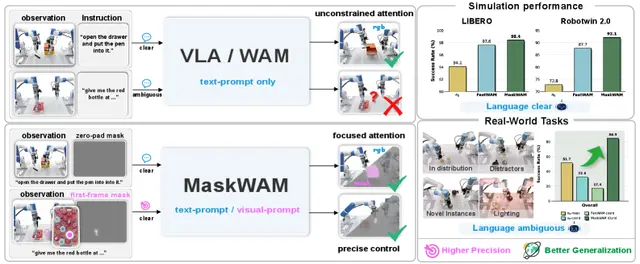
MaskWAM Teaches Robots to Predict What Matters for Better Manipulation
AI13 de jun.
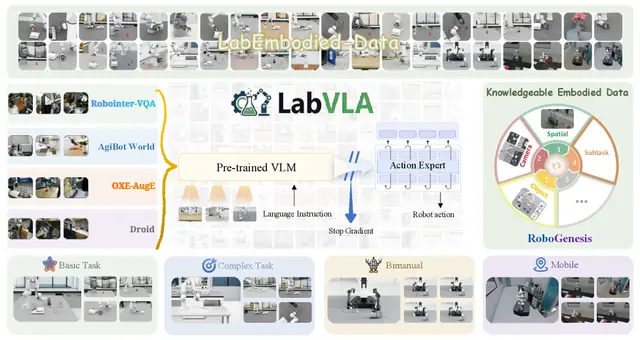
LabVLA Brings Vision-Language-Action Models to Lab Automation
Robotics13 de jun.
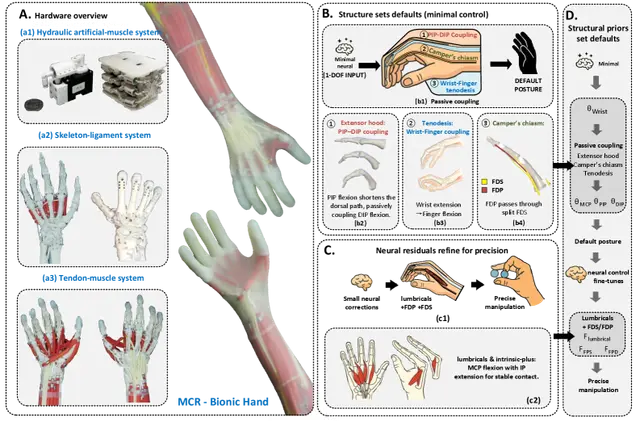
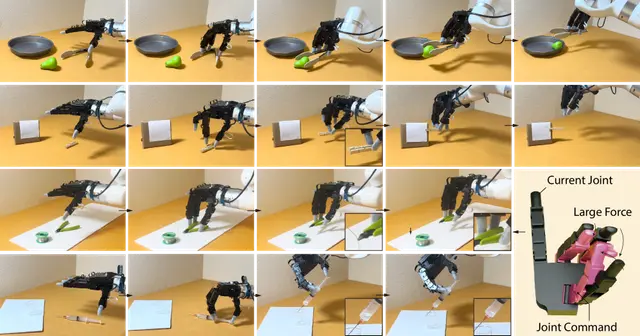
MCR-Bionic Hand: How Anatomical Structure Unlocks Dexterous Robot Manipulation

Robotics12 de jun.
Weaver: A Fast and Scalable World Model for Robotic Manipulation
Robotics12 de jun.
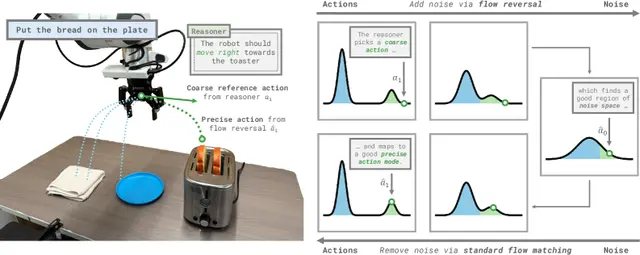
Flow Reversal Steering Makes Robot Generalists Better at Following High-Level Guidance
AI12 de jun.
Mana: A New System for Dexterous Robot Manipulation of Articulated Tools
AI11 de jun.
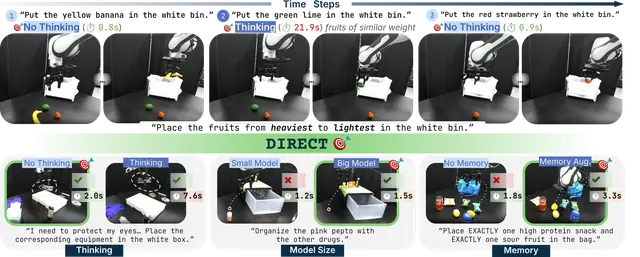
When and Where Should You Allocate Test-Time Compute in Embodied Planners?
Robotics11 de jun.
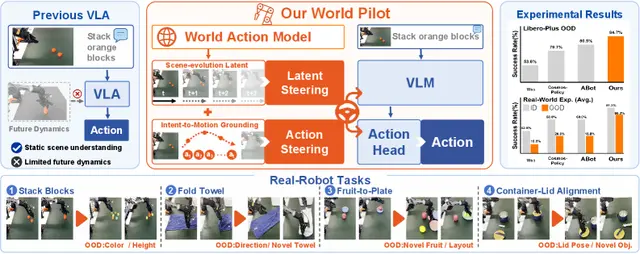
World Pilot Gives Vision-Language-Action Robots a World-Action Model Boost
AI11 de jun.
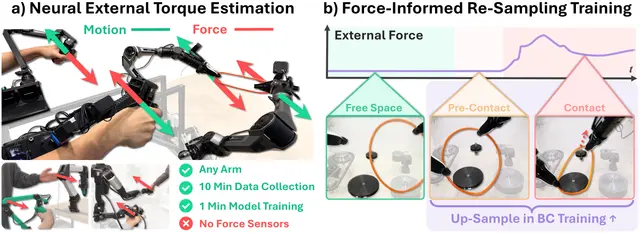
New Method Gives Cheap Robot Arms Force Feedback Without Extra Sensors
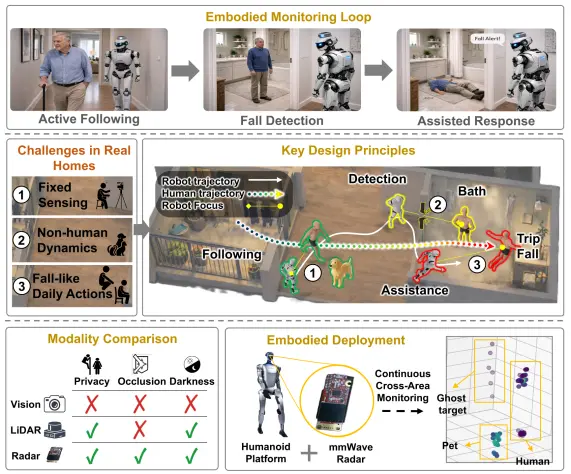
Humanoid10 de jun.
Embodied mmWave Radar on Humanoid Robots Enables 24/7 Fall Detection
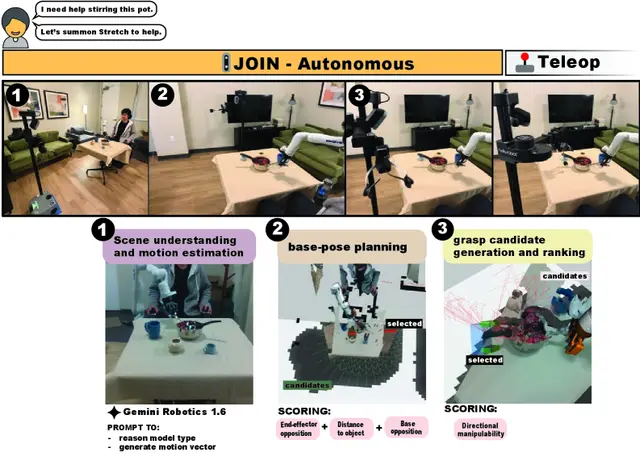
Robotics10 de jun.
Bimanual Joining System Lets Wheelchair Robots Call for Backup
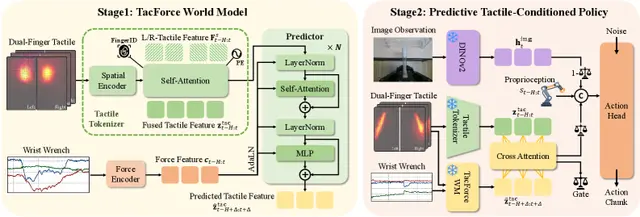
Robotics10 de jun.
TacForeSight Predicts Tactile Feedback From Force Data for Better Robot Handling
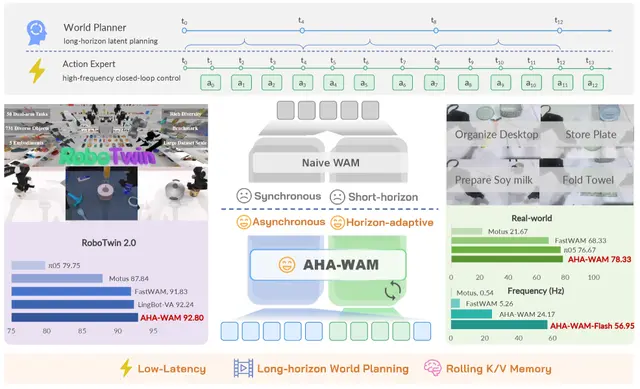
AI9 de jun.
AHA-WAM: Asynchronous World-Action Model for Faster, Smarter Robot Manipulation
Robotics9 de jun.
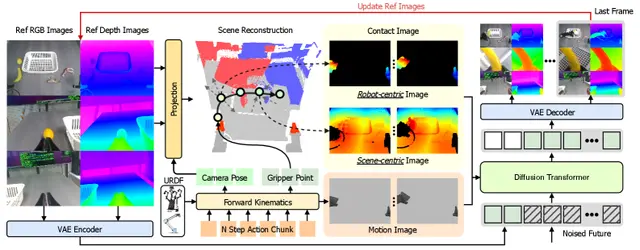
How Robots Turn Actions Into Motion and Contact Images for Better World Models
Robotics9 de jun.
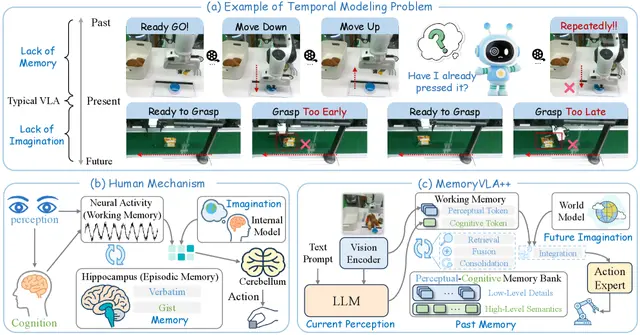
MemoryVLA++ Equips Robots with Memory and Imagination for Complex Tasks
AI8 de jun.