Papers badawcze

Przystępne podsumowania najnowszych badań z zakresu robotyki — robotów humanoidalnych, czworonogów, automatyzacji przemysłowej i AI.
499 publikacji
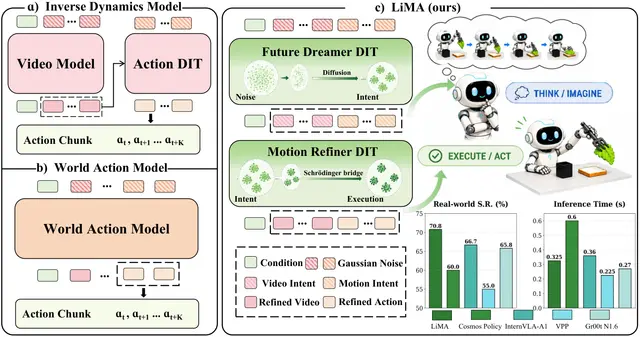
Asynchronous Diffusion for Long-Term Dexterous Robot Manipulation
Robotics24 wrz

Asynchronous Diffusion for Long-Term Dexterous Robot Manipulation

LiMA is an asynchronous multi-scale framework for jointly generating long-term foresight and robotic actions.

Ning Chen, Yankai Fu, Junkai Zhao, Qianpu Sun +4

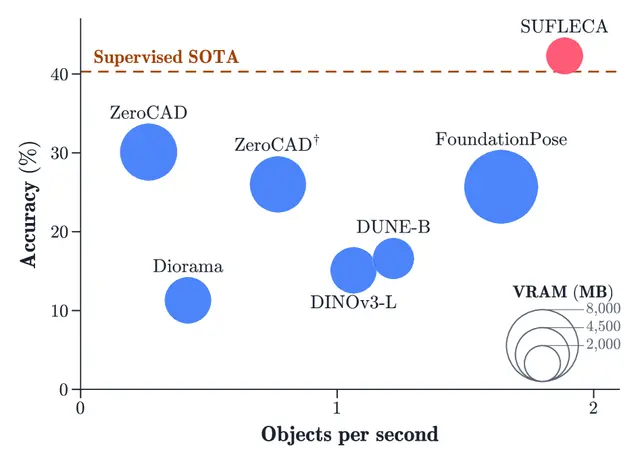
Scaling Up Feature Learning for CAD-to-Image Alignment
Robotics23 wrz

Scaling Up Feature Learning for CAD-to-Image Alignment

SUFLECA scales up feature learning for CAD-to-image alignment using weak supervision from synthetic renders, improving pose estimation in cluttered real scenes.

Saad Ejaz, Miguel Fernandez-Cortizas, Javier Civera +2

Single-Sensor Flow History Guides Underwater Robot Navigation
Robotics23 wrz

Single-Sensor Flow History Guides Underwater Robot Navigation

A single flow sensor’s history helps underwater robots recover lateral navigation cues in simulated unsteady wakes.

Linhao Jin, Qimin Feng, Peter Gunnarson +1

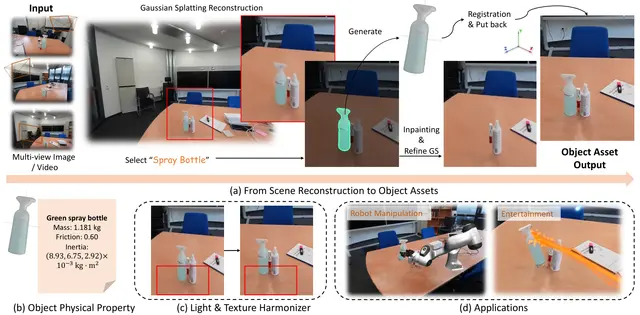
Gaussian Scene Reconstruction for Interactive Robotic Environments
Robotics23 wrz

Gaussian Scene Reconstruction for Interactive Robotic Environments

Runyi Yang, Deheng Zhang, Xiaoye Wang +6

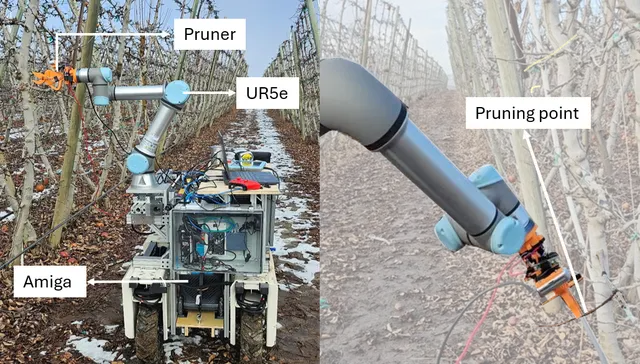
Hybrid Reinforcement Learning for Visuomotor Robotic Pruning in Planar Orchards
AI22 wrz

Hybrid Reinforcement Learning for Visuomotor Robotic Pruning in Planar Orchards

Abhinav Jain, Cindy Grimm, Stefan Lee

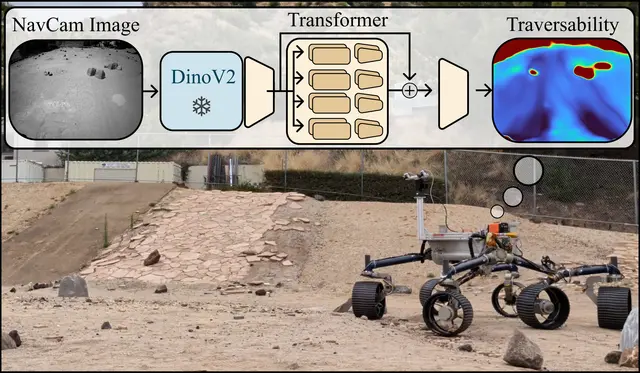
Learning to Drive on Mars with Multimodal Visual Traversability Models
Robotics22 wrz

Learning to Drive on Mars with Multimodal Visual Traversability Models

Deep learning offers an opportunity to learn terrain-dependent effects directly from driving experience.

Darren Chiu, Cole Wilson, Andrei Tumbar +2

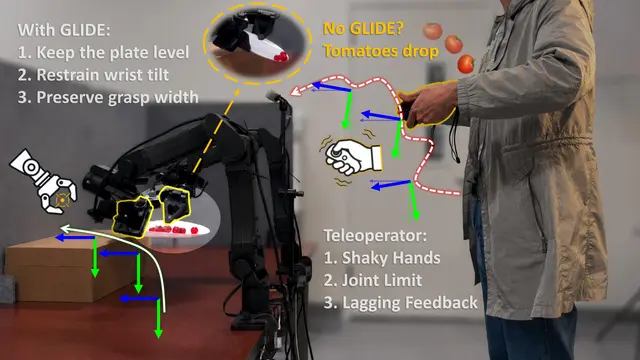
GLIDE Guardrails Help Robots Learn Safer Wine Serving Skills
Robotics22 wrz

GLIDE Guardrails Help Robots Learn Safer Wine Serving Skills

We illustrate guardrail refinement from guarded teleoperation through the Wine serving task.

Yuchen Song, Aditya Mittal, Unnat Jain

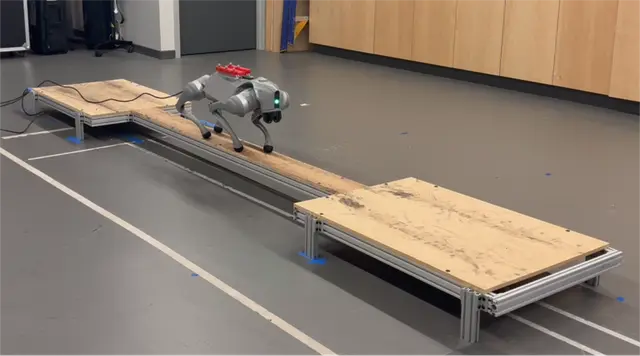
How Duty Factor Predicts Robust Quadrupedal Locomotion Across Gaits
Robotics21 wrz

How Duty Factor Predicts Robust Quadrupedal Locomotion Across Gaits

James Zhu, David Ologan, George Ortiz +5

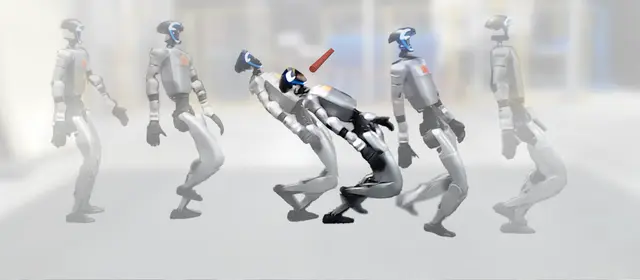
LIMBO Helps Humanoid Robots Learn Agile, Safe Whole-Body Control
Robotics21 wrz

LIMBO Helps Humanoid Robots Learn Agile, Safe Whole-Body Control

Jake Gonzales, Arturo Flores Alvarez, Yu-Ming Chen +3

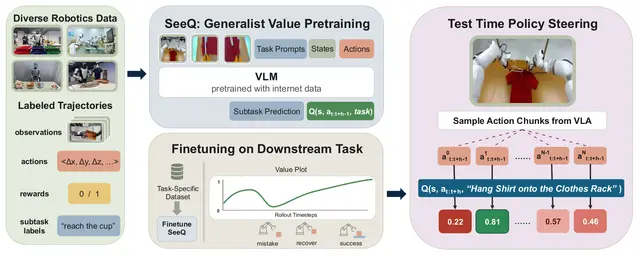
Training Generalist Value Functions for Long-Horizon Robot Manipulation
Robotics21 wrz

Training Generalist Value Functions for Long-Horizon Robot Manipulation

Next, we assess the importance of predicting the active subtask and conditioning value estimation on it for shirt-hang.

Saksham Singh, Zheyuan Hu, Max Sobol Mark +3

BayesContact: Estimating Hidden Object Poses by Fusing Vision and Touch
Robotics20 wrz

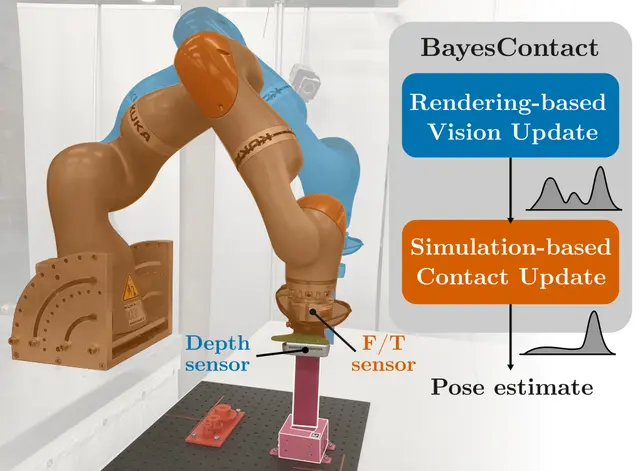
BayesContact: Estimating Hidden Object Poses by Fusing Vision and Touch

Reliable physical interaction with objects is critical for robots performing contact-rich manipulation tasks such as key insertion, cable connection, fasteni…

Aditya Kamireddypalli, Matias Mattamala, Joao Moura +3

NeoSLAM: A New Implementation and Comparative Evaluation Against RatSLAM
Robotics20 wrz

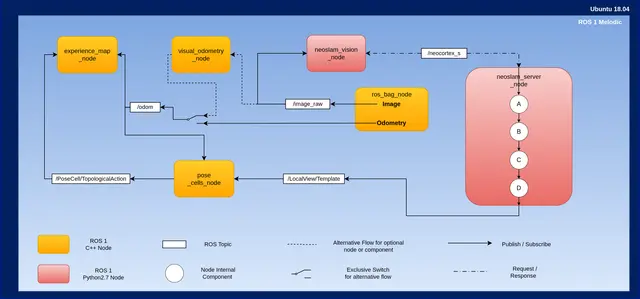
NeoSLAM: A New Implementation and Comparative Evaluation Against RatSLAM

Joao Victor T. Borges, Fabio Coelho, Paulo Padrao +4

NICO Robot Mimics Human Arm Gestures Using Only a Single RGB Camera
Humanoid20 wrz

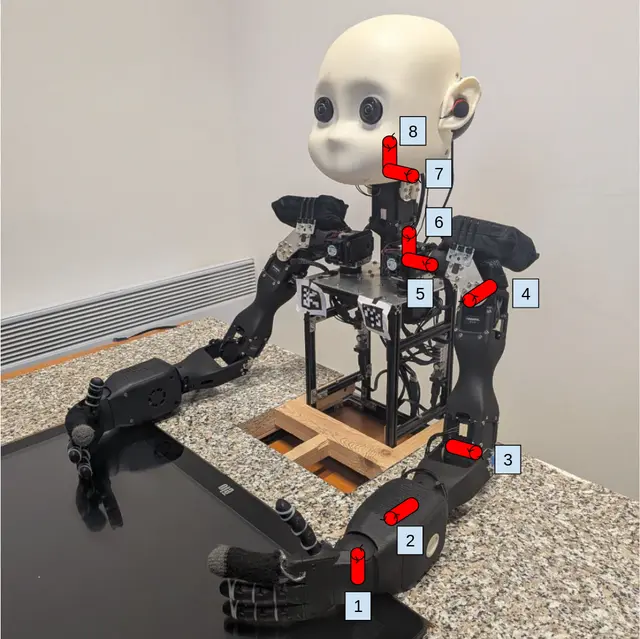
NICO Robot Mimics Human Arm Gestures Using Only a Single RGB Camera

Anastasiya Ihnatovich, Igor Farkaš

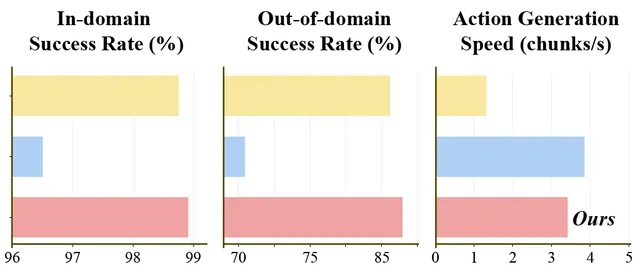
MoWAM Predicts Robot Motion for Efficient World Models and Action Planning
Robotics19 wrz

MoWAM Predicts Robot Motion for Efficient World Models and Action Planning

MoWAM predicts structured future robot motion instead of dense video, improving efficient manipulation action planning.

Jiayu Wang, Bin Zhu, Yue Yu +1

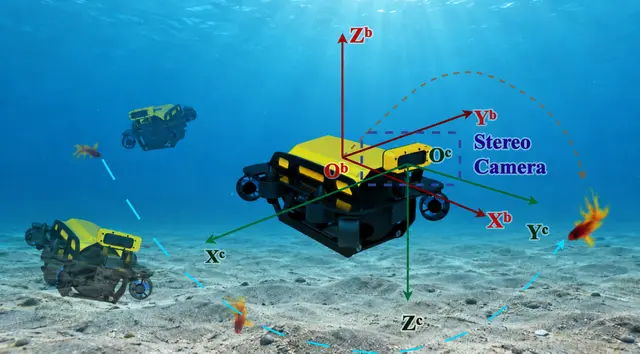
Underwater AUVs Track Targets with Better Depth and Motion Prediction
Robotics19 wrz

Underwater AUVs Track Targets with Better Depth and Motion Prediction

An eight-thruster AUV combines target-specific stereo depth and adaptive predictive control for steadier underwater visual tracking.

Yuheng Zhou, Haiyang Cheng, Yanqi Feng +5

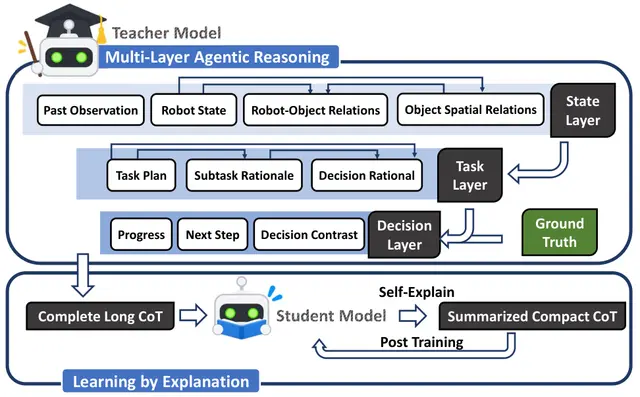
A Lightweight Robot Monitor Learns When Tasks Change Stage
Robotics19 wrz

A Lightweight Robot Monitor Learns When Tasks Change Stage

Jinbang Huang, Yuanzhao Hu, Zhiyuan Li +6

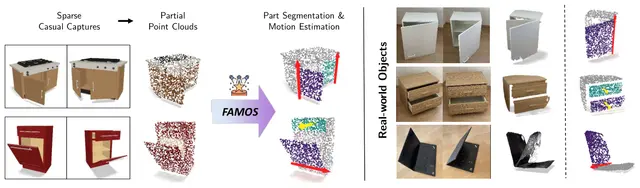
Feed-Forward 3D Articulation Modeling from Sparse Robot Observations
AI18 wrz

Feed-Forward 3D Articulation Modeling from Sparse Robot Observations

Kevin Qu, Tao Sun, Massimiliano Viola +5

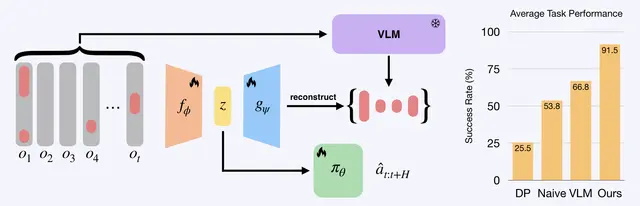
Lightweight Robotic Memory Models for Long-Horizon Manipulation
AI18 wrz

Lightweight Robotic Memory Models for Long-Horizon Manipulation

We test, in three simulated and one real task, three distinct memory-usage capabilities.

Nitish Dashora, Douglas Chen, Idan Shenfeld +3

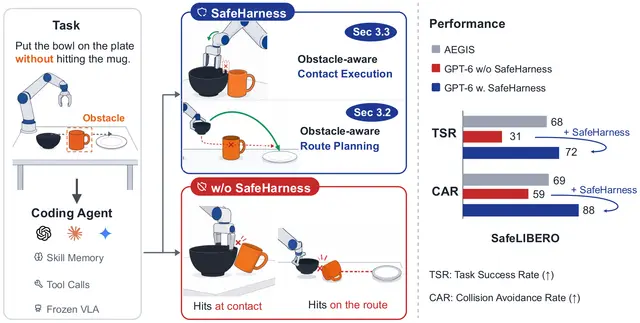
Safe Robot Manipulation Gets a Coding Agent to Check Every Move
AI18 wrz

Safe Robot Manipulation Gets a Coding Agent to Check Every Move

SafeHarness helps coding agents manipulate robots more safely by verifying routes and contact motions before execution.

Bingxin Xu, Yuzhang Shang, Zhen Dong +1

Always-Feasible Elastic QP Solver for High-Frequency Robot Control
Robotics17 wrz

Always-Feasible Elastic QP Solver for High-Frequency Robot Control

Daniel Morton, Jon Arrizabalaga, Zachary Manchester +1