Papers badawcze

Przystępne podsumowania najnowszych badań z zakresu robotyki — robotów humanoidalnych, czworonogów, automatyzacji przemysłowej i AI.
499 publikacji
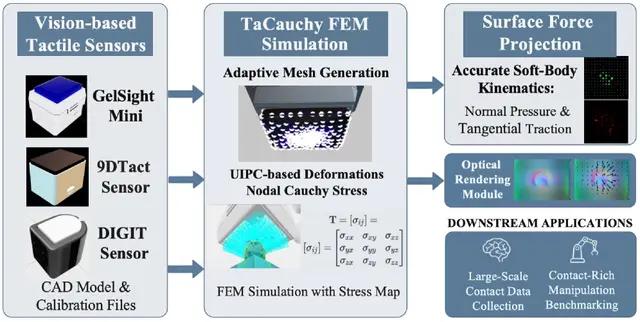
New FEM Framework Simulates Tactile Sensors with Unprecedented Force Accuracy
Robotics22 cze

New FEM Framework Simulates Tactile Sensors with Unprecedented Force Accuracy

TaCauchy integrates FEM-based force computation into Isaac Sim, extracting full Cauchy stress tensors for vision-based tactile sensors.

Hengfei Zhao, Yifan Xie, Junhao Gong, Yue Sun +5

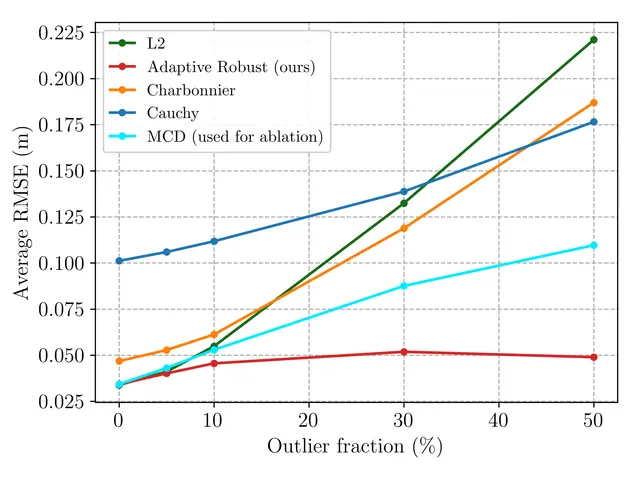
ARC: Adaptive Robust Estimation Handles Outliers and Unknown Noise in Real-Time Localization
Robotics22 cze

ARC: Adaptive Robust Estimation Handles Outliers and Unknown Noise in Real-Time Localization
A new adaptive robust framework jointly estimates a robot's position and the measurement noise statistics without any manual tuning, even when half the senso…

Alexandre Hadji-Thomas, Andrew Stirling, James R. Forbes

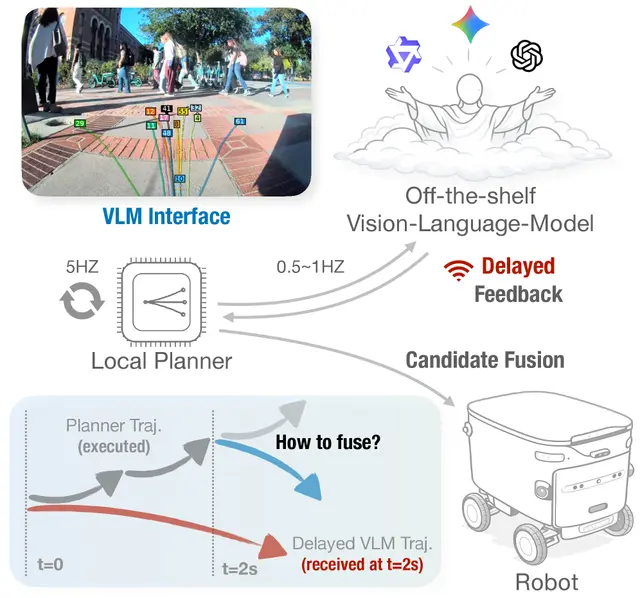
Slow Brain, Fast Planner: Keeping Robots Safe When AI Vision Takes Its Time
Robotics22 cze

Slow Brain, Fast Planner: Keeping Robots Safe When AI Vision Takes Its Time

We propose a hybrid architecture that combines a fast local planner and a slow Vision-Language Model (VLM). The planner generates dynamically feasible candid…

Zhenghao "Mark'' Peng, Honglin He, Quanyi Li +2

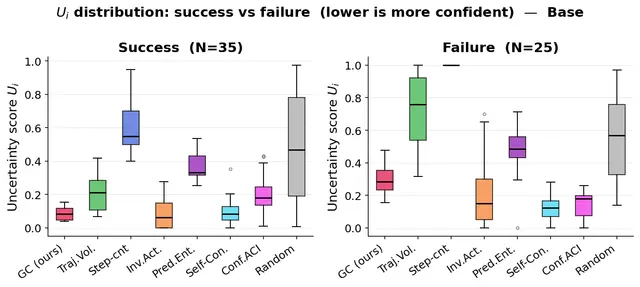
GroundControl: Anticipating Navigation Failures in Vision-Language Agents Using Trajectory-Consistent Uncertainty
Robotics21 cze

GroundControl: Anticipating Navigation Failures in Vision-Language Agents Using Trajectory-Consistent Uncertainty

Nastaran Darabi, Divake Kumar, Sina Tayebati +2

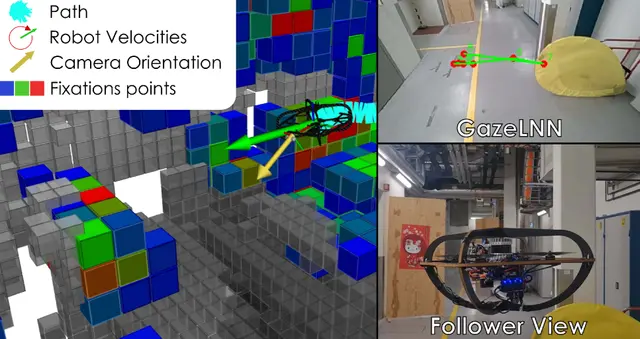
Fast Human Attention Prediction Enables Real-Time Fixation-Guided Drone Navigation
Robotics21 cze

Fast Human Attention Prediction Enables Real-Time Fixation-Guided Drone Navigation

Fatma Youssef Mohammed, Grzegorz Malczyk, Kostas Alexis

New Motion Planning Algorithms Make Continuum Robots More Resilient
Robotics21 cze

New Motion Planning Algorithms Make Continuum Robots More Resilient

Researchers have developed motion planning algorithms that significantly extend the lifespan of continuum robots — flexible, snake-like machines used in surg…

Oxana Shamilyan, Ievgen Kabin, Zoya Dyka +2

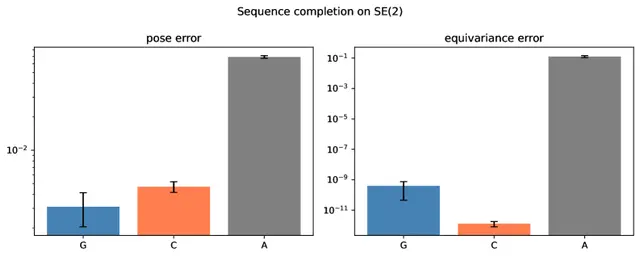
New Attention Mechanism Treats Robot Poses as Group Elements, Boosts Performance
AI19 cze

New Attention Mechanism Treats Robot Poses as Group Elements, Boosts Performance

Researchers have developed a fundamentally new attention mechanism where every token is an element of a matrix Lie group — such as a 2D or 3D pose — rather t…

Przemyslaw Musialski

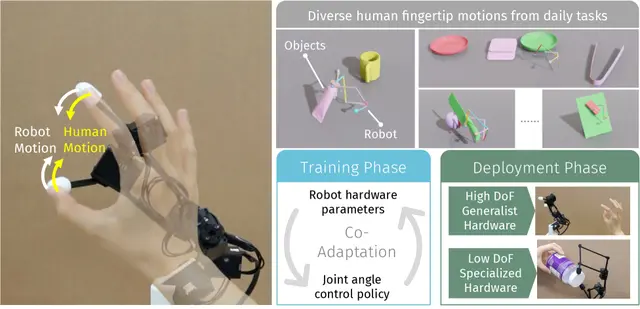
Generating Task-Specific Robot Hands from Human Fingertip Demonstrations
Robotics19 cze

Generating Task-Specific Robot Hands from Human Fingertip Demonstrations

Sha Yi, Nicklas Hansen, Xueqian Bai +3

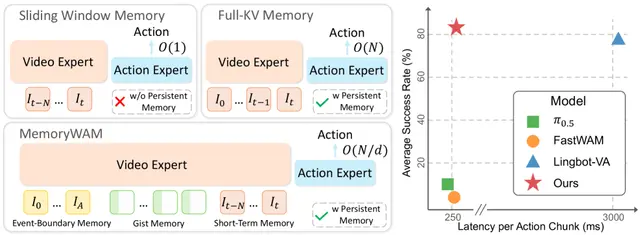
MemoryWAM: Persistent Memory Makes Robot Action Models Faster and Smarter
Robotics19 cze

MemoryWAM: Persistent Memory Makes Robot Action Models Faster and Smarter

Sizhe Yang, Juncheng Mu, Tianming Wei +8

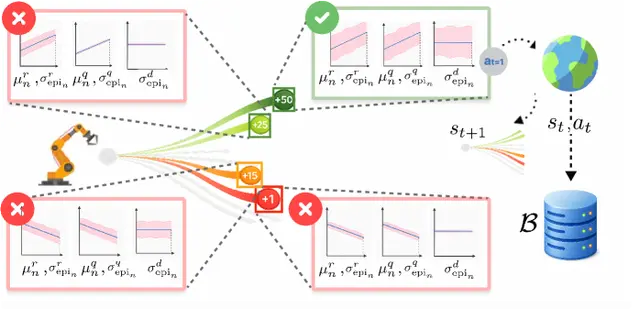
New Algorithm UBP2 Uses Uncertainty to Learn Robot Rewards from Preferences
AI18 cze

New Algorithm UBP2 Uses Uncertainty to Learn Robot Rewards from Preferences

Researchers have developed UBP2, a preference-based reinforcement learning method that actively guides exploration by balancing expected reward with model un…

Mohamed Nabail, Leo Cheng, Jingmin Wang +1

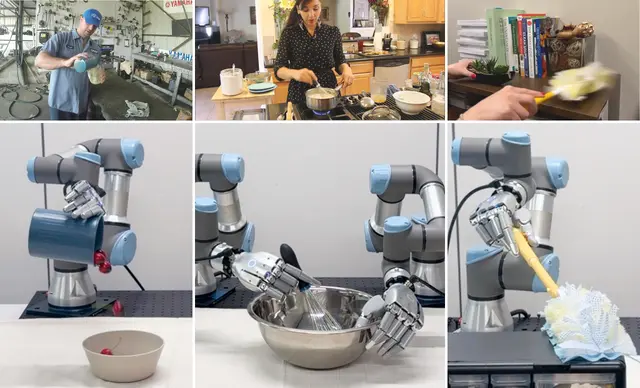
Do as I Do: Turning Everyday Human Videos Into Dexterous Robot Data
Robotics18 cze

Do as I Do: Turning Everyday Human Videos Into Dexterous Robot Data

Do as I Do is a two-step algorithm that reconstructs and retargets hand-object interactions from monocular RGB videos onto multi-fingered dexterous robot han…

Bhawna Paliwal, Haritheja Etukuru, William Liang +3

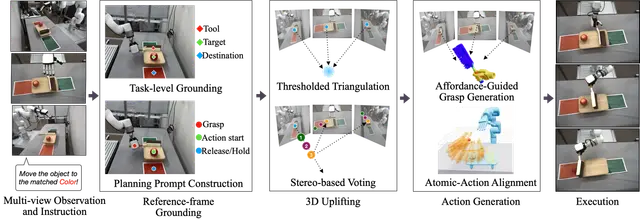
Zero-Shot Long-Horizon Dexterous Manipulation with Multi-View 3D Grounded VLM Reasoning
Robotics18 cze

Zero-Shot Long-Horizon Dexterous Manipulation with Multi-View 3D Grounded VLM Reasoning
Jisoo Kim, Sangwon Baik, Taeksoo Kim +4

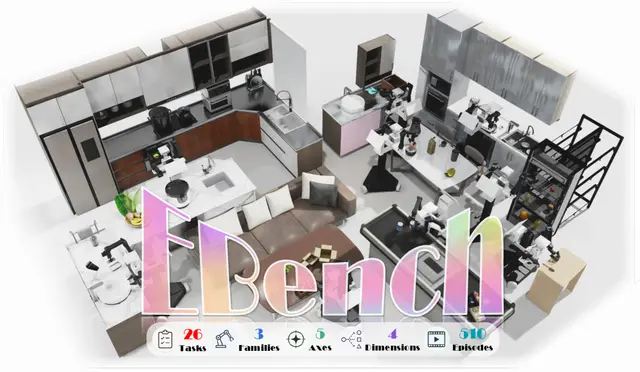
EBench: A New Benchmark Diagnoses Mobile Manipulation Robots' Core Capabilities
Robotics17 cze

EBench: A New Benchmark Diagnoses Mobile Manipulation Robots' Core Capabilities

Ning Gao, Jinliang Zheng, Xing Gao +22

Robotics17 cze

MOCHI Cleans Up Noisy Multi-Human Object Interaction Data

MOCHI is a two-stage framework that cleans noisy multi-human object interaction motion capture data using hand grasp optimization and diffusion-based refinement.

Jiye Lee, Yonghun Choi, Jungdam Won

AI17 cze

Visual Verifier Helps Robots Improve Their Own Policy Without Retraining
A new framework called VERITAS pairs a generalist robot policy with a gradient-free visual verifier that evaluates actions during inference, letting robots s…

Mingtong Zhang, Dhruv Shah

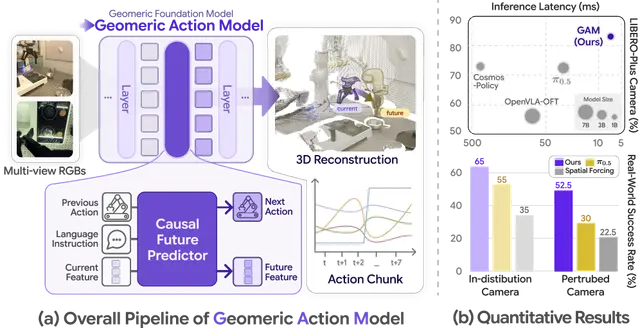
Geometric Action Model Unifies Geometry and Action Prediction for Robot Learning
AI16 cze

Geometric Action Model Unifies Geometry and Action Prediction for Robot Learning

Jisang Han, Seonghu Jeon, Jaewoo Jung +7

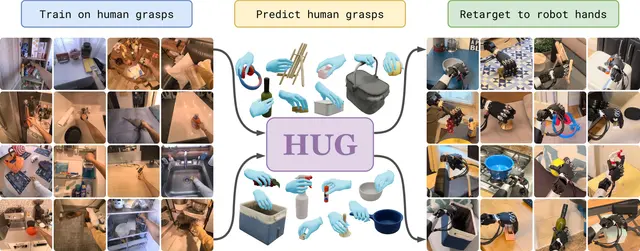
Human Universal Grasping: A Model That Learns Diverse Natural Grasps
Robotics16 cze

Human Universal Grasping: A Model That Learns Diverse Natural Grasps

Kevin Yuanbo Wu, Tianxing Zhou, Isaac Tu +5

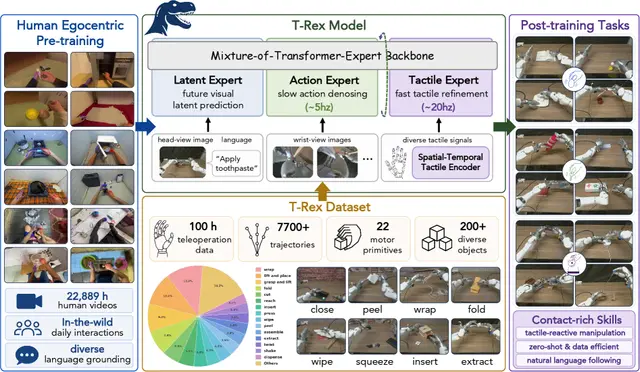
T-Rex: Tactile-Reactive Dexterous Manipulation Using Robot Hands
Robotics16 cze

T-Rex: Tactile-Reactive Dexterous Manipulation Using Robot Hands

Human dexterity relies on more than vision; it depends fundamentally on the ability to feel and rapidly react to fine-grained tactile signals. While everyday…

Dantong Niu, Zhuoyang Liu, Zekai Wang +32

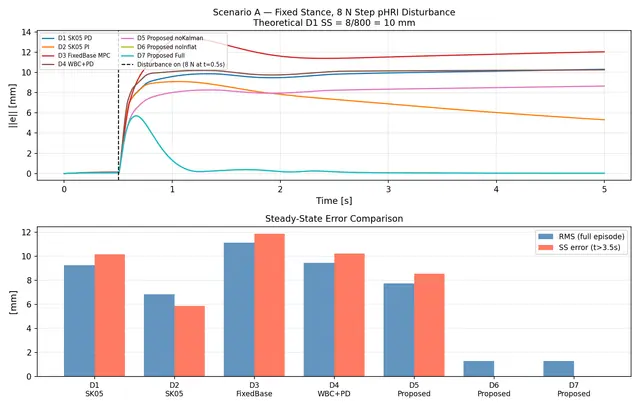
Whole-Body Impedance MPC Lets Legged Robots Safely Handle Human Pushes
Robotics15 cze

Whole-Body Impedance MPC Lets Legged Robots Safely Handle Human Pushes

A new three-level control architecture gives floating-base robots—humanoids and quadrupeds—the ability to reject physical human pushes and sustained contact …

Yongyan Cao

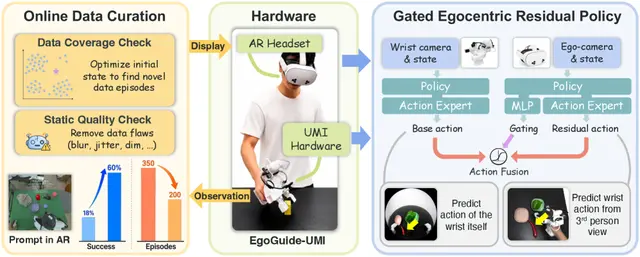
EgoGuide Boosts Robot Training Data with AR Guidance and Egocentric Vision
Robotics15 cze

EgoGuide Boosts Robot Training Data with AR Guidance and Egocentric Vision

Yue Xu, Mingtao Nie, Tianle Li +4