Onderzoek Papers

Samenvattingen in duidelijke taal van het nieuwste roboticaonderzoek — humanoïde robots, viervoeters, industriële automatisering en AI.
499 papers
Bandwidth-Limited Robots Learn to Sync Early, Not Panic Late, in Cooperative Navigation
Robotics12 jul

Bandwidth-Limited Robots Learn to Sync Early, Not Panic Late, in Cooperative Navigation

A new study reveals that when multiple robots navigate together under tight radio budgets, the smartest communication strategy isn't to ask for help when los…

Arav Gupta, Nivedan Yakolli, Avinash Gautam

FabriVLA: Lightweight VLA for Precise Multi-Task Manipulation
Robotics12 jul

FabriVLA: Lightweight VLA for Precise Multi-Task Manipulation

FabriVLA achieves 92% success on 50 manipulation tasks using a 1B parameter VLA with flow-matching and gated self-attention.

Shiyuan Yang, Borong Zhang, Jizheng Zhang +5

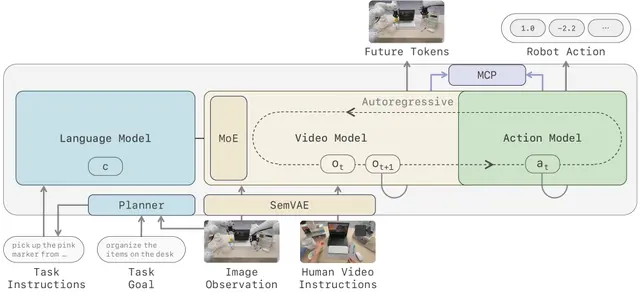
New Metric Measures How Human-Like and Comfortable Robot Movements Are
Robotics12 jul

New Metric Measures How Human-Like and Comfortable Robot Movements Are

Researchers have developed a quantitative index that scores any robot arm movement on how human-like and comfortable it feels — without needing human surveys…

Rosanna Coccaro, Enrico Ferrentino, Antonio Parziale +2

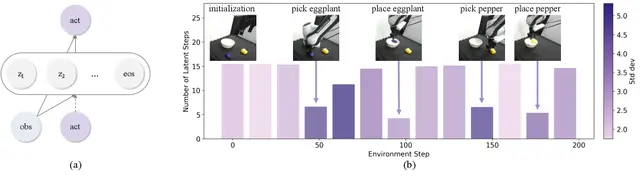
Native Video-Action Pretraining for Generalizable Robot Control
Robotics11 jul

Native Video-Action Pretraining for Generalizable Robot Control

Qihang Zhang, Lin Li, Luyao Zhang +26

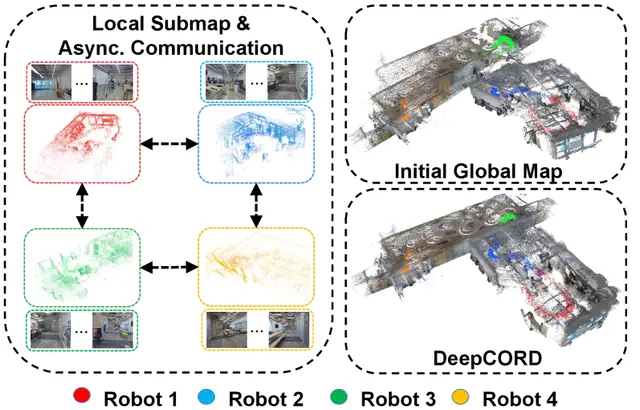
Latent Memory Palace: Teaching Robots to Reason Like Humans With Adaptive Compute
AI11 jul

Latent Memory Palace: Teaching Robots to Reason Like Humans With Adaptive Compute

Chuning Zhu, Eva Xu, Jose Barreiros +3

DeepCORD: Learning Adaptive Distributed Optimizers for Multi-Robot SLAM
Robotics11 jul

DeepCORD: Learning Adaptive Distributed Optimizers for Multi-Robot SLAM

DeepCORD learns to solve distributed factor graph optimization for multi-robot SLAM, outperforming hand-tuned solvers on 21 of 26 pose graph benchmarks.

Jaeho Shin, Maani Ghaffari, Yulun Tian

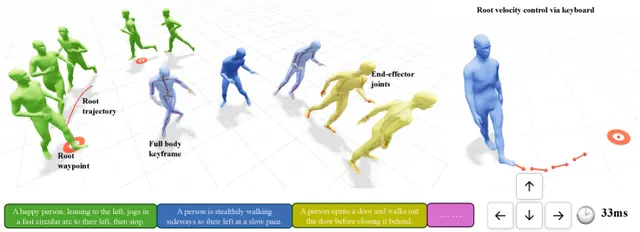
ARDY: Autoregressive Diffusion Model for Interactive Human Motion Generation
AI10 jul

ARDY: Autoregressive Diffusion Model for Interactive Human Motion Generation

We propose ARDY, an autoregressive diffusion model that enables interactive and controllable human motion generation. ARDY natively supports online text prom…

Kaifeng Zhao, Mathis Petrovich, Haotian Zhang +3

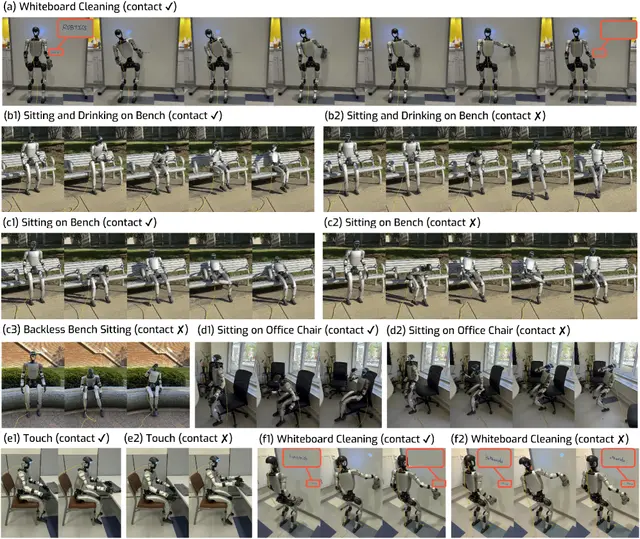
Humanoid Robots Learn to Control Object Contact Through Motion Mimicry
Humanoid10 jul

Humanoid Robots Learn to Control Object Contact Through Motion Mimicry

Xinyao Li, Xialin He, Runpei Dong +1

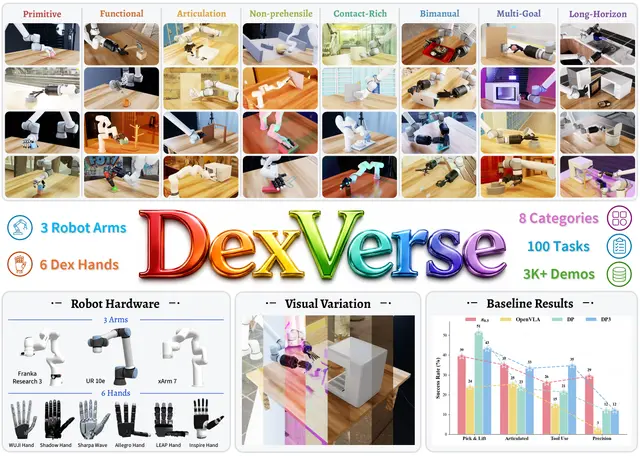
DexVerse: A Modular Benchmark for Multi-Task, Multi-Embodiment Dexterous Manipulation
Robotics10 jul

DexVerse: A Modular Benchmark for Multi-Task, Multi-Embodiment Dexterous Manipulation
Yunchao Yao, Zhuxiu Xu, Tianqi Zhang +12

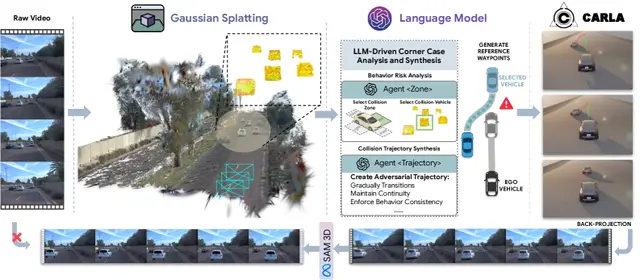
CARLA-GS: Decoupled AI Pipeline Synthesizes Rare Driving Scenarios from Real Data
AI9 jul

CARLA-GS: Decoupled AI Pipeline Synthesizes Rare Driving Scenarios from Real Data

CARLA-GS introduces a modular framework that decouples visual reconstruction, semantic reasoning, and physics simulation to autonomously generate rare but sa…

Kaicong Huang, Meng Ma, Ruimin Ke

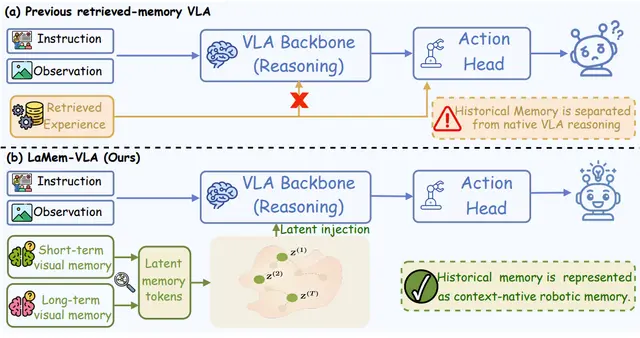
Dual Latent Memory Gives Robot Arms Sharper Long-Horizon Skills
Robotics9 jul

Dual Latent Memory Gives Robot Arms Sharper Long-Horizon Skills

Dual Latent Memory boosts VLA robot success on 10-step tasks from 12% to 82% by adding short- and long-term memory banks.

Hongyu Qu, Jianzhe Gao, Xiaobin Hu +6

Elephant Trunk Inspires ELEANOR: A Soft Architected Arm for Grasping
Robotics9 jul

Elephant Trunk Inspires ELEANOR: A Soft Architected Arm for Grasping

Giovanna A. Naselli, Anderson B. Nardin, Seonggun Joe +6

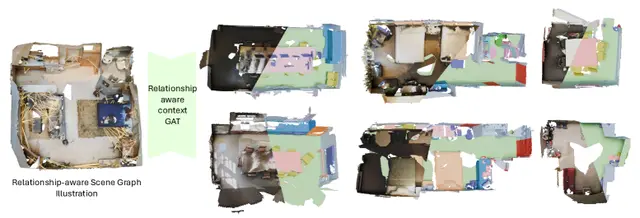
Beyond Isolated Objects: How 3D Scene Graphs Unlock Smarter Open-Vocabulary Robot Perception
Robotics8 jul

Beyond Isolated Objects: How 3D Scene Graphs Unlock Smarter Open-Vocabulary Robot Perception
Xianhao Chen, Jiarui Hu, Yuanbo Yang +5

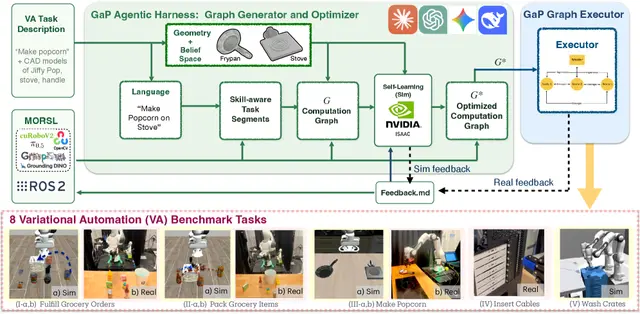
GaP: A Graph-Based Multi-Agent System for Variational Automation Tasks
AI8 jul

GaP: A Graph-Based Multi-Agent System for Variational Automation Tasks

GaP uses a graph-structured multi-agent system for variational automation, achieving 90%+ success on real manipulation tasks.

Kaiyuan Chen, Shuangyu Xie, Letian Fu +21

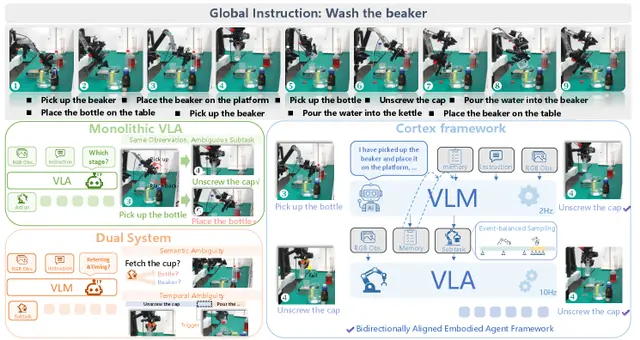
Cortex Framework: How a Bidirectional AI Solves Long-Horizon Robot Manipulation
AI8 jul

Cortex Framework: How a Bidirectional AI Solves Long-Horizon Robot Manipulation

Cortex uses a dual-system framework (VLM planner + VLA executor) with a structured subtask interface to overcome long-horizon manipulation failures and enable zero-shot error recovery.

Jiaqi Peng, Xiqian Yu, Delin Feng +10

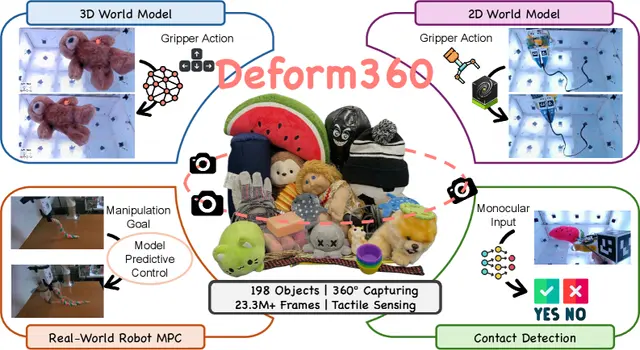
Deform360 Dataset Brings 41 Cameras and Touch Sensing to Deformable Object Robotics
Robotics7 jul

Deform360 Dataset Brings 41 Cameras and Touch Sensing to Deformable Object Robotics
Hongyu Li, Wanjia Fu, Xiaoyan Cong +11

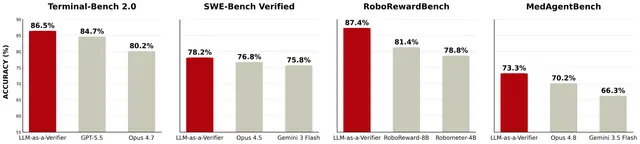
LLM-as-a-Verifier: A General Purpose Framework for Checking Robot and AI Outputs
AI7 jul

LLM-as-a-Verifier: A General Purpose Framework for Checking Robot and AI Outputs

Jacky Kwok, Shulu Li, Pranav Atreya +6

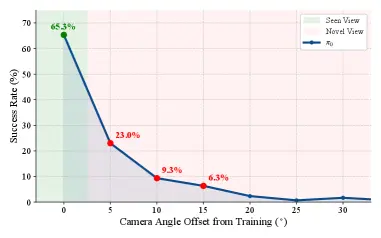
Robots That Adapt to Any Camera Viewpoint Without Calibration
AI7 jul

Robots That Adapt to Any Camera Viewpoint Without Calibration

CamVLA gives robots the ability to follow visual commands from any camera angle without needing recalibration or external camera data. By separating viewpoin…

Wenhao Li, Xueying Jiang, Quanhao Qian +4

Affordable Drones Get Smarter: Real-Time Vision on a $100 UAV
drones6 jul

Affordable Drones Get Smarter: Real-Time Vision on a $100 UAV

Researchers strapped three AI vision capabilities—face detection, face recognition, and monocular depth estimation—onto a DJI Tello drone costing under $100.…

Andrei-Marian Ungureanu, Stelian Spînu

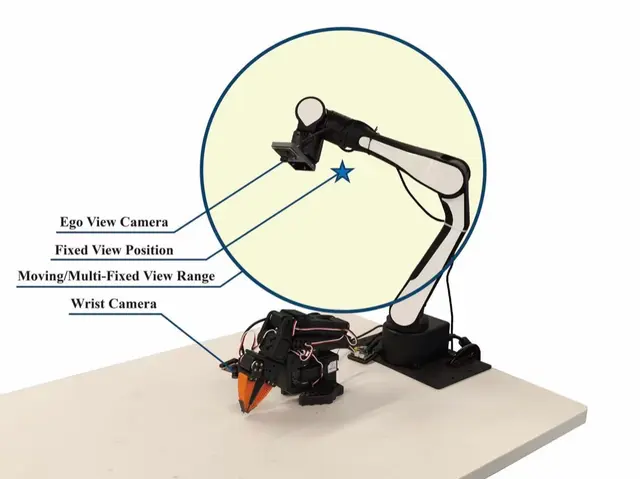
The Moving Eye: How Dynamic Camera Data Prevents Robot Vision Shortcuts
Robotics6 jul

The Moving Eye: How Dynamic Camera Data Prevents Robot Vision Shortcuts

Jincheng Tang, Yilong Zhu, Zhengyuan Xie +2