Papers tar-riċerka
Sommarji b’lingwaġġ sempliċi tal-aħħar riċerka fir-robotika — robots umanojdi, robots kwadrupedi, awtomazzjoni industrijali u AI.
AIOtt 7
Online Filtered Q-Gradients Speed Up Robot Flow Policy Training by 10x
AIOtt 6
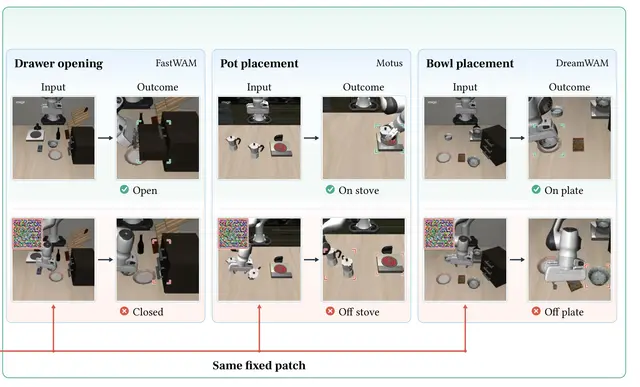
Transferable Adversarial Patches Disrupt World Action Models in Simulated Robot Tasks
AIOtt 6
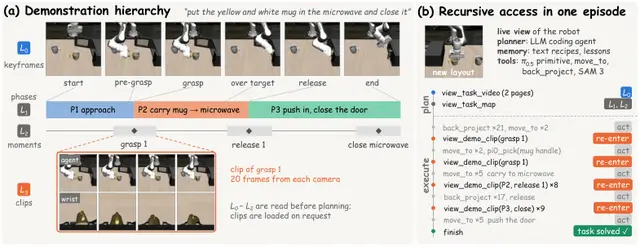
Recursive Video In-Context Learning Helps Robots Handle Long-Horizon Tasks
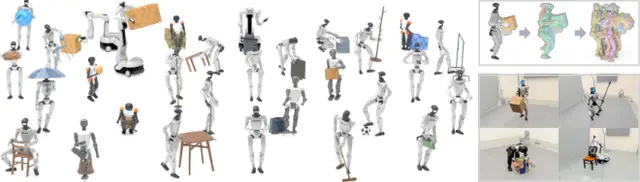
HumanoidOtt 6
How Humanoid Robots Grow Whole-Body Skills From Their Own Motion Data
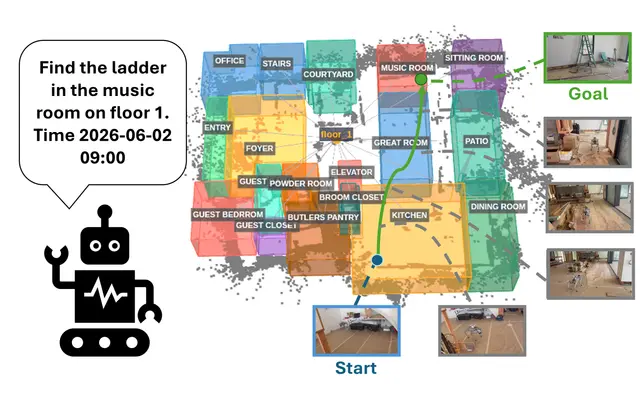
RoboticsOtt 5
How Robots Navigate Active Sites as Work Zones and Hazards Change
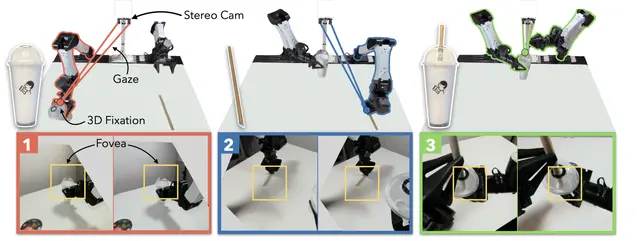
AIOtt 5
How Active Gaze Helps Robots Manipulate Precisely Without Wrist-Mounted Cameras
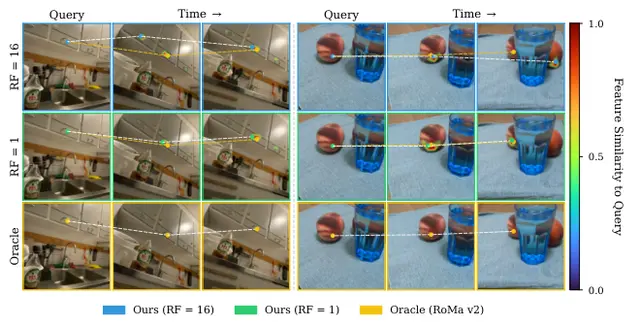
AIOtt 5
Geometric Learning from Novel Views with Lean Decoders and Strong Encoders
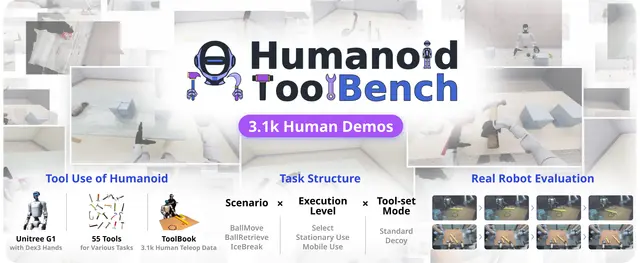
HumanoidOtt 4
Can Humanoid Robots Choose Tools and Complete Tasks While Moving Reliably?
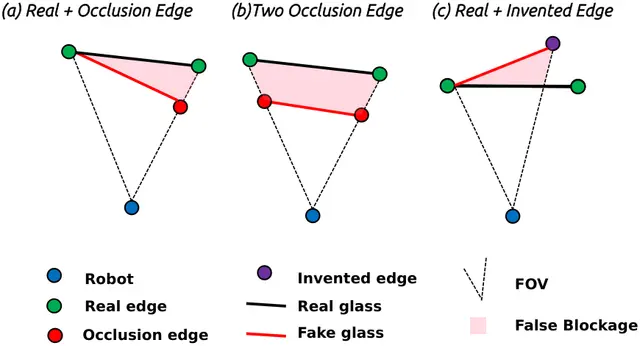
RoboticsOtt 4
How GlassGuard Helps Mobile Robots Map Glass Without Blocking Safe Paths
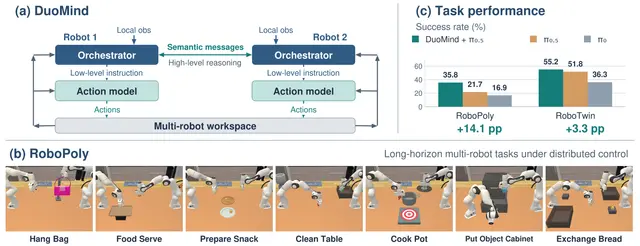
AIOtt 4
How DuoMind Helps Two Robots Coordinate With Shared Language
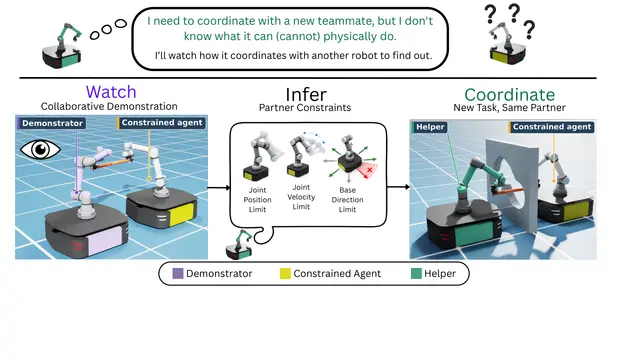
AIOtt 3
How Robots Learn Partner Limits for Safer Teamwork on New Tasks

AIOtt 3
FERPO Trains Robot Policies With Better Action Coverage, Faster Updates
AIOtt 3
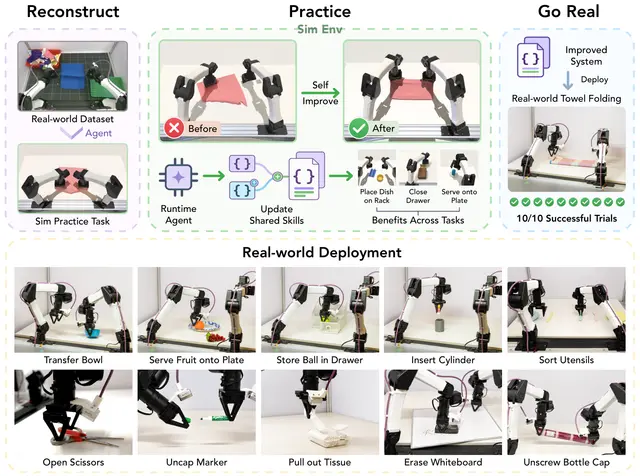
How RPG Helps Embodied Agents Improve Robot Skills Through Practice
RoboticsOtt 2
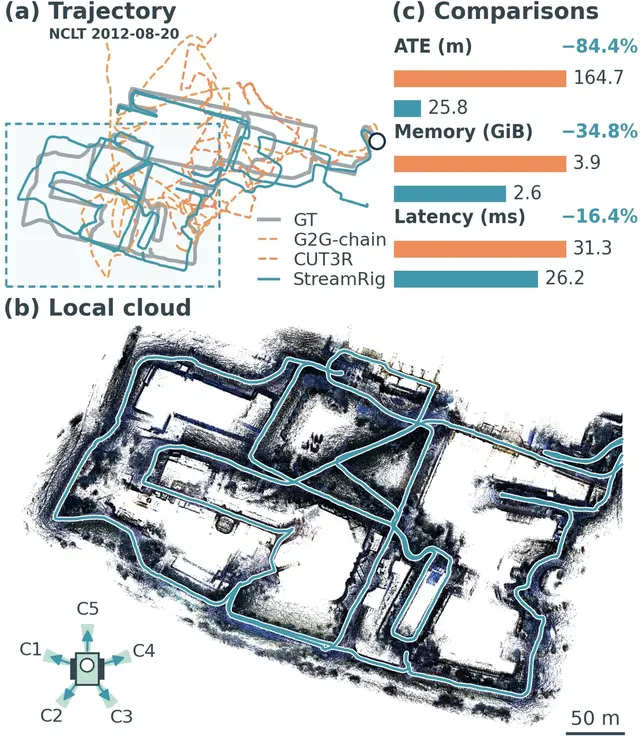
StreamRig Uses Intra-Rig Geometry for Streaming Multi-Camera Odometry
AIOtt 2
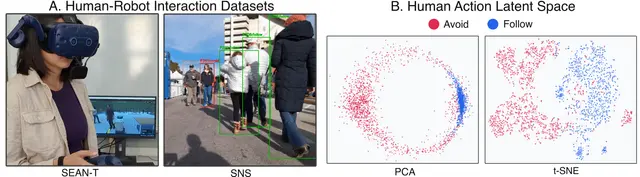
How STARS Helps Robots Read Social Intent from Human Motion Cues
AIOtt 2
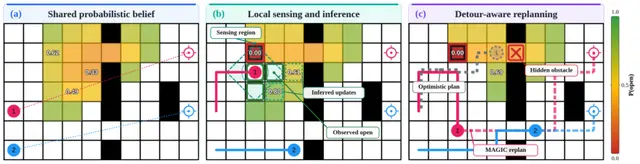
How Robot Teams Plan Safer Routes When Maps Hide Blocked Paths
RoboticsOtt 1
GPU Planning Helps Robots Pick Better Paths in Unknown Environments
AIOtt 1
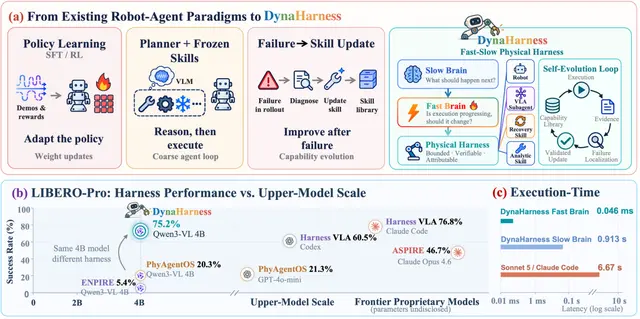
How a Physical Robot Harness Helps Agents Recover, Switch, and Learn
RoboticsOtt 1