Papers tar-riċerka

Sommarji b’lingwaġġ sempliċi tal-aħħar riċerka fir-robotika — robots umanojdi, robots kwadrupedi, awtomazzjoni industrijali u AI.
499 papers
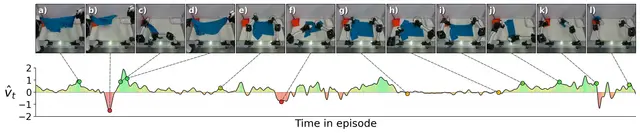
WARP-RM: Self-Supervised Robot Task Progress Estimation with Video Time-Warping
RoboticsĠun 29

WARP-RM: Self-Supervised Robot Task Progress Estimation with Video Time-Warping

Justin Yu, Andrew Goldberg, Kavish Kondap, Karim El-Refai +6

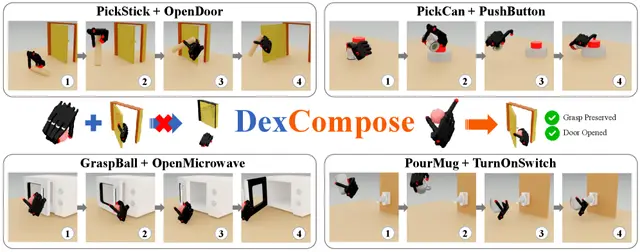
DexCompose Lets One Robot Hand Chain Dexterous Skills Without Retraining
AIĠun 29

DexCompose Lets One Robot Hand Chain Dexterous Skills Without Retraining

DexCompose composes dexterous manipulation policies on a single hand without retraining, achieving over 90% success using finger-aware masking and dual residual stabilizers.

Dihong Huang, Zhenyu Wei, Zhuxiu Xu +3

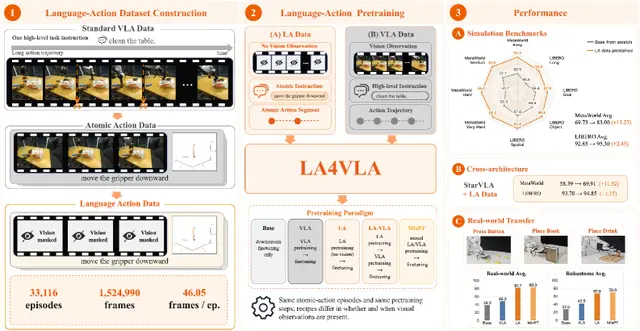
LA4VLA: Teaching Robots to Follow Instructions Without Seeing
RoboticsĠun 28

LA4VLA: Teaching Robots to Follow Instructions Without Seeing

Recent vision-language-action (VLA) models have a hidden weakness: they often rely on visual cues rather than truly understanding language instructions. A ne…

Tao Lin, Yuxin Du, Yiran Mao +13

OctoSense: Self-Supervised Learning Unifies 8 Sensors for Robust Robot Perception
RoboticsĠun 28

OctoSense: Self-Supervised Learning Unifies 8 Sensors for Robust Robot Perception

Anthony Bisulco, Jeremy Wang, Kostas Daniilidis +2

Hallucination in World Models is Predictable and Preventable
AIĠun 28

Hallucination in World Models is Predictable and Preventable

Nicklas Hansen, Xiaolong Wang

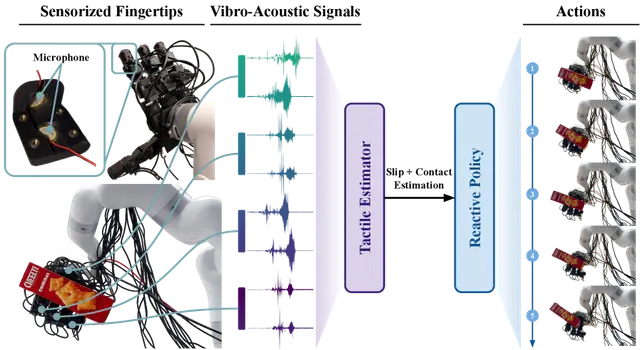
VibeAct: Using Vibration to Enable Reactive Robot Hand Dexterity
RoboticsĠun 27

VibeAct: Using Vibration to Enable Reactive Robot Hand Dexterity

Open-world manipulation requires rapid responses to contact and slip events. When a fingertip first makes contact, or when a grasp transitions from sticking …

Yuemin Mao, Uksang Yoo, Jean Oh +2

New Reinforcement Learning Method Lets Drones Race Fast in Unseen Tracks Without Retraining
RoboticsĠun 27

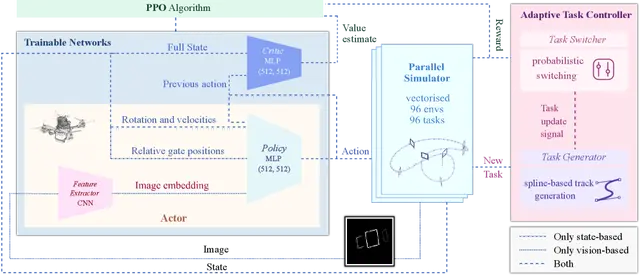
New Reinforcement Learning Method Lets Drones Race Fast in Unseen Tracks Without Retraining
Researchers show reinforcement learning for drone racing can achieve zero-shot generalization without sacrificing speed.

Jonathan Green, Jiaxu Xing, Nico Messikommer +2

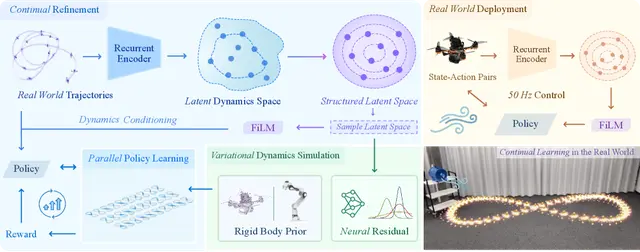
Continual Robot Learning: Adapting to Changing Dynamics in Real Time
RoboticsĠun 27

Continual Robot Learning: Adapting to Changing Dynamics in Real Time

Jiaxu Xing, Zhiyuan Zhu, Yunfan Ren +4

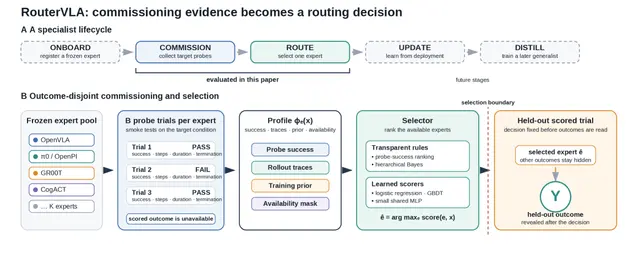
RouterVLA: Using Routine Smoke Tests to Pick the Best Robot VLA Model
RoboticsĠun 26

RouterVLA: Using Routine Smoke Tests to Pick the Best Robot VLA Model

Xingyu Ren, Chugang Yi, Ge Ma +1

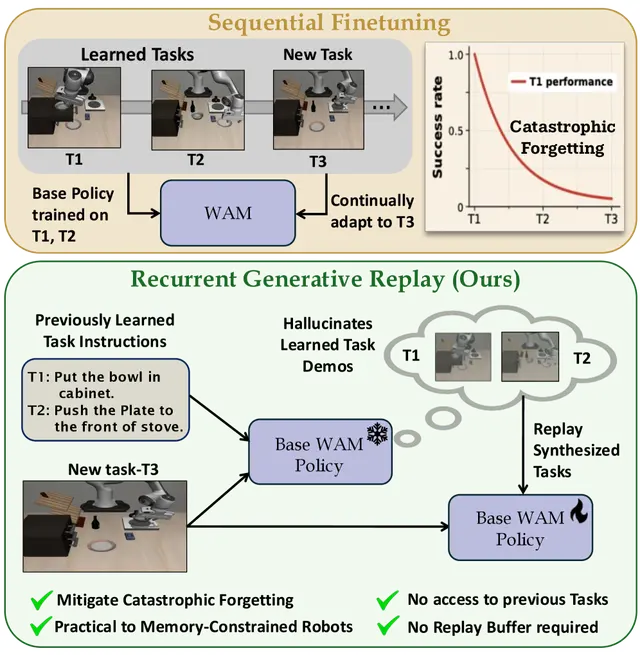
World Action Models Use Generative Replays to Prevent Robot Forgetting
RoboticsĠun 26

World Action Models Use Generative Replays to Prevent Robot Forgetting

We presented Recurrent Generative Replay (ReGen), the first continual learning framework to leverage the generative capabilities of World Action Models (WAMs…

Manish Kumar Govind, Dominick Reilly, Smit Patel +2

Massive Open Dataset and Toolkit for Robot Behavior Cloning
RoboticsĠun 26

Massive Open Dataset and Toolkit for Robot Behavior Cloning

ABC stack releases 130K-episode teleoperation dataset and open-source toolkit for scalable robot behavior cloning.

Arthur Allshire, Himanshu Gaurav Singh, Ritvik Singh +15

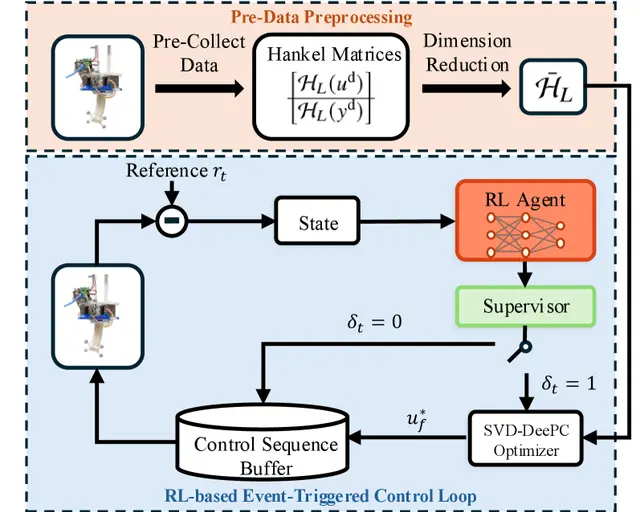
Deep Reinforcement Learning Makes Cable-Driven Soft Robot Arms More Computationally Efficient
RoboticsĠun 25

Deep Reinforcement Learning Makes Cable-Driven Soft Robot Arms More Computationally Efficient
Cheng Ouyang, Moeen Ul Islam, Kaixiang Zhang +3

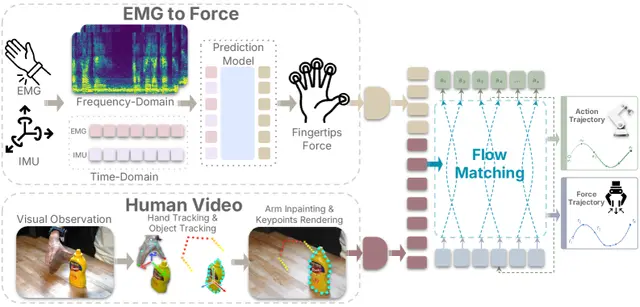
ForceBand: Learning Forceful Robot Manipulation Through Muscle Sensing
RoboticsĠun 25

ForceBand: Learning Forceful Robot Manipulation Through Muscle Sensing

Botao He, Zhi Wang, Linna Kuang +8

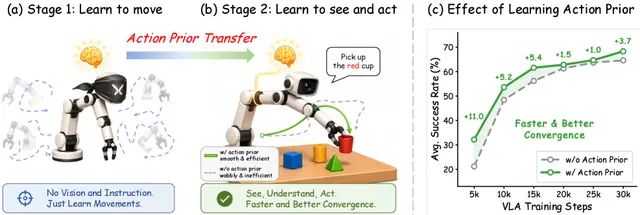
Robots Learn the Feel of Movement Before Learning to See and Act
AIĠun 25

Robots Learn the Feel of Movement Before Learning to See and Act

A two-stage training framework introduces a dedicated action prior learning stage before vision-language-action (VLA) training. By training a flow-matching-b…

Dong Jing, Tianqi Zhang, Jiaqi Liu +5

OpenReLoc: Object-Level Camera Relocalization with Open-Vocabulary Understanding
RoboticsĠun 24

OpenReLoc: Object-Level Camera Relocalization with Open-Vocabulary Understanding

OpenReLoc uses open-vocabulary object matching and LLM descriptions to robustly estimate camera pose from a single image, outperforming closed-vocabulary methods on real indoor scenes.

Zhaopeng Cui, Jiarui Hu, Jingbo Liu +7

Vision-Language Model Gives Warehouse Robots Context-Aware Semantic Maps
WarehouseĠun 24

Vision-Language Model Gives Warehouse Robots Context-Aware Semantic Maps

Marvin Rüdt, Hao Pang, Constantin Enke +2

InSight: How Robots Learn New Skills Without Human Help
AIĠun 24

InSight: How Robots Learn New Skills Without Human Help

Maggie Wang, Lars Osterberg, Stephen Tian +3

Robots Learn Physical Reasoning from Scalable Human Hand Data
RoboticsĠun 23

Robots Learn Physical Reasoning from Scalable Human Hand Data

Researchers have developed LaST-HD, a framework that lets robots learn complex manipulation skills by observing human hand demonstrations. By aligning human …

Jiaming Liu, Yinxi Wang, Chenyang Gu +15

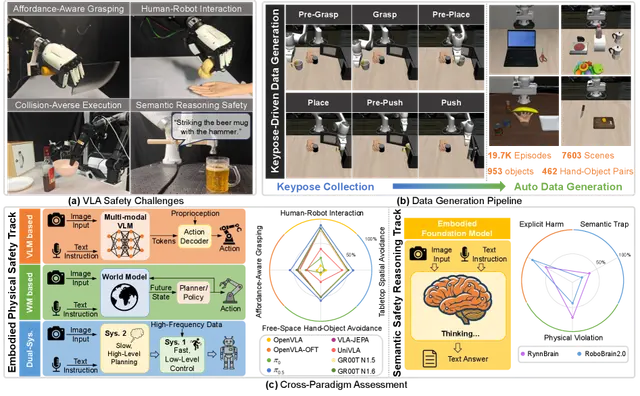
LIBERO-Safety Benchmark Puts Vision-Language-Action Robots Through Physical and Semantic Safety Tests
RoboticsĠun 23

LIBERO-Safety Benchmark Puts Vision-Language-Action Robots Through Physical and Semantic Safety Tests

Researchers introduced LIBERO-Safety, a comprehensive benchmark that systematically evaluates how vision-language-action (VLA) models handle physical safety …

Rongxu Cui, Zongzheng Zhang, Jingrui Pang +11

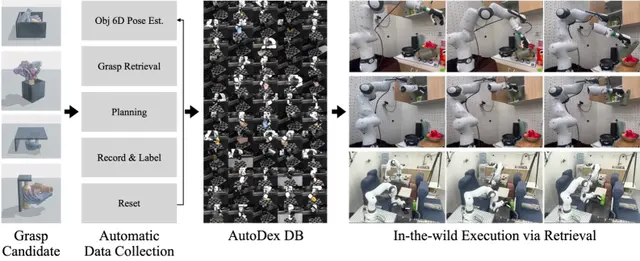
AutoDex: Fully Automated Dexterous Grasping Data Collection at 75+ Trials Per Hour
AIĠun 23

AutoDex: Fully Automated Dexterous Grasping Data Collection at 75+ Trials Per Hour

Mingi Choi, Gunhee Kim, Jisoo Kim +4