研究Papers
最新のロボティクス研究をわかりやすく要約 — ヒューマノイドロボット、四足歩行ロボット、産業オートメーション、AI。
Robotics6月14日
Navigation World Action Model for Goal-Conditioned Visual Navigation
Robotics6月14日
SPARC: Reliable Spatial Annotations from Robot Demonstrations at Scale
AI6月14日
Heterogeneous LiDAR Early Fusion and Learned Re-Ranking for Robust Long-Term Place Recognition
AI6月13日
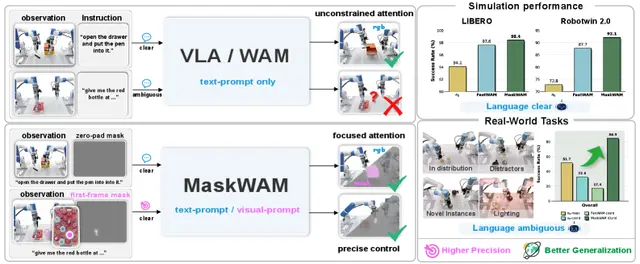
MaskWAM Teaches Robots to Predict What Matters for Better Manipulation
AI6月13日
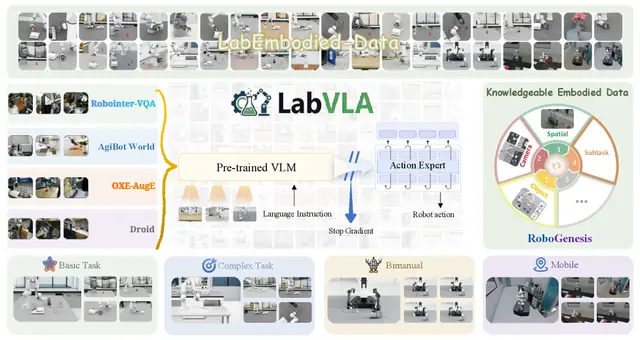
LabVLA Brings Vision-Language-Action Models to Lab Automation
Robotics6月13日
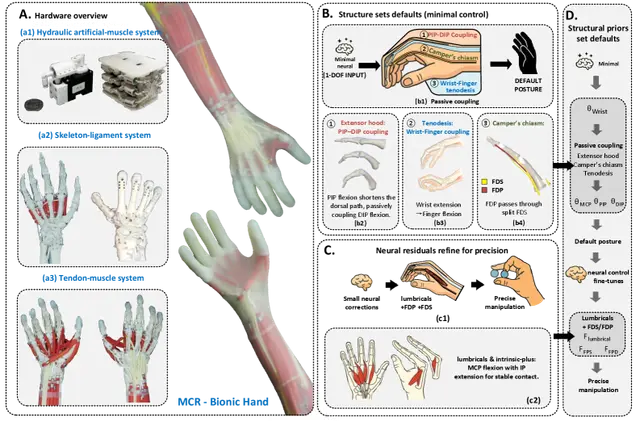
MCR-Bionic Hand: How Anatomical Structure Unlocks Dexterous Robot Manipulation

Robotics6月12日
Weaver: A Fast and Scalable World Model for Robotic Manipulation
Robotics6月12日
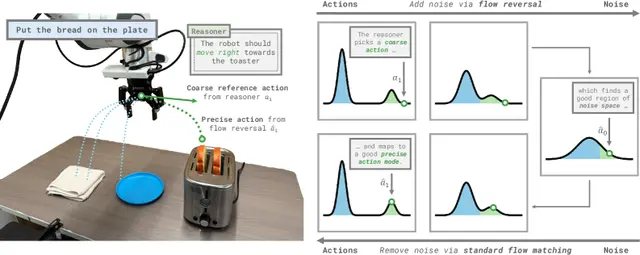
Flow Reversal Steering Makes Robot Generalists Better at Following High-Level Guidance
AI6月12日
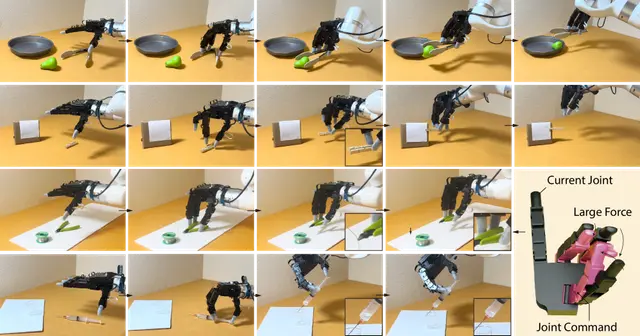
Mana: A New System for Dexterous Robot Manipulation of Articulated Tools
AI6月11日
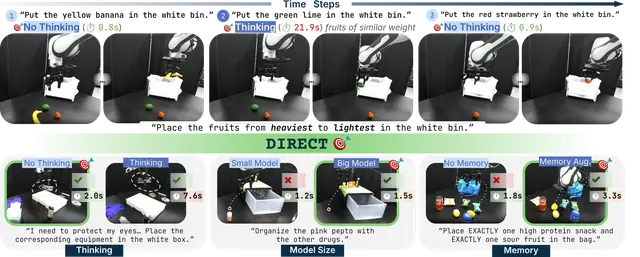
When and Where Should You Allocate Test-Time Compute in Embodied Planners?
Robotics6月11日
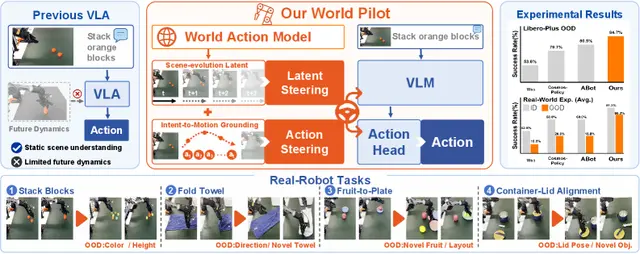
World Pilot Gives Vision-Language-Action Robots a World-Action Model Boost
AI6月11日
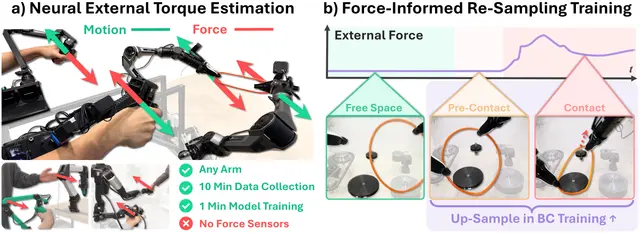
New Method Gives Cheap Robot Arms Force Feedback Without Extra Sensors
Humanoid6月10日
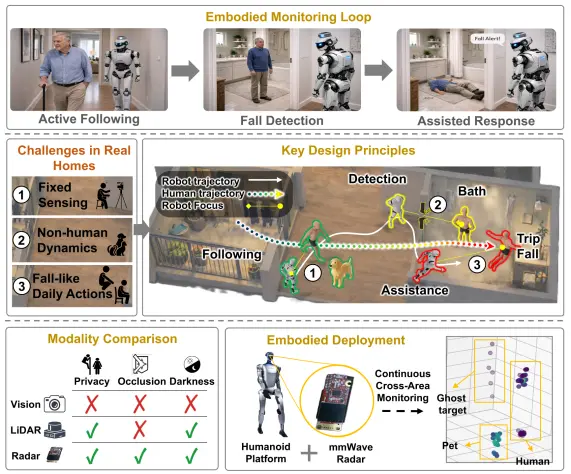
Embodied mmWave Radar on Humanoid Robots Enables 24/7 Fall Detection
Robotics6月10日
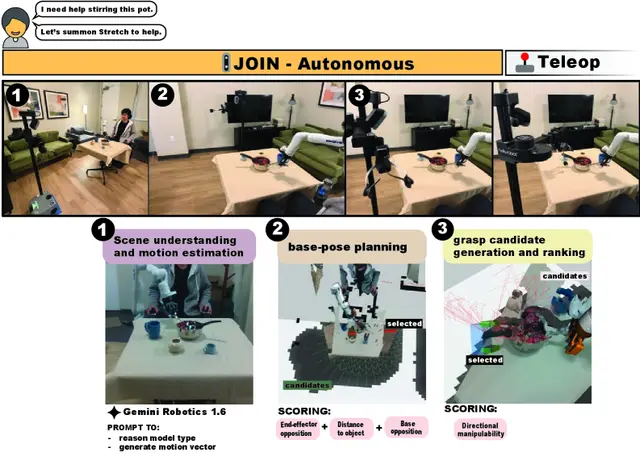
Bimanual Joining System Lets Wheelchair Robots Call for Backup
Robotics6月10日
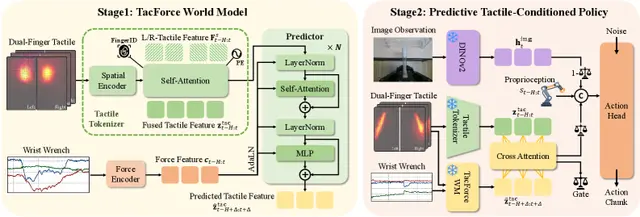
TacForeSight Predicts Tactile Feedback From Force Data for Better Robot Handling
AI6月9日
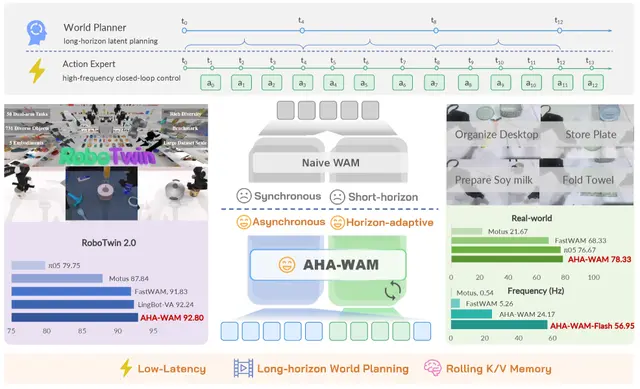
AHA-WAM: Asynchronous World-Action Model for Faster, Smarter Robot Manipulation
Robotics6月9日
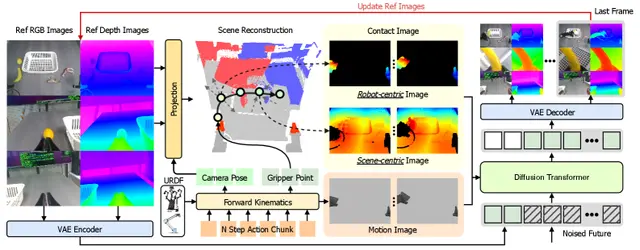
How Robots Turn Actions Into Motion and Contact Images for Better World Models
Robotics6月9日
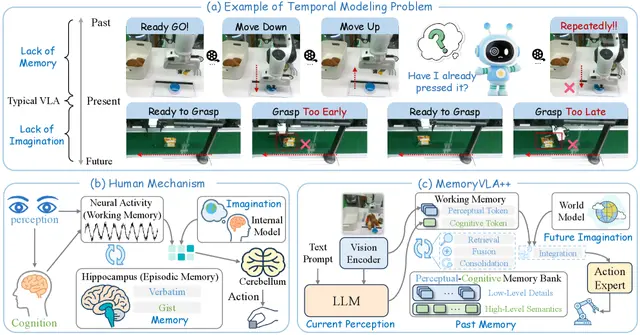
MemoryVLA++ Equips Robots with Memory and Imagination for Complex Tasks
AI6月8日