研究Papers
最新のロボティクス研究をわかりやすく要約 — ヒューマノイドロボット、四足歩行ロボット、産業オートメーション、AI。
AI7 日前
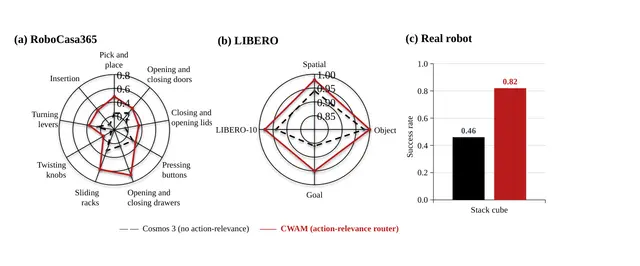
A Robot World Model Learns Which Objects Matter for Each Action
Humanoid7 日前
How Humanoids Learn to Escape Tight Spaces and Stand Up Safely
AI7 日前
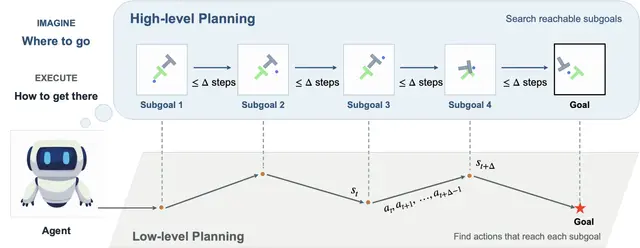
Hierarchical World Models Enable Reliable Long-Horizon Robot Planning with Implicit Dynamics
Robotics8 日前
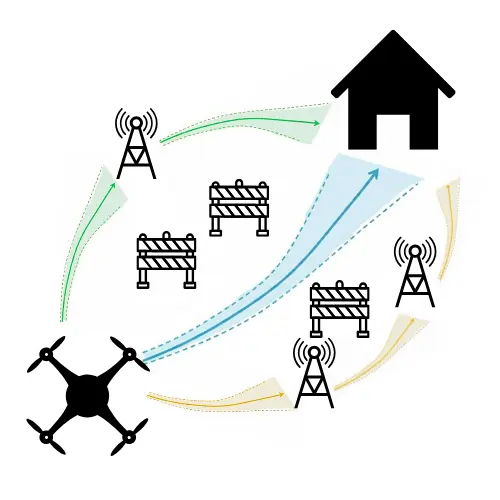
How Robots Plan Optimal Paths While Keeping Localization Uncertainty Below Limits
Robotics8 日前
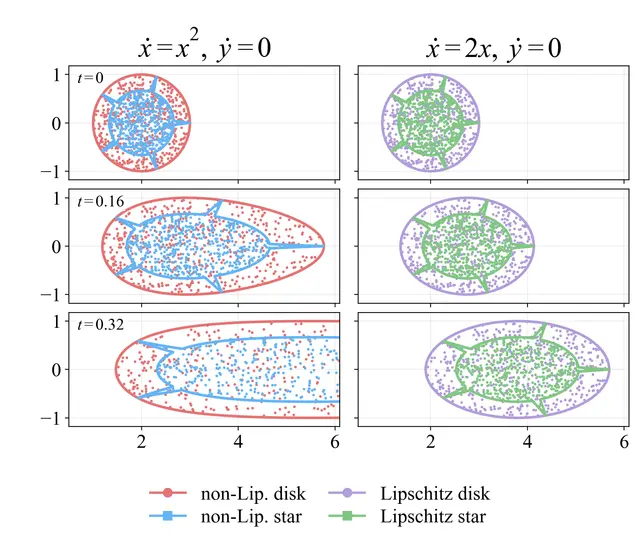
How Many Robot Simulations Are Needed to Map Every Reachable State?
AI8 日前
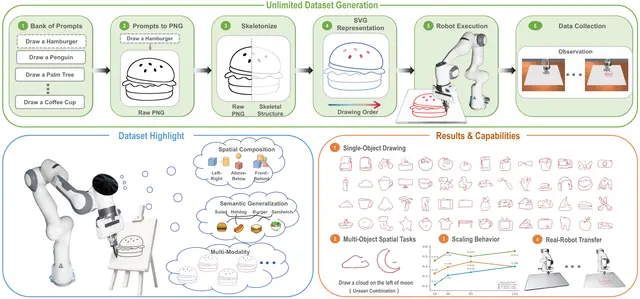
Can Robots Draw New Objects from Instructions? BURGER Tests VLA Generalization
Robotics9 日前
Robot Learns to Align, Latch, and Unfasten Screws with Force Feedback
Robotics9 日前
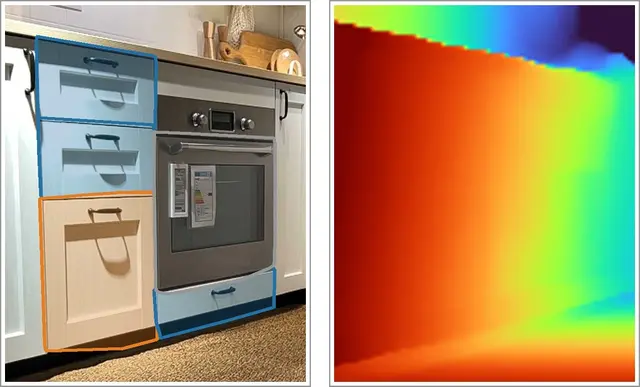
How Robots Learn Whether a Cabinet Door Swings or Slides Open
AI9 日前
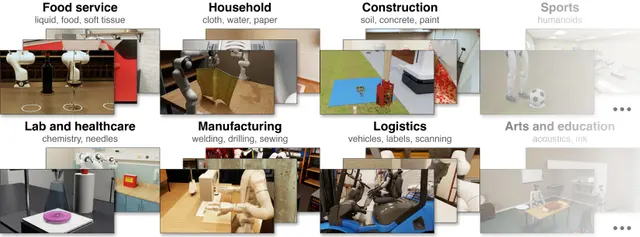
How Digital Agents Scale Realistic Physical Simulations for Better Robot Learning
Robotics10 日前
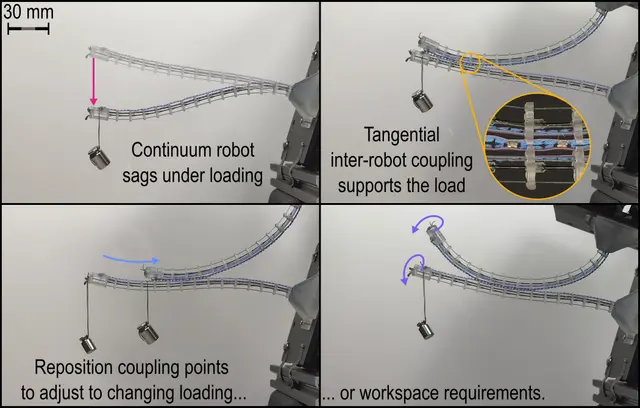
A Conveyor Belt Mechanism Enables Repositionable Magnetic Coupling Between Continuum Robots
Robotics10 日前
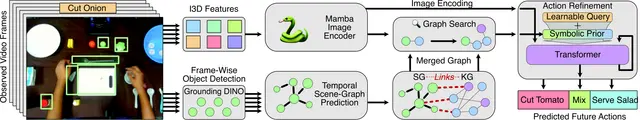
Symbolic Graphs Help Robots Predict Actions from Short Clips at Work
Robotics10 日前
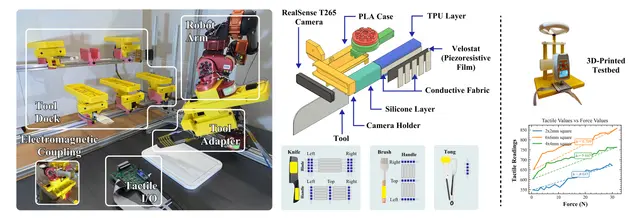
SwapBot Helps Robots Use Swappable Tools and Touch for Better Tasks
Robotics11 日前
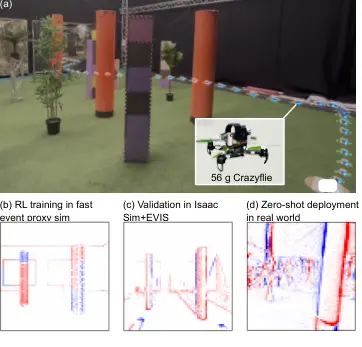
Rendering-Free Event Frame Simulation for Fast Reinforcement Learning in Drone Navigation
AI11 日前
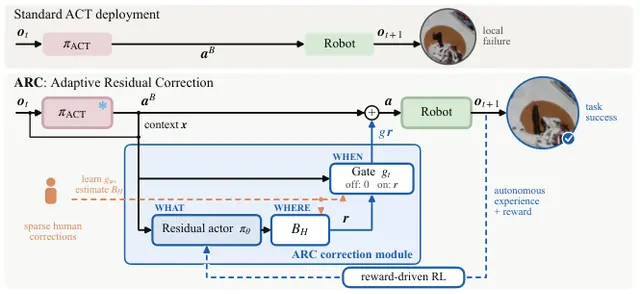
How Sparse Human Corrections Improve Precision in Existing Real-World Robot Policies
AI11 日前
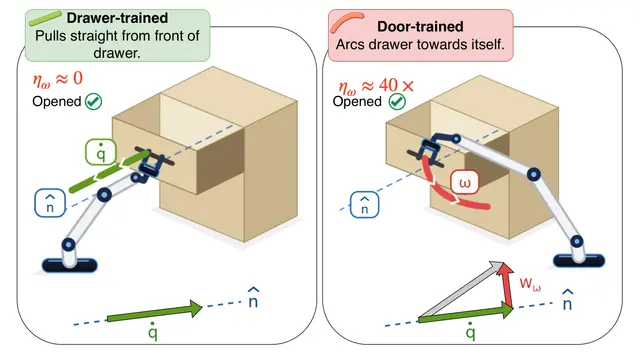
How to Evaluate Robot Manipulation Against Articulated Object Kinematic Constraints
Robotics12 日前
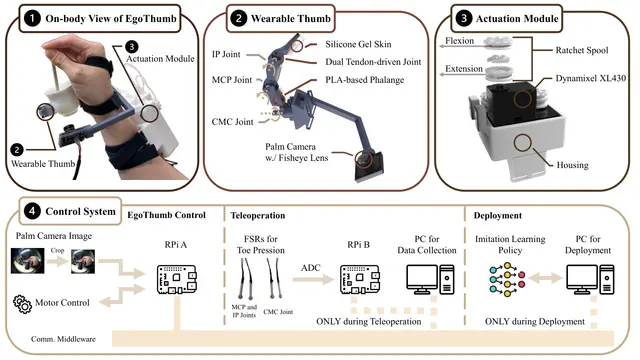
A Wearable Robotic Thumb Uses Vision to Grasp and Hold Objects
Robotics12 日前
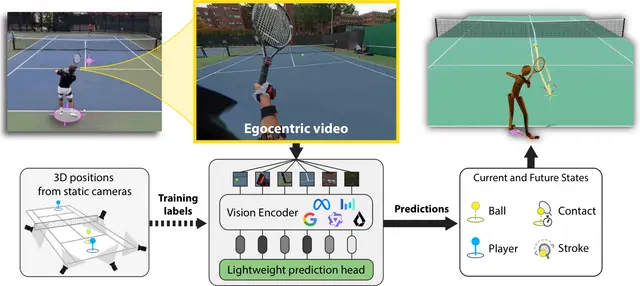
How Vision Models Track Tennis Balls and Predict Play in Motion
AI12 日前
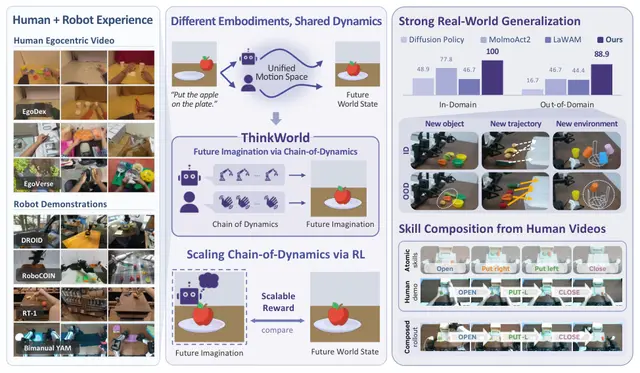
ThinkWorld Uses World Imagination to Strengthen Robot Action Reasoning
Robotics13 日前