Precio medio diario
Importes en USD


The MIDAS Hand Bundle is a DYNAMIXEL and ROBOTIS accessory bundle for building the open-source MIDAS Hand platform: a dexterous, anthropomorphic robotic hand designed for research, development, prototyping, and builders working with compact direct-drive actuation.
MIDAS Hand stands for Modular low-Impedance Direct-drive Anthropomorphic Sensing Hand. The platform is designed around a 16 DOF hand architecture with 13 active DYNAMIXEL actuators, providing a practical foundation for dexterous manipulation projects.
This bundle contains the core ROBOTIS components needed for the MIDAS Hand actuator and accessory stack. Additional parts, 3D printed components, assembly hardware, tools, and project-specific materials may be required.
| Quantity | Item |
|---|---|
| 1 | DYNAMIXEL Starter Kit |
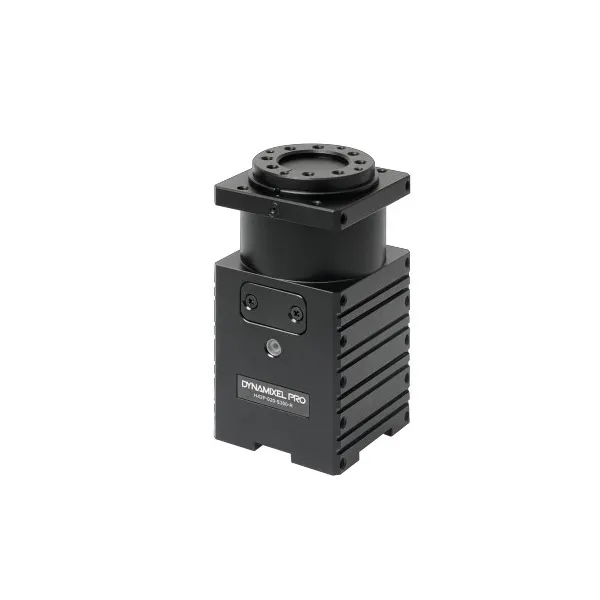
| 13 | DYNAMIXEL XM335-T323-T |
| 1 | Robot Cable-X3P 180MM (10pcs) |
3D printed parts are not included by default. Please contact us for 3D Printed Parts pricing.
MIDAS Hand is an open-source dexterous hand platform intended to make advanced robotic hand development more accessible. The project provides a practical release path for builders, including hardware files, CAD, assembly documentation, software resources, and a public bill of materials.
The platform is built for researchers, educators, developers, and robotics builders who need a capable anthropomorphic hand for experimentation in manipulation, sensing, teleoperation, grasping, and robotic interaction.
| Degrees of Freedom | 16 total DOF |
| Active DOF | 13 actuators |
| Estimated Build Time | More than 3 hours, depending on builder experience and assembly setup |
Watch the MIDAS Hand overview and project demonstration below.
The MIDAS Hand project was led and developed by the UCLA Robotics & Mechanisms Laboratory (RoMeLa).
RoMeLa is internationally recognized for advanced robotics research spanning humanoid robotics, robotic manipulation, wearable systems, medical robotics, and intelligent mechanisms. Their pioneering work has helped advance the state of the art in dexterous robotic systems and human-centered robotics research.
Visit UCLA RoMeLaHistorial de precios
Un punto de datos por día, calculado según la fecha de observación.
Importes en USD
Los promedios se calculan por día UTC a partir de todos los precios de oferta registrados.
Robotis
2567,92 €
Robotis
£2309,94

Robotis
£2383,12

Robotis
$2748,39

Robotis
$2748,39
Robotis
2197,97 €
Robotis
3291,54 €
Robotis
2171,94 €
Robotis
2151,54 €
Robotis
2247,09 €
Robotis
3292,20 €
Robotis
2026,05 €
🍪 Preferencias de cookies
Usamos cookies para medir el rendimiento. Política de privacidad