Leo Rover Developer Kit

Leo Rover Developer Kit 1.9

Leo Rover Developer Kit
Fictionlab | A-000000-04139
€5,758.80 VAT incl. €4,799.00 VAT excl.

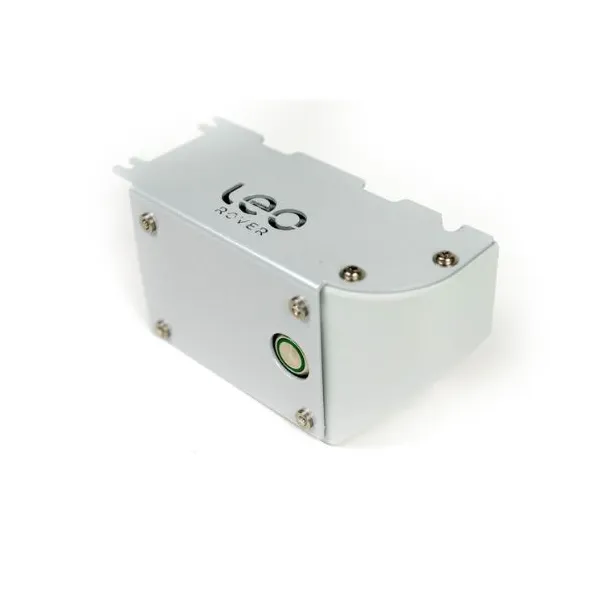
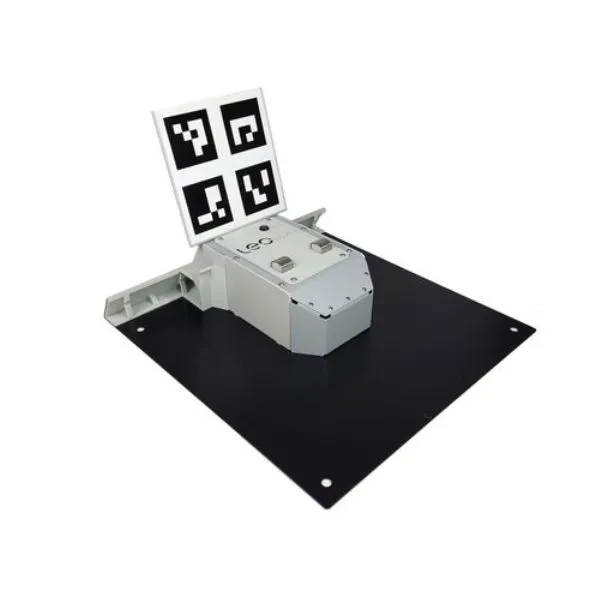
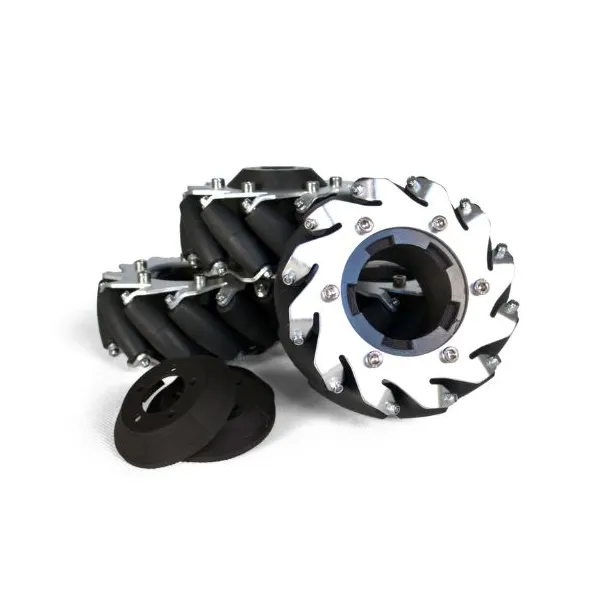
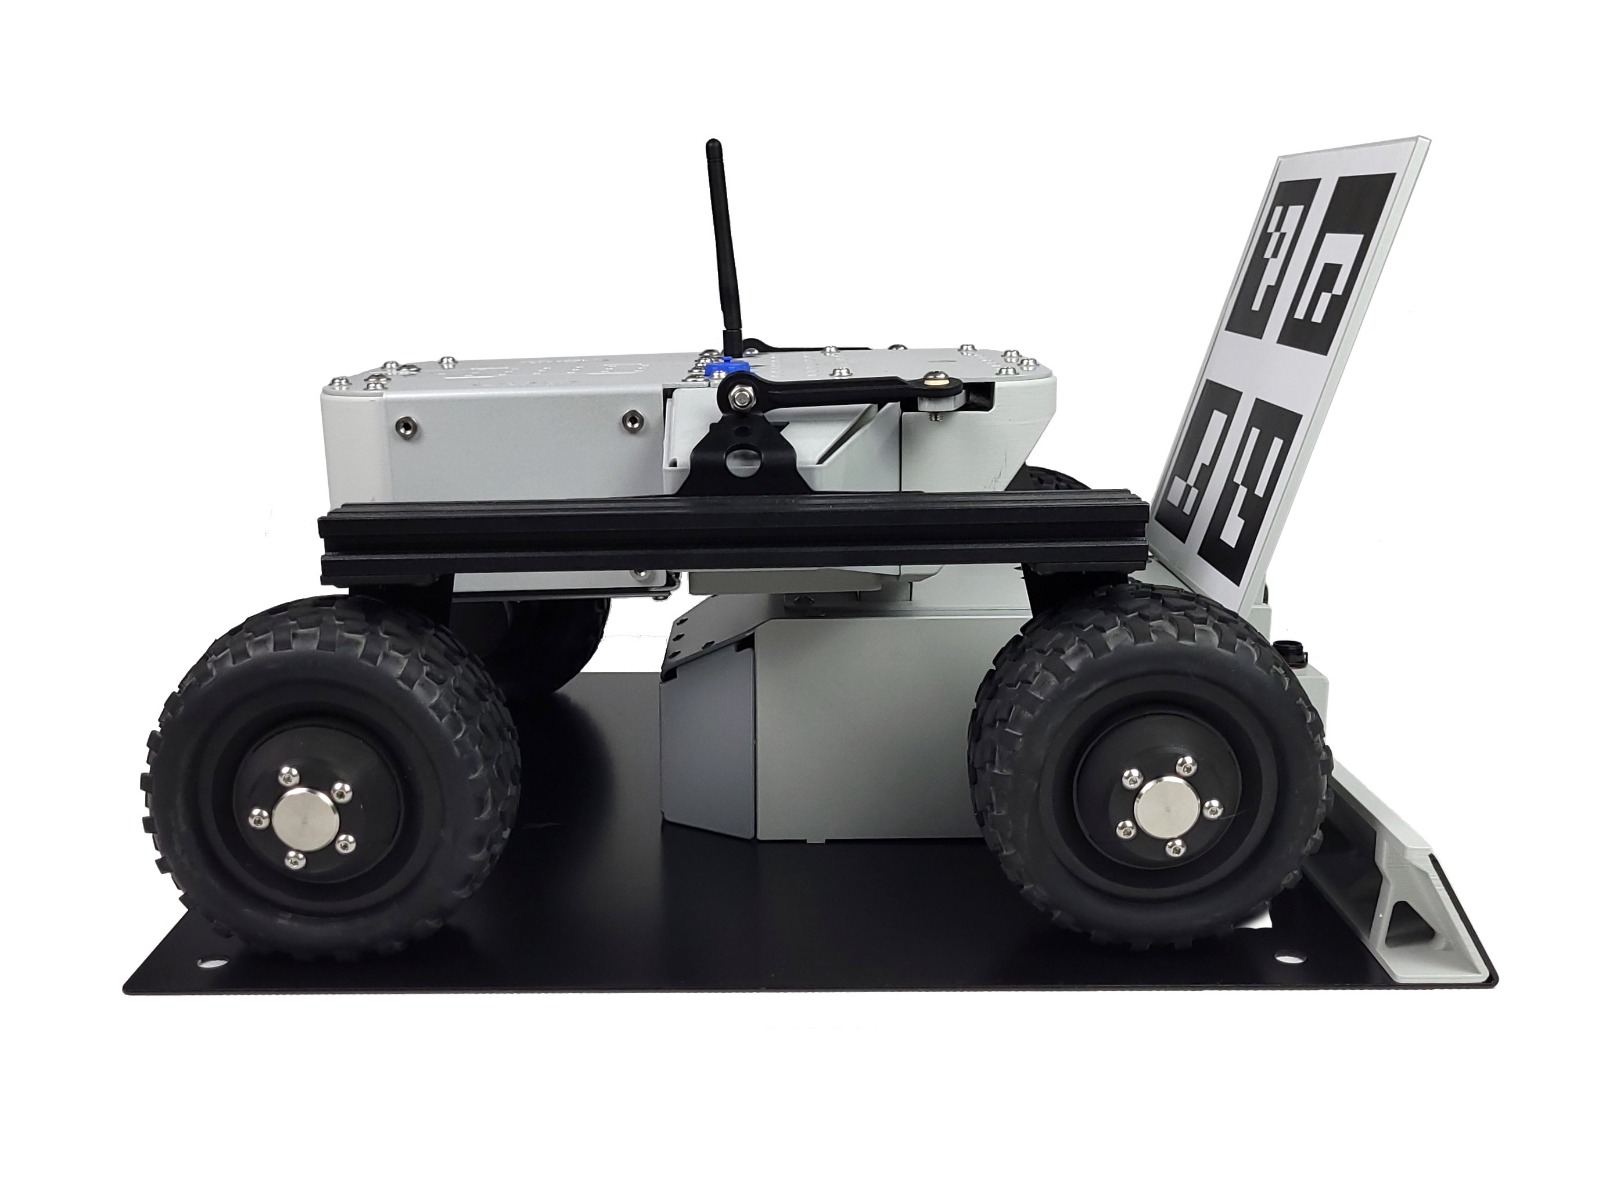
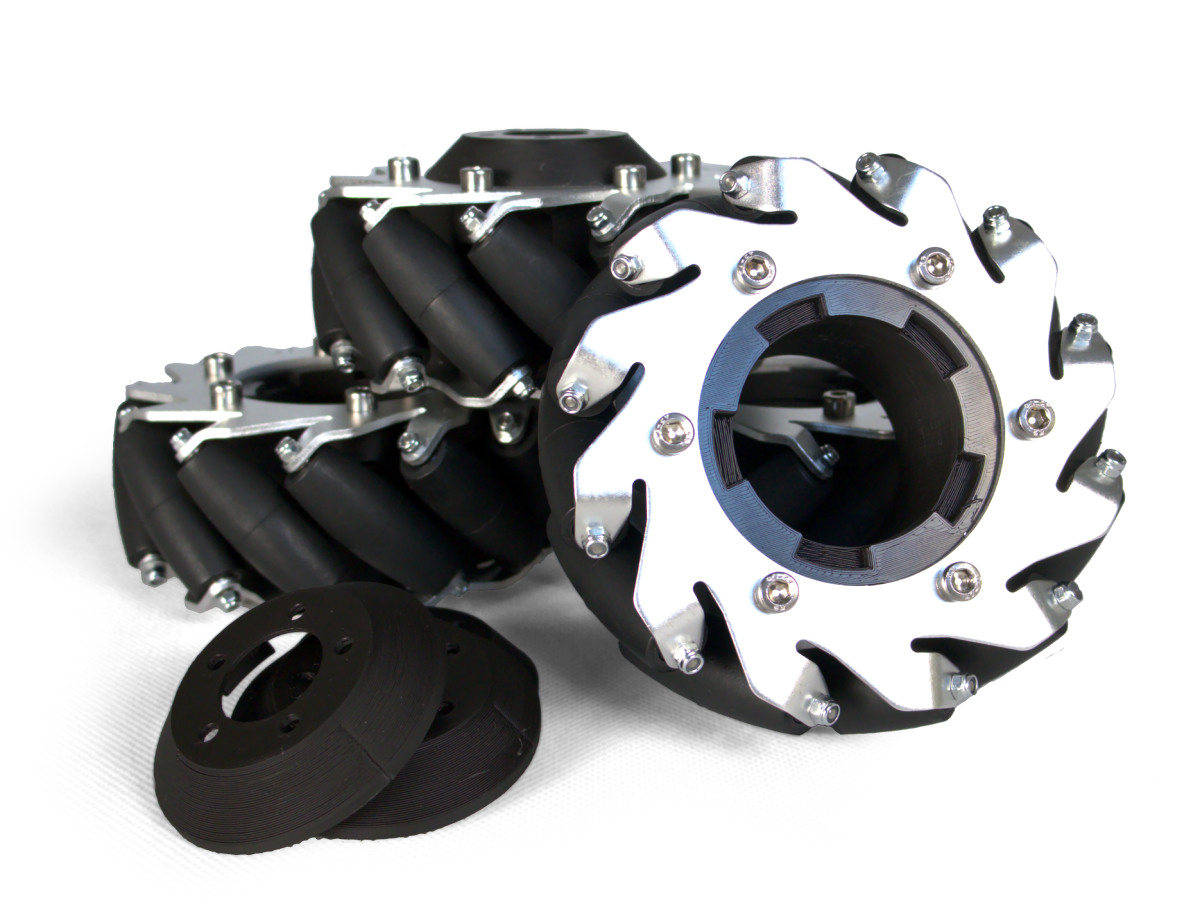
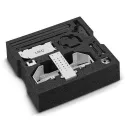
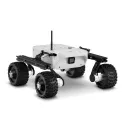
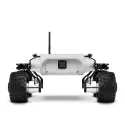
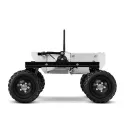
The Fictionlab Leo Rover 1.9 Developer Kit is an open-source 4x4 mobile robot kit designed for research, education, and robotics prototyping. Supplied with all the parts required for assembly, it provides a modular ROS 2 platform for developing and testing robotic applications both indoors and outdoors.

Quantity
2 Available

Get it in 24/48h! (see T&C)

Create a cart and turn it into a quote instantly!
Payment methods (see T&C)
Debit card
PayPal
Payment by invoice
Wire transfer

Leo Rover Developer Kit: an open platform for robotics R&D

  • 4x4 mobile robot to assemble: all parts required to build the Leo Rover 1.9 are included.
  • Native ROS 2 architecture: designed to integrate nodes, packages, and tools from the ROS 2 ecosystem.
  • Open-source platform: software and firmware released under the MIT license.
  • Payload of approximately 5 kg with standard tires.
  • Maximum speed of approximately 0.4 m/s.
  • Runtime of up to 4 hours with the standard battery.
  • IP55 protection against dust and water jets.
  • Rocker suspension and 4-wheel drive for operation on different types of terrain.
  • Modular design for adding sensors, actuators, onboard computers, and custom equipment.

The Developer Kit is particularly suited to laboratories, universities, engineering schools, and R&D teams looking for a robotic platform they can understand, modify, and adapt to their own projects.

A mobile robot to assemble for a better understanding of the platform

Unlike the assembled version, the Leo Rover Developer Kit is supplied as a set of components to assemble. Users build the robot’s mechanical structure, electronics, and various components before commissioning it.

This configuration is particularly relevant for education and training, as well as for teams that want full control over the hardware architecture of their platform in order to modify, maintain, or integrate it more easily into a specific robotic system.

Once assembled, the kit becomes a complete Leo Rover 1.9 with the same mechanical specifications and development capabilities as the pre-assembled platform.

ROS 2, open source et intégration de capteurs

The Leo Rover has been designed as a native ROS 2 platform. Its architecture makes it possible to use existing tools and packages from the ROS ecosystem while developing custom navigation, perception, or control functions.

The platform can also be used as a base for integrating a wide range of equipment:

  • 2D or 3D LiDAR for SLAM, localization, and autonomous navigation
  • RGB-D or stereo cameras for 3D perception and robot vision
  • GNSS for outdoor navigation projects
  • Environmental sensors for field data collection
  • Additional onboard computers for vision or artificial intelligence
  • Custom-developed actuators and equipment.

The top plate and chassis profiles offer several mounting options. Fictionlab also provides mechanical design files, allowing users to adapt certain parts to their project.

A mobile base designed for real-world experiments

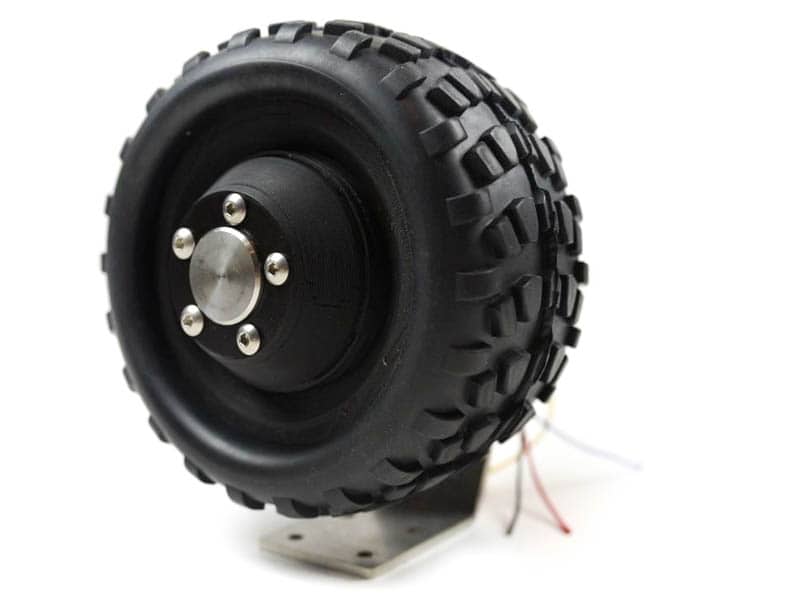
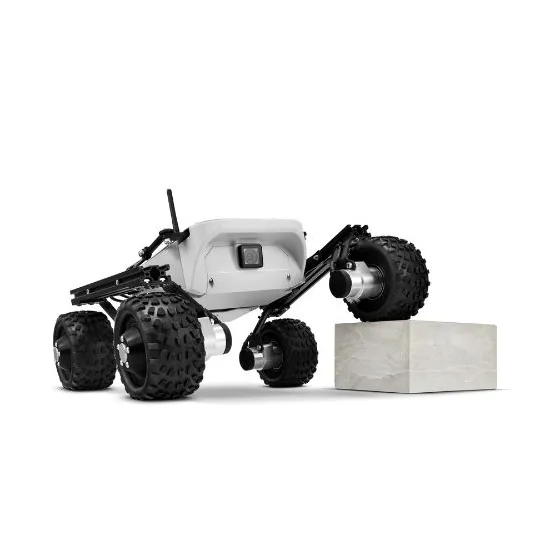
The Leo Rover 1.9 combines a metal structure, 4-wheel drive, and a rocker suspension designed to keep the wheels in contact with the ground on uneven surfaces.

It can be used on indoor floors as well as grass, gravel, or rough terrain. Its IP55 protection also makes it suitable for outdoor experiments in environments exposed to dust or water jets.

With ground clearance designed for obstacle negotiation and the ability to overcome obstacles of approximately 70 mm, the Leo Rover is particularly well suited to projects requiring algorithm testing beyond perfectly flat laboratory environments.

Technical specifications of the Leo Rover 1.9 Developer Kit

ConfigurationKit to assemble
Dimensions once assembled424 × 445 × 303 mm
WeightApproximately 7 kg
PayloadApproximately 5 kg with standard tires
Maximum linear speedApproximately 0.4 m/s
Maximum angular speedApproximately 1 rad/s
Estimated obstacle clearanceApproximately 70 mm
Drive system4-wheel drive
SuspensionRocker system
Protection ratingIP55
Operating temperature-10 °C to +40 °C
RuntimeUp to 4 hours with the standard battery
Communication rangeUp to 100 m
Integrated sensorsFront camera, IMU, and wheel encoders
Robotics frameworkROS 2
Software licenseMIT

Leo Rover resources

Historial de precios

Historial del precio medio

Un punto de datos por día, calculado según la fecha de observación.

Precio medio diario

Importes en USD

$6447,61
Gráfico del historial del precio medio en USDGráfico de líneas con 6 observaciones desde 2 oct 2026 hasta 7 oct 2026.$6447,64$6447,63$6447,62$6447,61$6447,602 oct3 oct4 oct5 oct7 oct2 oct 2026: precio medio de $6447,613 oct 2026: precio medio de $6447,614 oct 2026: precio medio de $6447,615 oct 2026: precio medio de $6447,616 oct 2026: precio medio de $6447,617 oct 2026: precio medio de $6447,61

Los promedios se calculan por día UTC a partir de todos los precios de oferta registrados.