Research Papers
Lättbegripliga sammanfattningar av den senaste robotikforskningen – humanoida robotar, fyrbenta robotar, industriell automatisering och AI.
AIför 7 d sedan
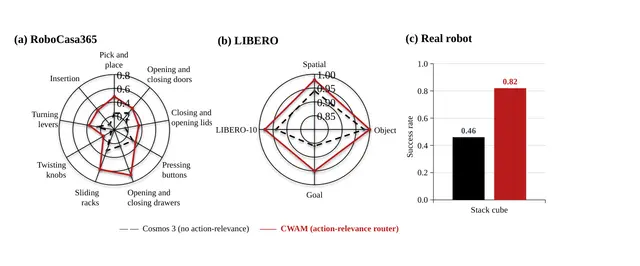
A Robot World Model Learns Which Objects Matter for Each Action
Humanoidför 7 d sedan
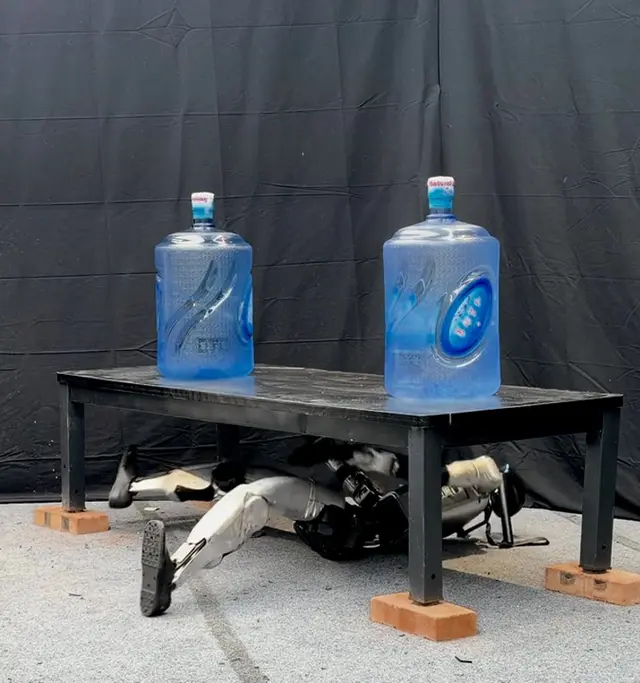
How Humanoids Learn to Escape Tight Spaces and Stand Up Safely
AIför 7 d sedan
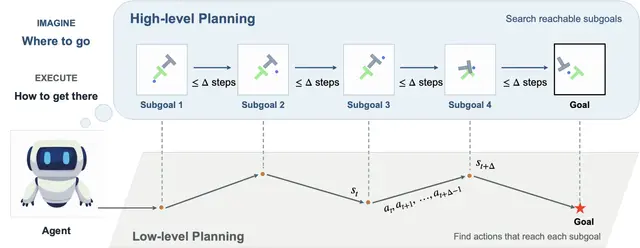
Hierarchical World Models Enable Reliable Long-Horizon Robot Planning with Implicit Dynamics
Roboticsför 8 d sedan
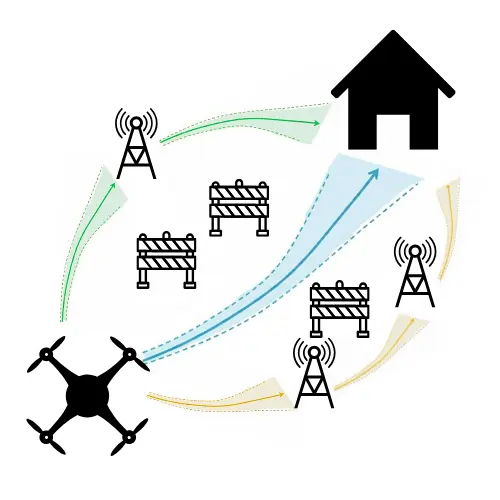
How Robots Plan Optimal Paths While Keeping Localization Uncertainty Below Limits
Roboticsför 8 d sedan
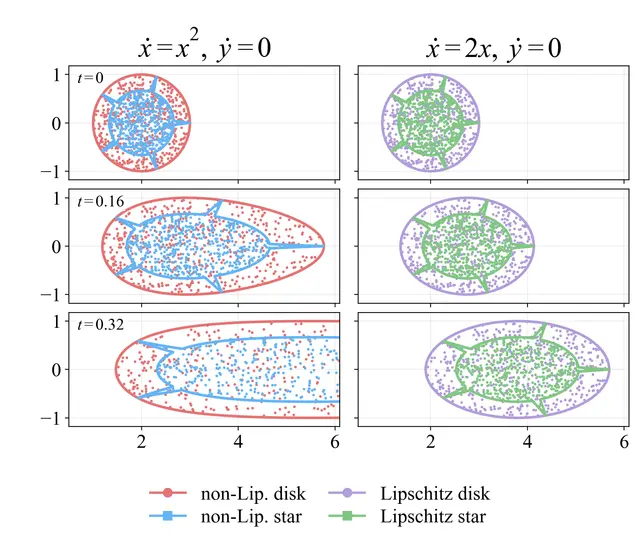
How Many Robot Simulations Are Needed to Map Every Reachable State?
AIför 8 d sedan
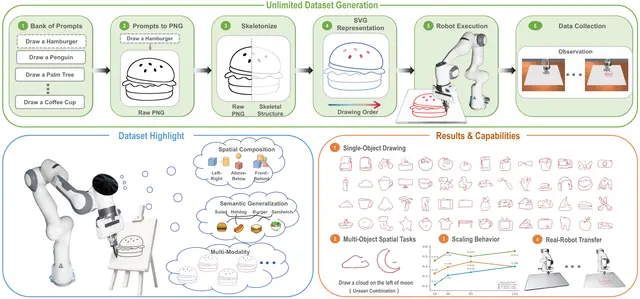
Can Robots Draw New Objects from Instructions? BURGER Tests VLA Generalization
Roboticsför 9 d sedan
Robot Learns to Align, Latch, and Unfasten Screws with Force Feedback
Roboticsför 9 d sedan
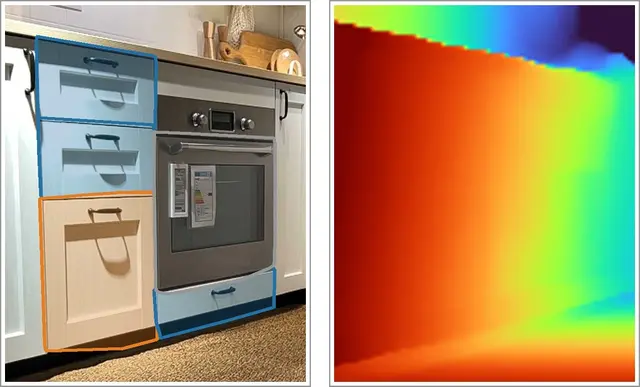
How Robots Learn Whether a Cabinet Door Swings or Slides Open
AIför 9 d sedan
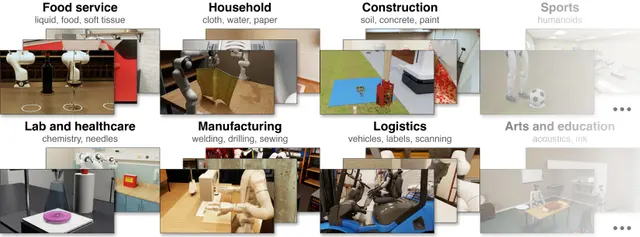
How Digital Agents Scale Realistic Physical Simulations for Better Robot Learning
Roboticsför 10 d sedan
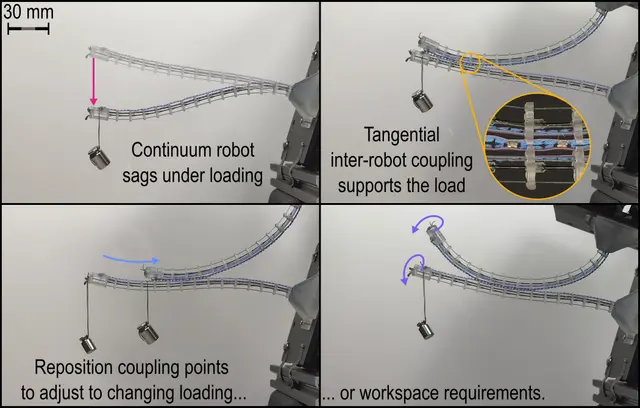
A Conveyor Belt Mechanism Enables Repositionable Magnetic Coupling Between Continuum Robots
Roboticsför 10 d sedan
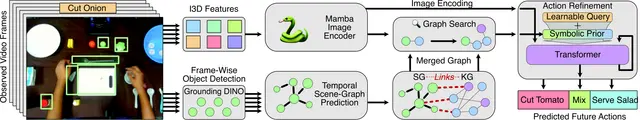
Symbolic Graphs Help Robots Predict Actions from Short Clips at Work
Roboticsför 10 d sedan
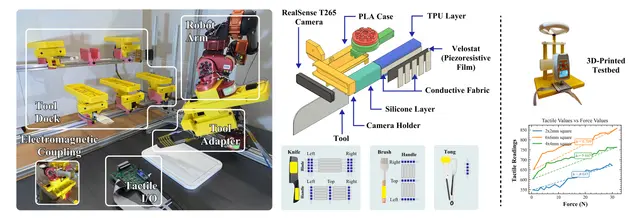
SwapBot Helps Robots Use Swappable Tools and Touch for Better Tasks
Roboticsför 11 d sedan
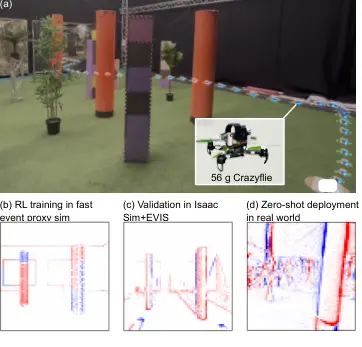
Rendering-Free Event Frame Simulation for Fast Reinforcement Learning in Drone Navigation
AIför 11 d sedan
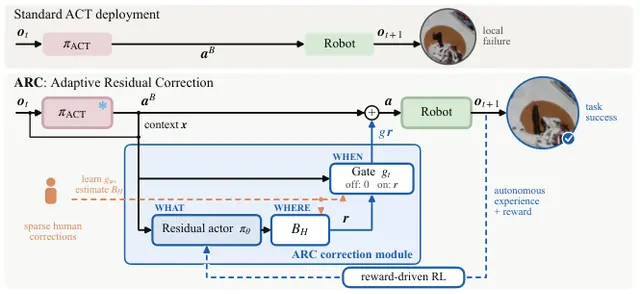
How Sparse Human Corrections Improve Precision in Existing Real-World Robot Policies
AIför 11 d sedan
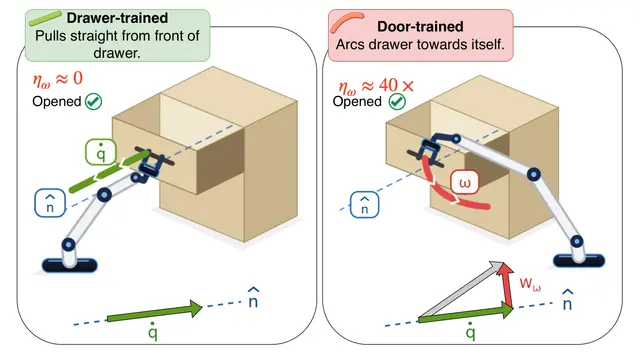
How to Evaluate Robot Manipulation Against Articulated Object Kinematic Constraints
Roboticsför 12 d sedan
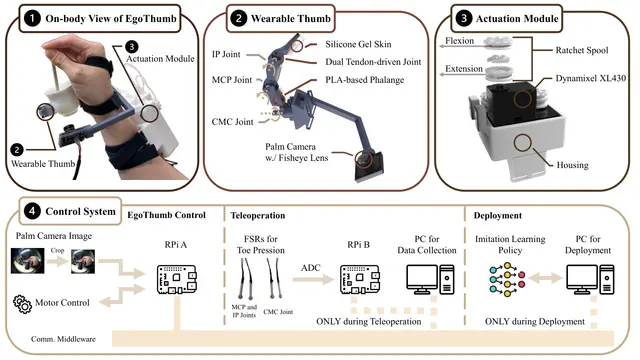
A Wearable Robotic Thumb Uses Vision to Grasp and Hold Objects
Roboticsför 12 d sedan
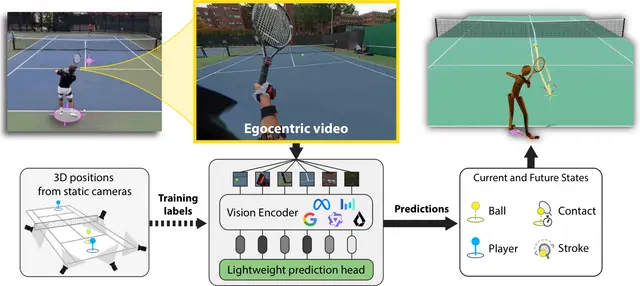
How Vision Models Track Tennis Balls and Predict Play in Motion
AIför 12 d sedan
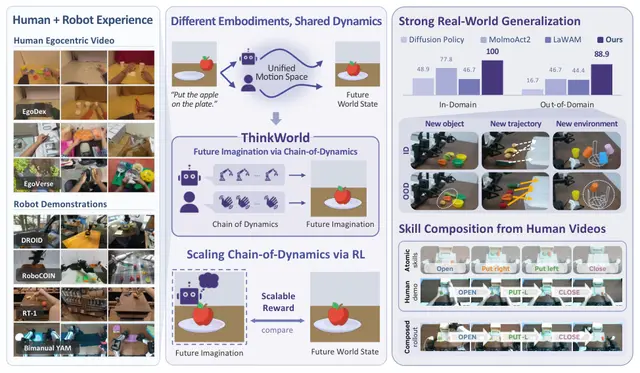
ThinkWorld Uses World Imagination to Strengthen Robot Action Reasoning
Roboticsför 13 d sedan