Research Papers
Lättbegripliga sammanfattningar av den senaste robotikforskningen – humanoida robotar, fyrbenta robotar, industriell automatisering och AI.
Roboticsi dag
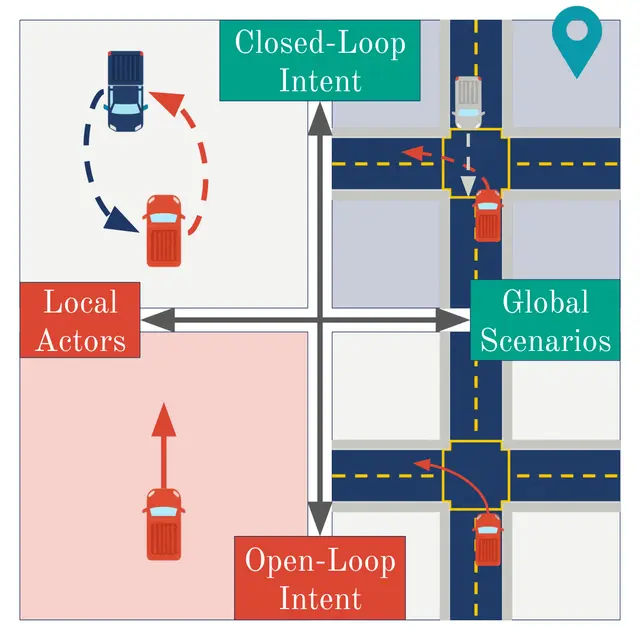
Keeping Autonomous Driving Test Scenarios on Track with Closed-Loop Policy Orchestration
AIi dag
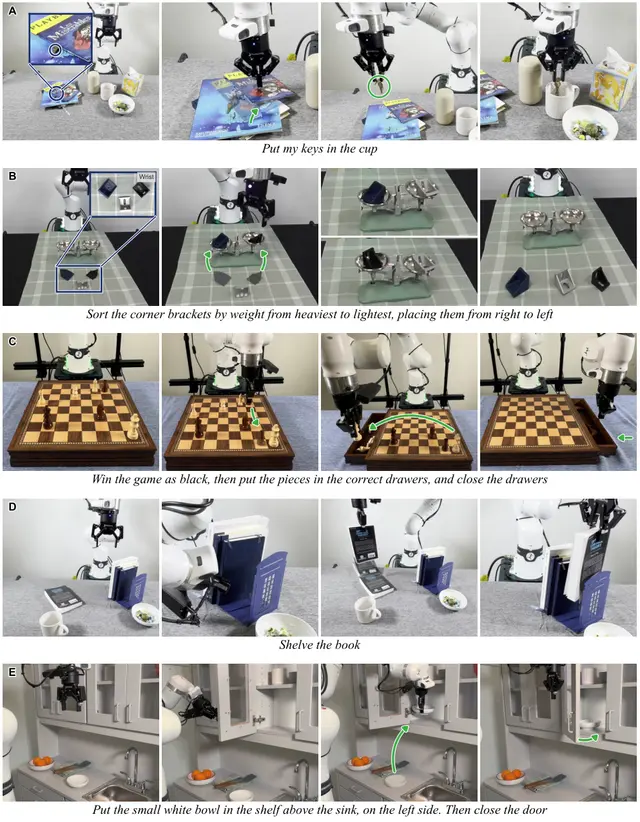
A Robot That Writes Code to See, Search, and Manipulate Objects
Roboticsi går
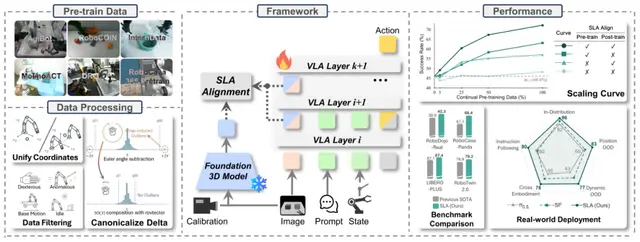
How Continual Training Scales Robot Skills Across Tasks and Robot Bodies
Roboticsi går
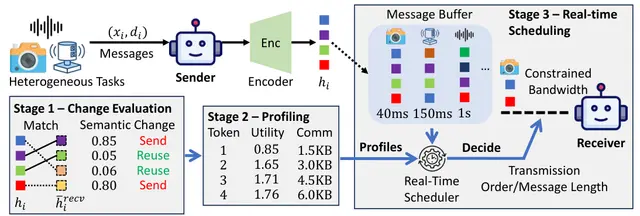
Real-Time Latent Communication for Cyber-Physical Agents
Roboticsi går
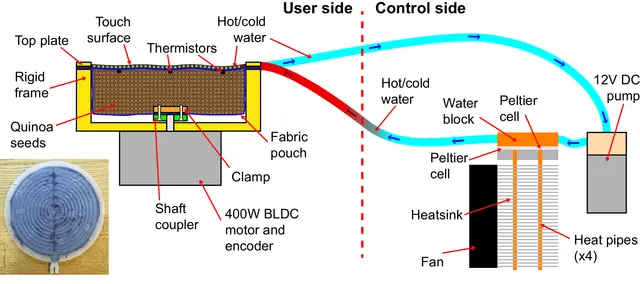
A Haptic Interface Combines Softness and Temperature Control in Real Time
Humanoidi förrgår
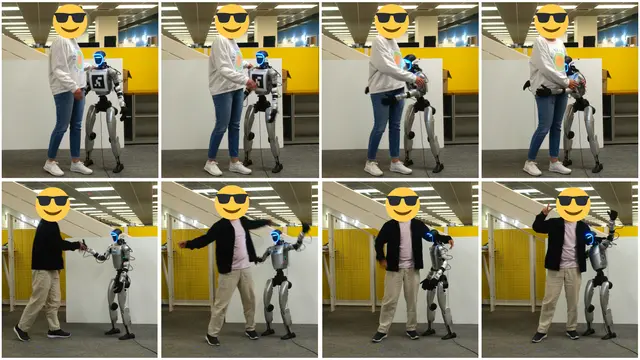
How Humanoids Learn Natural, Contact-Aware Human Interaction Through Motion
Roboticsi förrgår
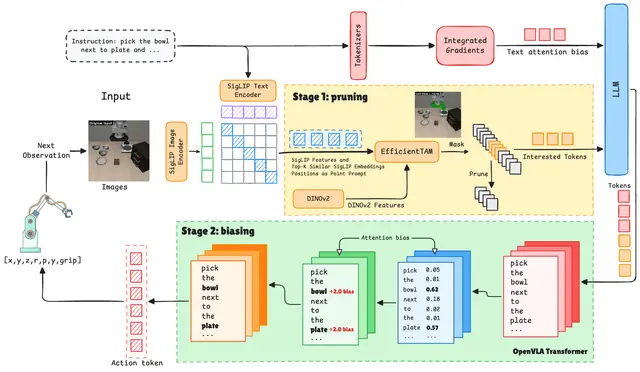
T3R Cuts Visual Tokens for Faster, More Robust Vision-Language-Action Models
AIi förrgår
Calibrated Latent Probing Predicts and Classifies VLA Failures Before They Happen
Roboticsför 3 d sedan
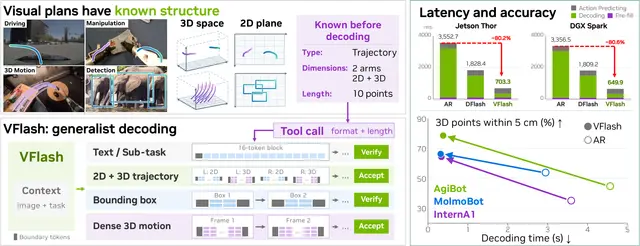
VFlash Lets Robots Decode Visual Plans Into Useful Actions More Quickly
Roboticsför 3 d sedan
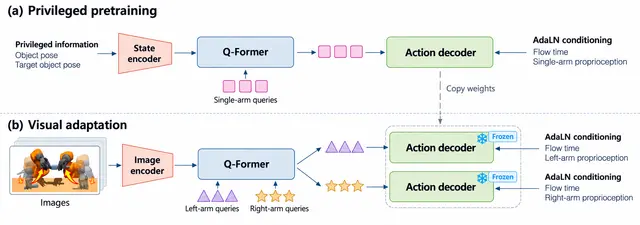
Dexterous Robot Hands Reuse RL Skills to Learn from Fewer Demos
Roboticsför 3 d sedan
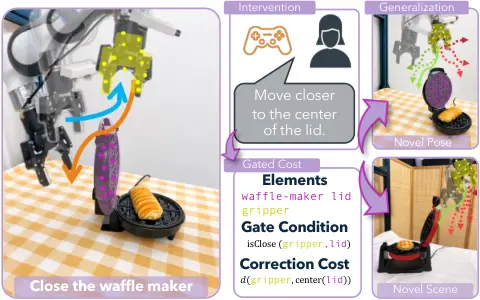
How Robots Learn Transferable VLA Corrections from Semantic Human Interventions
AIför 4 d sedan
How Reinforcement Learning Improves Generalist Robot Policies at Scale
Humanoidför 4 d sedan
Simulation Trains Humanoids to See, Plan, and Move in Real Worlds
Roboticsför 4 d sedan
Fast GPU Planning for Torque-Limited, Collision-Free Robot Motion
AIför 5 d sedan
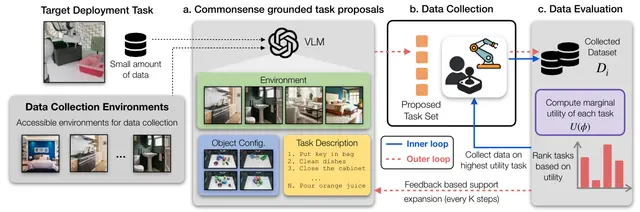
GUILD Guides Robot Imitation Learning Data Collection Across Auxiliary Tasks
AIför 5 d sedan
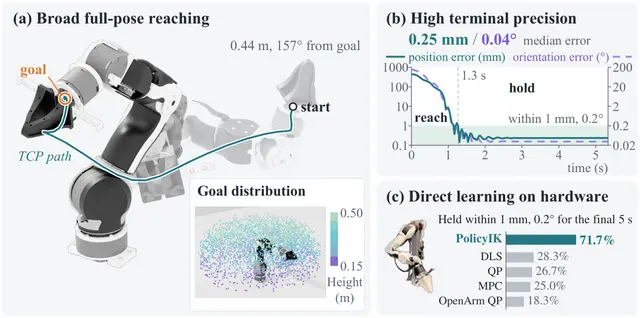
PolicyIK Uses Reinforcement Learning for Precise Robot Arm Inverse Kinematics
AIför 5 d sedan
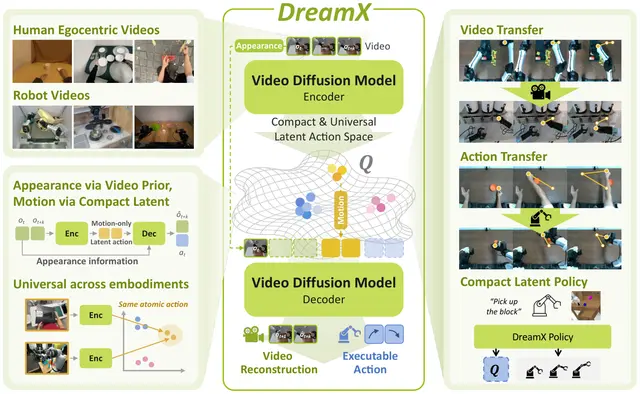
DreamX Learns Transferable Robot Actions from Video Diffusion Models
Roboticsför 6 d sedan
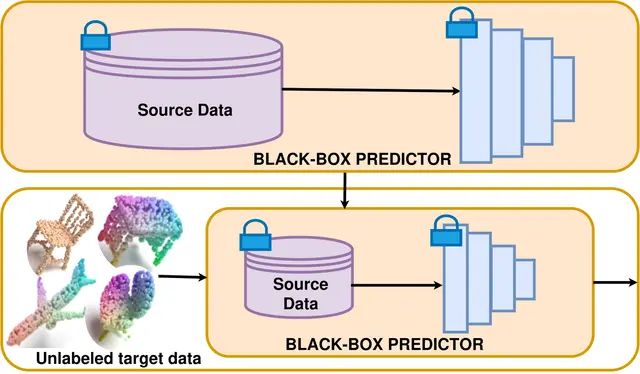
Backpropagation-Free Black-Box Domain Adaptation for Robust 3D Point Cloud Recognition
AIför 6 d sedan