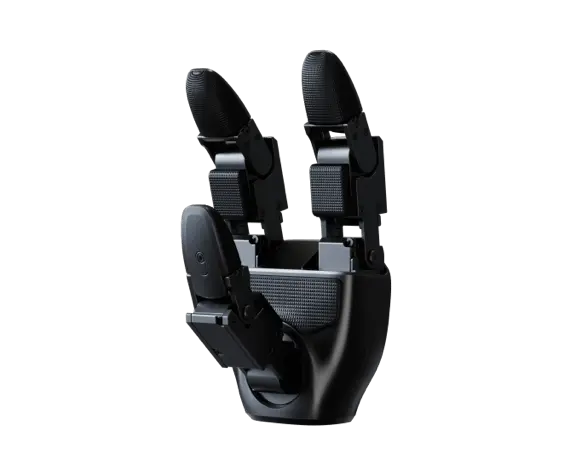
The Unitree Dex3-1 Tactile is Unitree's three-finger dexterous robotic hand for the G1 humanoid in its tactile version, part G1-DEX3-3FINGERHAND-TACTILE. On the same seven-degree-of-freedom, force-controlled mechanism as the standard Dex3-1, it carries 33 pressure sensors in 9 arrays across the palm, the finger pads and the fingertips.
With pressure at the contact points, a G1 can tell when a finger touches, how hard each pad presses and how the load shifts during a grasp, rather than guessing contact from joint torque. The sensors cover 10 g to 2,500 g and report pressure and their own temperature in the same 1,000 Hz USB 2.0 stream as joint position, velocity, torque, voltage, current and IMU data. That suits teleoperation with touch feedback, tactile datasets for imitation learning and work with light or fragile objects.
The thumb has three degrees of freedom and the index and middle fingers two each. Six joints are direct-drive micro brushless force-control units and one is gear-driven, giving hybrid force and position control at the joints. The hand weighs 710 g, measures 175 × 88 × 77 mm flat, repeats fingertip position to ±2 mm and grasps up to 500 g on a 5 cm round hard object, with 400 W of peak power for 3 s; the sensors take 20 kg without damage. It runs on 12–58 V and from −20 to 60 °C.
The standard Dex3-1 for the G1 is the same hand without the tactile arrays, and the Dex3-1 Tactile for the Unitree H2 is sold as its own part, so order the one that matches your robot. For five fingers on a G1, see the G1 Third-Party Dexterous Hand or the tendon-driven Unitree Dex2/5, and compare our other dexterous robotic hands.
Key Capabilities
-
33 pressure sensors in 9 arrays: Three 2 × 2 arrays in the palm, a 2 × 2 array on each finger pad and a 3 × 1 array at each fingertip sense from 10 g to 2,500 g.
-
Touch in the joint stream: Pressure and sensor temperature arrive at 1,000 Hz over USB 2.0 together with joint position, velocity, torque and IMU data.
-
Hybrid force and position control: Six direct-drive micro brushless force-control joints and one geared joint set grip force at the fingers themselves.
-
Three fingers, 7 degrees of freedom: The thumb has three degrees of freedom and swings from −60° to 60° at its base; the index and middle fingers have two each.
-
Made for the G1: Unitree builds the Dex3-1 for its G1 humanoid, and this is the tactile version, part G1-DEX3-3FINGERHAND-TACTILE.
-
710 g, 500 g grasp: The hand measures 175 × 88 × 77 mm flat, grasps up to 500 g, and its sensors take 20 kg without damage.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.