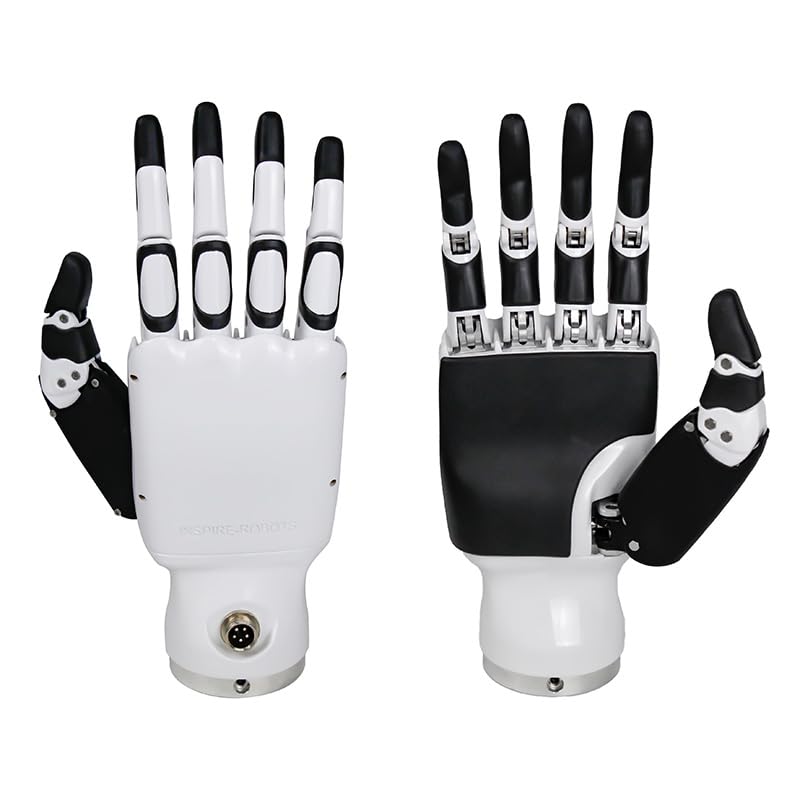
- 11 DOF with 6 active joints Active thumb abduction/adduction plus independent finger flexion deliver 11 total degrees of freedom concentrated on the joints most critical for diverse grasp configurations.
- EtherCAT, CANfd, and RS-485 interfaces Pro tier adds EtherCAT communication to the Basic's RS-485 and CANfd, supporting deterministic real-time control in demanding manipulation and humanoid research platforms.
- Cascaded and compliance control modes Adds cascaded control and compliance control on top of position-velocity-current feedback, enabling more nuanced force-sensitive and adaptive manipulation behaviors.
- 383 g at 20 kg maximum load Aerospace-grade aluminum alloy and food-grade polymer construction achieves 383 g weight—20% below the industry average—while supporting 20 kg maximum load and ≥50 N grip force.
- Anti-collision finger design Structural and control-layer protection against unexpected finger contact events extends operational reliability in unstructured manipulation environments.
- ≤50 dB operating noise Operating noise confirmed at ≤50 dB at 50 cm, compatible with audio-sensitive laboratory settings and human-shared environments requiring low acoustic disturbance.

Gemiddelde prijs per dag
Bedragen in USD