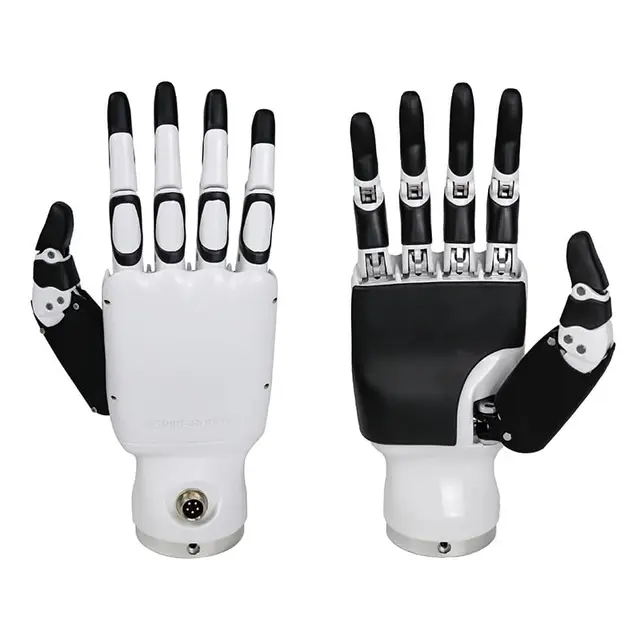
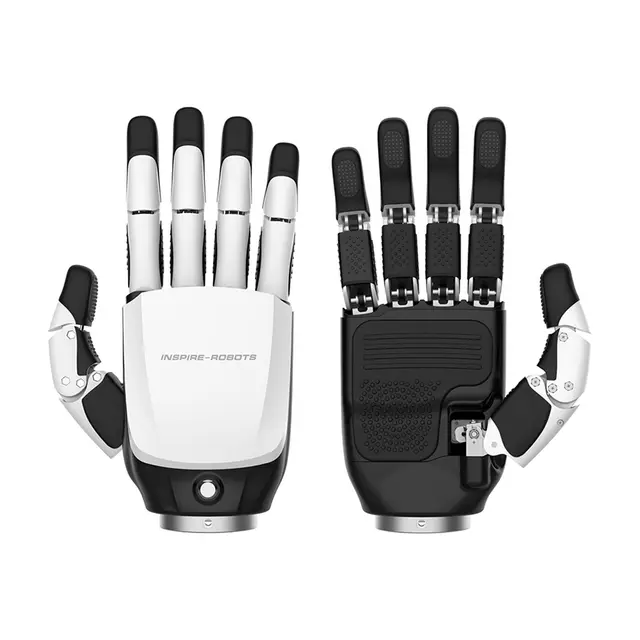
The Inspire RH56F1-E2L is the left-hand version of Inspire Robots' RH56F1 dexterous robotic hand, in the build without tactile sensors. Its five fingers have 12 joints moved by 6 degrees of freedom, inside an all-metal integrated skeleton with the wiring concealed in the hand. It weighs 620 g and measures 183.3 mm long and 79.1 mm across the palm.
Inspire rates every fingertip at 15 N or more and the thumb at 10 N or more, rates the passive payload at 30 kg, and puts the series through 20 stringent tests. That suits humanoid builders and research labs that need a hand where a parallel gripper runs out: tool handles, cups and irregular parts, picked and held by one robot hand or by a left and right pair on a two-armed robot.
Force is read at 0.1 N resolution and fingertips repeat to ±0.2 mm. The thumb rotates laterally through 60–180° at more than 155°/s, the four fingers flex at more than 107°/s, and the hand closes fully in 0.8 s or less. The E2 interface combines EtherCAT and RS-485 with 1 kHz real-time communication, on a 24–48 V supply drawing at most 5 A at 24 V. The wrist carries four 3.5 mm through holes for mounting, and fitment to your arm or humanoid is confirmed with the quotation.
The RH56F1 right hand (E2R) mirrors this one for a two-handed setup. The RH56F1 tactile left hand (E2L-T1) and its right-hand twin add eight tactile sensors with a 30 N range and 5 % full-scale accuracy, for work that needs contact data; the E2L is the choice when position and force feedback are enough. Compare them with the rest of our dexterous robotic hands.
Key Capabilities
-
All-metal skeleton at 620 g: An integrated metal frame with wiring concealed inside keeps the hand rigid at 620 g, 183.3 mm long and 79.1 mm across the palm.
-
15 N at every fingertip: Each fingertip pushes with at least 15 N and the thumb with at least 10 N, with force read at 0.1 N resolution.
-
30 kg passive payload: Inspire rates the RH56F1 to hold 30 kg passively and puts the series through 20 stringent tests.
-
Six drives, twelve joints: Six degrees of freedom move twelve joints across five fingers, and fingertips repeat to ±0.2 mm.
-
Fast thumb and fingers: The thumb rotates laterally through 60–180° at over 155°/s, the four fingers flex at over 107°/s, and the hand closes in 0.8 s or less.
-
EtherCAT and RS-485 at 1 kHz: The E2 build carries both interfaces with 1 kHz real-time communication on a 24–48 V supply.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.