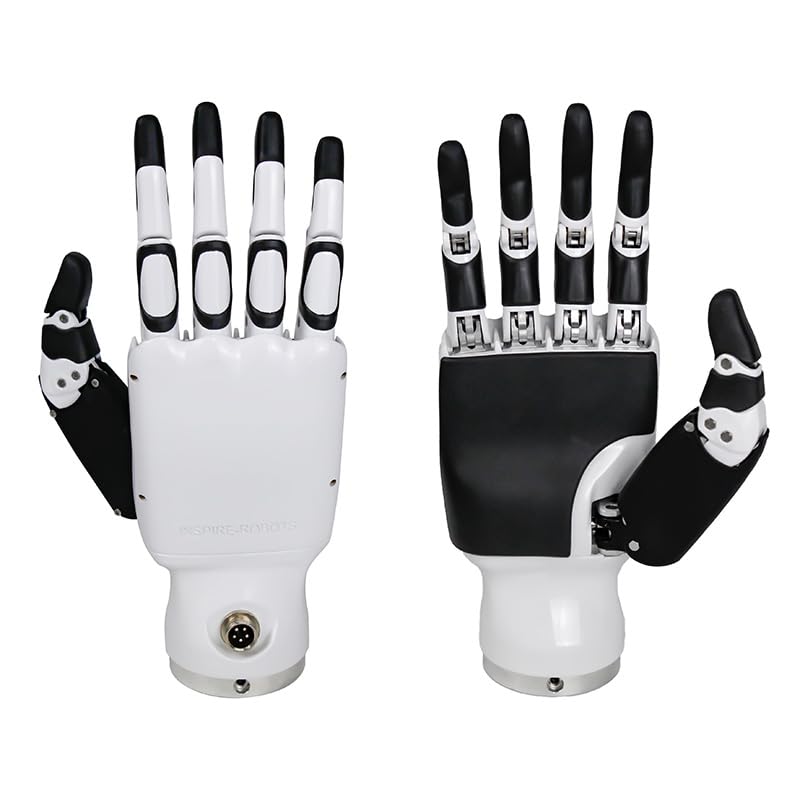
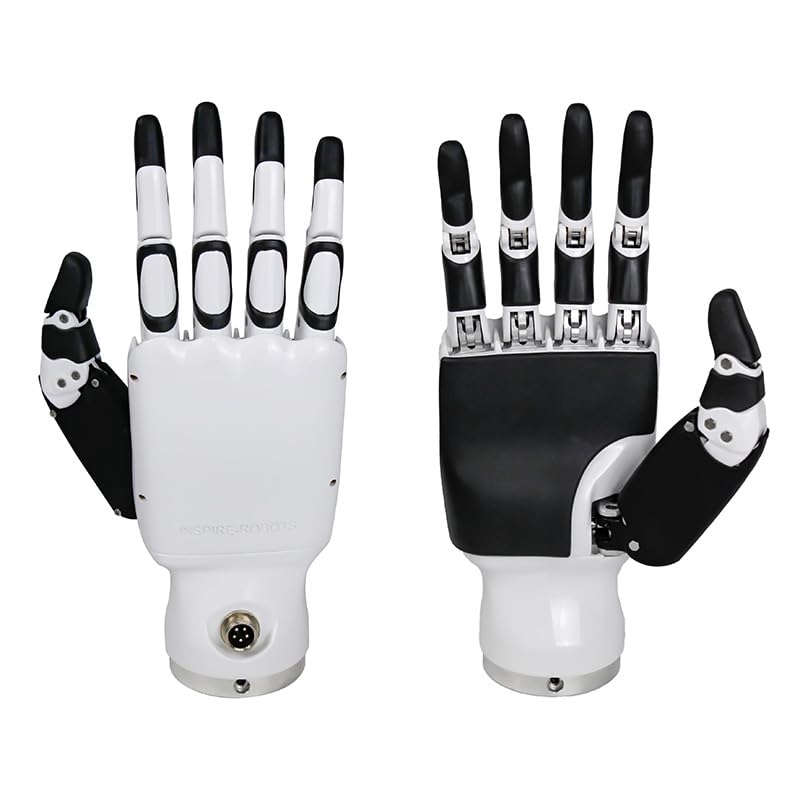
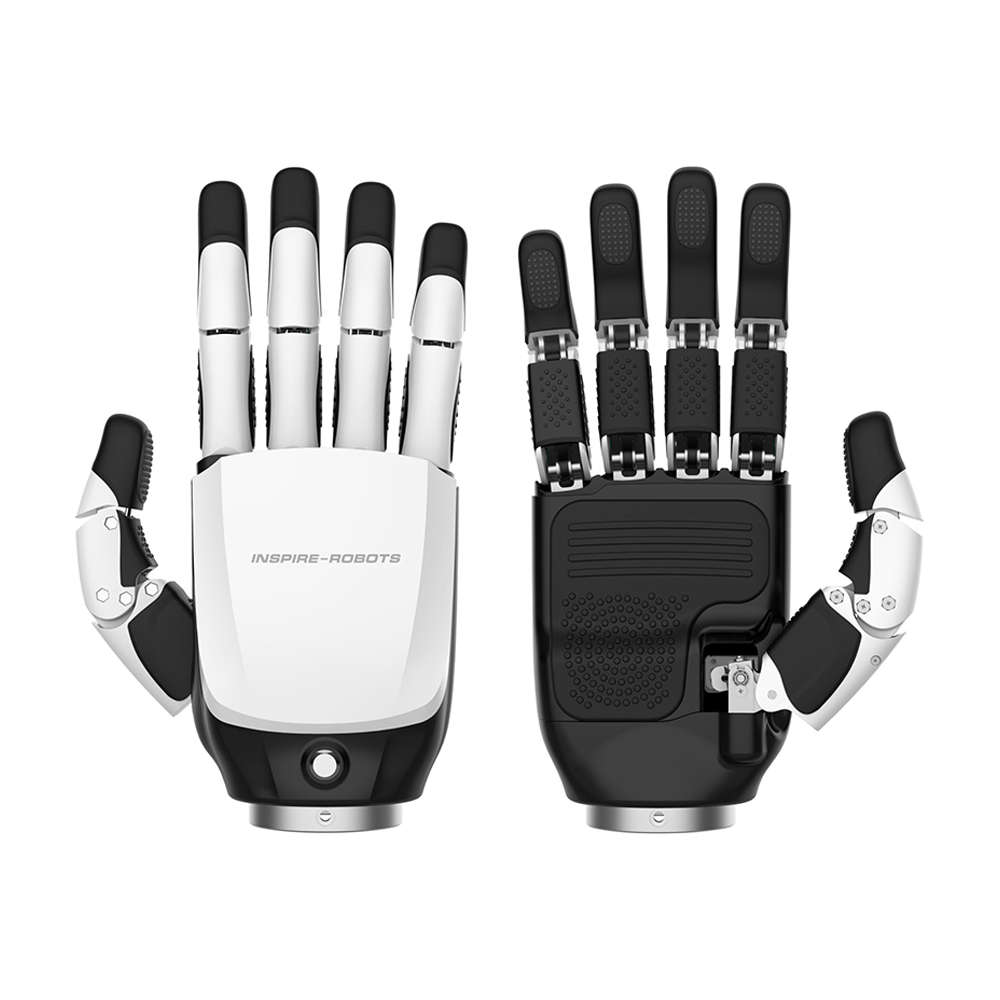
- Humanoid five-finger layout covering pinch, power and tripod grasps
- 6 degrees of freedom across 12 joints, driven by six linear servo actuators
- Configurable tactile sensing from 5 up to 17 modules for contact feedback
- Six force sensors with 0.5 N resolution for closed-loop, threshold-based gripping
- Power-off self-lock holds position without re-homing at startup
- Maximum fingertip output force of 30 N with ±0.2 mm repeatability
- Thumb lateral rotation over 85 degrees; brisk finger speeds for responsive grasps
- Integration over Modbus TCP and CAN, with RS485 optional

តម្លៃមធ្យមប្រចាំថ្ងៃ
ចំនួនទឹកប្រាក់ជារូបិយប័ណ្ណ USD