Prezzo medio giornaliero
Importi in USD


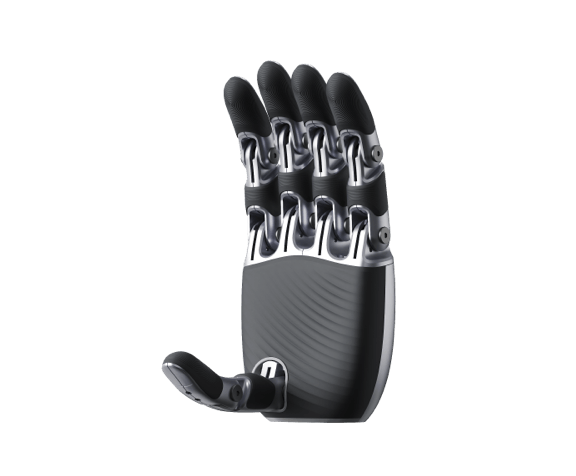
Official cable-driven dexterous hand for the Unitree R1 humanoid robot, developed in-house by Unitree Robotics. The Tendon Cable Dexterous Hand features a cable-driven actuation system with 2 degrees of freedom across 10 joints -- four fingers with 8 joints and a thumb with 2 joints. Weighing approximately 365g with compact dimensions of 151 x 67 x 70 mm, this hand delivers 10N fingertip force for reliable grasping across a wide range of objects. Operates on 24-58V and includes a full robot development interface for secondary development. This listing is for a single hand -- typically, two dexterous hands are selected per humanoid robot for dual-arm manipulation.
The Unitree R1 Dedicated Tendon Cable Dexterous Hand is an in-house developed cable-driven dexterous hand designed specifically for the Unitree R1 humanoid robot. Unlike linkage or gear-driven alternatives, this hand employs a tendon cable actuation system that routes flexible cables from remotely mounted actuators to each finger joint, enabling a lightweight, compact end-effector with natural compliance. The hand features 2 degrees of freedom distributed across 10 total joints -- four fingers with 8 joints and a thumb with 2 joints -- providing sufficient dexterity for everyday grasping and manipulation tasks. At approximately 365g with dimensions of 151 x 67 x 70 mm, the hand minimizes payload on the R1 arm while delivering 10N fingertip force for secure object handling. A full robot development interface is provided for researchers and engineers to implement custom control algorithms and grasp strategies.
The Tendon Cable Dexterous Hand employs a cable-driven actuation architecture that separates motors from the hand structure, routing force through flexible tendons to achieve a lightweight, compliant end-effector:
Despite its streamlined 2-DOF design, the Tendon Cable Dexterous Hand achieves versatile grasping through compliant cable-driven mechanics and coupled joint motion:
The Tendon Cable Dexterous Hand is designed for researchers and developers who need a lightweight, open platform for manipulation research. Unitree provides a comprehensive robot development interface:
Each Tendon Cable Dexterous Hand package contains the following components for a single hand:
| Parameter | Unitree R1 Tendon Cable Dexterous Hand |
| Product Name | Tendon Cable Dexterous Hand |
| Development | In-house development by Unitree Robotics |
| Compatible Robot | Unitree R1 humanoid robot |
| Drive Mechanism | Cable-driven (tendon actuation) |
| Total Degrees of Freedom | 2 |
| Total Number of Joints | 10 |
| Finger Configuration | Four fingers with 8 joints; Thumb with 2 joints |
| Dimensions (Approx.) | 151 x 67 x 70 mm |
| Weight (Approx.) | 365 g |
| Operating Voltage | 24 - 58 V DC |
| Fingertip Force | 10 N |
| Haptic Feedback | Not included |
| Secondary Development | Supported |
| Robot Development Interface | Provided |
| Package Quantity | Single hand per package |
| Typical Robot Configuration | Two hands per humanoid robot (dual-arm) |
| Warranty | 12 months |
* Specifications are based on manufacturer data and may vary slightly by production batch.
* This hand does not include haptic feedback sensors. Force control must be implemented through motor current sensing or external vision systems.
* This hand is developed in-house by Unitree Robotics specifically for the R1 platform.
* This package includes one dexterous hand. For dual-arm manipulation, order two units.
* Operating voltage: 24-58V DC. Ensure the R1 robot power bus is configured within this range.
* Tendon cables require periodic inspection and tension adjustment. Refer to the maintenance guide for scheduling.
* Secondary development requires programming skills and familiarity with robotics control concepts.
* Unitree is a registered trademark of Unitree Robotics.

Storico dei prezzi
Un dato al giorno, calcolato in base alla data di rilevazione.
Importi in USD
Le medie sono calcolate per giorno UTC sulla base di tutti i prezzi delle offerte registrati.

Unitree
$1490
Unitree
£1106,26

Unitree
$6500

Unitree
$8680

Unitree
$7800

Unitree
$10.000

Unitree
$25.000

Unitree
$25.000

Unitree
$7680
Unitree
$8680

Unitree
$16.450

Unitree
$18.950
🍪 Preferenze cookie
Utilizziamo i cookie per misurare le prestazioni. Informativa sulla privacy