Prezzo medio giornaliero
Importi in USD
Descrizione
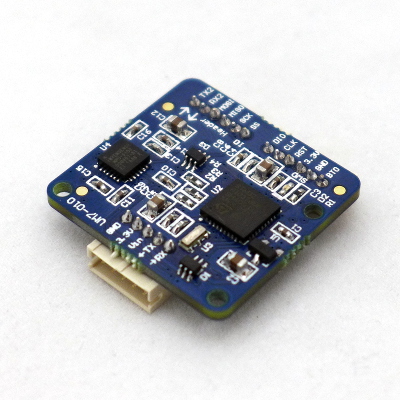
The UM7 is a 3rd-generation Attitude and Heading Reference System (AHRS / IMU) that takes advantage of state-of-the-art MEMS technology to improve performance and reduce costs. Like its predecessors, the UM7 combines triaxial accelerometer, rate gyro, and magnetometer data using a sophisticated Extended Kalman Filter to produce attitude and heading estimates. The UM7 also adds many new features, including higher gyro bias stability and lower noise, a new communication architecture for improved flexibility, optional NMEA packet transmission, UTC time-synchronization with external GPS, and support for third-order temperature compensation on all sensors. Even with its added features, the UM7 is offered at a significantly reduced priced compared to other sensors in its class. The UM7 comes with one 5-pin cable assembly for the main IO header. High performance Excellent gyro bias stability over temperature Adjustable low-pass filter and EKF settings provide customizable performance for various applications. States and sensor data synchronized to GPS position and velocity using optional external GPS module. Supports alignment calibration and third-order bias and scale factor temperature compensation for accels, gyros, and magnetometer (optionally performed in-factory or by the end-user). Magnetometer soft and hard-iron calibration Lower Cost State-of-the-art MEMS devices designed for mass-market consumer applications drastically lowers cost OEM version reduces overall cost, size, and weight Ease of use Transmits data using human-readable NMEA strings, binary packets for higher efficiency, or a combination of both Flexible communication architecture allows UM7 to transmit any combination of data at individually adjustable rates Connects to the CHR Serial Interface software to allow for real-time plotting of sensor data, logging, device configuration, and magnetometer calibration Attitude and Heading Specifications EKF estimation rate: 500 Hz +/- 1 degree typical static pitch/roll accuracy +/- 3 degree typical dynamic pitch/roll accuracy +/- 3 degree typical static yaw accuracy +/- 5 degree typical dynamic yaw accuracy 0.5 degree angle repeatability 0.01 degree angular resolution Other Specifications Input voltage: 5.0V Communication: 3.3V TTL UART, SPI bus Supported baud rates: 9600, 14400, 19200, 38400, 57600, 115200, 128000, 153600, 230400, 256000, 460800, 921600 Power consumption: 50mA at 5.0V Operating temperature: -40 to +85 C Dimensions: 1.06″ x 1.02″ x 0.26″ (27mm x 26mm x 6.5mm) Weight: 0.4 oz. (11 grams) Data outputs rates: 1 Hz to 255 Hz (binary packets), 1 Hz to 100 Hz (NMEA packets) Output data: Attitude and heading (Euler Angles), Attitude quaternion, GPS altitude, position, velocity (w/ external GPS), magnetometer, accelerometer, gyro data Documents UM7 Datasheet AN1005 – Understanding Euler Angles AN1006 – Understanding Quaternions AN1007 – Estimating Position and Velocity Using Accelerometers AN1008 – Sensors used for Orientation Estimation Software Downloads CHR Serial Interface v3.0.7 Windows Installer Use the Serial Interface software to configure the UM7, log data, and plot data in real-time. Latest firmware revision (U71B, comes pre-installed on new sensors) Example Code Example Matlab communication code The UM7 is a 3rd-generation Attitude and Heading Reference System (AHRS) that takes advantage of state-of-the-art MEMS technology to improve performance and reduce costs. Like its predecessors, the UM7 combines triaxial accelerometer, rate gyro, and magnetometer data using a sophisticated Extended Kalman Filter to produce attitude and heading estimates.
The UM7 is a 3rd-generation Attitude and Heading Reference System (AHRS / IMU) that takes advantage of state-of-the-art MEMS technology to improve performance and reduce costs. Like its predecessors, the UM7 combines triaxial accelerometer, rate gyro, and magnetometer data using a sophisticated Extended Kalman Filter to produce attitude and heading estimates. The UM7 also adds many new features, including higher gyro bias stability and lower noise, a new communication architecture for improved flexibility, optional NMEA packet transmission, UTC time-synchronization with external GPS, and support for third-order temperature compensation on all sensors. Even with its added features, the UM7 is offered at a significantly reduced priced compared to other sensors in its class. The UM7 comes with one 5-pin cable assembly for the main IO header. High performance Excellent gyro bias stability over temperature Adjustable low-pass filter and EKF settings provide customizable performance for various applications. States and sensor data synchronized to GPS position and velocity using optional external GPS module. Supports alignment calibration and third-order bias and scale factor temperature compensation for accels, gyros, and magnetometer (optionally performed in-factory or by the end-user). Magnetometer soft and hard-iron calibration Lower Cost State-of-the-art MEMS devices designed for mass-market consumer applications drastically lowers cost OEM version reduces overall cost, size, and weight Ease of use Transmits data using human-readable NMEA strings, binary packets for higher efficiency, or a combination of both Flexible communication architecture allows UM7 to transmit any combination of data at individually adjustable rates Connects to the CHR Serial Interface software to allow for real-time plotting of sensor data, logging, device configuration, and magnetometer calibration Attitude and Heading Specifications EKF estimation rate: 500 Hz +/- 1 degree typical static pitch/roll accuracy +/- 3 degree typical dynamic pitch/roll accuracy +/- 3 degree typical static yaw accuracy +/- 5 degree typical dynamic yaw accuracy 0.5 degree angle repeatability 0.01 degree angular resolution Other Specifications Input voltage: 5.0V Communication: 3.3V TTL UART, SPI bus Supported baud rates: 9600, 14400, 19200, 38400, 57600, 115200, 128000, 153600, 230400, 256000, 460800, 921600 Power consumption: 50mA at 5.0V Operating temperature: -40 to +85 C Dimensions: 1.06″ x 1.02″ x 0.26″ (27mm x 26mm x 6.5mm) Weight: 0.4 oz. (11 grams) Data outputs rates: 1 Hz to 255 Hz (binary packets), 1 Hz to 100 Hz (NMEA packets) Output data: Attitude and heading (Euler Angles), Attitude quaternion, GPS altitude, position, velocity (w/ external GPS), magnetometer, accelerometer, gyro data Documents UM7 Datasheet AN1005 – Understanding Euler Angles AN1006 – Understanding Quaternions AN1007 – Estimating Position and Velocity Using Accelerometers AN1008 – Sensors used for Orientation Estimation Software Downloads CHR Serial Interface v3.0.7 Windows Installer Use the Serial Interface software to configure the UM7, log data, and plot data in real-time. Latest firmware revision (U71B, comes pre-installed on new sensors) Example Code Example Matlab communication code
Storico dei prezzi
Un dato al giorno, calcolato in base alla data di rilevazione.
Importi in USD
Le medie sono calcolate per giorno UTC sulla base di tutti i prezzi delle offerte registrati.

RoboSavvy
£118,42
RoboSavvy
£121,36
RoboSavvy
£108,08
RoboSavvy
£134,88
RoboSavvy
£89,89
RoboSavvy
£95,83
RoboSavvy
£74,99
RoboSavvy
£74,90

RoboSavvy
£66,66
RoboSavvy
£215,83
RoboSavvy
£24,67
RoboSavvy
£12,25
🍪 Preferenze cookie
Utilizziamo i cookie per misurare le prestazioni. Informativa sulla privacy