Prezzo medio giornaliero
Importi in USD
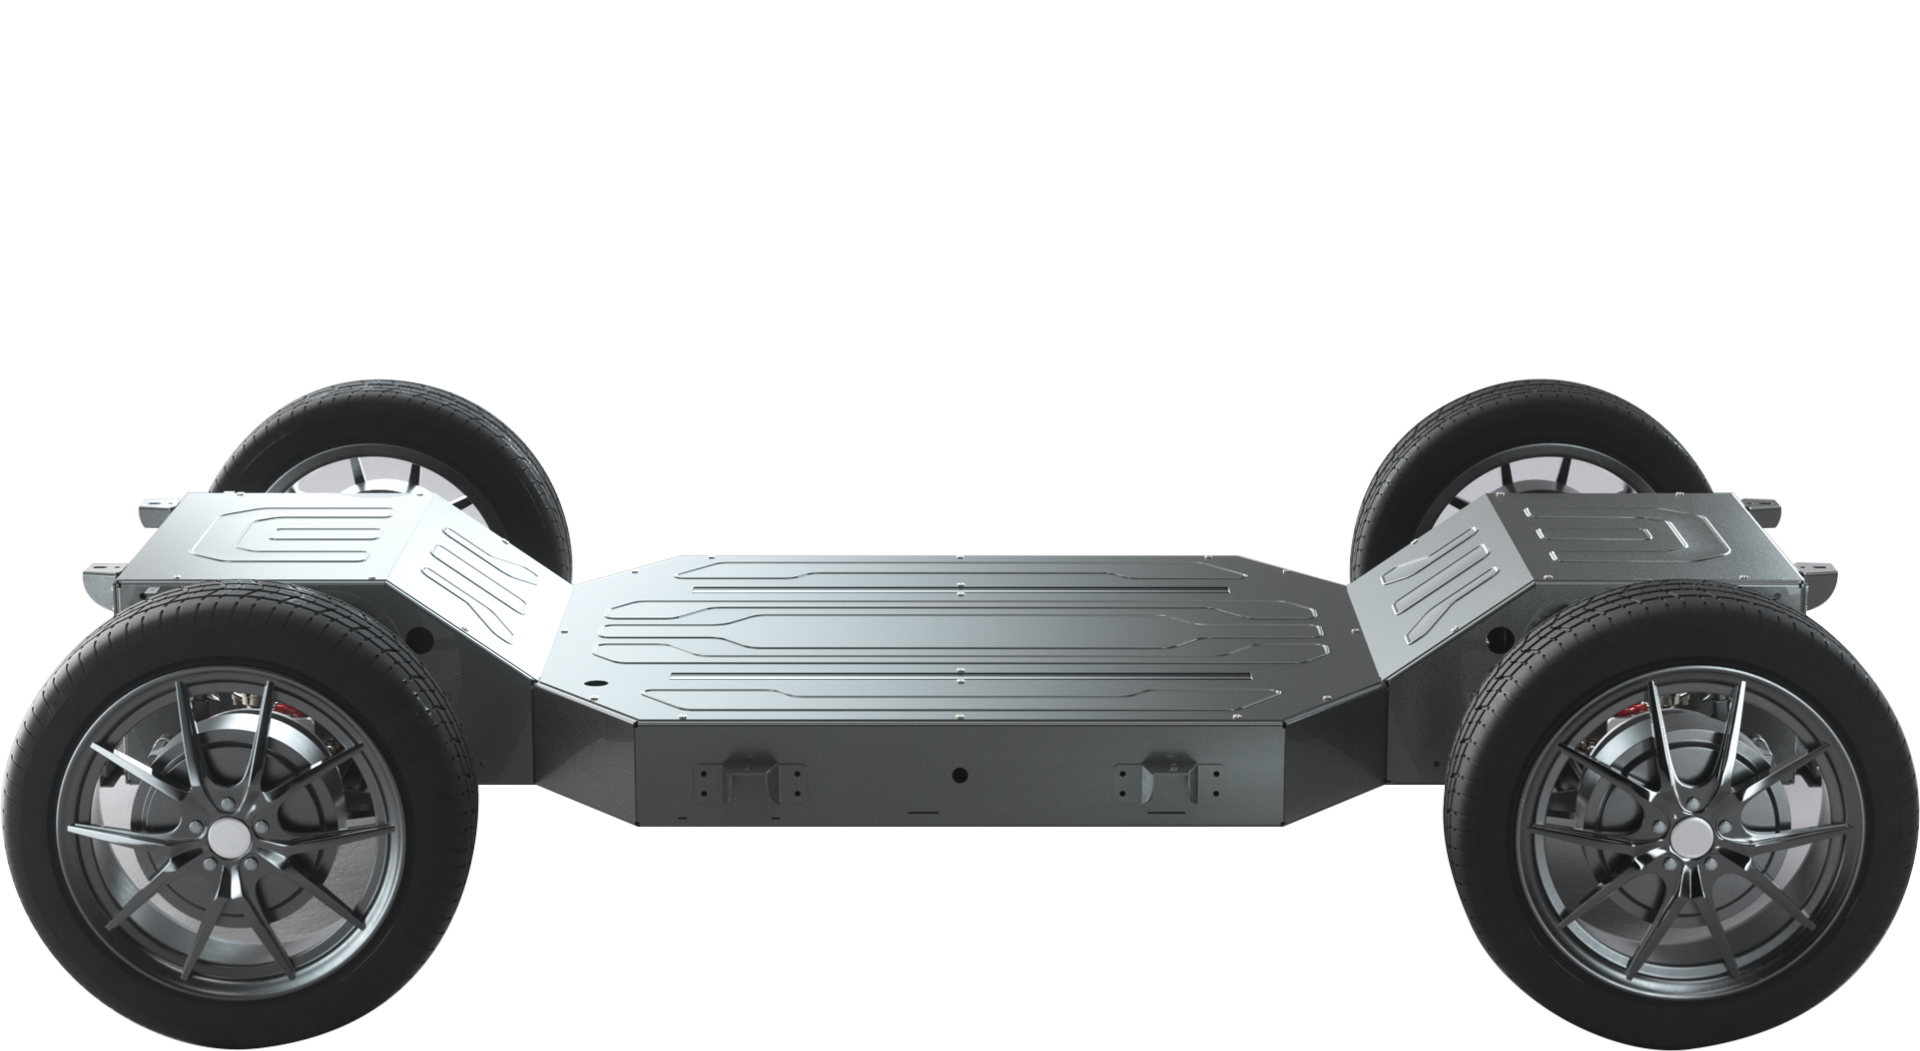
PIX Moving
£17.758,01
Descrizione
A drive-by-wire chassis platform dedicated to autonomous driving developers. With open CAN interface for engineering development and rapid prototyping of smart vehicles. Reliable, Flexible, Extensible As a software-defined chassis platform, PIXLOOP offers comprehensive, open and powerful API interfaces for developers. PIXLOOP supports open-source software like Autoware and Apollo, users are empowered to focus on their application development based on PIXLOOP, significantly reducing the development cost and lead time for autonomous driving and smart vehicle applications. PIXLOOP - Hooke Size: 2510 x 1700 x 630mm 70-100km Driving Mileage 500kg Without Load 20% Gradability 40km/h Maximum Speed (Limit set by software) 4-wheel Steering Basic Parameters Battery capacity(kW·h) 10.8 Cruise range(km) 130 Slow charging time(h) 7.5 Acceleration time (s)(0-30Km) No load 4.5 Driving type Four-wheel drive Maximum payload (kg) 500 Steering type Two-wheel/four-wheel/wedge steering Complete vehicle warranty 1 year Chassis Parameters Overall dimensions (mm) 2520×1680×630(±15) Wheelbase (mm) 1900 Front/Rear Wheel Track (mm) 1470/1470(±5) Front/Rear Overhang (mm) 237/237 Min Ground Clearance (mm)(Full Load) 215 Approach Angle /Departure Angle (°) / Min Ground Clearance (mm)(No Load) ≥240 Min Turning Radius (m) ≤3.5 Curb Weight (kg) 480(±10) Max Allowable Load Mass (kg) 500 Full Load Mass (kg) 980(±10) Normal Speed (Km/h) ≤40 Max Speed (Km/h) No Load(A Disclaimer Agreement Needs to be Signed) 60 Max Gradability (%) No Load 30 Acceleration Time (s)(0-30Km) No Load 4.5 Inner/Outer Wheel Steering Angle (°) 29/26 Suspension Type Front & Rear Double Wishbone Independent Suspension Tire Specifications 215/45R17 IP Level IP56 Suspension spring travel (mm) Full load 30±3 Frame Material High strength steel Steering System Rated Power (KW) 0.5 Rated Torque(N.M) 4.5 Rated Rotating Speed (r/min) 1050 Operating Voltage (V) 10.8~14 Steering Range (°) ±450 Steering Structure Drive-by-wire Electric Steering Steering Type Ackerman Steering Steering Mode Two-wheel/four-wheel/wedge steering Operating Temperature (℃) -40~105 Communication Speed (kps) 500 Steering Accuracy (°) 1 Response Time (ms) ≤150 Max Output Force of Steering Rod (N) 10000 Communication Protocol CAN2.0B Steady-state error (°) ±1 Overshoot (°) ≤15 Control Method Target Steering Wheel Angle & Angular Velocity Toe-in (mm) 5 Braking System Braking Type for Driving Drive-by-wire Hydraulic Braking Braking Type for Parking Electronic Parking System Overshoot(Mpa) 0.5 Brake Type Disc Motor Type Permanent Magnet Brushless Motor Rated Power (KW) 0.45 Rated Torque(N.M) 2.3 Rated Rotating Speed (r/min) 1700 Operating Voltage (V) 9~14 Response Time (ms) ≤200 Communication Protocol CAN2.0B Max Braking Pressure (Mpa) 7 Max Pressure Build-up Time(ms) ≤300ms Control Method Target pressure closed loop Control precision (Mpa) 0.1 Steady-state Error (Mpa) 0.3 Operating Temperature (℃) -40 ~ 85 Max Braking Distance (m)Full load@30km/h ≤6 Drive system Rated Power (KW) 12 Rated Torque(N.M) 4×126 Rated Rotating Speed (r/min) 230 Peak Power(KW) 4×3.8 Peak Torque (N.M) 4×180 Peak Rotating Speed (r/min) 550 Rated Voltage (V) 72V Cooling Method Air Cooling Speed Control Accuracy (km/h) 0.1 Motor Size (mm) ø280 Responding Speed (ms) ≤200ms Steady-state Error (km/h) 0.2 Communication Protocol CAN2.0B Drive motor type Permanent Magnet Brushless DC Motor Overshoot (km/h) 0.4 Control Method Accelerator Pedal Opening (Torque Control & Speed Control) Tire Specifications 215/45R17 Battery System Power Battery Type Ternary Lithium Battery Rated Voltage of Battery System (V) 72 Rated Capacity of Battery System (AH) 150 Battery System Energy (kW.h) 10.8 Max Output Power of Battery System(KW)(less than or equal to 60S) 25 Over-discharge Protection Method for Power Battery BMS Overcharge Protection Method for Power Battery BMS Charging Method AC Slow Charge Charging Time (h) 7.5 Cooling Method Natural Cooling Low Voltage Starting Power Lead-acid Battery Operating Voltage(V) 12~14 Lighting and Interface Front Light ● Front Steering Light ● Rear Steering Light ● Rear Braking Light ● OBD Diagnostic Interface ● DB9 control interface ● Chassis Communication Type CAN2.0B Autonomous Driving System Reserved Interface Power supply interface 12V500W(24V300W) Auxiliary Safety Functions Automatic parking with power off ● Overcharge and Over-discharge Protection Method for Power Battery ● OTA remote upgrade ● Software protection for steering limit ● False-touch protection for push rod of remote control ● Low-speed remote control mode ● Emergency stop buttons on chassis and remote control ● Remote Parking ● Built BY Engineers FOR Engineers A drive-by-wire chassis platform dedicated to autonomous driving developers. Comes with a set of sensors to achieve the basic autonomous driving functions, like path planning, path following, vector map building, obstacle avoidance, traffic lights recognition etc. The sensor package includes LiDAR, camera, computing unit, navigation system etc.. PIX platforms have rich open CAN interface for users to integrate the upper control layer for further software development and algorithms testing. The PIXKIT Hooke supports Autoware. Core/Universe and ROS2.
A drive-by-wire chassis platform dedicated to autonomous driving developers. With open CAN interface for engineering development and rapid prototyping of smart vehicles. Reliable, Flexible, Extensible As a software-defined chassis platform, PIXLOOP offers comprehensive, open and powerful API interfaces for developers. PIXLOOP supports open-source software like Autoware and Apollo, users are empowered to focus on their application development based on PIXLOOP, significantly reducing the development cost and lead time for autonomous driving and smart vehicle applications. PIXLOOP - Hooke Size: 2510 x 1700 x 630mm 70-100km Driving Mileage 500kg Without Load 20% Gradability 40km/h Maximum Speed (Limit set by software) 4-wheel Steering Basic Parameters Battery capacity(kW·h) 10.8 Cruise range(km) 130 Slow charging time(h) 7.5 Acceleration time (s)(0-30Km) No load 4.5 Driving type Four-wheel drive Maximum payload (kg) 500 Steering type Two-wheel/four-wheel/wedge steering Complete vehicle warranty 1 year Chassis Parameters Overall dimensions (mm) 2520×1680×630(±15) Wheelbase (mm) 1900 Front/Rear Wheel Track (mm) 1470/1470(±5) Front/Rear Overhang (mm) 237/237 Min Ground Clearance (mm)(Full Load) 215 Approach Angle /Departure Angle (°) / Min Ground Clearance (mm)(No Load) ≥240 Min Turning Radius (m) ≤3.5 Curb Weight (kg) 480(±10) Max Allowable Load Mass (kg) 500 Full Load Mass (kg) 980(±10) Normal Speed (Km/h) ≤40 Max Speed (Km/h) No Load(A Disclaimer Agreement Needs to be Signed) 60 Max Gradability (%) No Load 30 Acceleration Time (s)(0-30Km) No Load 4.5 Inner/Outer Wheel Steering Angle (°) 29/26 Suspension Type Front & Rear Double Wishbone Independent Suspension Tire Specifications 215/45R17 IP Level IP56 Suspension spring travel (mm) Full load 30±3 Frame Material High strength steel Steering System Rated Power (KW) 0.5 Rated Torque(N.M) 4.5 Rated Rotating Speed (r/min) 1050 Operating Voltage (V) 10.8~14 Steering Range (°) ±450 Steering Structure Drive-by-wire Electric Steering Steering Type Ackerman Steering Steering Mode Two-wheel/four-wheel/wedge steering Operating Temperature (℃) -40~105 Communication Speed (kps) 500 Steering Accuracy (°) 1 Response Time (ms) ≤150 Max Output Force of Steering Rod (N) 10000 Communication Protocol CAN2.0B Steady-state error (°) ±1 Overshoot (°) ≤15 Control Method Target Steering Wheel Angle & Angular Velocity Toe-in (mm) 5 Braking System Braking Type for Driving Drive-by-wire Hydraulic Braking Braking Type for Parking Electronic Parking System Overshoot(Mpa) 0.5 Brake Type Disc Motor Type Permanent Magnet Brushless Motor Rated Power (KW) 0.45 Rated Torque(N.M) 2.3 Rated Rotating Speed (r/min) 1700 Operating Voltage (V) 9~14 Response Time (ms) ≤200 Communication Protocol CAN2.0B Max Braking Pressure (Mpa) 7 Max Pressure Build-up Time(ms) ≤300ms Control Method Target pressure closed loop Control precision (Mpa) 0.1 Steady-state Error (Mpa) 0.3 Operating Temperature (℃) -40 ~ 85 Max Braking Distance (m)Full load@30km/h ≤6 Drive system Rated Power (KW) 12 Rated Torque(N.M) 4×126 Rated Rotating Speed (r/min) 230 Peak Power(KW) 4×3.8 Peak Torque (N.M) 4×180 Peak Rotating Speed (r/min) 550 Rated Voltage (V) 72V Cooling Method Air Cooling Speed Control Accuracy (km/h) 0.1 Motor Size (mm) ø280 Responding Speed (ms) ≤200ms Steady-state Error (km/h) 0.2 Communication Protocol CAN2.0B Drive motor type Permanent Magnet Brushless DC Motor Overshoot (km/h) 0.4 Control Method Accelerator Pedal Opening (Torque Control & Speed Control) Tire Specifications 215/45R17 Battery System Power Battery Type Ternary Lithium Battery Rated Voltage of Battery System (V) 72 Rated Capacity of Battery System (AH) 150 Battery System Energy (kW.h) 10.8 Max Output Power of Battery System(KW)(less than or equal to 60S) 25 Over-discharge Protection Method for Power Battery BMS Overcharge Protection Method for Power Battery BMS Charging Method AC Slow Charge Charging Time (h) 7.5 Cooling Method Natural Cooling Low Voltage Starting Power Lead-acid Battery Operating Voltage(V) 12~14 Lighting and Interface Front Light ● Front Steering Light ● Rear Steering Light ● Rear Braking Light ● OBD Diagnostic Interface ● DB9 control interface ● Chassis Communication Type CAN2.0B Autonomous Driving System Reserved Interface Power supply interface 12V500W(24V300W) Auxiliary Safety Functions Automatic parking with power off ● Overcharge and Over-discharge Protection Method for Power Battery ● OTA remote upgrade ● Software protection for steering limit ● False-touch protection for push rod of remote control ● Low-speed remote control mode ● Emergency stop buttons on chassis and remote control ● Remote Parking ●
Storico dei prezzi
Un dato al giorno, calcolato in base alla data di rilevazione.
Importi in USD
Le medie sono calcolate per giorno UTC sulla base di tutti i prezzi delle offerte registrati.

XAG
$18.977

Unitree
$16.800

AgileX
$17.500

AgileX
$18.500

Ikitbot
a partire da 16.500 €
Inbolt
18.800 €
Mech-Mind Robotics
17.616 €
Mech-Mind Robotics
16.032 €
AIRSKIN
19.400 €

Elephant Robotics
19.900 zł

Elephant Robotics
13.900 zł

Unitree
$12.900
🍪 Preferenze cookie
Utilizziamo i cookie per misurare le prestazioni. Informativa sulla privacy