Istraživački Papers

Sažeci najnovijih istraživanja iz robotike jednostavnim jezikom — humanoidni roboti, četveronošci, industrijska automatizacija i umjetna inteligencija.
499 radova
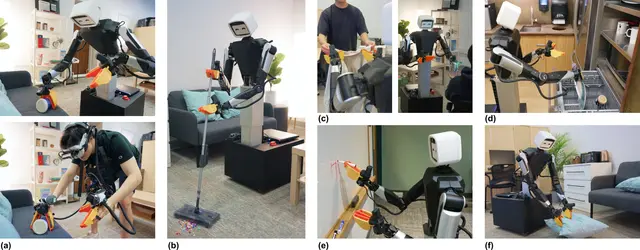
Pixel Robot Learns Mobile Manipulation from Human and Robot Demonstrations
AIprije 6 dana

Pixel Robot Learns Mobile Manipulation from Human and Robot Demonstrations

Pixel combines an affordable wheeled humanoid with human demonstrations, whole-body control, and learning policies for mobile manipulation.

Tony Tao, Jason Jingzhou Liu, Ruslan Salakhutdinov, Deepak Pathak

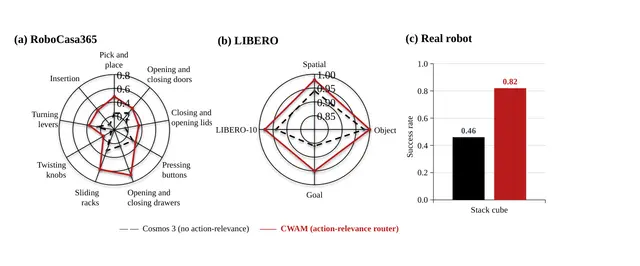
A Robot World Model Learns Which Objects Matter for Each Action
AIprije 7 dana

A Robot World Model Learns Which Objects Matter for Each Action

CausalWAM learns to route task-relevant visual details to a robot action model, outperforming random token selection in reported manipulation tests.

Juntao Cheng, Jinzhou Tang, Fan Feng +2

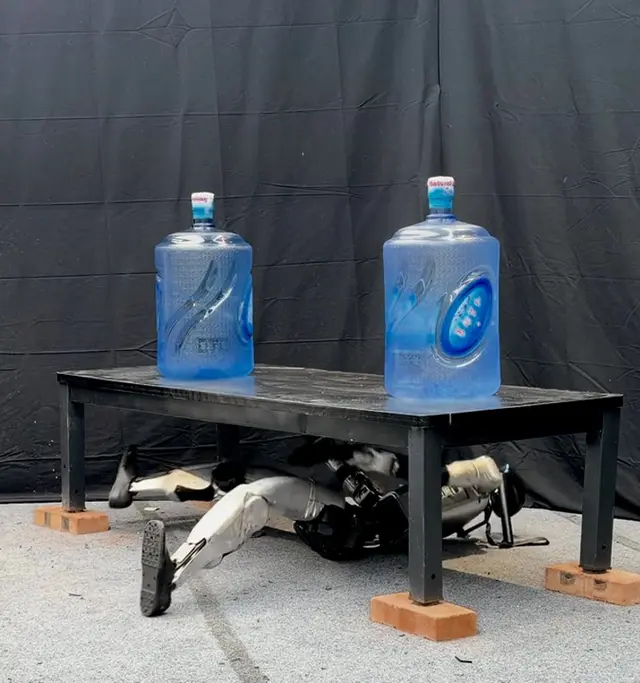
How Humanoids Learn to Escape Tight Spaces and Stand Up Safely
Humanoidprije 7 dana

How Humanoids Learn to Escape Tight Spaces and Stand Up Safely

ROOF teaches a humanoid to create clearance beneath overhead obstacles and stand using one proprioceptive recovery policy.

Yidan Lu, Jiayuan Yu, Zongrui Cai +5

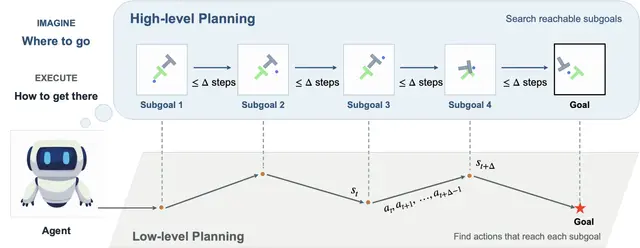
Hierarchical World Models Enable Reliable Long-Horizon Robot Planning with Implicit Dynamics
AIprije 7 dana

Hierarchical World Models Enable Reliable Long-Horizon Robot Planning with Implicit Dynamics
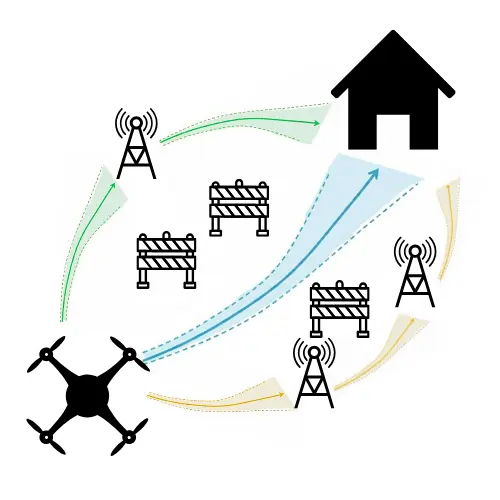
Gaoyue Zhou, Yvonne Wu, Zichen Jeff Cui +4

How Robots Plan Optimal Paths While Keeping Localization Uncertainty Below Limits
Roboticsprije 8 dana

How Robots Plan Optimal Paths While Keeping Localization Uncertainty Below Limits
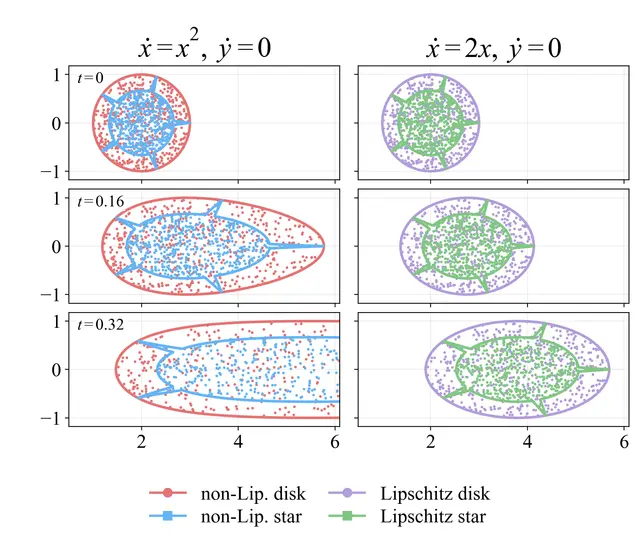
Chinmay Mundane, Manav Mishra, PB Sujit

How Many Robot Simulations Are Needed to Map Every Reachable State?
Roboticsprije 8 dana

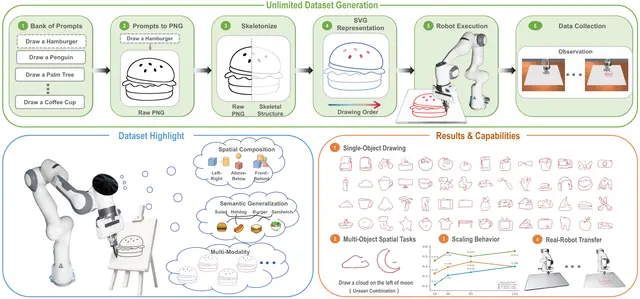
How Many Robot Simulations Are Needed to Map Every Reachable State?

A new analysis shows how state dimension, flow expansion, and sampling quality set fundamental limits on endpoint-based reachability estimates.

Jixian Liu, Ihab Tabbara, Hussein Sibai +1

Can Robots Draw New Objects from Instructions? BURGER Tests VLA Generalization
AIprije 8 dana

Can Robots Draw New Objects from Instructions? BURGER Tests VLA Generalization

BURGER tests whether vision-language-action robots can draw from instructions, generalize to new objects, and adapt to human edits.

Xiangyu Xu, Bangshuai Peng, Ziyi Liu +5

Robot Learns to Align, Latch, and Unfasten Screws with Force Feedback
Roboticsprije 9 dana

Robot Learns to Align, Latch, and Unfasten Screws with Force Feedback

Hemant Kumar, Piyush Goenka, Nikhil Chopra

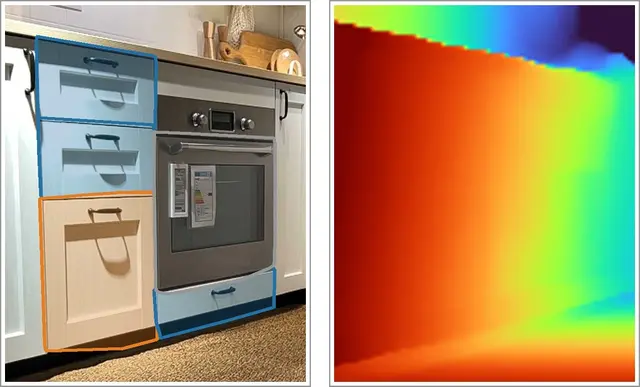
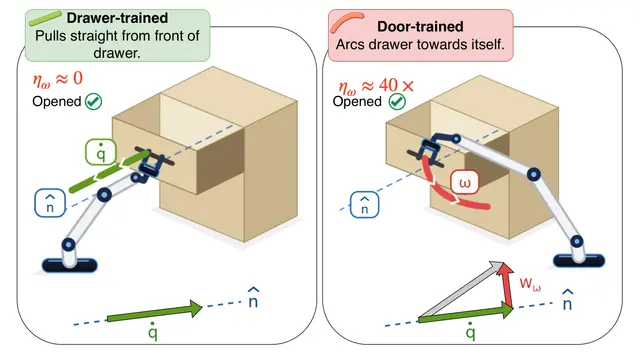
How Robots Learn Whether a Cabinet Door Swings or Slides Open
Roboticsprije 9 dana

How Robots Learn Whether a Cabinet Door Swings or Slides Open

Dibyendu Ghosh

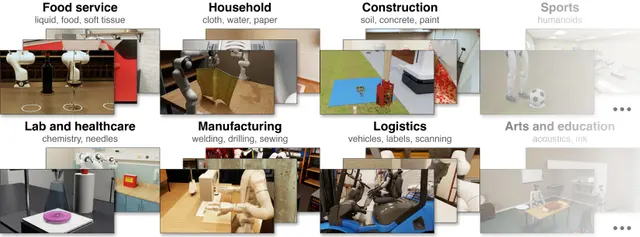
How Digital Agents Scale Realistic Physical Simulations for Better Robot Learning
AIprije 9 dana

How Digital Agents Scale Realistic Physical Simulations for Better Robot Learning

More broadly, our results suggest that simulation has been held back not by the idea of simulation, but by unrealistic simulations.

Pranjal Aggarwal, Sean Welleck

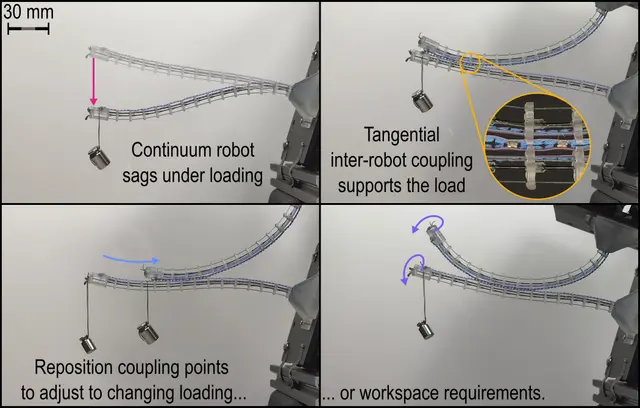
A Conveyor Belt Mechanism Enables Repositionable Magnetic Coupling Between Continuum Robots
Roboticsprije 10 dana

A Conveyor Belt Mechanism Enables Repositionable Magnetic Coupling Between Continuum Robots
This section introduces a novel conveyor belt mechanism integrated within a custom tendon-driven robot with a sub-centimeter diameter.

Ella Walsh, Eric Diller, Jessica Burgner-Kahrs

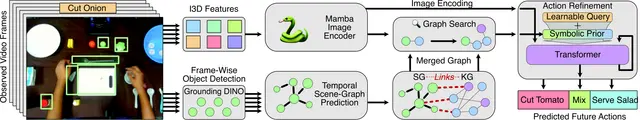
Symbolic Graphs Help Robots Predict Actions from Short Clips at Work
Roboticsprije 10 dana

Symbolic Graphs Help Robots Predict Actions from Short Clips at Work

Fnu Aryan, Yaqi Xie, Joseph Campbell +6

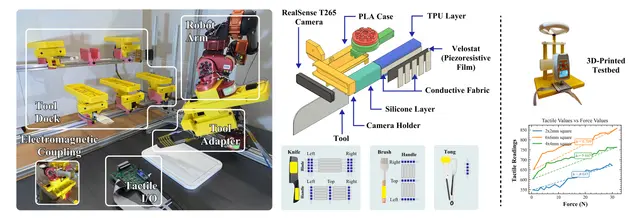
SwapBot Helps Robots Use Swappable Tools and Touch for Better Tasks
Roboticsprije 10 dana

SwapBot Helps Robots Use Swappable Tools and Touch for Better Tasks

Yunchu Zhang, Ray Song, Junhan Jiao +6

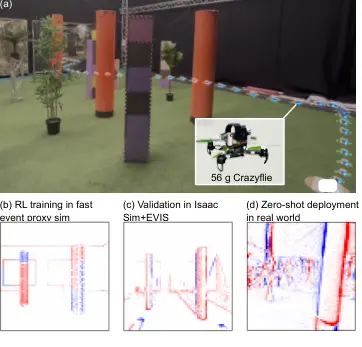
Rendering-Free Event Frame Simulation for Fast Reinforcement Learning in Drone Navigation
Roboticsprije 11 dana

Rendering-Free Event Frame Simulation for Fast Reinforcement Learning in Drone Navigation
These systems convincingly demonstrate the latency and dynamic-range advantages of events, but they execute their networks off-board or on onboard computers drawing typically 10 W or more.

Dequan Ou, Austin Lopez, Quentin Missinne +2

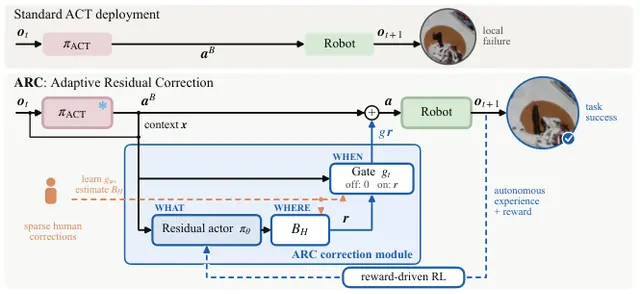
How Sparse Human Corrections Improve Precision in Existing Real-World Robot Policies
AIprije 11 dana

How Sparse Human Corrections Improve Precision in Existing Real-World Robot Policies
ARC uses sparse human corrections to guide when and where a robot refines its actions, while task reward selects what it executes.

Anukriti Singh, Maxime Caniot, Pratap Tokekar +1

How to Evaluate Robot Manipulation Against Articulated Object Kinematic Constraints
AIprije 11 dana

How to Evaluate Robot Manipulation Against Articulated Object Kinematic Constraints
Baptiste Bonin, Caro Strickland, Audrey Durand

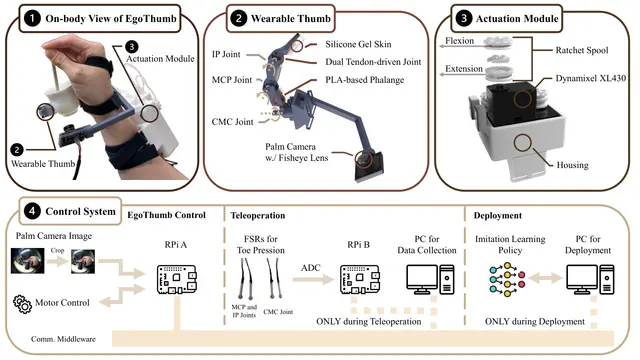
A Wearable Robotic Thumb Uses Vision to Grasp and Hold Objects
Roboticsprije 12 dana

A Wearable Robotic Thumb Uses Vision to Grasp and Hold Objects

Jianyu Hou, Jiawei Fu, Weikang Wan +3

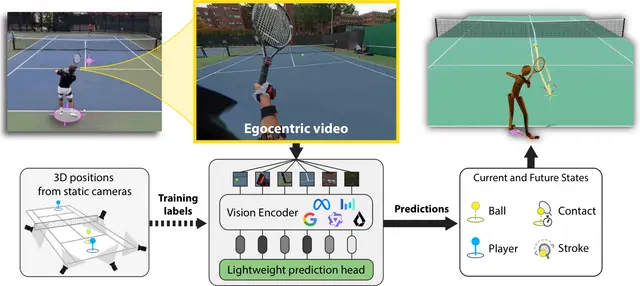
How Vision Models Track Tennis Balls and Predict Play in Motion
Roboticsprije 12 dana

How Vision Models Track Tennis Balls and Predict Play in Motion

A tennis-video study compares vision models for ball tracking and play prediction, finding that depth helps while longer histories do not always improve results.

Tudor Braicu, Joseph DelPreto, Jared Boyer +4

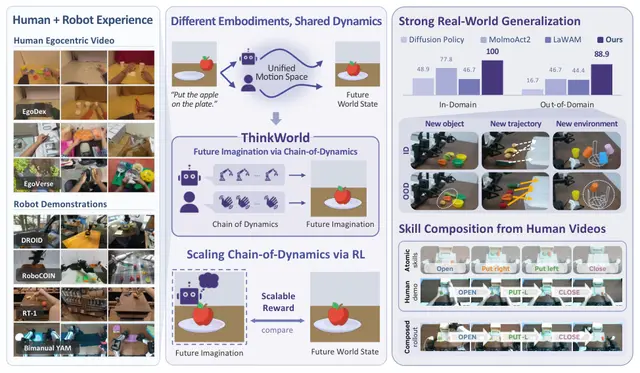
ThinkWorld Uses World Imagination to Strengthen Robot Action Reasoning
AIprije 12 dana

ThinkWorld Uses World Imagination to Strengthen Robot Action Reasoning

Once trained with joint supervision, the model generates CoDs and predicts future visual states conditioned on them.

Chaehyun Kim, Chi-Pin Huang, Jisoo Kim +4

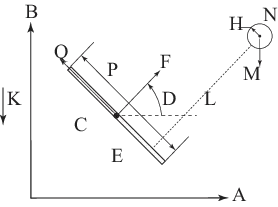
Robotic Catching Uses Virtual Constraints to Land Flying Pucks Without Sliding
Roboticsprije 13 dana

Robotic Catching Uses Virtual Constraints to Land Flying Pucks Without Sliding

Aakash Khandelwal, Ranjan Mukherjee