Istraživački Papers

Sažeci najnovijih istraživanja iz robotike jednostavnim jezikom — humanoidni roboti, četveronošci, industrijska automatizacija i umjetna inteligencija.
499 radova
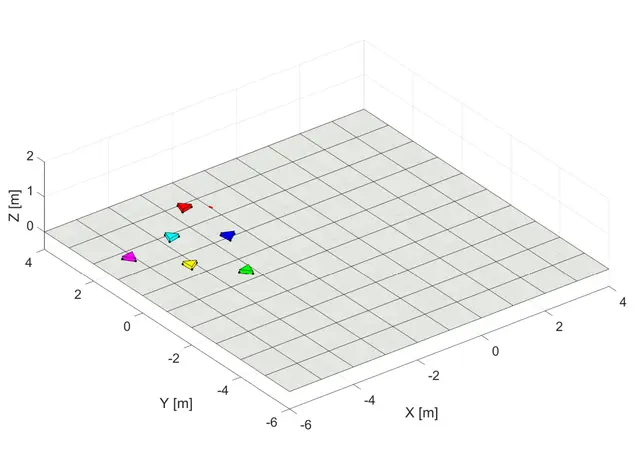
Energy-Based Formation and Collision Control for Multi-Agent Robot Systems
Robotics4. ruj

Energy-Based Formation and Collision Control for Multi-Agent Robot Systems

This section introduces the notation, an overview of port-Hamiltonian systems and graph theory, the model of the agents to be used, and the problem statement.

Martín Crespo, Sergio Junco, Matías Nacusse

Three Surgical Cameras Reveal When Robots See Much Better in 3D
Robotics3. ruj

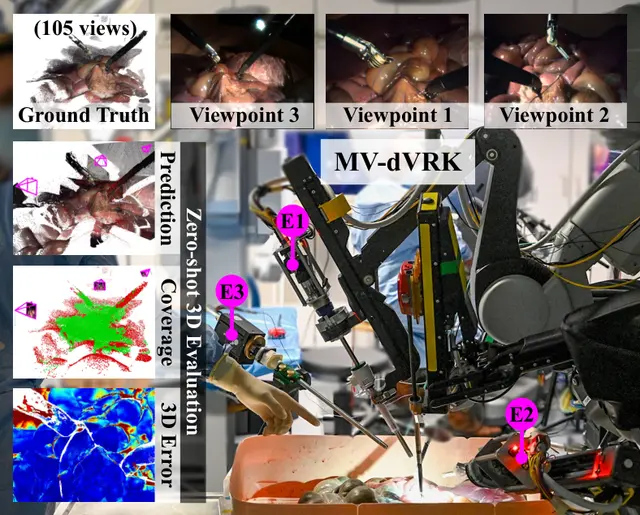
Three Surgical Cameras Reveal When Robots See Much Better in 3D

MV-dVRK benchmarks sparse surgical 3D perception and shows when a third synchronized endoscope makes multi-view reconstruction outperform stereo.

Guido Caccianiga, Sergey Prokudin, Yutong Chen +9

Evaluating World Models for Robot Control Under Real-Time Feedback
Robotics3. ruj

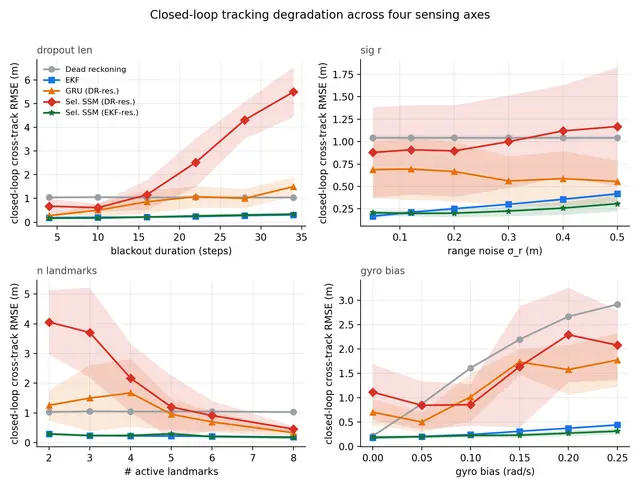
Evaluating World Models for Robot Control Under Real-Time Feedback

Although the experimental platform considered in this study is intentionally simple, the underlying evaluation issue applies more broadly to predictive models used in robotic systems.

Dharini Raghavan, Amritpal Singh

Robust LiDAR Semantic Segmentation for Safe Autonomous Driving Deployment
Robotics3. ruj

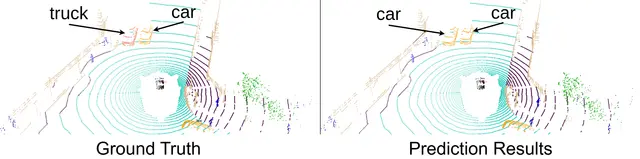
Robust LiDAR Semantic Segmentation for Safe Autonomous Driving Deployment

Samir Abou Haidar, Alexandre Chariot, Mehdi Darouich +2

Imitation Learning Loses Dexterous Robot Robustness at Higher Speeds
AI2. ruj

Imitation Learning Loses Dexterous Robot Robustness at Higher Speeds

Clinton Enwerem, John S. Baras, Calin Belta

Humanoid Robots Open Doors, Recover, and Sort Objects Autonomously
Humanoid2. ruj

Humanoid Robots Open Doors, Recover, and Sort Objects Autonomously

A reusable humanoid robot system opens doors, recovers from disturbances, and sorts objects using object-centric behaviors.

Duncan Calvert, Luigi Penco, Dexton Anderson +4

Pepper Robots Learn Where to Look Before Moving Through Dense Foliage
Robotics2. ruj

Pepper Robots Learn Where to Look Before Moving Through Dense Foliage

SG-AMP helps pepper-plant robots find hidden peduncles and navigate foliage by combining scene graphs, active perception, and semantic motion planning.

Rohit Menon, Shiva Rudra Lolla, Niklas Mueller-Goldingen +3

Autonomous Robot Manipulation Skills Through Language-Driven Quality-Diversity
Robotics1. ruj

Autonomous Robot Manipulation Skills Through Language-Driven Quality-Diversity

Émiland Garrabé, Mahdi Khoramshahi, Stéphane Doncieux

Two Arms Build 3D Maps from Calibrated RGB-D Data for Robots
Robotics1. ruj

Two Arms Build 3D Maps from Calibrated RGB-D Data for Robots

Manish Kansana, Mohammed Yusuf Mujawar, Sudip Mittal +2

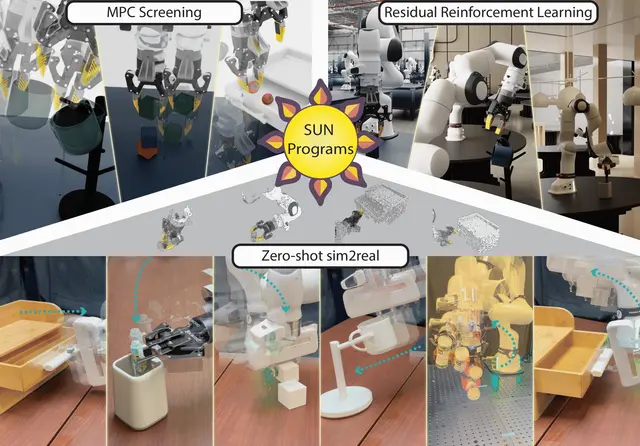
Persistent Programs for Language-Grounded Robot Control, Learning, and Transfer
AI1. ruj

Persistent Programs for Language-Grounded Robot Control, Learning, and Transfer

Data generators scale robot experience by retargeting object-relative demonstration segments across scene configurations.

Weiqi Wang, Zhi Li, Yudong Lei +7

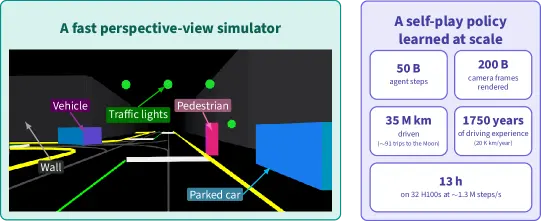
Pictura Trains Self-Driving Policies with Perspective Self-Play at Scale
AI31. kol

Pictura Trains Self-Driving Policies with Perspective Self-Play at Scale

Pictura trains driving policies from scratch using perspective self-play and a fast batch rasterizer, achieving zero-shot generalization.

Yuan Yin, Elias Ramzi, Marc Lafon +8

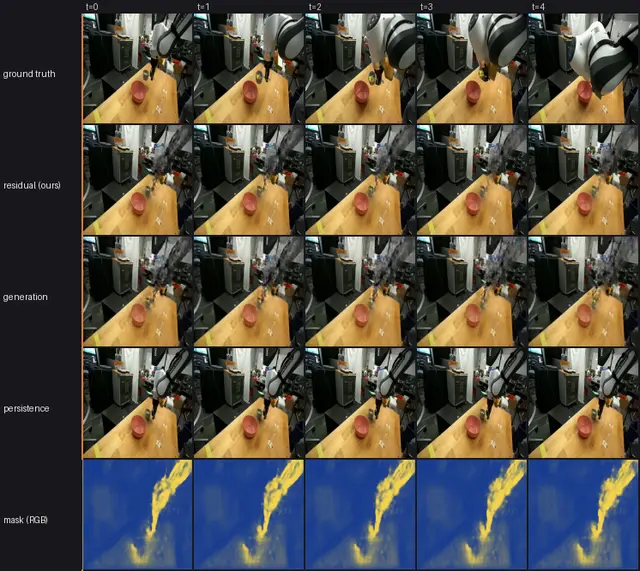
Particle World Modeling for Text-Assisted Robot Video Prediction
AI31. kol

Particle World Modeling for Text-Assisted Robot Video Prediction

Yafei Zhang, Nan Wu

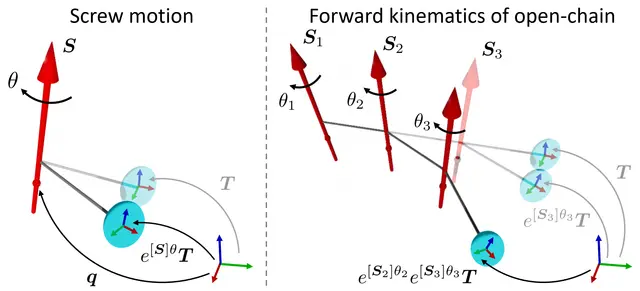
ChainSplat Helps Robots Learn Flexible Object Motion From RGB Video
Robotics31. kol

ChainSplat Helps Robots Learn Flexible Object Motion From RGB Video

Seungyeon Kim, Noémie Jaquier

Transitional AV Lane-Change Dataset Reveals How Gaps Converge and Collision Risk Peaks
Robotics30. kol

Transitional AV Lane-Change Dataset Reveals How Gaps Converge and Collision Risk Peaks
New field experiments with a transitional autonomous vehicle (tAV) performing 78 mandatory lane changes on a public road show that lead and lag gaps consiste…

Abhinav Sharma, Md Abdullah Al Hasan, Danjue Chen +1

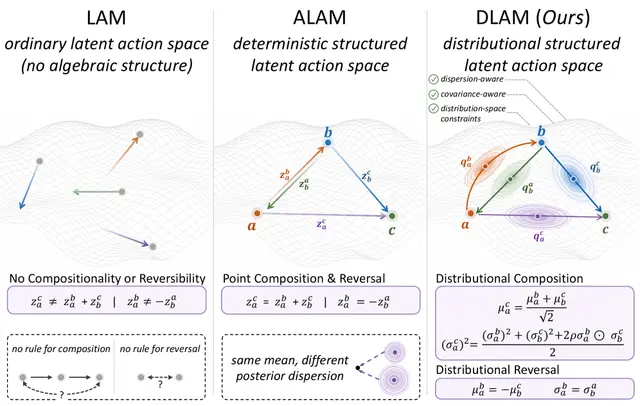
New Model Teaches Robots to Predict Visual Changes with Uncertain Latent Actions
AI30. kol

New Model Teaches Robots to Predict Visual Changes with Uncertain Latent Actions

DLAM learns distributional latent actions from visual transitions using temporal constraints, improving robot control without modifying policy architecture.

Zuojin Tang, Feifan Luo, Haoyun Liu +10

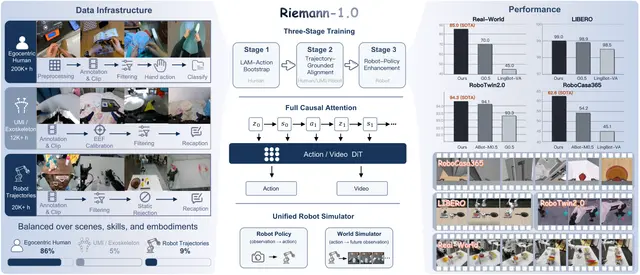
Riemann-1.0 Builds Embodied World Action Models for Physical AI
Robotics30. kol

Riemann-1.0 Builds Embodied World Action Models for Physical AI

Haofeng Sun, Jiangbo Pei, Fei Kang +13

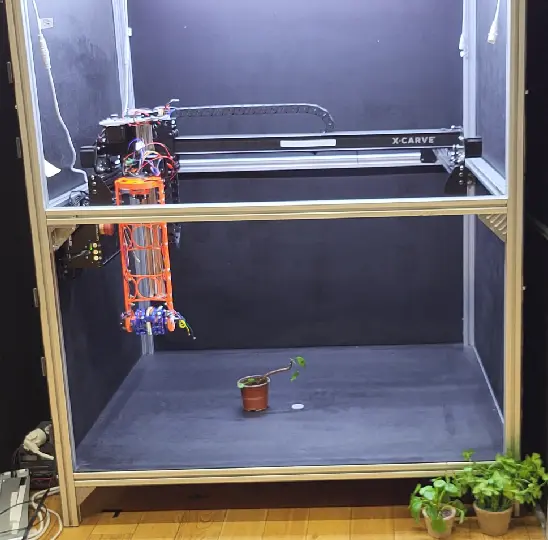
Robotic Active Sensing Maps Plant Stress Across Individual Plant Leaves
AI29. kol

Robotic Active Sensing Maps Plant Stress Across Individual Plant Leaves

Ayman Laaroussi, Peter Hanappe, David Colliaux

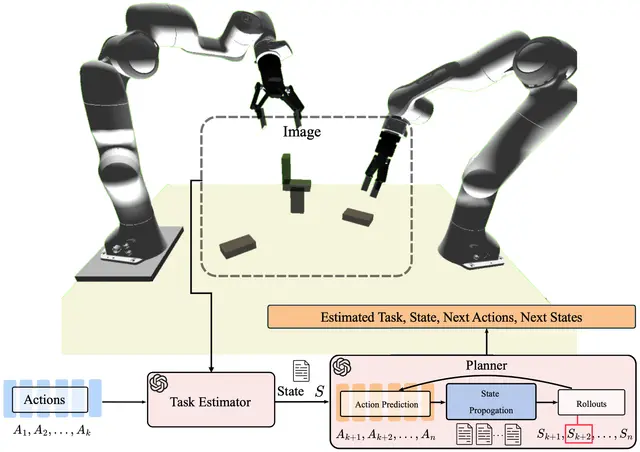
State-Aware Task Planning with Multimodal LLMs for Human-Robot Collaboration
AI29. kol

State-Aware Task Planning with Multimodal LLMs for Human-Robot Collaboration

STEP enhances long-term action anticipation with multimodal large language models by explicitly modeling state transitions.

Maitrey Gramopadhye, Prakash Baskaran, Xiao Liu +2

Scheduling Marine Autonomous Vehicle Fleets for Greater Scientific Impact
Robotics29. kol

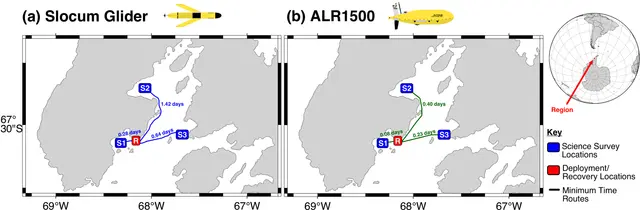
Scheduling Marine Autonomous Vehicle Fleets for Greater Scientific Impact

Marine Autonomous Vehicles are integral to future marine research infrastructure.

Mehdi El Krari, Jonathan Smith, Maria Fox

Task-Aware 3D Detection Improves Fast LiDAR Robot Perception
AI28. kol

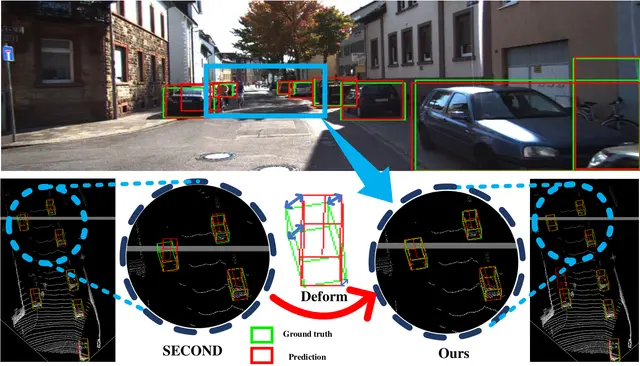
Task-Aware 3D Detection Improves Fast LiDAR Robot Perception

Su Wang, Yaochen Li, Min Yang +3