शोध Papers

नवीनतम रोबोटिक्स अनुसंधान के सरल भाषा में सारांश — मानवाकार रोबोट, चतुष्पद, औद्योगिक स्वचालन और एआई।
499 शोध-पत्र
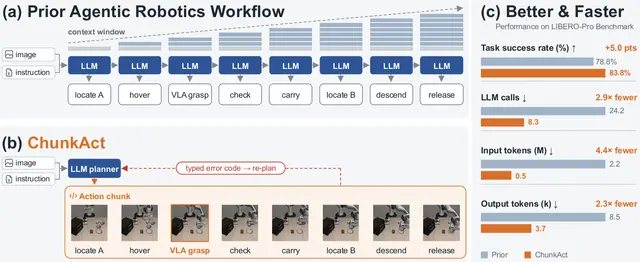
ChunkAct Lets Robots Reuse Task Plans Instead of Replanning Each Action
AI26 दिन पहले

ChunkAct Lets Robots Reuse Task Plans Instead of Replanning Each Action

ChunkAct compiles repeated robot procedures into reusable action chunks, reserving AI planning for key decisions and failures.

Bingxin Xu, Wenrui Bao, Xinxin Liu, Jiawei Zhou +2

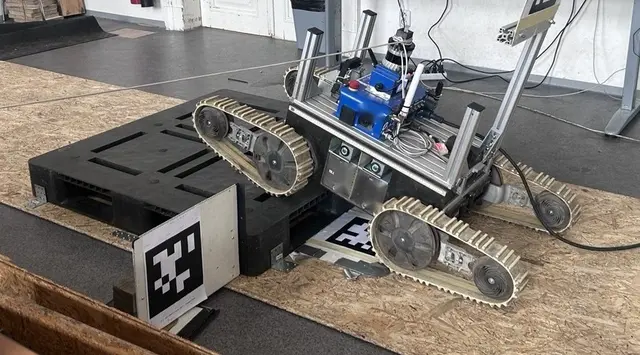
A Mapless Flipper Controller Helps Tracked Robots Stay Level and Escape
Robotics27 दिन पहले

A Mapless Flipper Controller Helps Tracked Robots Stay Level and Escape

A mapless flipper controller stabilizes an articulated tracked robot and helps it recover from stalls, including when tall grass hides a log.

Valentýn Číhala, Pavel Sarga, Martin Pecka +2

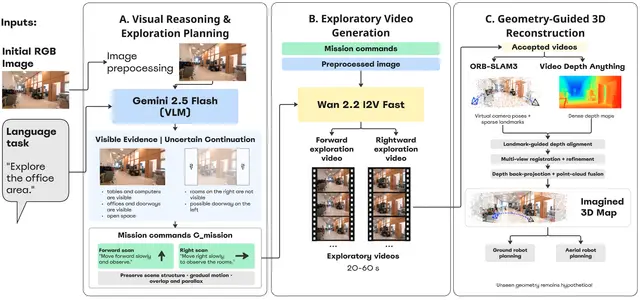
Robots Use Imagined Video to Build 3D Maps Before They Move
Robotics27 दिन पहले

Robots Use Imagined Video to Build 3D Maps Before They Move

HorizonNav uses generated future views to build tentative 3D maps, then plans routes independently of the imagined camera motion.

Hajira Amjad, Valerii Serpiva, Viacheslav Liubimov +2

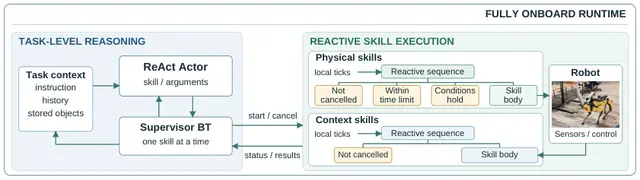
How Behavior-Tree Agents Make Onboard Robots More Reliable in Real Tasks
Robotics27 दिन पहले

How Behavior-Tree Agents Make Onboard Robots More Reliable in Real Tasks

Fabio Hübel, Adam Lilja, Yue Yin +5

Thermal Vision Helps Robots Find Hidden Wheel Tracks in Snow Safely
Robotics28 दिन पहले

Thermal Vision Helps Robots Find Hidden Wheel Tracks in Snow Safely

Yiming Yang, Jeremy P. Bos

Chronos Policy Uses Physical Time to Improve Robot Learning and Control
Robotics28 दिन पहले

Chronos Policy Uses Physical Time to Improve Robot Learning and Control

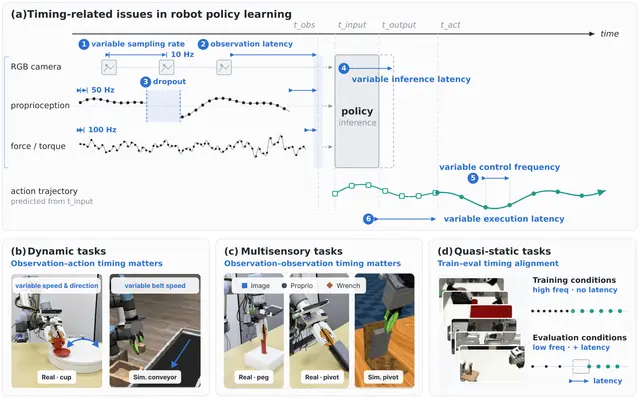
Chronos Policy makes observation and action timing explicit in the policy.

Changhao Wang, Jaden Clark, Shuran Song

Robots Learn New Tasks by Changing the Noise Behind Their Actions
Robotics28 दिन पहले

Robots Learn New Tasks by Changing the Noise Behind Their Actions

Noise Space Learning adapts a robot policy by changing its action noise while leaving the pretrained generator fixed.

Junjie Lu, Chuheng Zhang, Yucen Wang +4

How RoboRSI Helps Robots Improve and Reuse Skills in Real Environments
AI29 दिन पहले

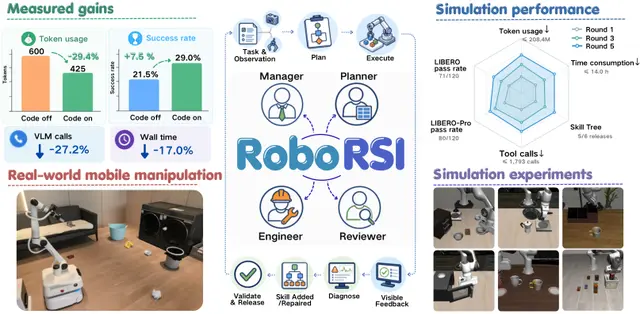
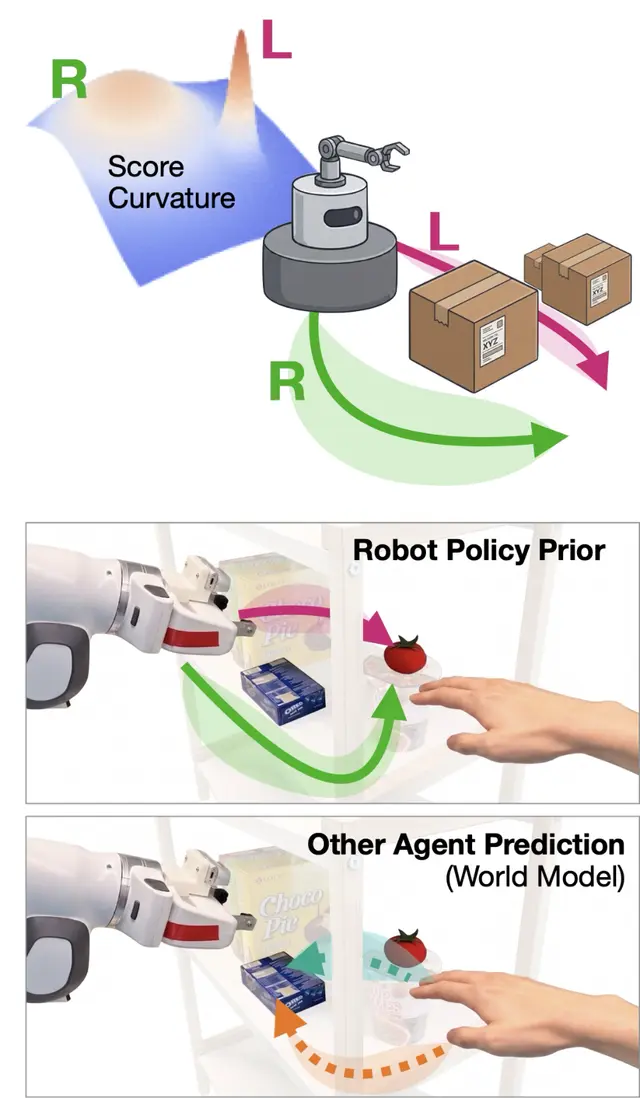
How RoboRSI Helps Robots Improve and Reuse Skills in Real Environments

Zimo Wen, Yijin Chen, Yuxuan Cao +8

Fast Robot Trajectory Uncertainty Enables Safer Paths Through Crowds and Obstacles
Robotics29 दिन पहले

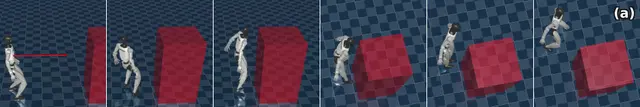
Fast Robot Trajectory Uncertainty Enables Safer Paths Through Crowds and Obstacles
Zhiwei Xue, Jia Yue Kam, Jinhang Qiu +5

A Safety Filter Helps Humanoids Stay Safe Without Sacrificing Their Tasks
AI29 दिन पहले

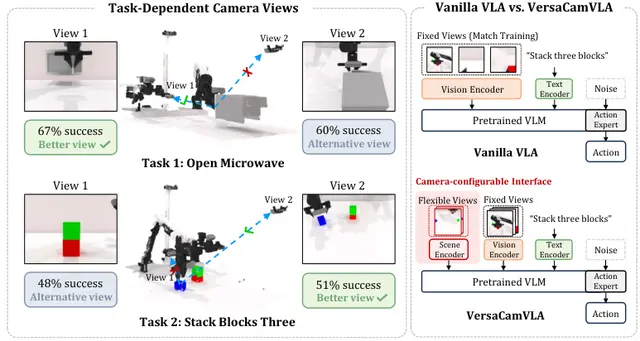
A Safety Filter Helps Humanoids Stay Safe Without Sacrificing Their Tasks

FAITH separates task learning from a learned safety filter, helping robots preserve performance when safe actions exist and reduce harm when they do not.

Songyuan Zhang, Baljeet Singh, Sarthak Ranjeet Kaingade +2

Flexible Camera Policies Help Robots Handle Changing Views During Manipulation Tasks
Robotics10 अक्टू॰

Flexible Camera Policies Help Robots Handle Changing Views During Manipulation Tasks
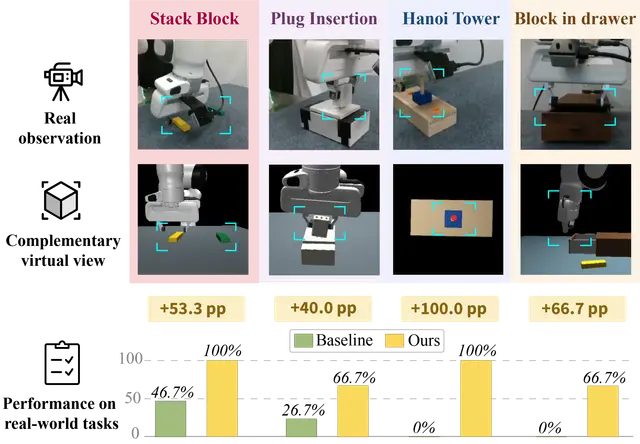
VersaCamVLA helps robot manipulation policies adapt to changing camera arrangements using learned scene tokens and wrist-camera motion.

Boyao Han, Chen Shi, Jingjing Qian +2

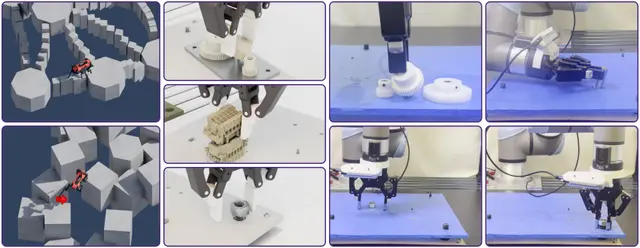
Virtual Views Help Robots Improve Fine Manipulation Success at Test Time
Robotics10 अक्टू॰

Virtual Views Help Robots Improve Fine Manipulation Success at Test Time

Jiayu Wang, Yue Yu, Bin Zhu +2

A Balanced Data Diet Improves Large-Scale Reinforcement Learning for Robot Control
AI10 अक्टू॰

A Balanced Data Diet Improves Large-Scale Reinforcement Learning for Robot Control

Octi Zhang, Mateo Guaman Castro, Patrick Yin +4

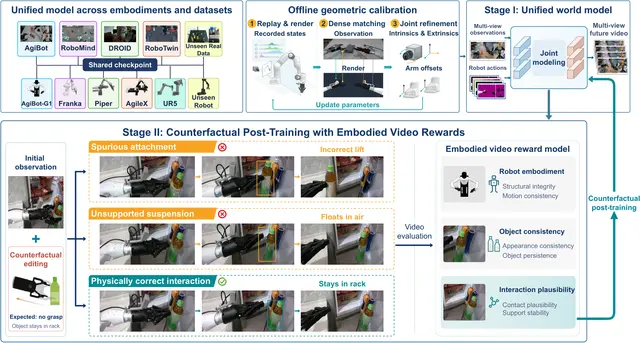
How Context-Aware Safety Filters Keep Generated Humanoid Motions Safe Near People
AI9 अक्टू॰

How Context-Aware Safety Filters Keep Generated Humanoid Motions Safe Near People

CSF filters text-generated robot motions using natural-language safety rules and scene context, redirecting strikes when a person is present.

Lizhi Yang, Yiling Hou, Yao Tang +4

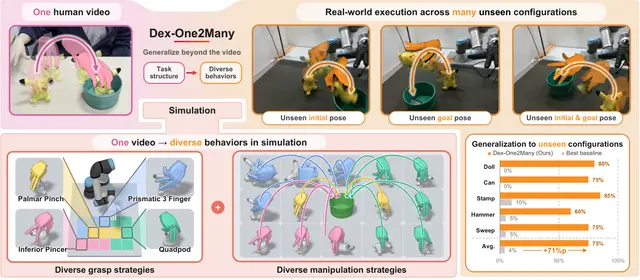
A Robot World Model That Tests Actions Before Robots Try Them
Robotics9 अक्टू॰

A Robot World Model That Tests Actions Before Robots Try Them

DreamTrue predicts robot-camera video after proposed actions and uses counterfactual training to improve action fidelity and policy evaluation.

Junyan Li, Ruizhi Li, Yu Liu +6

Learning Generalizable Dexterous Robot Manipulation from a Single Human Demonstration
Robotics9 अक्टू॰

Learning Generalizable Dexterous Robot Manipulation from a Single Human Demonstration
Jusuk Lee, Sungha Kim, Yeonsoo Park +8

Long-WAM Scales Visual Context for Predictive Robot Action and Control
AI8 अक्टू॰

Long-WAM Scales Visual Context for Predictive Robot Action and Control

Wei Huang, Bohan Zhang, Chenzhi Liu +13

Steer Robot Policies with Sparse Human Input Using RoboPrompt
Robotics8 अक्टू॰

Steer Robot Policies with Sparse Human Input Using RoboPrompt

Human intentions often underspecify robot actions.

Yanwen Zou, Chenyang Shi, Guoxuan Xu +5

Persistent 3D Object Memory for Spatial Questions in Egocentric Video
AI8 अक्टू॰

Persistent 3D Object Memory for Spatial Questions in Egocentric Video

We study how the objects retained, their estimated positions, movement histories, and contextual descriptions help answer different spatial questions.

Shravan Chaudhari, William Paul, Suchi Saria +2

When Is Robot Security Evidence Still Fast Enough to Act Safely?
Robotics7 अक्टू॰

When Is Robot Security Evidence Still Fast Enough to Act Safely?

Dimitrios Nikou, Nikolaos Kekatos, Sophia Petridou +1