Articles de recherche
Résumés en langage clair des dernières recherches en robotique — robots humanoïdes, quadrupèdes, automatisation industrielle et IA.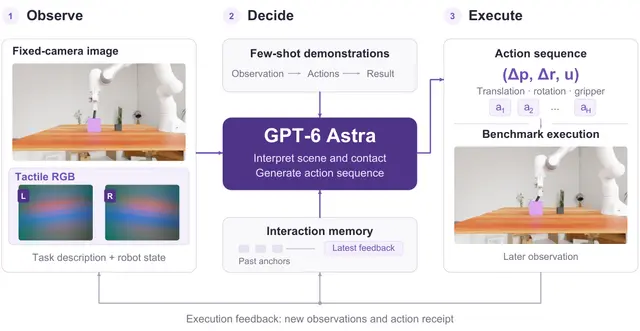
AIil y a 20 j
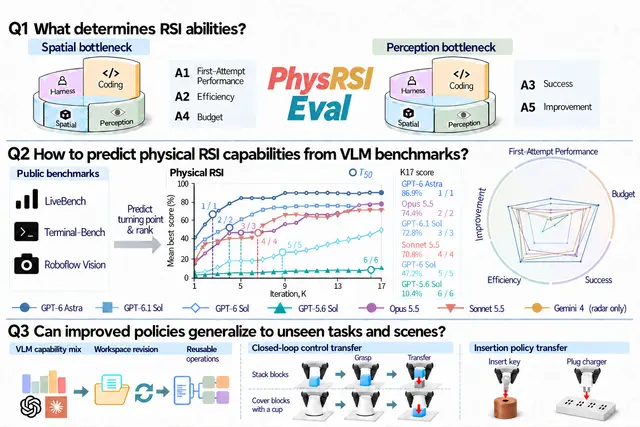
How LLMs Improve Robot Manipulation Through Physical Feedback and Repeated Practice
Roboticsil y a 20 j
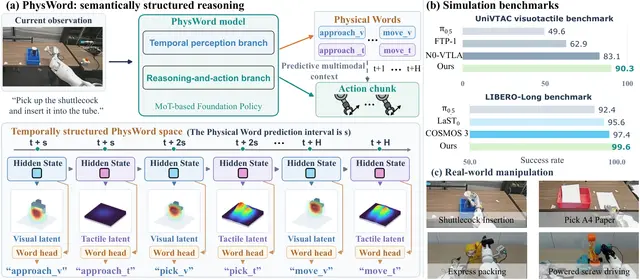
Robot Words Help Manipulators Predict Motion, Touch, and Reuse Actions Better
Roboticsil y a 21 j
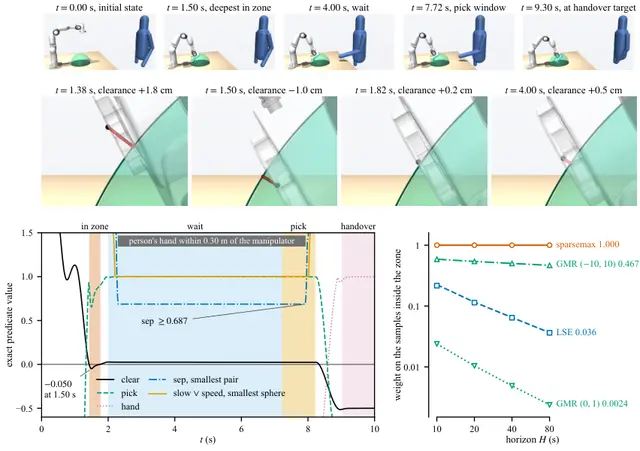
SparseMax-dSTL Enables Sound Temporal Logic Trajectory Optimization
Roboticsil y a 21 j
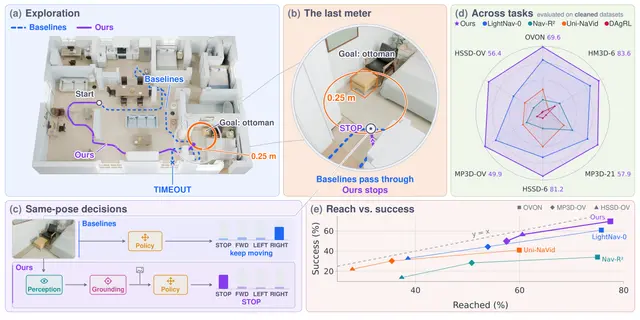
Why Robots Reach Navigation Goals but Still Fail to Stop Correctly
Roboticsil y a 21 j
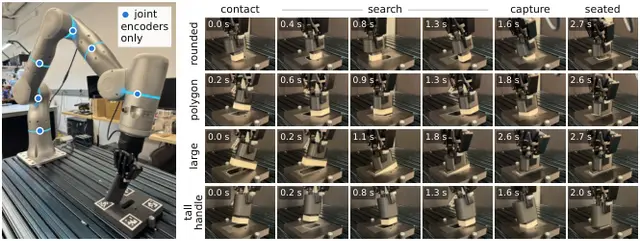
Precise Proprioceptive Sim-to-Real Robot Assembly for Diverse Pegs, Gears, and Nuts
AIil y a 22 j
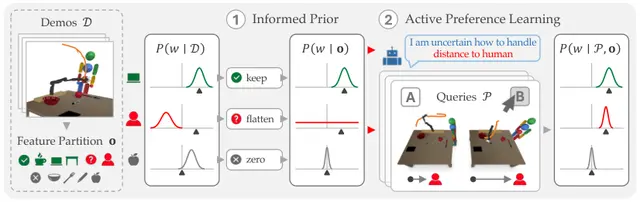
Robots Learn to Ask Better Questions About What People Really Want
Roboticsil y a 22 j
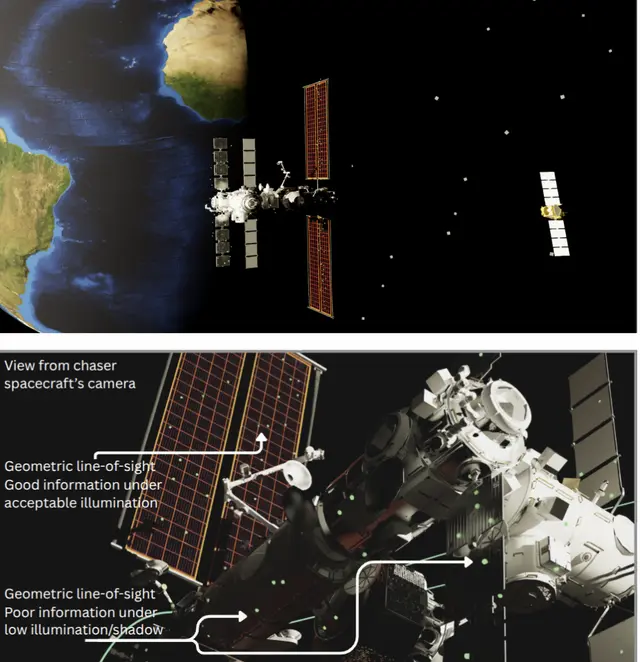
Active Perception for Better-Lit Autonomous Spacecraft Inspection in Orbit
Roboticsil y a 22 j
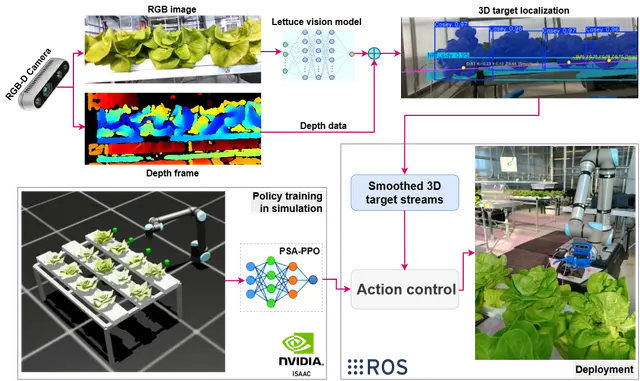
Path-Safe Sim-to-Real Learning for Hydroponic Lettuce Harvesting
AIil y a 23 j
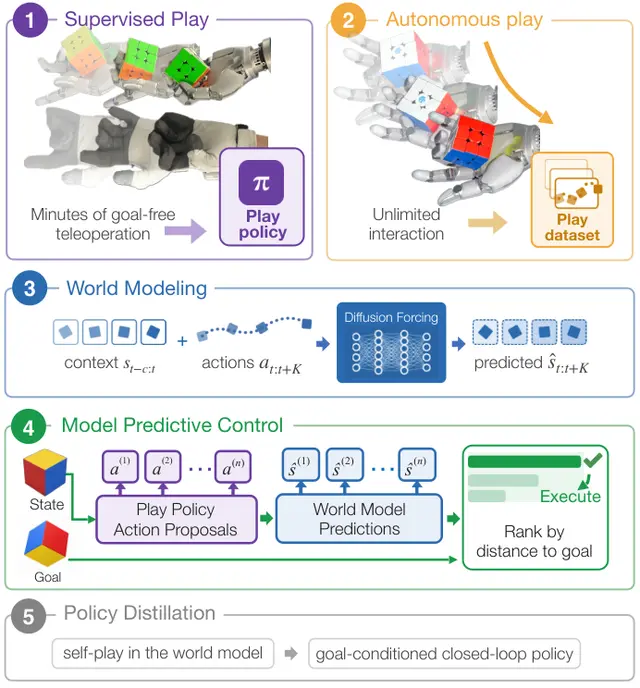
Dexterous Robot Manipulation Through Supervised Play and Planning
AIil y a 23 j
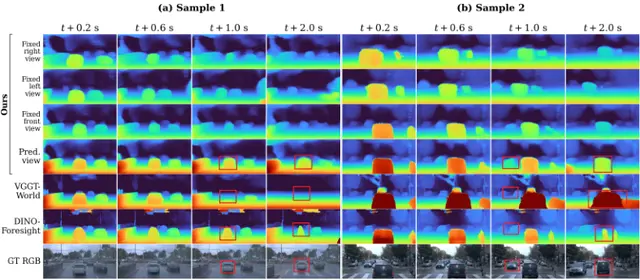
GeoState Helps Robots Predict 3D Scenes Beyond Their Current Camera View
AIil y a 23 j
How Co-Evolving Robot Training Worlds Helps Policies Learn and Adapt Better
Roboticsil y a 24 j
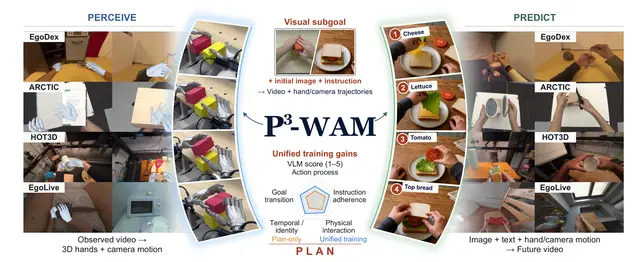
Dexterous Robots See, Predict, and Plan with One World Action Model
AIil y a 24 j
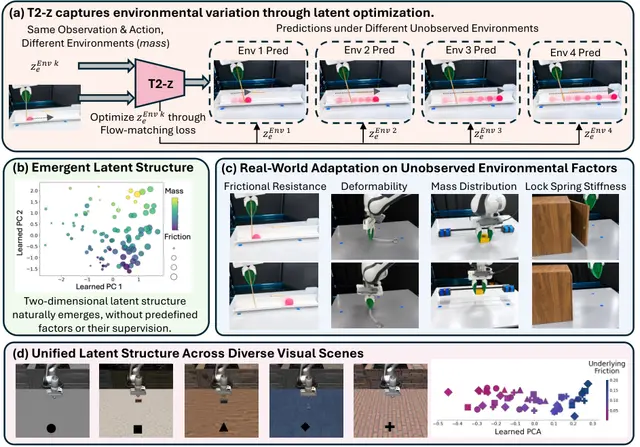
T2-z Optimizes Environment Latents for Robotic World Models at Test Time
Roboticsil y a 24 j
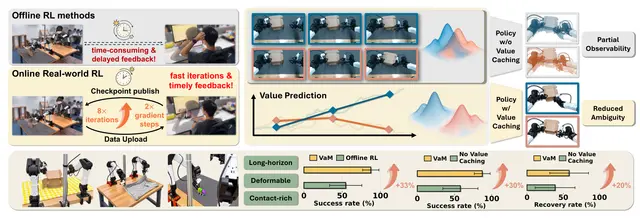
Robot Policies Turn Value Predictions Into Memory to Learn Online
AIil y a 25 j
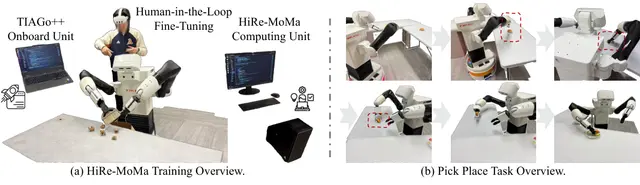
Sparse Human Guidance Trains Mobile Robots for Real-World Object Manipulation Tasks
Humanoidil y a 25 j
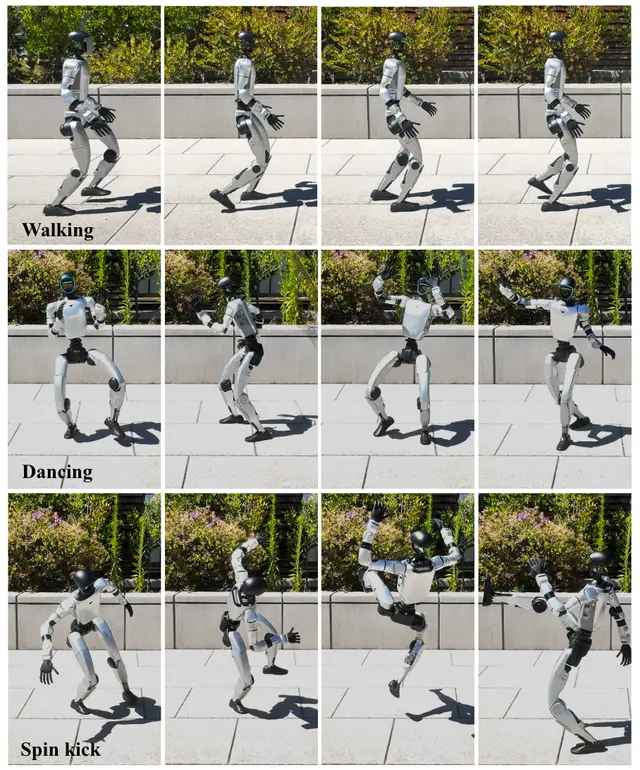
Diffusion Builds Humanoid Controllers From Weights for Real Robot Motion
Roboticsil y a 25 j
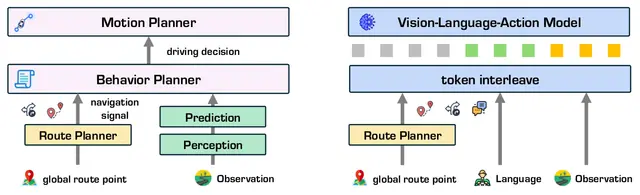
A Driving AI That Checks If Navigation Commands Are Safe First
Roboticsil y a 26 j
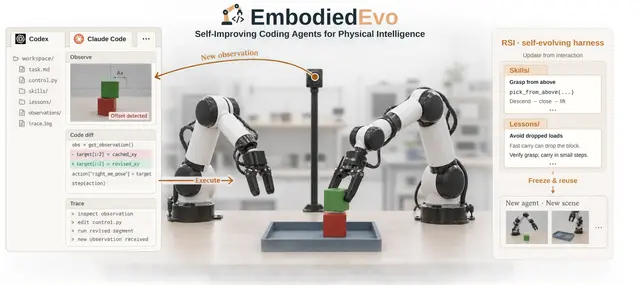
EmbodiedEvo: Coding Agents Build Reusable Skills for Physical Robot Tasks
AIil y a 26 j