Prix moyen quotidien
Montants en USD


The R1 EDU platform supports secondary development, fully open joint and sensor control interfaces, and mainstream simulation platforms. The EDU configuration also supports high-power computing modules in the 40–100 TOPS range.
With two Unitree tendon-driven dexterous hands, the U10 configuration adds 2 actuated degrees of freedom per hand to the 26-DOF R1 EDU base, for 30 total actuated degrees of freedom.
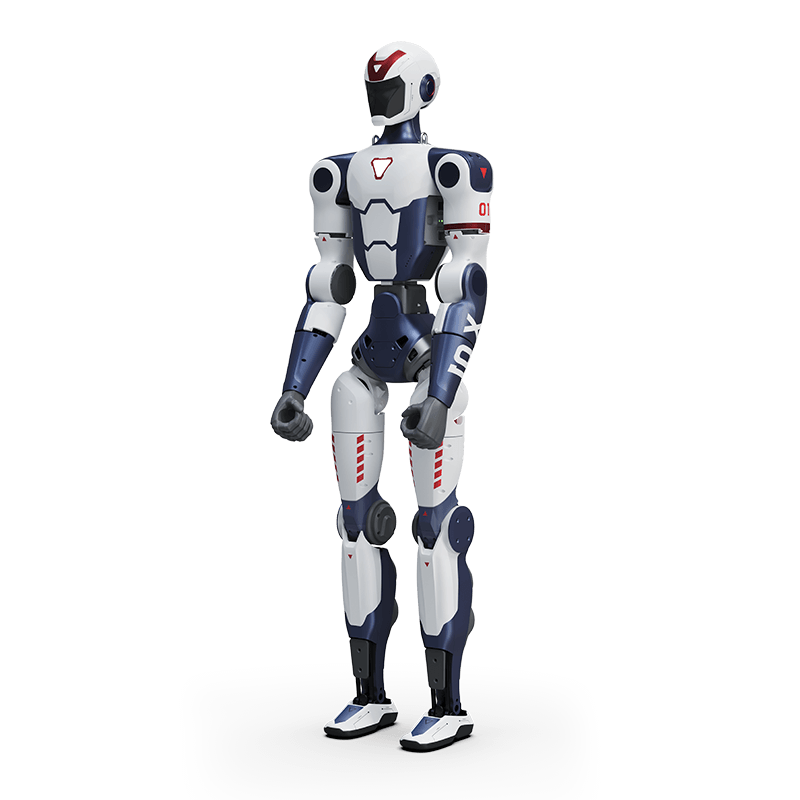
R1 EDU combines open development interfaces, high-performance computing, binocular perception, and optional dexterous manipulation hardware.
R1 EDU supports secondary development with open interfaces for robot joints and sensors.
The EDU platform supports high-power computing modules, including configurations up to 100 TOPS.
Each Unitree tendon-driven dexterous hand provides 2 actuated degrees of freedom with hidden internal wiring and compatibility with R1.
R1 EDU uses a binocular camera for onboard visual perception.
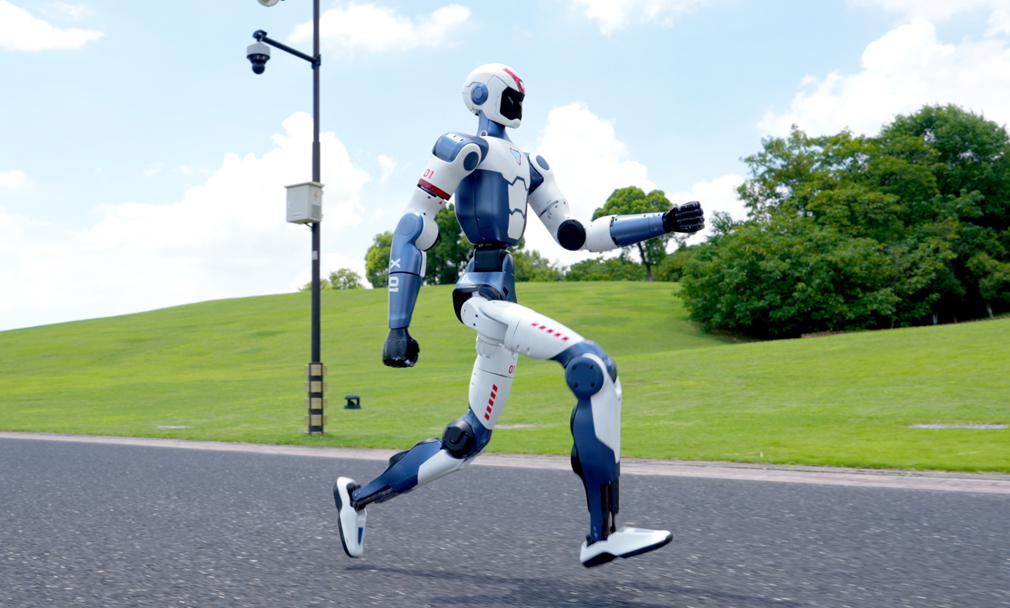

The R1 EDU base provides 26 joint degrees of freedom. Two Unitree Dex2/5 tendon-driven hands add 2 actuated degrees of freedom per hand.
R1 EDU combines an 8-core high-performance processor with optional high-power computing modules, binocular vision, open development interfaces, and support for mainstream simulation platforms.
Research-oriented R1 EDU configuration with high-power computing and dual dexterous hands.
| Specification | R1 EDU U10 |
|---|---|
| Dimensions (H × W × D), Standing | 47.6 × 14.1 × 7.5 in |
| Weight With Battery | Approx. 63.9 lbs |
| Total Degrees of Freedom | 26 |
| Degrees of Freedom Per Leg | 6 |
| Degrees of Freedom at Waist | 2 |
| Degrees of Freedom Per Arm | 5 |
| Degrees of Freedom at Head | 2 |
| Maximum Arm Load | 4.4 lbs |
| Calf + Thigh Length | 23.6 in |
| Arm Reach | Approx. 16.5 in |
| Waist Joint Range | Y: ±150° R: ±30° |
| Knee Joint Range | -10° to +139° |
| Hip Joint Range | Y: ±157° P: -168° to +146° R: -60° to +100° |
| Hollow Internal Wiring | Yes, throughout all joints |
| Joint Encoders | Dual + single encoders |
| Cooling System | Localized air cooling |
| Power Supply | Lithium-ion battery |
| Base Computing Power | 8-core high-performance CPU |
| Audio | Standard speakers and microphone array |
| Wireless Connectivity | Wi-Fi 6, Bluetooth 5.2 |
| Perception Sensors | Standard humanoid stereo camera; optional R1 LiDAR kit available |
| Included Power Accessories | 1 charger, 1 smart battery (quick-release) |
| Handheld Remote Control | 1 included |
| Battery Life | Approx. 1 hour |
| Smart OTA Updates | Supported |
| Customization | Available |
| Secondary Development | Supports both high-level and low-level customization; provides robot models and simulation interfaces; supports simulation environments such as Isaac Sim |
| Built-in Computing Docking Station | 40 TOPS, open to secondary development, with AI algorithm technical support |
| Development Support | Technical support services, comprehensive development manuals, and ecosystem support |
| Warranty | 12 months |
| Robot Accessories | Remote control, charger, robot transport case |
| Protective Mount | Not included by default |
| R1 EDU U10 Configuration | Includes all features of the R1 EDU Smart Edition |
| Dexterous Hands | 2 tendon-cable dexterous hands |
| Dexterous Hand DOF Per Hand | 2 |
| Total Robot Degrees of Freedom With Dexterous Hands | 30 (26 + 2 + 2) |
| Upgraded Computing Docking Station | 100 TOPS; supports secondary development and includes AI algorithm technical support |
| Simulation & Development Support | Supports high-level and low-level secondary development, robot models, simulation interfaces, and simulation environments such as Isaac Sim |
| Technical & Ecosystem Support | Technical support services, comprehensive development manuals, and ecosystem support |
| U10 Perception Sensors | Standard anthropomorphic stereo camera; optional R1 LiDAR kit available |
| Dexterous Hand Wiring | No external wiring between the dexterous hands and the robot |
| Wrist Camera | Not included |
| U10 Warranty | 12 months |
| U10 Protective Mount | Not included by default |
The R1 EDU platform supports secondary development, fully open joint and sensor control interfaces, and mainstream simulation platforms. The EDU configuration also supports high-power computing modules in the 40–100 TOPS range.
With two Unitree tendon-driven dexterous hands, the U10 configuration adds 2 actuated degrees of freedom per hand to the 26-DOF R1 EDU base, for 30 total actuated degrees of freedom.
R1 EDU combines open development interfaces, high-performance computing, binocular perception, and optional dexterous manipulation hardware.
R1 EDU supports secondary development with open interfaces for robot joints and sensors.
The EDU platform supports high-power computing modules, including configurations up to 100 TOPS.
Each Unitree tendon-driven dexterous hand provides 2 actuated degrees of freedom with hidden internal wiring and compatibility with R1.
R1 EDU uses a binocular camera for onboard visual perception.
The R1 EDU base provides 26 joint degrees of freedom. Two Unitree Dex2/5 tendon-driven hands add 2 actuated degrees of freedom per hand.
R1 EDU combines an 8-core high-performance processor with optional high-power computing modules, binocular vision, open development interfaces, and support for mainstream simulation platforms.
Research-oriented R1 EDU configuration with high-power computing and dual dexterous hands.
| Specification | R1 EDU U10 |
|---|---|
| Dimensions (H × W × D), Standing | 47.6 × 14.1 × 7.5 in |
| Weight With Battery | Approx. 63.9 lbs |
| Total Degrees of Freedom | 26 |
| Degrees of Freedom Per Leg | 6 |
| Degrees of Freedom at Waist | 2 |
| Degrees of Freedom Per Arm | 5 |
| Degrees of Freedom at Head | 2 |
| Maximum Arm Load | 4.4 lbs |
| Calf + Thigh Length | 23.6 in |
| Arm Reach | Approx. 16.5 in |
| Waist Joint Range | Y: ±150° R: ±30° |
| Knee Joint Range | -10° to +139° |
| Hip Joint Range | Y: ±157° P: -168° to +146° R: -60° to +100° |
| Hollow Internal Wiring | Yes, throughout all joints |
| Joint Encoders | Dual + single encoders |
| Cooling System | Localized air cooling |
| Power Supply | Lithium-ion battery |
| Base Computing Power | 8-core high-performance CPU |
| Audio | Standard speakers and microphone array |
| Wireless Connectivity | Wi-Fi 6, Bluetooth 5.2 |
| Perception Sensors | Standard humanoid stereo camera; optional R1 LiDAR kit available |
| Included Power Accessories | 1 charger, 1 smart battery (quick-release) |
| Handheld Remote Control | 1 included |
| Battery Life | Approx. 1 hour |
| Smart OTA Updates | Supported |
| Customization | Available |
| Secondary Development | Supports both high-level and low-level customization; provides robot models and simulation interfaces; supports simulation environments such as Isaac Sim |
| Built-in Computing Docking Station | 40 TOPS, open to secondary development, with AI algorithm technical support |
| Development Support | Technical support services, comprehensive development manuals, and ecosystem support |
| Warranty | 12 months |
| Robot Accessories | Remote control, charger, robot transport case |
| Protective Mount | Not included by default |
| R1 EDU U10 Configuration | Includes all features of the R1 EDU Smart Edition |
| Dexterous Hands | 2 tendon-cable dexterous hands |
| Dexterous Hand DOF Per Hand | 2 |
| Total Robot Degrees of Freedom With Dexterous Hands | 30 (26 + 2 + 2) |
| Upgraded Computing Docking Station | 100 TOPS; supports secondary development and includes AI algorithm technical support |
| Simulation & Development Support | Supports high-level and low-level secondary development, robot models, simulation interfaces, and simulation environments such as Isaac Sim |
| Technical & Ecosystem Support | Technical support services, comprehensive development manuals, and ecosystem support |
| U10 Perception Sensors | Standard anthropomorphic stereo camera; optional R1 LiDAR kit available |
| Dexterous Hand Wiring | No external wiring between the dexterous hands and the robot |
| Wrist Camera | Not included |
| U10 Warranty | 12 months |
| U10 Protective Mount | Not included by default |


Historique des prix
Un point de données par jour, calculé selon la date d’observation.
Montants en USD
Les moyennes sont calculées par jour UTC à partir de tous les prix d’offre enregistrés.

Unitree
$22 900
Unitree
$23 200

Unitree
$21 790
Unitree
$21 090
Unitree
$21 890
Unitree
$23 890
Unitree
$23 190
Unitree
$22 390
Unitree
$21 690
Unitree
$22 490
Unitree
$24 490
Unitree
$23 790
🍪 Préférences relatives aux cookies
Nous utilisons des cookies pour mesurer les performances. Politique de confidentialité