Prix moyen quotidien
Montants en USD
Description
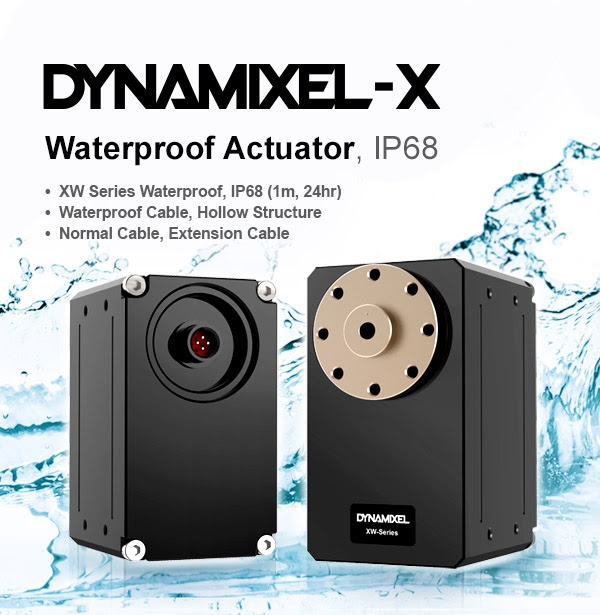
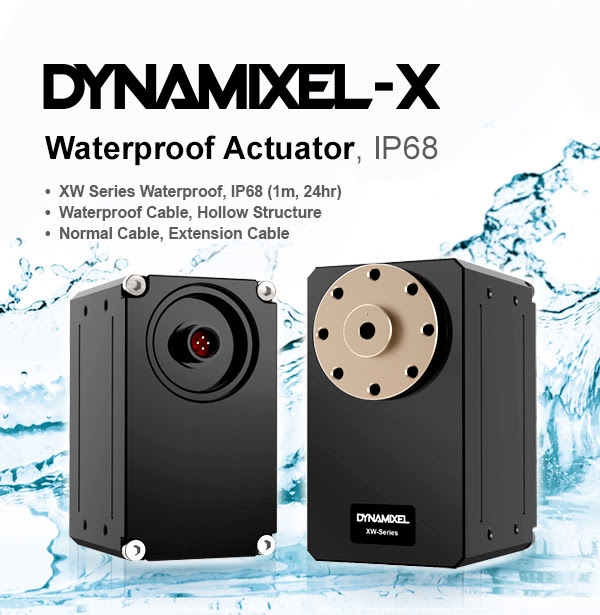
Basic Features Waterproof - IP68 (1m, 24H) Waterproof cable, hollow stucture Normal Cable, Extension Cable Improved Torque, Compact Design Enhanced Durability and Expandability Hollow Back Case Minimizes Cable Stress (3-Way Wiring) Frames Directly Screwed onto the Case (No Nuts Needed) Improved Aluminum Case Heat Sink Operating Modes Current-Based Torque Control (4096 steps, 2.69mA/step) Profile Control for Smooth Motion Planning Trajectory Data and Moving Status (In-Position, Following Error, etc.) Energy Efficient (Standby Current Reduced from 100mA to 40mA) Model: XW540-T260-R Weight : 185g Torque : 9.5 N·m [Stall torque] Speed : 40 rpm [No load speed] Dimensions: 33.5 X 58.5 X 44 (WⅹHⅹD) [mm] Motor: Coreless IP68 (1m, 24hr) For more detailed information, please visit the Product Information page. Performance Graph The Max Torque and the Stall Torque of Performance Graph are different in measurement methods. Stall torque is a measured value of the momentary torque that it can reach. This is generally how RC servos are measured. The Performance graph is also called as N-T curves, which is measured with the gradually increasing load. The actual motor operation environment is closer to the performance graph, not stall torque method. For this reason, the performance graph is broadly used in the industrial field. Generally, Max Torque of the Performance Graph is less than the Stall Torque. Specifications Item Specifications MCU ARM CORTEX-M3 (72 [MHz], 32Bit) Position Sensor Contactless absolute encoder (12Bit, 360 [°])Maker : ams(www.ams.com), Part No : AS5045 Motor Coreless(Maxon) Baud Rate 9,600 [bps] ~ 4.5 [Mbps] Control Algorithm PID control Resolution 4096 [pulse/rev] Backlash 15 [arcmin] (0.25 [°]) Operating Modes Current Control ModeVelcoity Control ModePosition Control Mode (0 ~ 360 [°])Extended Position Control Mode (Multi-turn)Current-based Position Control ModePWM Control Mode (Voltage Control Mode) Weight 185 g Dimensions (W x H x D) 33.5 x 58.5 x 45.9 mm Gear Ratio 260.6 : 1 Stall Torque 8.8 [N.m] (at 11.1 [V], 4.5 [A])9.5 [N.m] (at 12.0 [V], 4.9 [A])11.2 [N.m] (at 14.8 [V], 5.9 [A]) No Load Speed 37 [rev/min] (at 11.1 [V])40 [rev/min] (at 12.0 [V])48 [rev/min] (at 14.8 [V]) Radial Load 40 [N] (10 [mm] away from the horn) Axial Load 20 [N] Operating Temperature -5 ~ +80 [°C] Ingress Protection rating IP 68 Input Voltage 10.0 ~ 14.8 [V] (Recommended : 12.0 [V]) Command Signal Digital Packet Protocol Type RS485 Asynchronous Serial Communication(8bit, 1stop, No Parity) Physical Connection RS485 Multidrop Bus ID 253 ID (0 ~ 252) Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc Part Material Full Metal Gear / Full Metal Case Standby Current 40 [mA] Package Components XW540-T260 -R 1 HN13-N105 1 Robot Cable-WP 1000mm 1 Robot Cable-WP 1000mm(Extension) 1 Wrench Bolt WB M2.5x5 16 Wrench Bolt WB M2.5x4 10 Wrench Bolt WB M3x10 1 Compatible Products Controller : OpenCM9.04 485 Expansion Board, OpenCR1.0 Interface : USB2Dynamixel, U2D2 Factory Default Settings ID : 1 Baud Rate : 57600bps (User can change various settings including ID and baud rate according to environment) Waterproof Cabling Performance Comparison Caution DYNAMIXEL XW series uses a waterproof cable. One side has a waterproof connector and the other side has a JST connector. Extension cable has waterproof connectors for both sides. Comply with the operating environment. (Depth 1 m, 24 hr in normal fresh water) Do not pull the rubber cap of the connector. The rubber cap is connected to the rubber packing, and any deformation may cause leakage. The rubber cap is designed for dust protection and is not waterproof. When using underwater, please connect a waterproof cable. Do not insert blades or other sharp objects during product operation. The OpenCR controller has a JST connector for direct connection, but since the OpenCM9.04 + OpenCM 485 expansion board only has a Molex connector, a conversion cable must be used by utilizing U2D2 PHB. Links e-Manual Drawing Software Compatibility Guide Selection Guide DYNAMIXEL SDK The NEW waterproof Servos are here! DYNAMIXEL XW Series - Waterproof Servo - IP68 The DYNAMIXEL X-Series is a line-up of high-performance networked actuators. Improved Torque, Compact Design, Enhanced Durability, and Expandability.
Basic Features Waterproof - IP68 (1m, 24H) Waterproof cable, hollow stucture Normal Cable, Extension Cable Improved Torque, Compact Design Enhanced Durability and Expandability Hollow Back Case Minimizes Cable Stress (3-Way Wiring) Frames Directly Screwed onto the Case (No Nuts Needed) Improved Aluminum Case Heat Sink Operating Modes Current-Based Torque Control (4096 steps, 2.69mA/step) Profile Control for Smooth Motion Planning Trajectory Data and Moving Status (In-Position, Following Error, etc.) Energy Efficient (Standby Current Reduced from 100mA to 40mA) Model: XW540-T260-R Weight : 185g Torque : 9.5 N·m [Stall torque] Speed : 40 rpm [No load speed] Dimensions: 33.5 X 58.5 X 44 (WⅹHⅹD) [mm] Motor: Coreless IP68 (1m, 24hr) For more detailed information, please visit the Product Information page. Performance Graph The Max Torque and the Stall Torque of Performance Graph are different in measurement methods. Stall torque is a measured value of the momentary torque that it can reach. This is generally how RC servos are measured. The Performance graph is also called as N-T curves, which is measured with the gradually increasing load. The actual motor operation environment is closer to the performance graph, not stall torque method. For this reason, the performance graph is broadly used in the industrial field. Generally, Max Torque of the Performance Graph is less than the Stall Torque. Specifications Item Specifications MCU ARM CORTEX-M3 (72 [MHz], 32Bit) Position Sensor Contactless absolute encoder (12Bit, 360 [°])Maker : ams(www.ams.com), Part No : AS5045 Motor Coreless(Maxon) Baud Rate 9,600 [bps] ~ 4.5 [Mbps] Control Algorithm PID control Resolution 4096 [pulse/rev] Backlash 15 [arcmin] (0.25 [°]) Operating Modes Current Control ModeVelcoity Control ModePosition Control Mode (0 ~ 360 [°])Extended Position Control Mode (Multi-turn)Current-based Position Control ModePWM Control Mode (Voltage Control Mode) Weight 185 g Dimensions (W x H x D) 33.5 x 58.5 x 45.9 mm Gear Ratio 260.6 : 1 Stall Torque 8.8 [N.m] (at 11.1 [V], 4.5 [A])9.5 [N.m] (at 12.0 [V], 4.9 [A])11.2 [N.m] (at 14.8 [V], 5.9 [A]) No Load Speed 37 [rev/min] (at 11.1 [V])40 [rev/min] (at 12.0 [V])48 [rev/min] (at 14.8 [V]) Radial Load 40 [N] (10 [mm] away from the horn) Axial Load 20 [N] Operating Temperature -5 ~ +80 [°C] Ingress Protection rating IP 68 Input Voltage 10.0 ~ 14.8 [V] (Recommended : 12.0 [V]) Command Signal Digital Packet Protocol Type RS485 Asynchronous Serial Communication(8bit, 1stop, No Parity) Physical Connection RS485 Multidrop Bus ID 253 ID (0 ~ 252) Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc Part Material Full Metal Gear / Full Metal Case Standby Current 40 [mA] Package Components XW540-T260 -R 1 HN13-N105 1 Robot Cable-WP 1000mm 1 Robot Cable-WP 1000mm(Extension) 1 Wrench Bolt WB M2.5x5 16 Wrench Bolt WB M2.5x4 10 Wrench Bolt WB M3x10 1 Compatible Products Controller : OpenCM9.04 485 Expansion Board, OpenCR1.0 Interface : USB2Dynamixel, U2D2 Factory Default Settings ID : 1 Baud Rate : 57600bps (User can change various settings including ID and baud rate according to environment) Waterproof Cabling Performance Comparison Caution DYNAMIXEL XW series uses a waterproof cable. One side has a waterproof connector and the other side has a JST connector. Extension cable has waterproof connectors for both sides. Comply with the operating environment. (Depth 1 m, 24 hr in normal fresh water) Do not pull the rubber cap of the connector. The rubber cap is connected to the rubber packing, and any deformation may cause leakage. The rubber cap is designed for dust protection and is not waterproof. When using underwater, please connect a waterproof cable. Do not insert blades or other sharp objects during product operation. The OpenCR controller has a JST connector for direct connection, but since the OpenCM9.04 + OpenCM 485 expansion board only has a Molex connector, a conversion cable must be used by utilizing U2D2 PHB. Links e-Manual Drawing Software Compatibility Guide Selection Guide DYNAMIXEL SDK
Historique des prix
Un point de données par jour, calculé selon la date d’observation.
Montants en USD
Les moyennes sont calculées par jour UTC à partir de tous les prix d’offre enregistrés.

Robotis
$1 241,89
Robotis
1 265,40 €
Robotis
£835,83
Robotis
£754,06
Robotis
£873
Robotis
£833,94
Robotis
£759,92

Robotis
$873,89

Robotis
$873,89

Robotis
$885,39

Robotis
$885,39

Robotis
$885,39
🍪 Préférences relatives aux cookies
Nous utilisons des cookies pour mesurer les performances. Politique de confidentialité