Precio medio diario
Importes en USD
Descripción
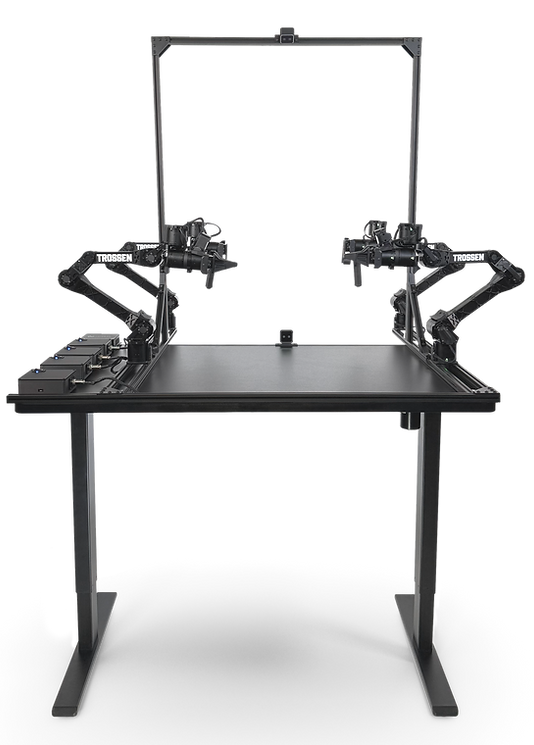
The Stationary AI is a high-performance, all-in-one robotic machine learning workstation built to meet the demand for affordable, capable data collection and model development. With a four-arm configuration, an intuitive touchscreen interface, and a high-performance desktop, it delivers cutting-edge performance right out of the box—accelerating research in automation, human-robot interaction, and advanced manipulation without the need for extensive setup or modification. SPECIFICATIONS 2X Leader-Follower WidowX AI Arm Pairs 1X 10" Touchscreen 4X Intel RealSense D405 Cameras Frame & Accessories Desk not included. CONFIGURATIONS Base Computing capabilities depend on factors such as OS, RAM, storage, and CPU/GPU performance. With Mini PC Compact Linux Mini PC, Data Collection, Teloperation, On Device Model Training*, Cloud Model Training, Model Evaluation* With High-Performance Laptop High-Performance Linux Desktop, Data Collection, Teloperation, On Device Model Training*, Cloud Model Training, Model Evaluation* SOFTWARE SUPPORT Hugging Face LeRobot Google CoLab Gazebo MuJoCo NVIDIA Issac ROS2 RESOURCES <a href="https://youtube.com/playlist?list=PL8X3t2QTE54tC1eCGDOGs_-56qOYco-gV&si=ZuR14Nyy2S37FNB5" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="M41.944 62.145V37.762L62 49.953z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> TUTORIALS <a href="https://docs.trossenrobotics.com/" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="M64 39.688H36a1.626 1.626 0 0 1 0-3.25h28a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M48.444 47.646H36a1.626 1.626 0 0 1 0-3.25h12.444a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M56.223 55.604H36a1.626 1.626 0 0 1 0-3.25h20.223a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M48.444 63.562H36a1.626 1.626 0 0 1 0-3.25h12.444a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> </g> </svg> </a> DOCUMENTATION <a href="https://github.com/interbotix" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="m36.482 50.751 7.274 2.447v4.083L32 52.493v-3.537l11.756-4.788v4.069z" fill="#ffffff" data-color="2"></path> <path d="M48.065 60.513h-3.178l6.61-21.025h3.192l-6.623 21.025Z" fill="#ffffff" data-color="2"></path> <path d="m63.545 50.711-7.235-2.46v-4.069L68 48.97v3.537l-11.69 4.788v-4.069l7.235-2.513Z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> GITHUB <a href="https://drive.google.com/drive/folders/1bVi37QH0NhnrXrNQ6zcDeJ-FLGykucKv?usp=sharing" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="m50 55.851-7.893-7.823 2.319-2.347 3.975 4.192V37.72H51.6v12.153l3.965-4.192 2.328 2.347z" fill="#ffffff" data-color="2"></path> <path d="M40.332 54.208v4.57h19.336v-4.57H62v7.072H38v-7.072z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> DOWNLOADS
The Stationary AI is a high-performance, all-in-one robotic machine learning workstation built to meet the demand for affordable, capable data collection and model development. With a four-arm configuration, an intuitive touchscreen interface, and a high-performance desktop, it delivers cutting-edge performance right out of the box—accelerating research in automation, human-robot interaction, and advanced manipulation without the need for extensive setup or modification. SPECIFICATIONS 2X Leader-Follower WidowX AI Arm Pairs 1X 10" Touchscreen 4X Intel RealSense D405 Cameras Frame & Accessories Desk not included. CONFIGURATIONS Base Computing capabilities depend on factors such as OS, RAM, storage, and CPU/GPU performance. With Mini PC Compact Linux Mini PC, Data Collection, Teloperation, On Device Model Training*, Cloud Model Training, Model Evaluation* With High-Performance Laptop High-Performance Linux Desktop, Data Collection, Teloperation, On Device Model Training*, Cloud Model Training, Model Evaluation* SOFTWARE SUPPORT Hugging Face LeRobot Google CoLab Gazebo MuJoCo NVIDIA Issac ROS2 RESOURCES <a href="https://youtube.com/playlist?list=PL8X3t2QTE54tC1eCGDOGs_-56qOYco-gV&si=ZuR14Nyy2S37FNB5" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="M41.944 62.145V37.762L62 49.953z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> TUTORIALS <a href="https://docs.trossenrobotics.com/" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="M64 39.688H36a1.626 1.626 0 0 1 0-3.25h28a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M48.444 47.646H36a1.626 1.626 0 0 1 0-3.25h12.444a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M56.223 55.604H36a1.626 1.626 0 0 1 0-3.25h20.223a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M48.444 63.562H36a1.626 1.626 0 0 1 0-3.25h12.444a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> </g> </svg> </a> DOCUMENTATION <a href="https://github.com/interbotix" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="m36.482 50.751 7.274 2.447v4.083L32 52.493v-3.537l11.756-4.788v4.069z" fill="#ffffff" data-color="2"></path> <path d="M48.065 60.513h-3.178l6.61-21.025h3.192l-6.623 21.025Z" fill="#ffffff" data-color="2"></path> <path d="m63.545 50.711-7.235-2.46v-4.069L68 48.97v3.537l-11.69 4.788v-4.069l7.235-2.513Z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> GITHUB <a href="https://drive.google.com/drive/folders/1bVi37QH0NhnrXrNQ6zcDeJ-FLGykucKv?usp=sharing" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="m50 55.851-7.893-7.823 2.319-2.347 3.975 4.192V37.72H51.6v12.153l3.965-4.192 2.328 2.347z" fill="#ffffff" data-color="2"></path> <path d="M40.332 54.208v4.57h19.336v-4.57H62v7.072H38v-7.072z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> DOWNLOADS
Historial de precios
Un punto de datos por día, calculado según la fecha de observación.
Importes en USD
Los promedios se calculan por día UTC a partir de todos los precios de oferta registrados.

Elephant Robotics
19.900 zł

Unitree
$21.000

XAG
$18.977

Unitree
$21.000

AgileX
$18.500

Husarion
$20.995

Husarion
$20.995
Robotiq
19.960 €
Inbolt
18.800 €
Mech-Mind Robotics
19.992 €
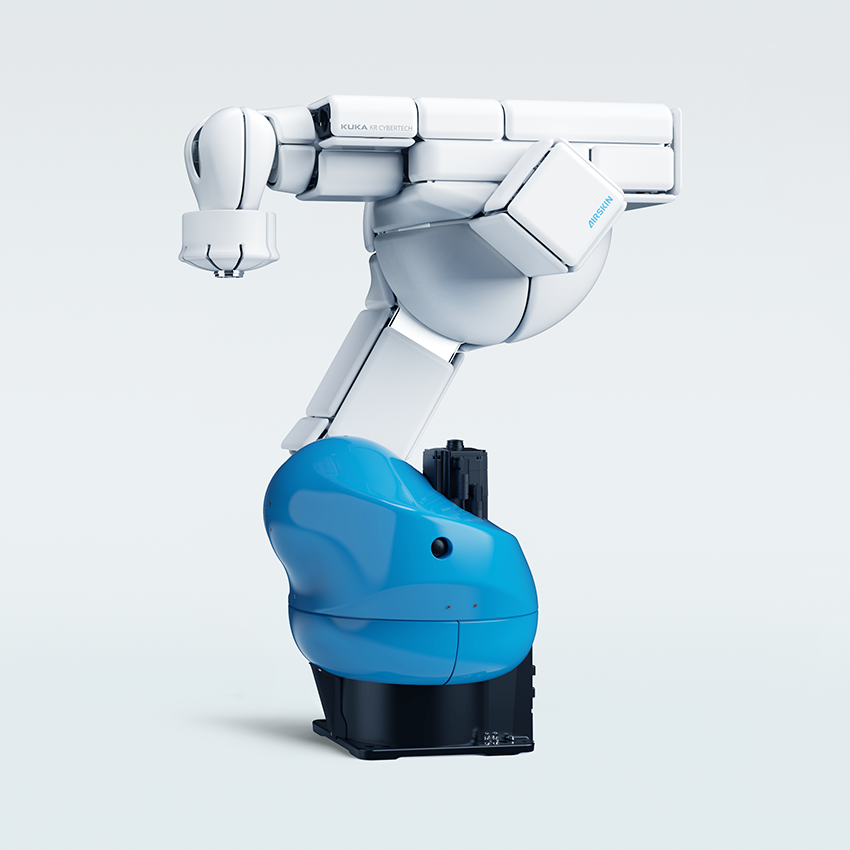
AIRSKIN
19.400 €

Unitree
$23.400
🍪 Preferencias de cookies
Usamos cookies para medir el rendimiento. Política de privacidad