Forsknings-Papers
Opsummeringer i et letforståeligt sprog af den nyeste robotforskning — humanoide robotter, firbenede robotter, industriel automatisering og AI.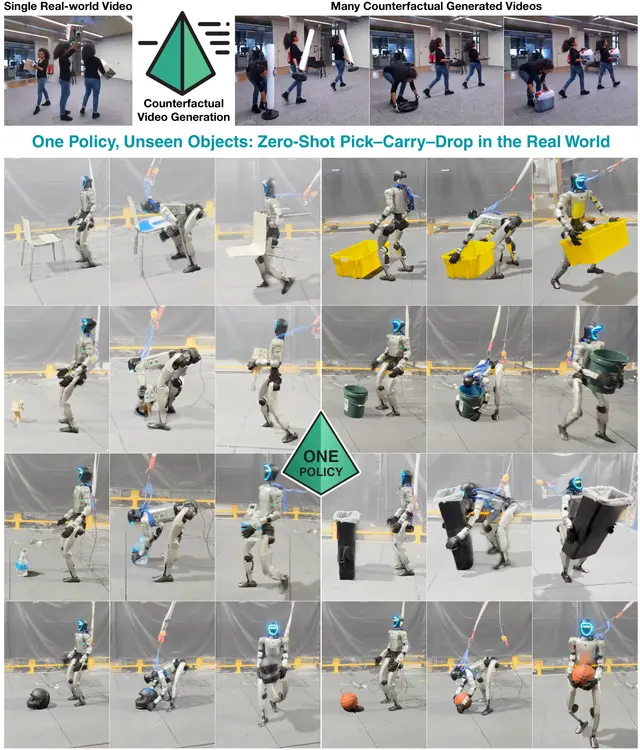
Robotics30. sep.
Robots Learn New Manipulation Skills From Videos, Not Teleoperation
AI30. sep.
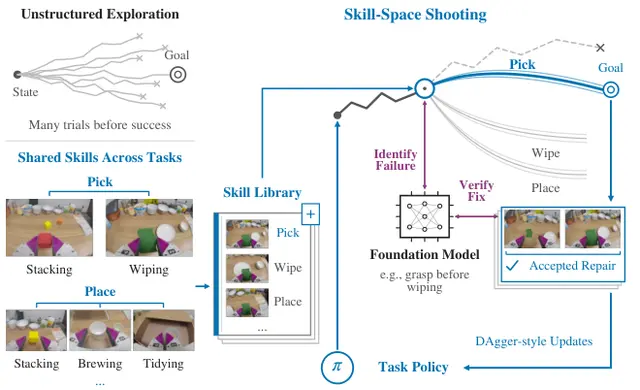
How Robots Improve Policies by Reusing Skills to Repair Their Failures
AI29. sep.
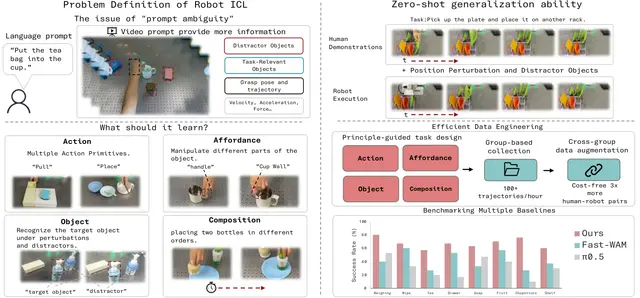
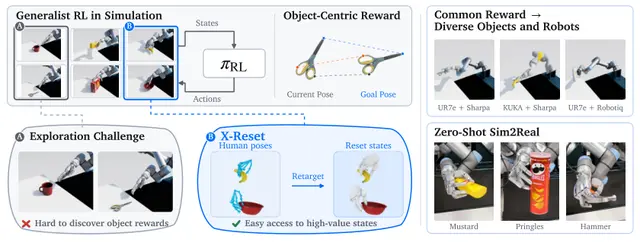
Human Demonstrations Help Robot Hands Learn Object Manipulation
Robotics29. sep.
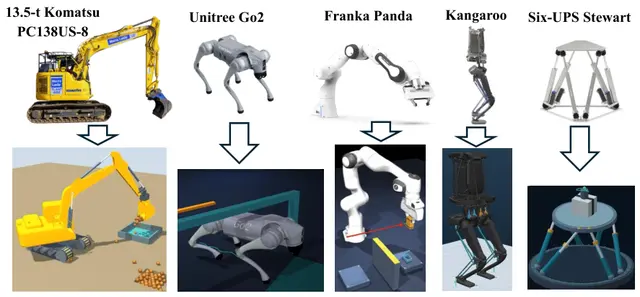
RoboCompiler: Compiling Closed-Chain Robots for Consistent Control and Simulation
AI29. sep.
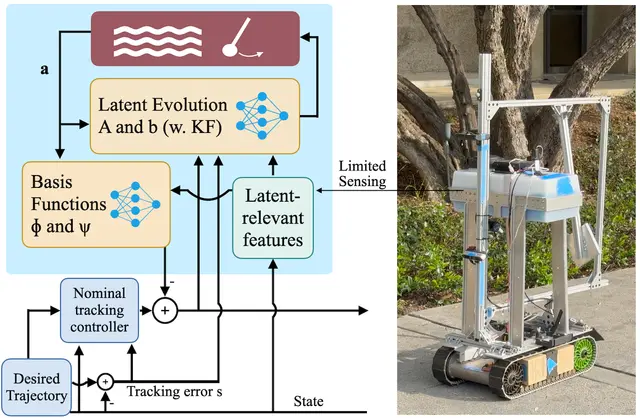
How Robots Learn to Model Hidden Disturbances for Better Robot Control
drones28. sep.
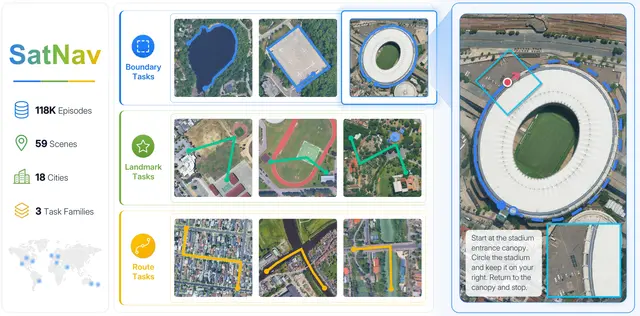
SatNav Benchmarks Long-Horizon UAV Navigation from Satellite Images
Humanoid28. sep.
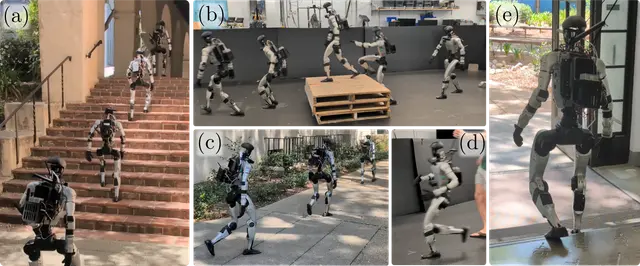
Humanoid Robots Learn to Walk, Run, Jump, and Read Rough Terrain
Robotics28. sep.
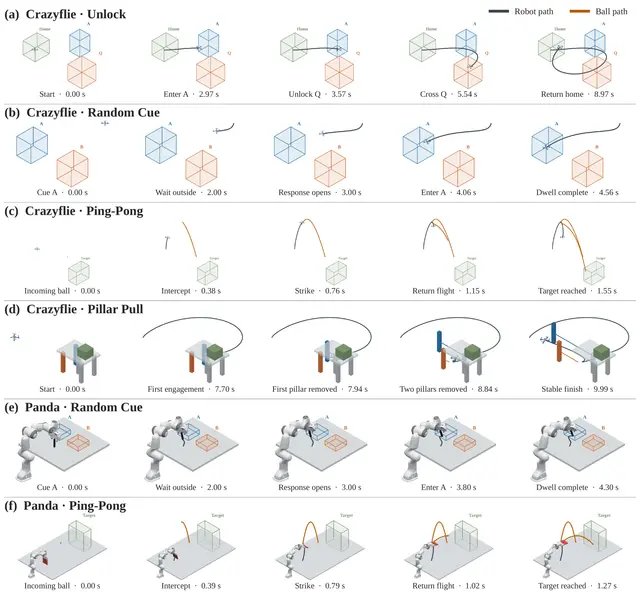
STL-Guided Robot Policy Learning from Sparse Success Signals for Control
Robotics27. sep.
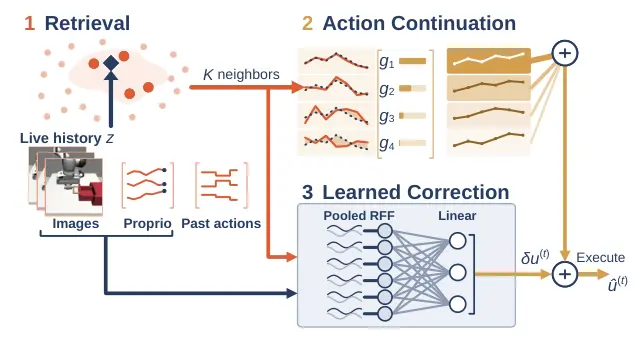
Training-Free Robot Behavior Cloning Through Retrieval and Action Continuation
Robotics27. sep.
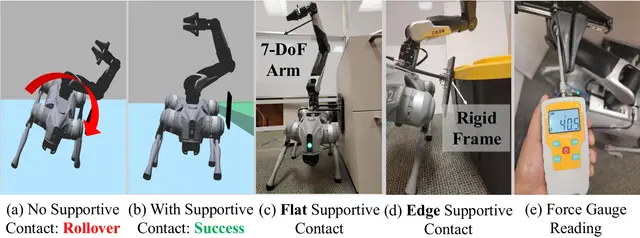
Choosing Environmental Contacts for Legged Loco-Manipulation
Robotics27. sep.
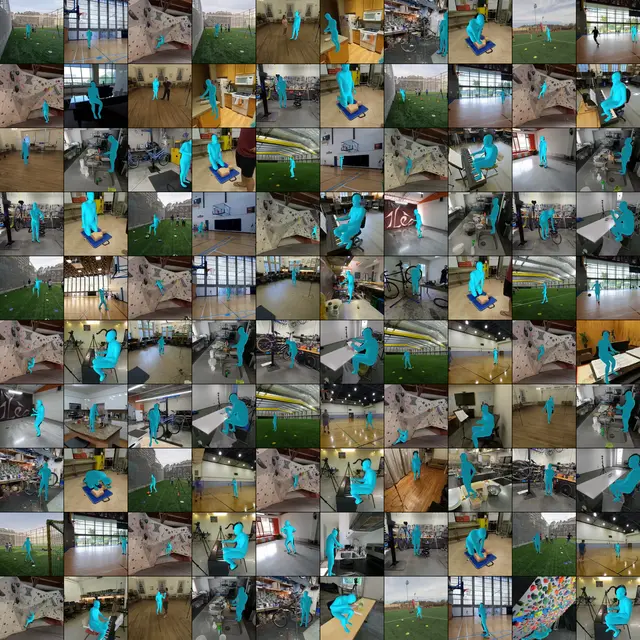
Ego-Exo4D Human Meshes Dataset for 4D Motion Reconstruction from Multi-View Video
AI26. sep.
Object-Centric World Models Help Underwater ROVs Plan Safer Salvage
AI26. sep.
Dense 3D Point Tracking with Sliding-Window De-Duplication
AI26. sep.
How Coding Agents Solve Generalized Robot Task and Motion Planning
AI25. sep.
Rolling World Action Models for Faster Closed-Loop Robot Manipulation
AI25. sep.
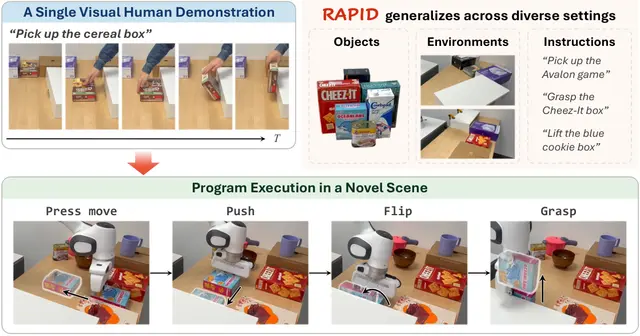
RAPID Enables Robot Manipulation Programs to Generalize Across Diverse New Scenes
AI25. sep.
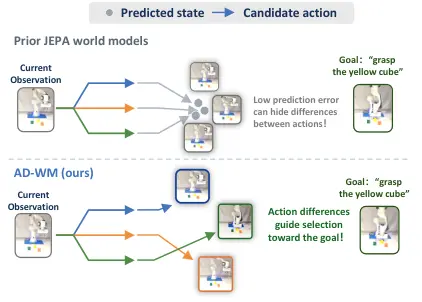
Action-Discriminative World Models Improve Counterfactual Robot Control
AI24. sep.
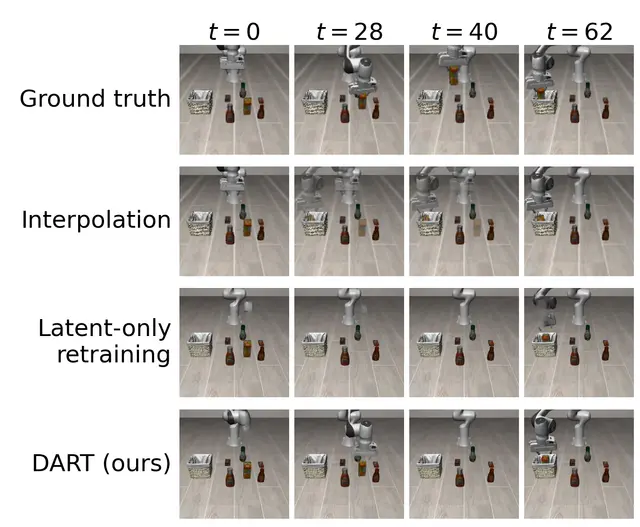
How DART Restores Lost Motion in Frozen World Models for Robots
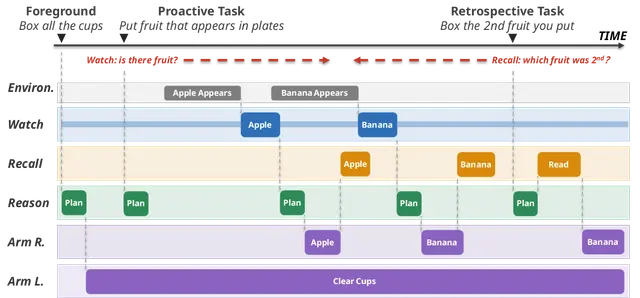
Robotics24. sep.