Forsknings-Papers
Opsummeringer i et letforståeligt sprog af den nyeste robotforskning — humanoide robotter, firbenede robotter, industriel automatisering og AI.
AI29. jun.
DexCompose Lets One Robot Hand Chain Dexterous Skills Without Retraining
Robotics28. jun.
LA4VLA: Teaching Robots to Follow Instructions Without Seeing

Robotics28. jun.
OctoSense: Self-Supervised Learning Unifies 8 Sensors for Robust Robot Perception
AI28. jun.
Hallucination in World Models is Predictable and Preventable
Robotics27. jun.
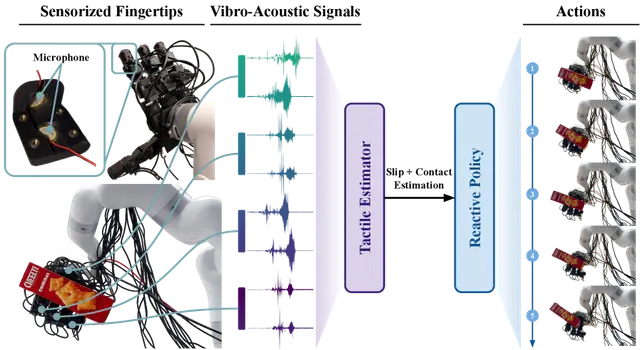
VibeAct: Using Vibration to Enable Reactive Robot Hand Dexterity
Robotics27. jun.
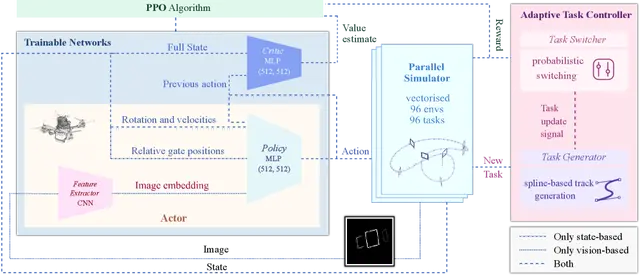
New Reinforcement Learning Method Lets Drones Race Fast in Unseen Tracks Without Retraining
Robotics27. jun.
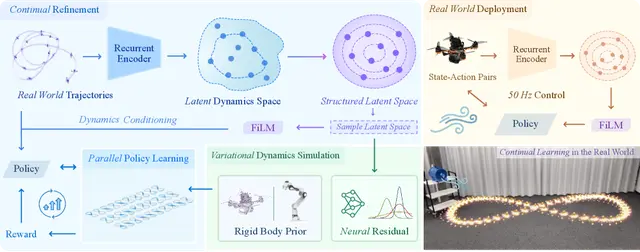
Continual Robot Learning: Adapting to Changing Dynamics in Real Time
Robotics26. jun.
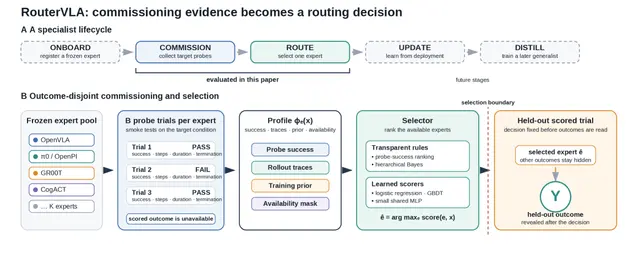
RouterVLA: Using Routine Smoke Tests to Pick the Best Robot VLA Model
Robotics26. jun.
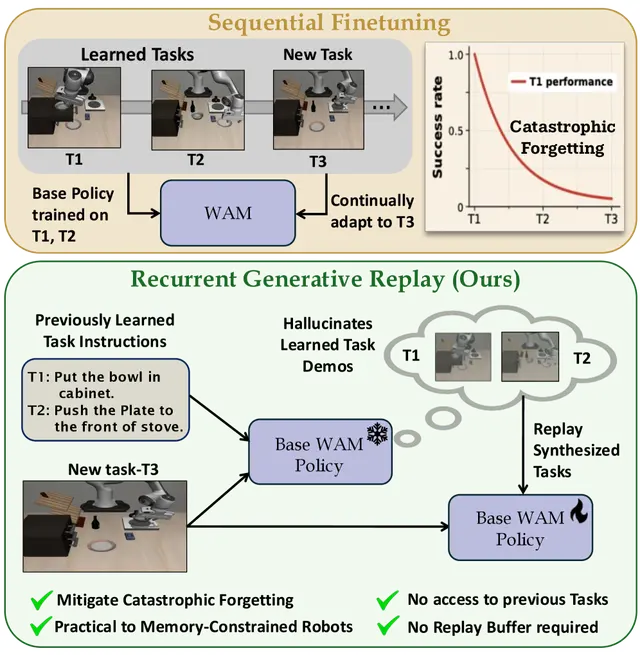
World Action Models Use Generative Replays to Prevent Robot Forgetting

Robotics26. jun.
Massive Open Dataset and Toolkit for Robot Behavior Cloning
Robotics25. jun.
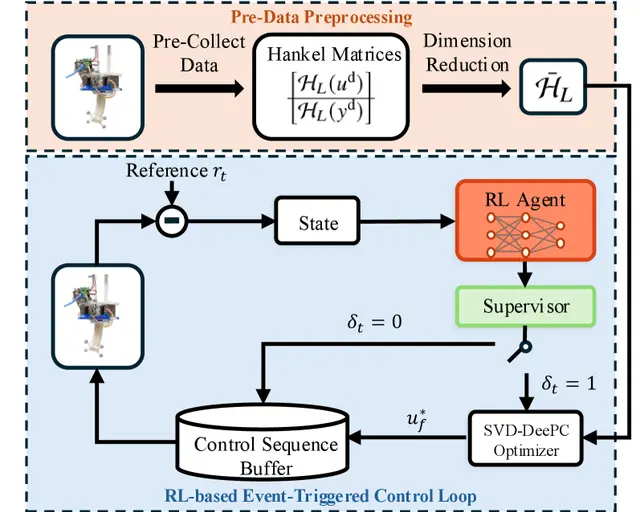
Deep Reinforcement Learning Makes Cable-Driven Soft Robot Arms More Computationally Efficient
Robotics25. jun.
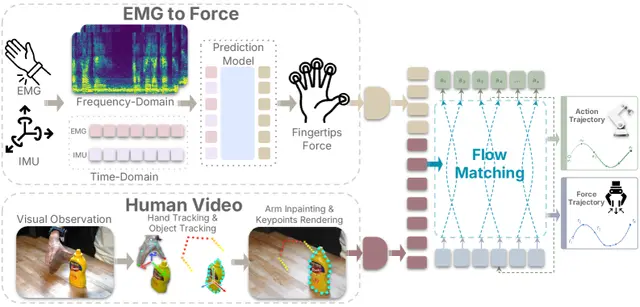
ForceBand: Learning Forceful Robot Manipulation Through Muscle Sensing
AI25. jun.
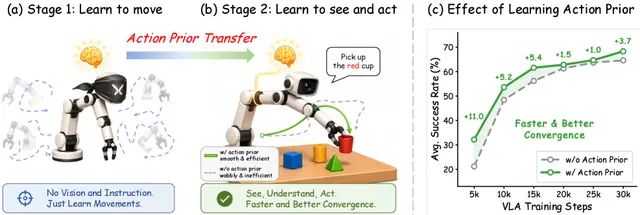
Robots Learn the Feel of Movement Before Learning to See and Act
Robotics24. jun.
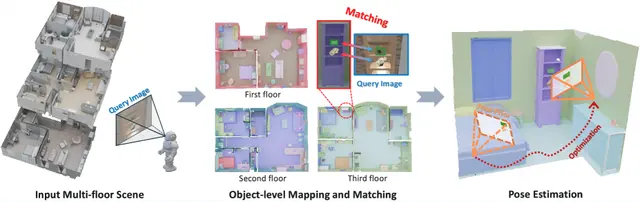
OpenReLoc: Object-Level Camera Relocalization with Open-Vocabulary Understanding
Warehouse24. jun.
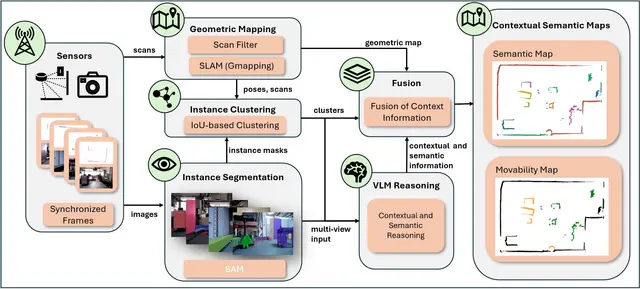
Vision-Language Model Gives Warehouse Robots Context-Aware Semantic Maps
AI24. jun.
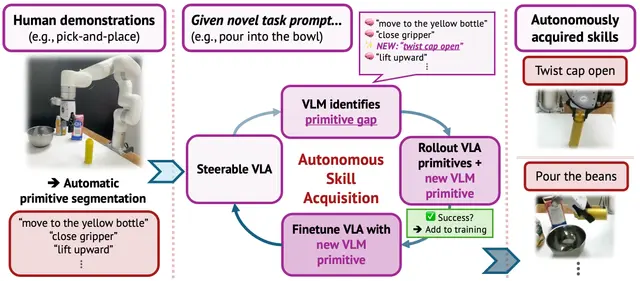
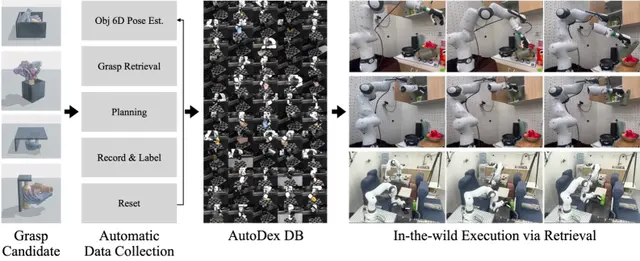
InSight: How Robots Learn New Skills Without Human Help
Robotics23. jun.
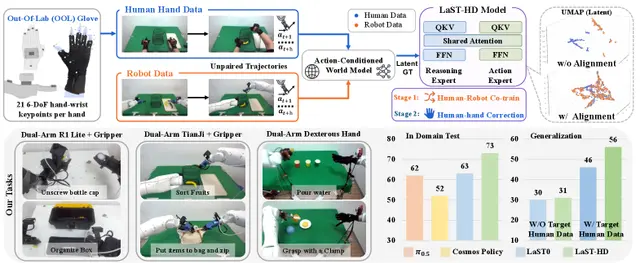
Robots Learn Physical Reasoning from Scalable Human Hand Data
Robotics23. jun.
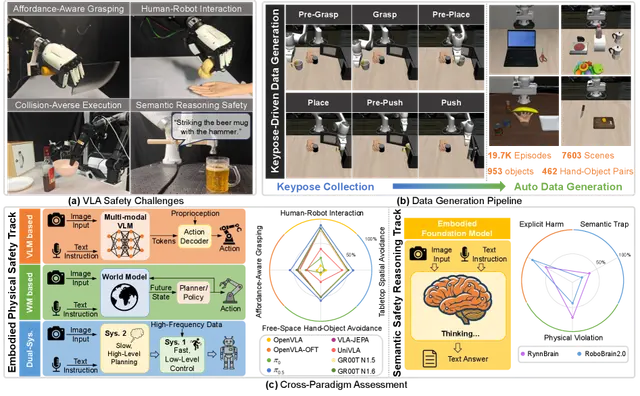
LIBERO-Safety Benchmark Puts Vision-Language-Action Robots Through Physical and Semantic Safety Tests
AI23. jun.