Forsknings-Papers
Opsummeringer i et letforståeligt sprog af den nyeste robotforskning — humanoide robotter, firbenede robotter, industriel automatisering og AI.
Roboticsi dag
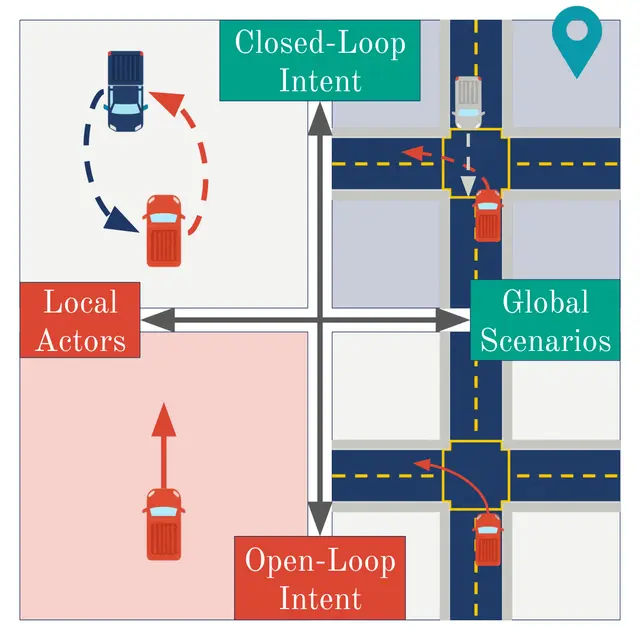
Keeping Autonomous Driving Test Scenarios on Track with Closed-Loop Policy Orchestration
AIi dag
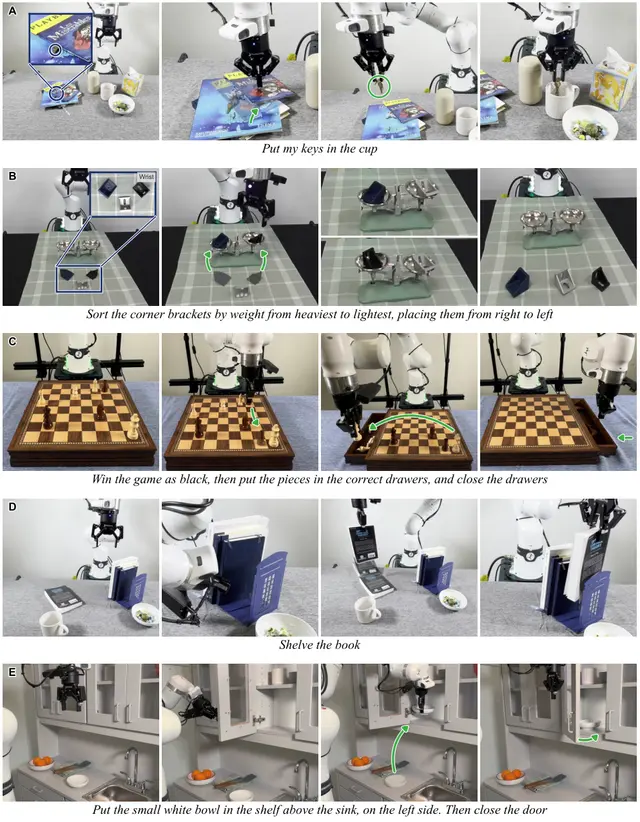
A Robot That Writes Code to See, Search, and Manipulate Objects
Roboticsi går
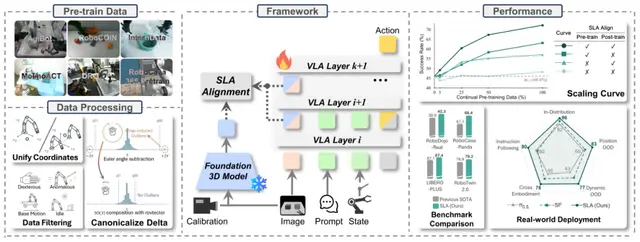
How Continual Training Scales Robot Skills Across Tasks and Robot Bodies
Roboticsi går
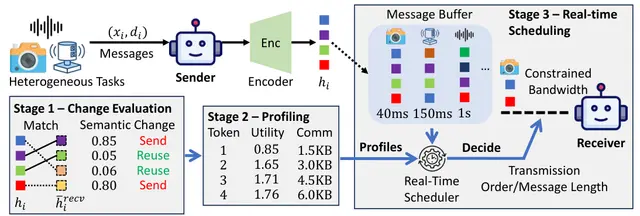
Real-Time Latent Communication for Cyber-Physical Agents
Roboticsi går
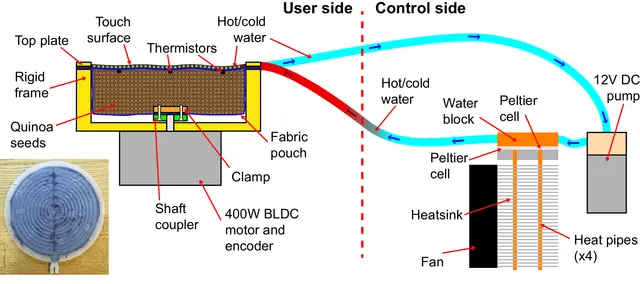
A Haptic Interface Combines Softness and Temperature Control in Real Time
Humanoidi forgårs
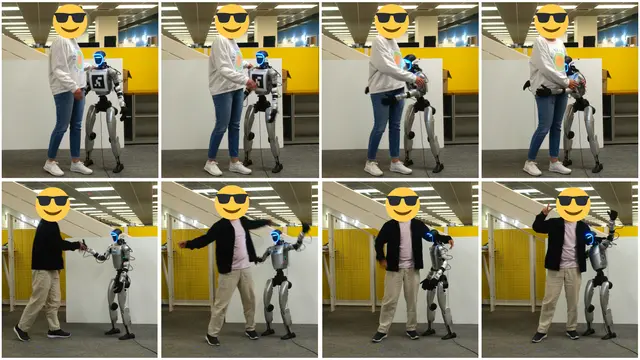
How Humanoids Learn Natural, Contact-Aware Human Interaction Through Motion
Roboticsi forgårs
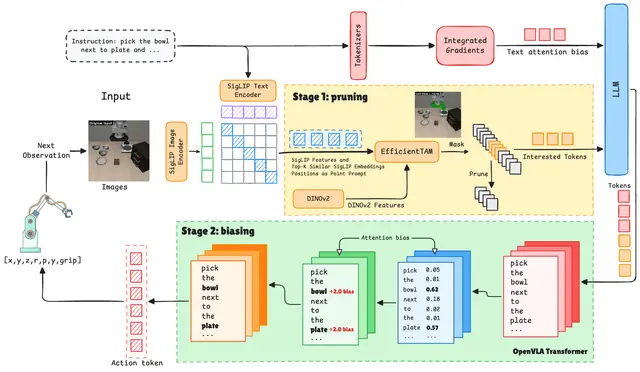
T3R Cuts Visual Tokens for Faster, More Robust Vision-Language-Action Models
AIi forgårs
Calibrated Latent Probing Predicts and Classifies VLA Failures Before They Happen
Robotics3 dage siden
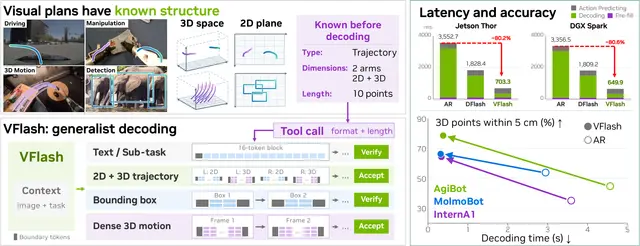
VFlash Lets Robots Decode Visual Plans Into Useful Actions More Quickly
Robotics3 dage siden
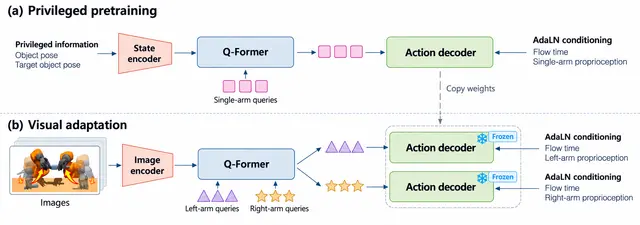
Dexterous Robot Hands Reuse RL Skills to Learn from Fewer Demos
Robotics3 dage siden
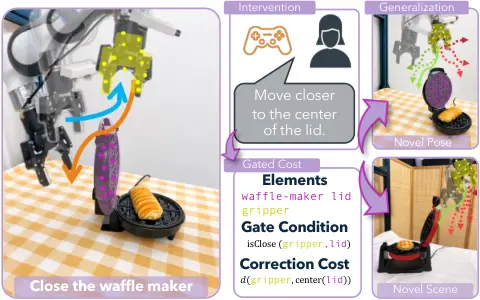
How Robots Learn Transferable VLA Corrections from Semantic Human Interventions
AI4 dage siden
How Reinforcement Learning Improves Generalist Robot Policies at Scale
Humanoid4 dage siden
Simulation Trains Humanoids to See, Plan, and Move in Real Worlds
Robotics4 dage siden
Fast GPU Planning for Torque-Limited, Collision-Free Robot Motion
AI5 dage siden
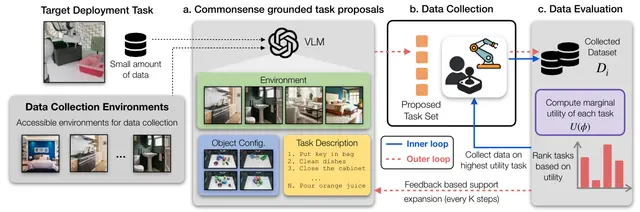
GUILD Guides Robot Imitation Learning Data Collection Across Auxiliary Tasks
AI5 dage siden
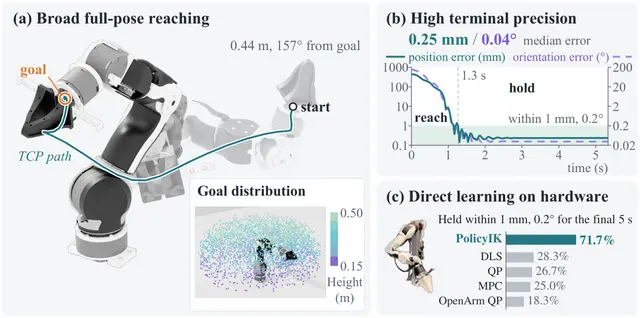
PolicyIK Uses Reinforcement Learning for Precise Robot Arm Inverse Kinematics
AI5 dage siden
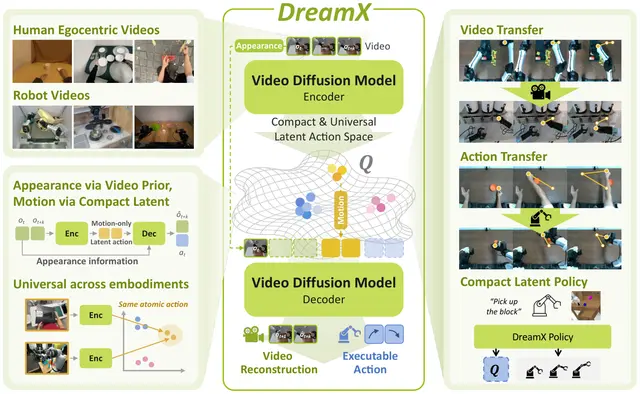
DreamX Learns Transferable Robot Actions from Video Diffusion Models
Robotics6 dage siden
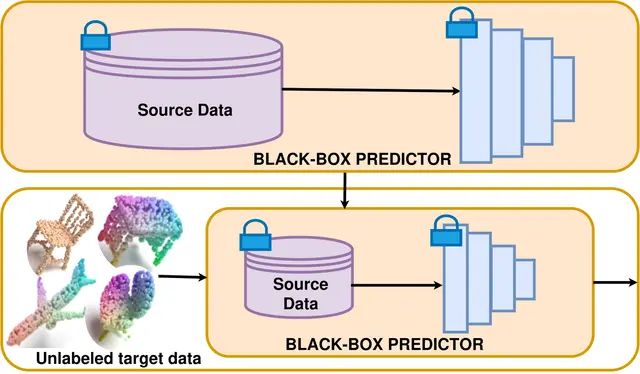
Backpropagation-Free Black-Box Domain Adaptation for Robust 3D Point Cloud Recognition
AI6 dage siden